Week-7 Challenge: DC Motor Control
EV BATCH - 17
1. (A) Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
(B) Comment on the armature current shoot-up from the scope results.
(C) Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
1(A). Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
Aim:
To Read and Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
Theory:
The matlab demo model of speed control of a DC motor using BJT H- bridge . The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of IV). Therefore, the IGBT block can be used to model the BJT device .
- The IGBT block does not simulate the gate current controlling the BUT or IGBT. The switch is controlled by a Simulink signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm) it simulates a fan type load (where Load torque is proportional to square of speed),
- The armature mean voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%
- The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models) Two transistors are switched simultaneously: Q1 and Q4 or 02 and 03. When Ol and 04 are fired a positive voltage is applied to the motor and diodes D2 D3 operate as free-wheeling diodes when Q and Q4 are switched off. When Q2 and 03 are fired, a negative voltage is applied to the motor and diodes DI-D4 operate as free wheeling diodes when Q2 and 03 are switched off.
Simulation Model:
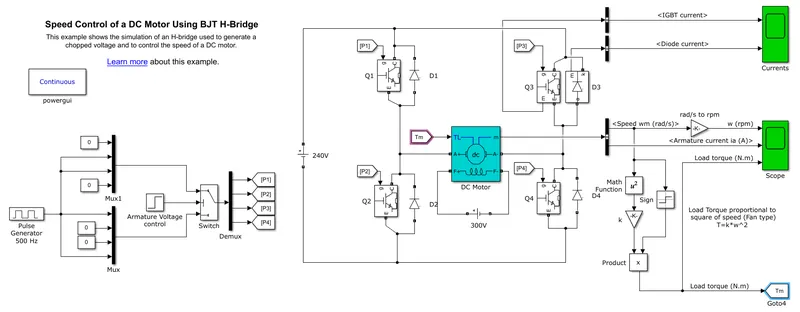
- Initially, we run MATLAB demo Speed control of a DC motor using BJT H bridge with all it's default values and different pulse width(duty cycle) 75%, 55%, and 45% .
- From this we get following three plot results.
Results:
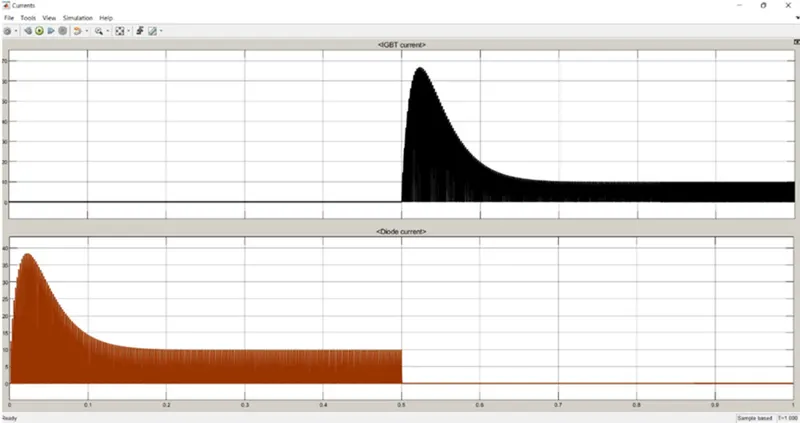
>> Output of IGBT and DIODE Current:
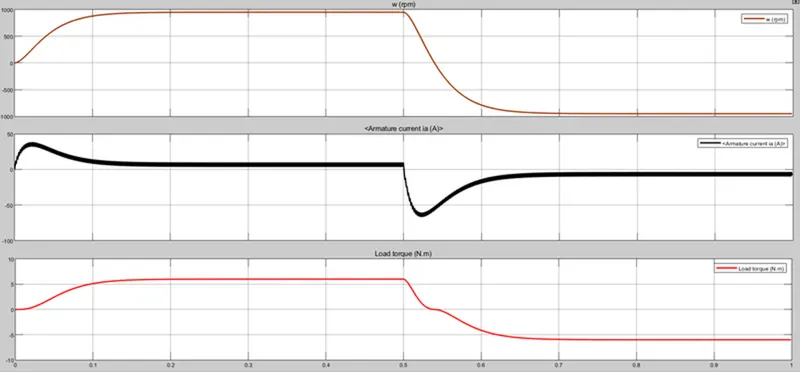
>> Output with DUTY CYCLE 75%:
>> Output with DUTY CYCLE 55%:
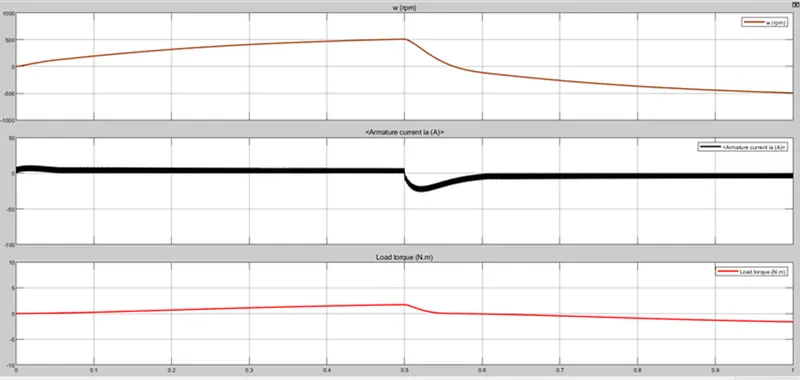
>> Output with DUTY CYCLE 45%:
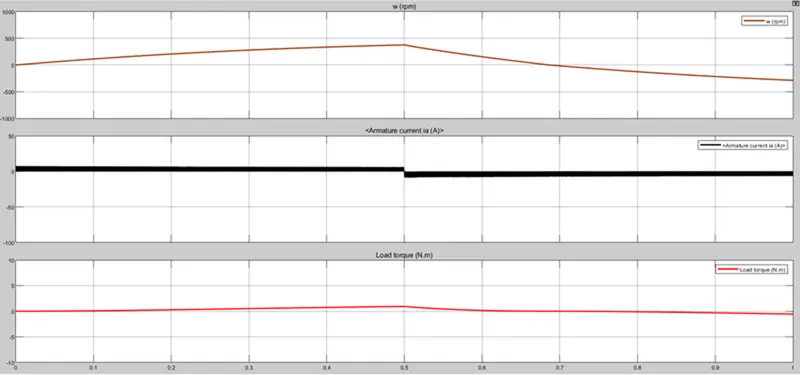
1(B). Comment on the armature current shoot-up from the scope results.
- From 1st plot we can see that the current plot has initially very high value and then becomes steady and after that shows same path in the - ve direction.
- In these three plots the value of this current shoot up is decreasing and the 3d plot has almost smooth current flow.
- To get steadier and smoother current floe we need to decrease and control the duty cycle.
- This shoot up happens because of the switching in the circuit that cause heat losses during switching. To avoid these losses, we use HEAT SINK material to dissipate the heat. From this the motor can change its direction of rotation easily and very smoothly.
1(C). Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
Aim:
To Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
Simulation Model:
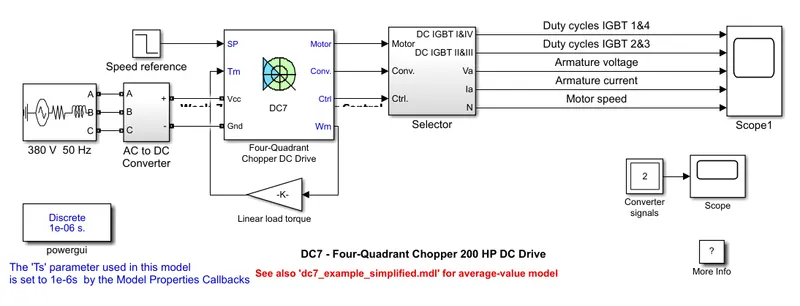
The Four-Quadrant Chopper DC Drive (DC7) block:
- The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two Pl regulators.
- The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block
- The first regulator is a speed regulator, followed by a current regulator The speed regulator outputs the armature current reference (in pu) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed,
- The speed reference change rate fallows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over current and destabilize the system
- The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices (Pulse Width Modulation). For proper system behavior, the instantaneous puiso values of IGBT devices I and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current
- In order to limit the amplitude of the current oscillations a smoothing Inductance is placed in series with the armature circuit.
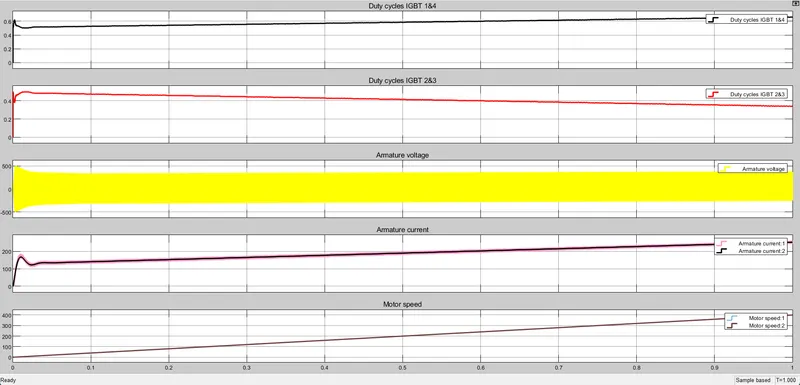
Results:
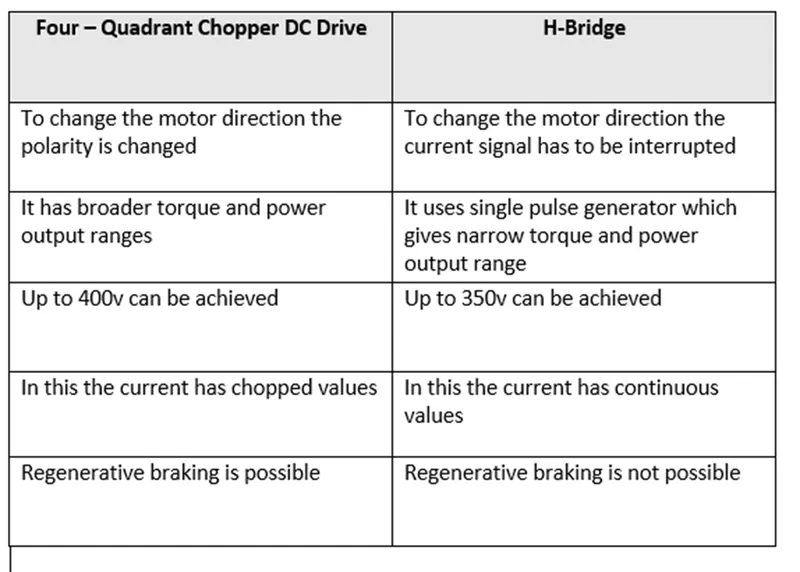
Compare of Four-Quadrant Chopper DC Drive (DC7) to H-bridge model:
------------------------------------------O-------------------------------------------------
2. Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results. (Refer to article - Multiquadrant operation of motor )
Aim:
To Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results.
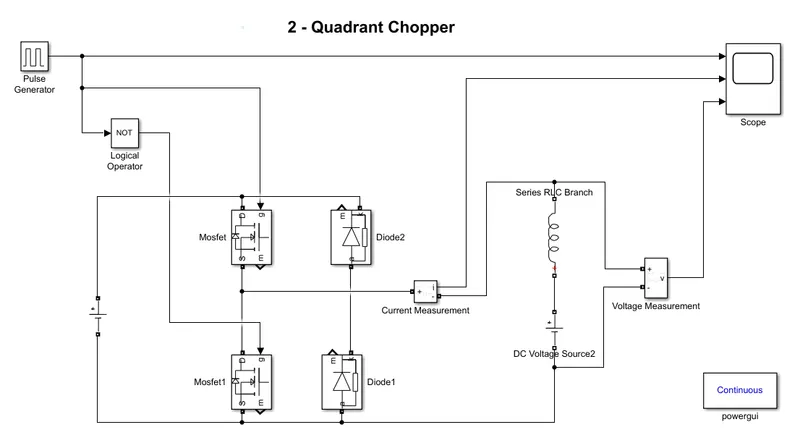
Simulation Model:
Working:
>> Two Quadrant Type - A Chopper or Type - C Chopper:
- Type C chopper is obtained by connecting type –A and type –B choppers in parallel.
- We will always get a positive output voltage V0 as the freewheeling diode FD is present across the load.
- When the chopper is on the freewheeling diode starts conducting and the output voltage v0 will be equal to Vs .
- The direction of the load current i0 will be reversed.
- The current i0 will be flowing towards the source and it will be positive regardless the chopper is on or the FD conducts.
- The load current will be negative if the chopper is or the diode D2 conducts. We can say the chopper and FD operate together as type-A chopper in first quadrant.
- In the second quadrant, the chopper and D2 will operate together as type –B chopper.
- The average voltage will be always positive but the average load current might be positive or negative.
- The power flow may be life the first quadrant operation ie from source to load or from load to source like the second quadrant operation.
- The two choppers should not be turned on simultaneously as the combined action my cause a short circuit in supply lines.
- For regenerative braking and motoring these type of chopper configuration is used.
>> Two Quadrant Type - B Chopper or Type - D Chopper:
- The circuit diagram of the type D chopper is shown in the above figure below.
- When the two choppers are on the output voltage v0 will be equal to Vs .
- When v0 = – Vs the two choppers will be off but both the diodes D1 and D2 will start conducting.
- V0 the average output voltage will be positive when the choppers turn-on the time Ton will be more than the turn off time Toff its shown in the wave form below.
- As the diodes and choppers conduct current only in one direction the direction of load current will be always positive.
- The power flows from source to load as the average values of both v0 and i0 is positive.
- From the wave form it is seen that the average value of V0 is positive thus the forth quadrant operation of type D chopper is obtained.
- From the wave forms the Average value of output voltage is given by
V0= (Vs Ton-VsToff)/T = Vs.(Ton-Toff)/T
Explanation:
- First open the matlab and click on the simulink then we get the simulink blank model .
- Next go the library and search the required blocks i.e, pulse generator, MOSFET, NOT gate, DC voltage source , Diode , Current measurement, Voltage measurement, series RLC branch, Scope .
- Now connect the circuit as per circuit shown in above .
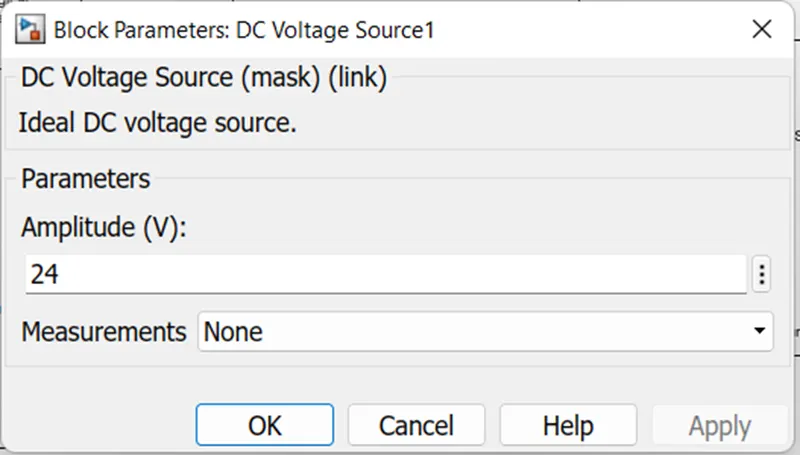
- Let the voltage of dc voltage source is 24 volts.
- Let us consider an series rlc branch and select inductor L. thus block works as a load.
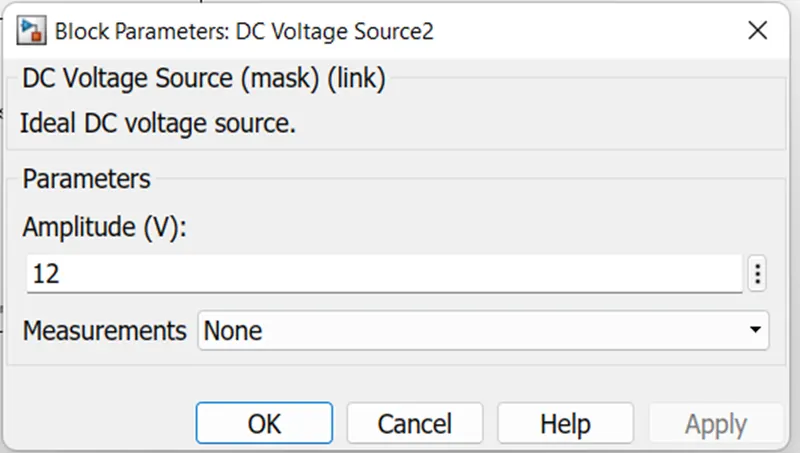
- To consider LE load i.e, motor load, and dc voltage source of 12 volts is also connected in series with inductor.
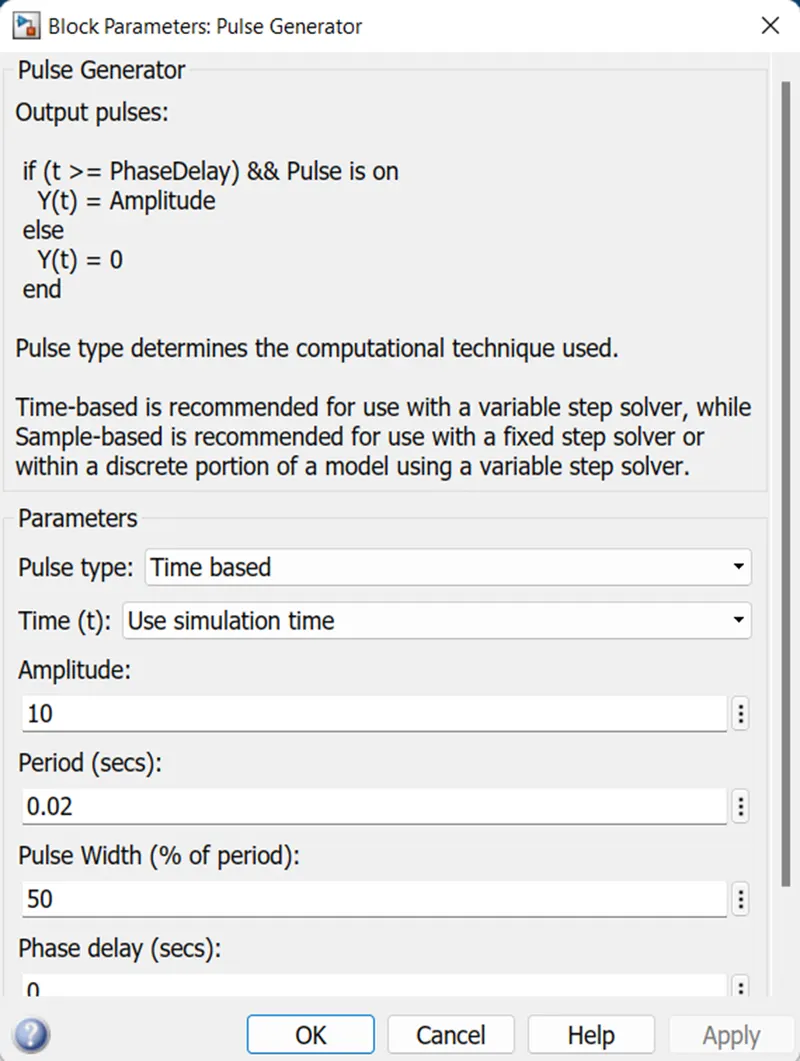
- The pulse generator block is used to create gate pulse .
- the not gate is used in the model so that the two mosfet will not get closed at the same time otherwise short circuit will occur due to use of not gate whan one mosfet is ON the other mosfet will get off and when other mosfet is ON the first mosfet will get off
- The amplitude of pulse generator is kept 10 so that we can clearly see the pulses at scope and let period be 0.02 seconds and let pulse width be 50%.
Results:
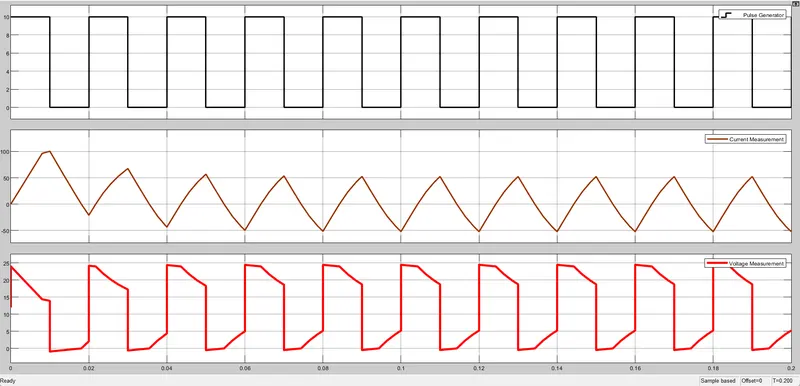
- The voltage waveform is not going less than zero. the minimum value of voltage is zero and maximum value is always in the positive direction.
- However in current waveform, the current increases and decreases.
- The current may be positive as well as negative. and the pulse amplitude is 10 thus from pulse waveform we can see that the pulse amplitude is 10.
-----------------------------------------O----------------------------------------------
3. Explain in a brief about operation of BLDC motor.
Working of BLDC Motor:
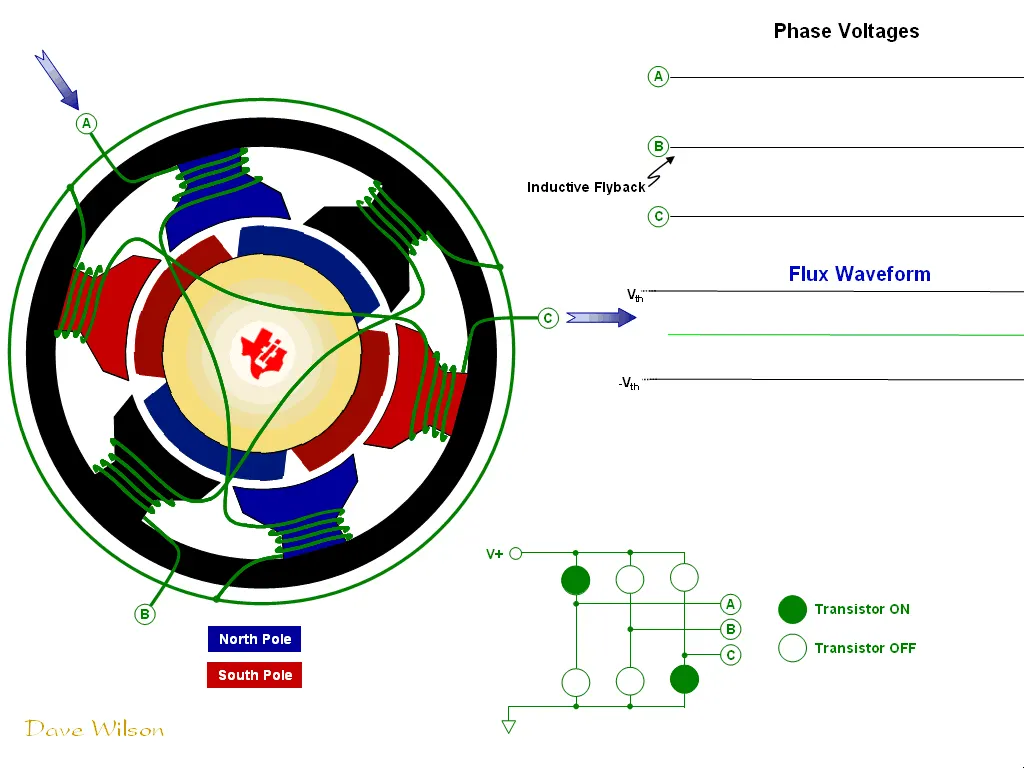
- The principles for the working of a BLDC motor are the same as for a brushed DC motor, internal shaft position feedback In case of a brushed DC motor, feedback is implemented using a mechanical commutator and brushes. With a in BLDC motor, it is achieved using multiple feedback sensors.
- The most commonly used sensors are hall sensors and optical encoders Hall sensors work on the hall-effect principle that when a current-carrying conductor is exposed to the magnetic field, charge carriers experience a force based on the voltage developed across the two sides of the conductor.
- If the direction of the magnetic field is reversed, the voltage developed will reverse as well For Hall effect sensors used in BLDC motors whenever rotor magnetic poles (N or S) pass near the hall sensor, they generate a HIGH or LOW level signal, which can be used to determine the position of the shaft
- In a commutation system-one that is based on the position of the motor identified using feedback sensors-two of the three electrical windings are energized at a time as shown in figure
- The GREEN winding labeled (001 is energized as the NORTH pale and the BLUE winding labeled as '010" is energized as the SOUTH pole Because of this excitation, the SOUTH pole of the rotor aligns with the GREEN winding and the NORTH pale aligns with the RED winding labeled 100 in order to move the rotor, the RED and BLUE windings are driergized in the direction shown in figure
- This causes the RED winding to become the NORTH pole and the BLUE winding to became the SOUTH pole. This shifting of the magnetic leid in the stator produces torque because of the deveopment of repulsion (Red winding NORTH NORTH alignment) and attraction forces (BLUE winding NORTH-SOUTH alignment) which moves the rotor in the clockwise direction.
- This torque is at its maximum when the rotor starts to move, but it reduces as the two fields align to each other. Thus, to preserve the torque or to build up the rotation, the magnetic field generated by stator should keep switching.
- To catch up with the field generated by the stator, the rotor will keep rotating. Since the magnetic field of the stator and rotor both rotate at the same frequency, they come under the category of synchronous motor.
- This switching of the stator to build up the rotation is known as commutation. For 3-phase windings, there are 6 steps in the commutation, Lo, 6 unique combinations in which motor windings will be energized.
>> Advantages of BLDC Motor:
- Less overall maintenance due to absence of brushes
- Reduced size with far superior thermal characteristics
- Higher speed range and lower electric noise generation.
- It has no mechanical commutator and associated problems
- Higher dynamic response due to low inertia and carrying windings in the stator
- Less electromagnetic interference
- Low noise due to absence of brushes
>> Disadvantages of BLDC Motor:
- These motors are costly
- Electronic controller required control this motor is expensive
- Requires complex drive circuitry
- Need of additional sensors
>> Applications of BLDC Motor:
- Computer hard drives and DVD/CD players
- Electric vehicles, hybrid vehicles, and electric bicycles
- Industrial robots, CNC machine tools, and simple belt driven systems
- Washing machines, compressors and dryers
- Fans, pumps and blowers
Conclusion:
- MATLAB demo model named Speed control of a DC motor using BJTH bridge is studied and the the armature current shoot-up is studiod and The Four Quadrant Chopper DC Drive (DC7) block is also studied and Compare it with the H-bridge model.
- 2 quadrant chopper using simulink model is made and the Various results obatined is studied
- Operation of BLDC motor is studied.