Week-7 Challenge: DC Motor Control
TASK-1
SPEED CONTROL OF A DC MOTOR
- SPEED CONTROL OF A DC MOTOR USING BJT H-BRIDGE:
AIM: To control the speed of a DC motor by chopping the voltage using BJT H-BRIDGE chopper.
DESCRIPTION:
The Bipolar junction Transistor (BJT) when used in power applications, operates as IGBT, it is like a combination of MOSFET and BJT. When it is conducting a forward voltage Vf is developed between collector and emitter (in the range of 1V). Therefore, the IGBT block can be used to model the BJT device.
The IGBT block does not simulate by the gate current controlling the BJT or IGBT. The switch (IGBT) is controlled by a Simulink signal either 1 or 0.
To construct H-bridge chopper circuit used four IGBT’s with anti-parallel diodes. DC motor load is connected as to form the H-bridge. Configuration of DC motor uses the preset model 5HP,24V,1750rpm and mechanical input given as toque load which is proportional to square of speed. Wound type field is selected and which is separately excited by 300V constant DC voltage source. H-BRIDGE chopper circuit fed by DC voltage source with given amplitude 240V. which means armature voltage can be varied from 0 to 240V when the duty cycle is varied from 0 to 100%. Duty cycle is given using pulse generator block.
In the four IGBT’s two of them are operated simultaneously either Q1, Q4 or Q2, Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2, D3 operates as free-wheeling diodes when Q1 and Q4 are in off mode. When Q2 and Q3 are a negative voltage is applied to the motor and diodes D1, D4 operates as free-wheeling diodes when Q2 and Q3 are in off mode.
MODEL:
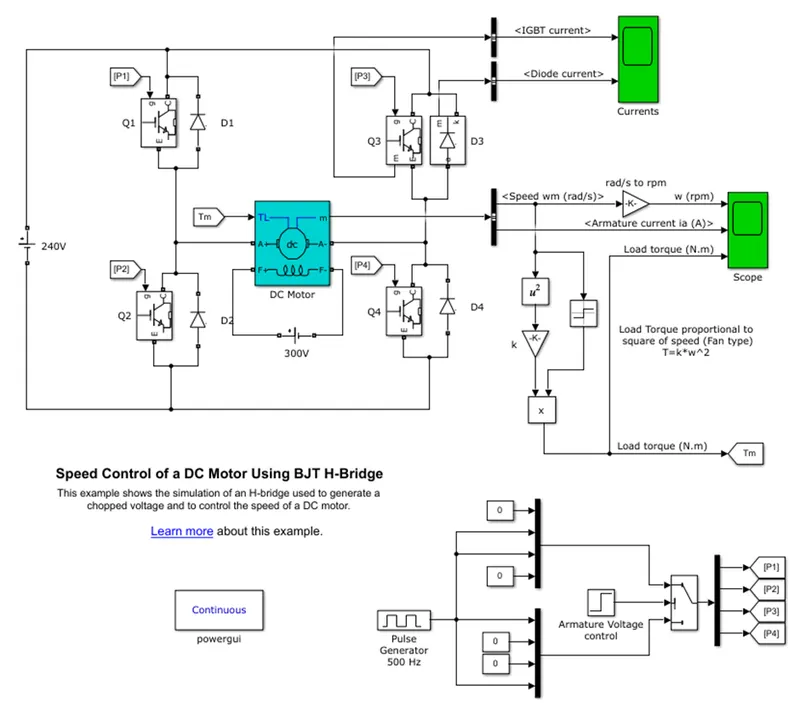
SIMULATION:
The motor starts in the positive direction from t=0 to 0.5secs with a duty cycle of 75% and gets average output voltage of 180V. At t=0.5 sec., the armature voltage suddenly reversed and the motor runs in the negative direction.
RESULTS:
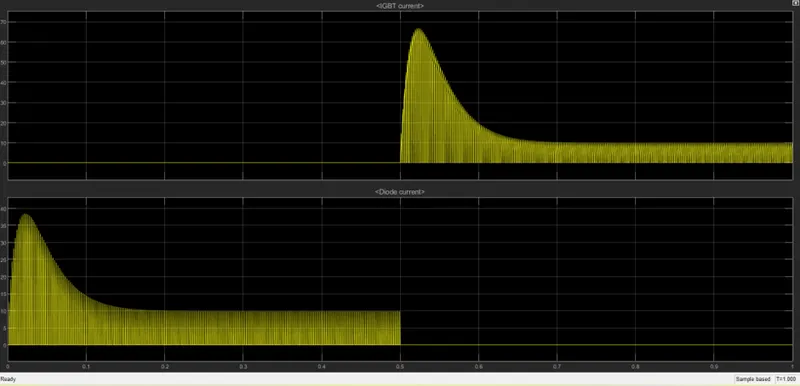
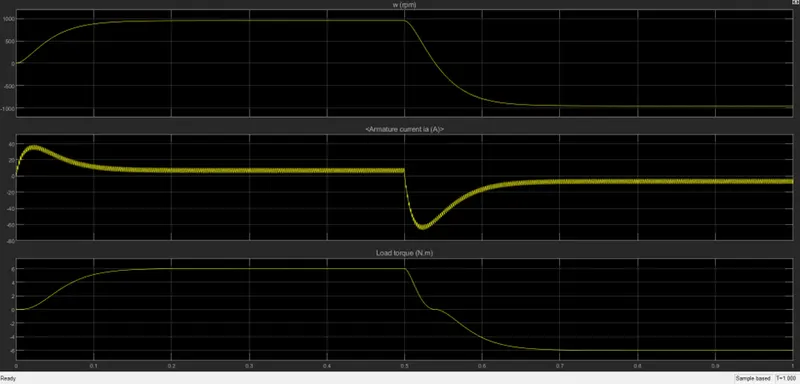
- B) ARMATURE CURRENT SHOOT-UP FROM SCOPE RESULTS:
From the armature current graph, we can observe that from T=0 secs to T=0.5 secs armature current is positive and at T=0.5 secs current direction is reversed so, it is negative. At the time of starting from 0 sec to 0.05 secs armature current is reaches to its positive peak value around 36A and settled at around 10A up to 0.5 secs. When it reversed it reaches to its negative peak value is around 65A and after sometime settled at around -7A. From the graph we can observe that at the staring current is high for few milli seconds and it is also high for few milli seconds when the voltage is reversed.
- C) FOUR QUADRANT CHOPPER DC DRIVE (DC7) BLOCK:
MODEL:
DESCRIPTION:
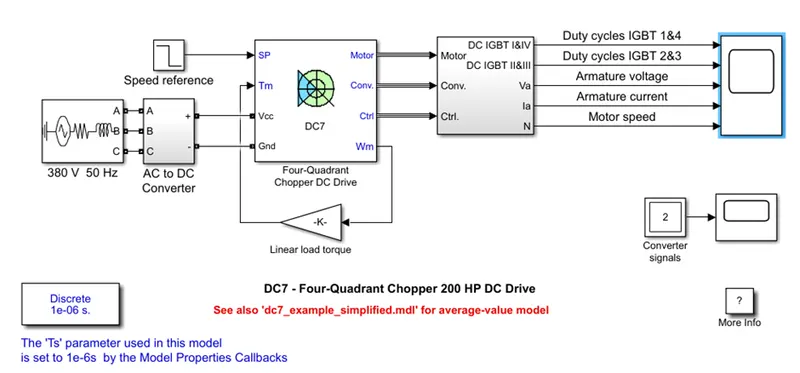
Three phase source is used for the AC supply, ph-ph rms voltage is given 380V at 50Hz frequency. Three phase ac supply is converted to DC by using bridge rectifier. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
The Four-Quadrant Chopper DC Drive (DC7) block represents a four-quadrant, DC-supplied, chopper (or DC-DC PWM converter) drive for DC motors. This drive features closed-loop speed control with four-quadrant operation. The speed control loop outputs the reference armature current of the machine. Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived. This duty cycle is then compared with a sawtooth carrier signal to obtain the required PWM signals for the chopper.
The main advantage of this drive, compared with other DC drives, is that it can operate in all four quadrants (forward motoring, reverse regeneration, reverse motoring, and forward regeneration). In addition, due to the use of high switching frequency DC-DC converters, a lower armature current ripple (compared with thyristor-based DC drives) is obtained. However, four switching devices are required, which increases the complexity of the drive system.
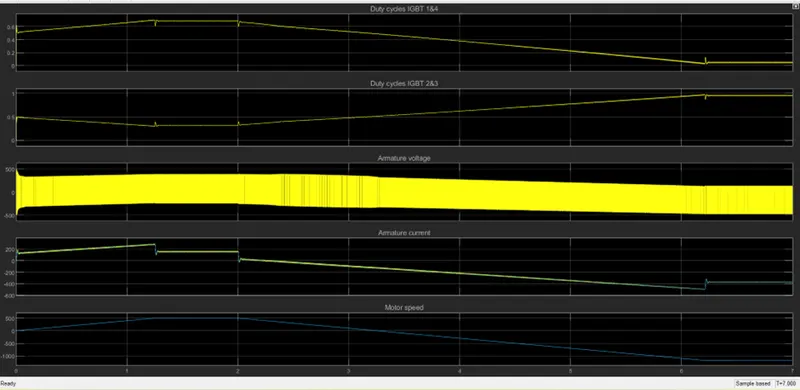
Selector block subsystem is created to take the required output signal by using bus link and armature voltage, armature current, speed, duty cycles of IGBT 1 & 4 and duty cycles of IGBT 2 & 3 are connected to scope.
RESULTS:
COMPARISON:
In H-bridge inverter armature current is not smooth as in the four-quadrant chopper and in H-bridge inverter more spikes are there in the armature current but by using DC7 block very less ripples are there in the armature current. In the four-quadrant chopper armature current follows the current reference very well, with fast response time and small ripples. Notice that the current ripple frequency is 5 kHz. Discrete signal type simulation is used in the four-quadrant chopper and in the H-bridge chopper continuous type simulation is used.
TASK-2
TWO QUADRANT CHOPPER
Aim: To develop a 2-Quadrant Chopper using Simulink and explain the working of the same with the relevant results.
Description:
2-Quadrant Chopper: Based on the operation of chopper in the quadrants the 2-Quadrant chopper is of two types.
- Class C or Type A chopper
- Class D or Type B chopper
Class C or Type A chopper
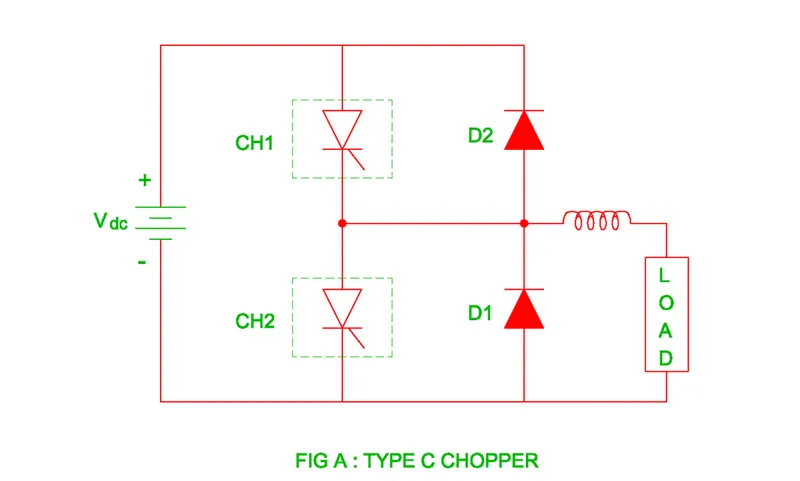
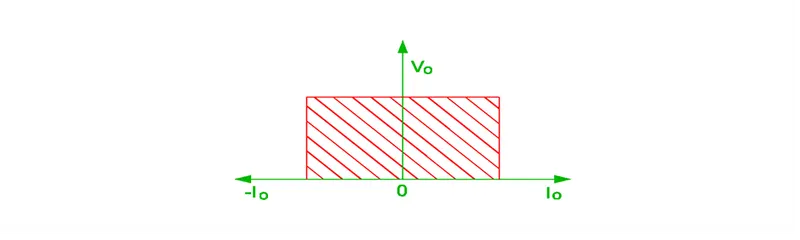
Class C chopper is obtained by connecting Class-A and Class-B choppers in parallel. We will always get a positive output voltage V0 as the free-wheeling diode FD is present across the load.
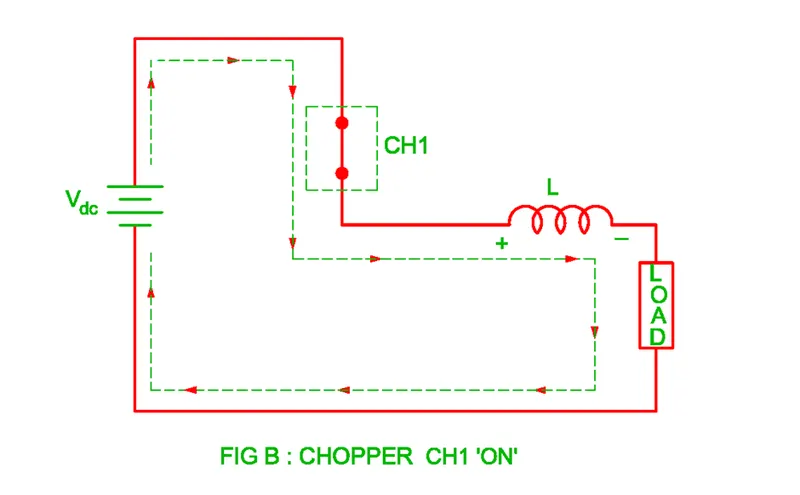
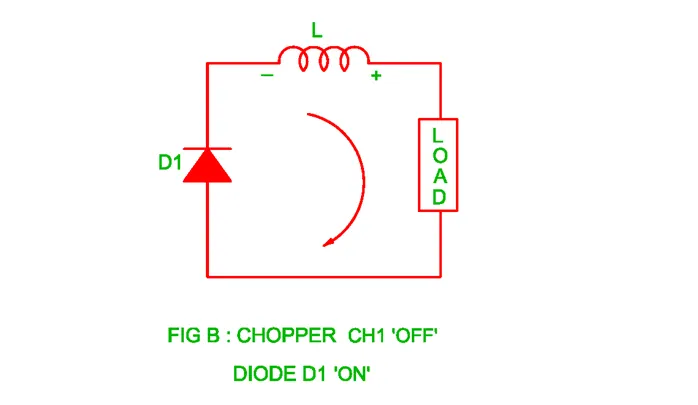
When the chopper CH-1 is ON load current i0 flows from source to the load that is i0 is positive and the inductor current increases exponentially. when the chopper CH-1 is off the free-wheeling diode conducts and current continuous to flow in the same direction through the freewheeling diode as the inductor doesn’t allow sudden change in current but the voltage will be zero this means the voltage may be positive or zero and the current is positive during CH-1 and FD operation. This acts as Class A chopper.
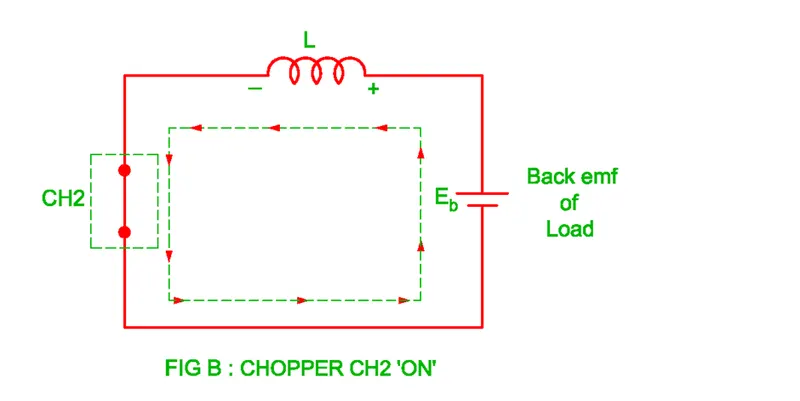
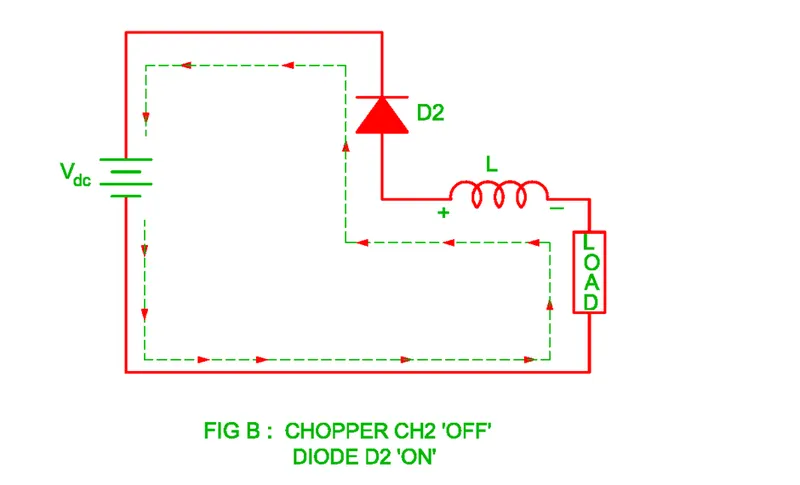
Then the chopper CH-2 is switched ON due to the back emf of DC motor, The load current flows in the negative direction through the path Load – Inductor - CH-2 – Load. The negative current flows until chopper CH-2 is switched OFF and chopper CH-1 is switched ON. When the chopper CH-2 is switched off, the stored energy of inductor dissipates its energy through path L – D2 – Vs – Load – L. This acts as Class B chopper.
When chopper CH-1 or diode FD conducts, the load current becomes positive and load current becomes negative when CH-2 or D2 conducts. The chopper CH-1 and CH-2 never conducts simultaneously otherwise the DC supply source is short circuited.
Class D or Type B chopper
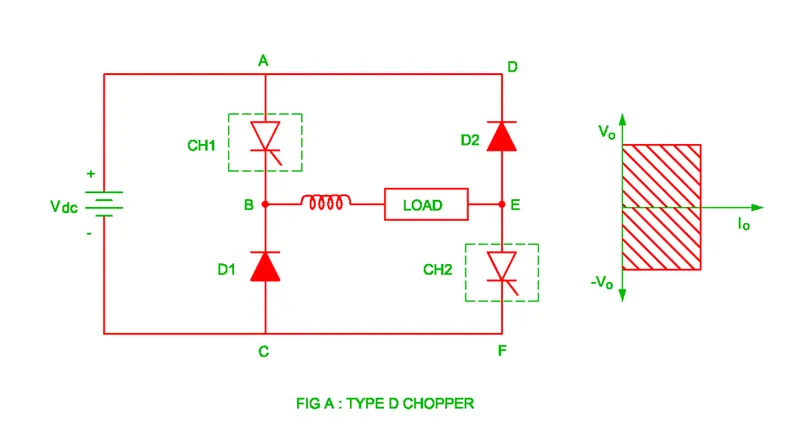
The two quadrant Type B chopper or Class D chopper works is first as well as the fourth quadrant therefore the output current remains positive but output voltage may be either positive or negative. The polarity of output voltage depends up on the chopper ON time and chopper OFF time. When TON > TOFF – Output Voltage Positive, TON > TOFF – Output Current Negative TON = TOFF – Output Voltage Zero.
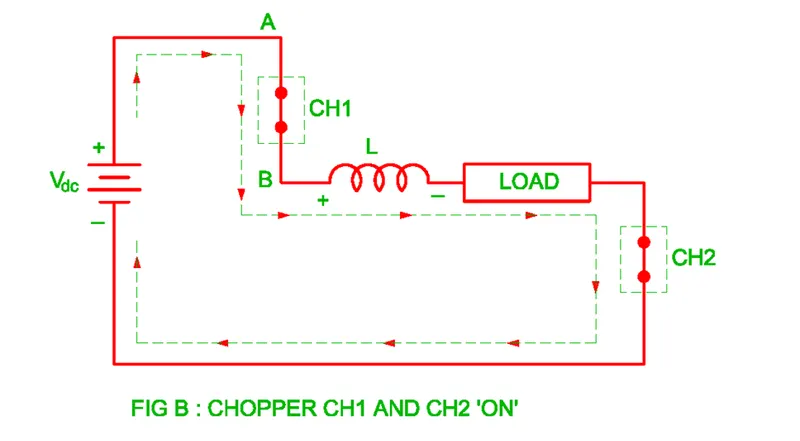
When Chopper CH-1 and CH-2 both are switched on simultaneously, the current flows through the path (+) Vdc - CH-1 – Load – CH-2 – Vdc (-). The voltage across load is equal to the supply voltage Vdc and current increases exponentially. The chopper works is first quadrant because the output voltage and output current both are positive.
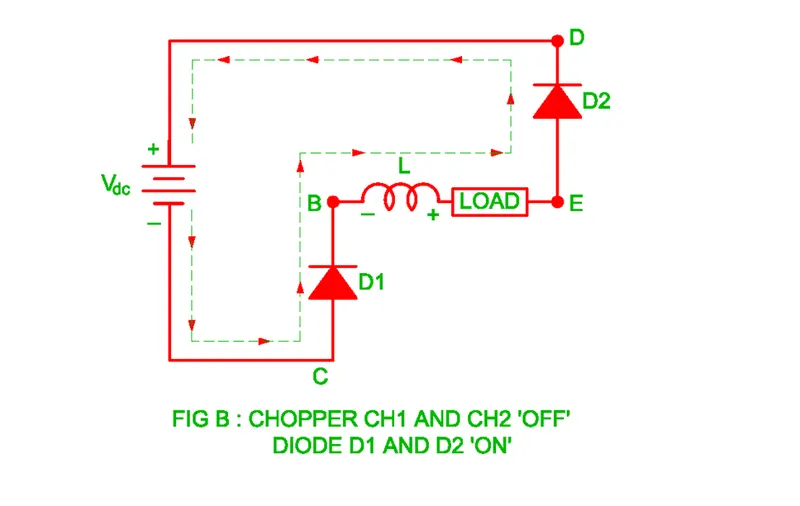
When chopper CH-1 and CH-2 both are switched OFF simultaneously, the Diode D1 and D2 forward biased and current flows through the path Load – D2 - (+) Vdc -Vdc (-) – D1. The chopper works in the fourth quadrant because the output voltage negative and output current positive. The application of Class-D chopper is in the forward motoring and regenerative braking of motor.
MODEL:
- As there are two types of 2-Quadrant Choppers i choose the Class-D type Chopper in this simulation
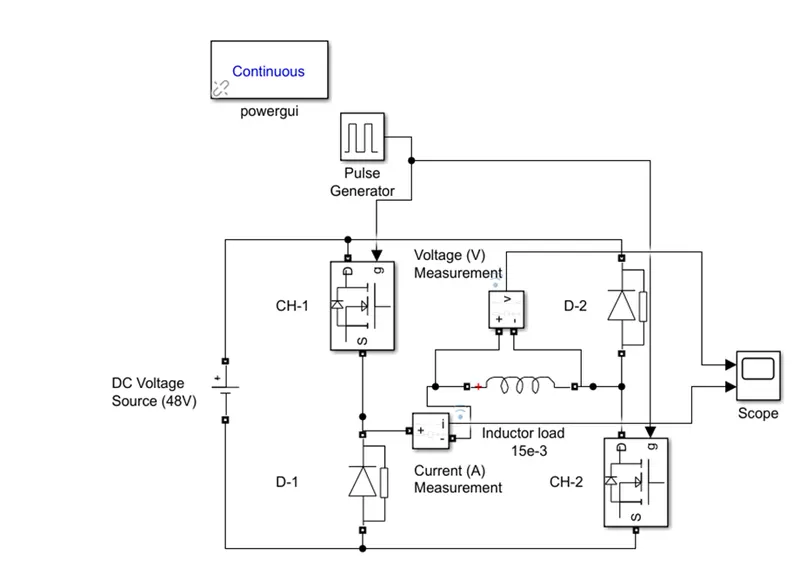
Fig showing the simulink model of 2-Quadrant Class-D chopper
Blocks Used
The Blocks used in this model are
- Powergui (Continuous)
- Pulse Generator
- DC Voltage Source
- MOSFET
- Diode
- Series RLC branch
- Current Measurement
- Voltage Measurement
- Scope
Construction
- In this model we have taken the DC supply voltage source as 48V.
- We have used two choppers and two diodes and a series RLC branch to build the circuit.
- The Choppers and Diodes in such a manner that the load will be in between the two Choppers and also it should be in between the two Diodes as well.
- The signal to gate pulses of choppers was given from the pulse generator.
- The Amplitude of the pulse was chosen to be 10 and period was taken as 0.04sec (1/f = 1/25) such that 25 pulses will be given to the gates of MOSFETS in a second.
- The pulse width % was taken as 50 that means the choppers will be ON for 50% of time period and Diodes will be forward biased for another 50%.
- The Current measurement block was connected in series with the Inductor Load and the Voltage measurement block connected in parallel.
- Here the inductor load was taken as 15e-3H.
- I choose the simulation time for 1s.
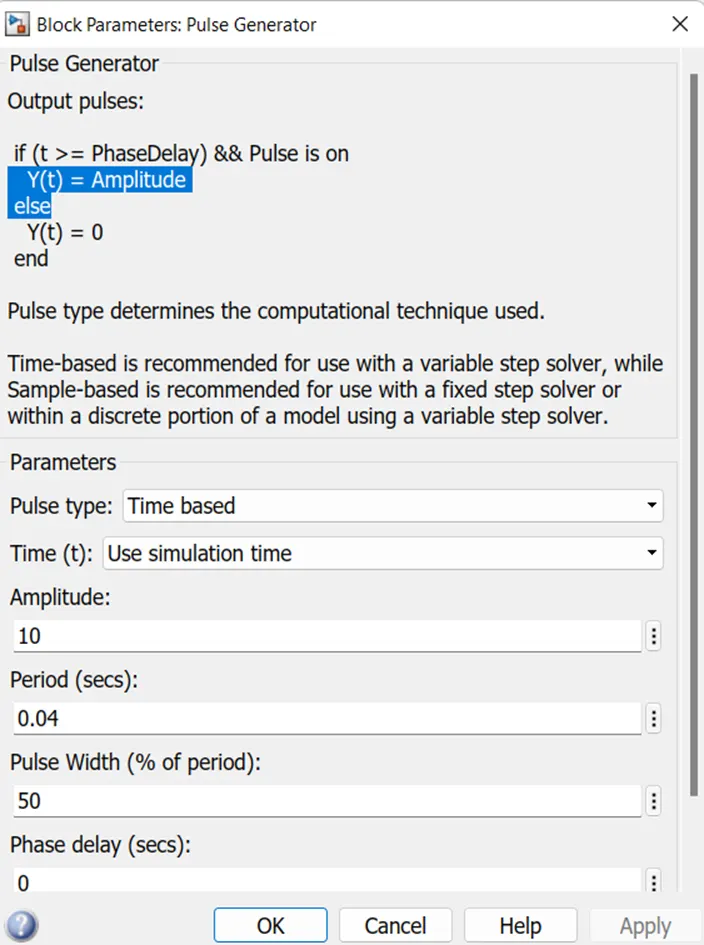
Fig showing the Block Parameters of Pulse Generator
Working
- The working of Class-D type chopper is simple, when there is pulse input signal the two Choppers CH-1 and CH-2 gets ON simultaneously.
- When the two choppers are in ON condition the load current flows from source to the load.
- Then the voltage across the load will be equal to the supply voltage and the current in the inductor load increases exponentially, as the inductor stores the energy.
- The current and the voltage will be positive in this period.
- After 50% of the Time period the pulse from the Pulse generator will become Zero then both the choppers will be in OFF state.
- When the two choppers are in OFF state then the as the inductor gets de-energized and current flows from Load to Source in this period the current will be positive but the voltage will be negative.
Results:
- From the scope we got the results
- By observing the current waveform, we can say that the load current is positive in both the quadrants.
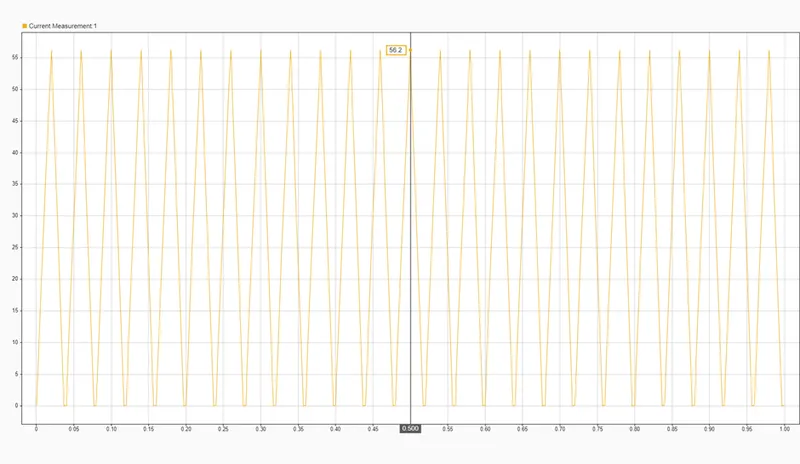
Fig showing the current across the load of 2-Quadrant Class-D chopper
- By observing the voltage waveform, we can say that the voltage across the load may be positive, zero or negative.
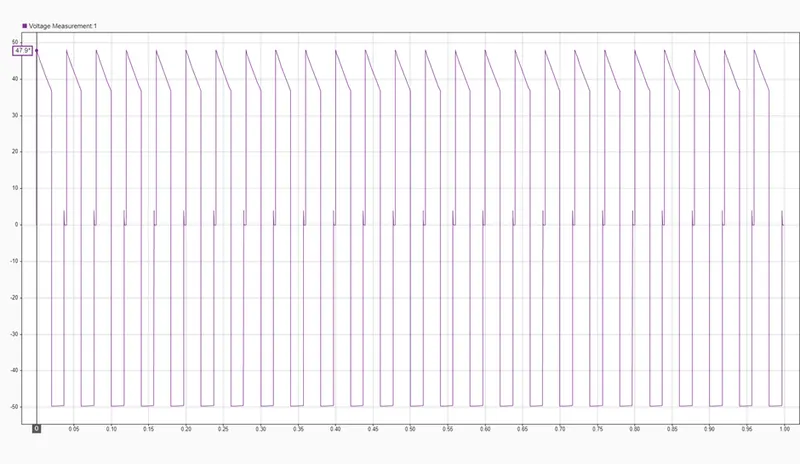
Fig showing the voltage across the load of 2-Quadrant Class-D chopper
TASK-3
BRUSHLESS DC MOTOR
DESCRIPTION:
A brushless DC electric motor also known as an electronically commutated motor or DC synchronous motor; it is a synchronous motor using a direct current electric power supply. It uses an electronic controller to switch DC currents to the motor windings producing magnetic fields which effectively rotate in the air gap (space) and which the permanent magnet rotor follows. The controller adjusts the phase and amplitude of the DC current pulses to control the speed and torque of the motor. This electronically commutated controller is an alternative to the mechanical commutator which is required brushes and used in many conventional electric motors.
CONSTRUCTION OF BLDC MOTOR:
BLDC motors can be constructed in different physical configurations. Depending on the stator windings, these can be configured as single-phase, two-phase, or three-phase motors. However, three-phase BLDC motors with permanent magnet rotor are most commonly used.
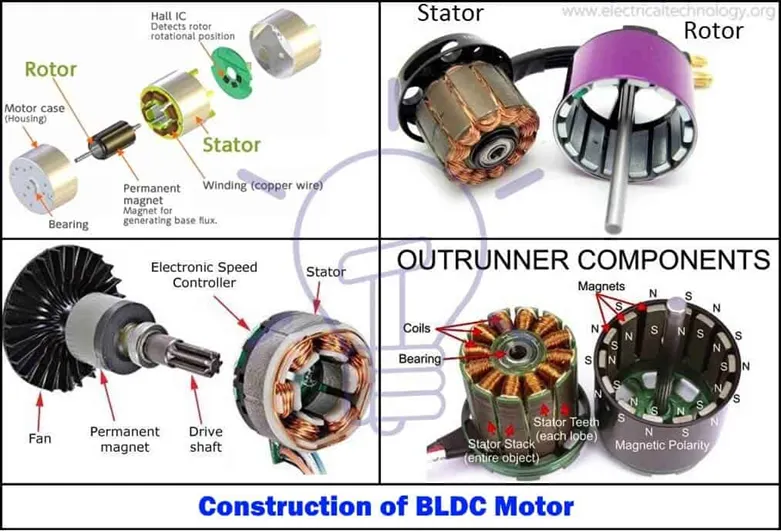
The construction of this motor has many similarities of three phase induction motor as well as conventional DC motor. This motor has stator and rotor parts as like all other motors.
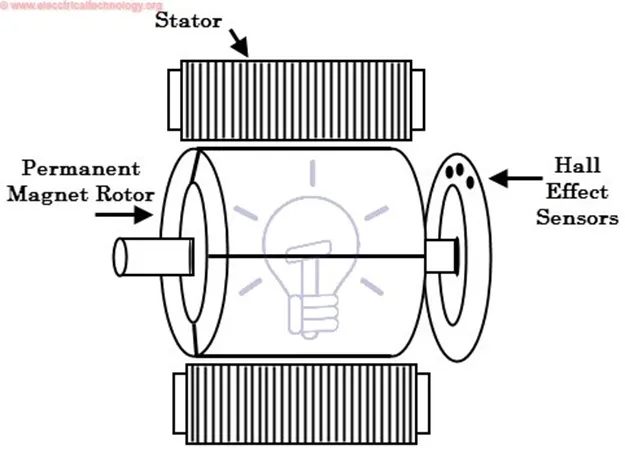
Stator of a BLDC motor made up of stacked steel laminations to carry the windings. These windings are placed in slots which are axially cut along the inner periphery of the stator. These windings can be arranged in either star or delta. However, most BLDC motors have three phase star connected stator.
Each winding is constructed with numerous interconnected coils, where one or more coils are placed in each slot. In order to form an even number of poles, each of these windings is distributed over the stator periphery.
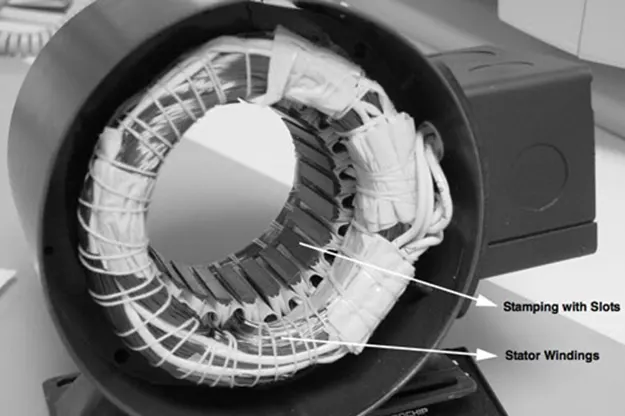
The stator must be chosen with the correct rating of the voltage depending on the power supply capability. For robotics, automotive and small actuating applications, 48 V or less voltage BLDC motors are preferred. For industrial applications, "automobiles" and automation systems 100 V or higher rating motors are used.
BLDC motor incorporates a permanent magnet in the rotor. The number of poles in the rotor can vary from 2 to 8 pole pairs with alternate south and north poles depending on the application requirement. In order to achieve maximum torque in the motor, the flux density of the material should be high. A proper magnetic material for the rotor is needed to produce required magnetic field density.
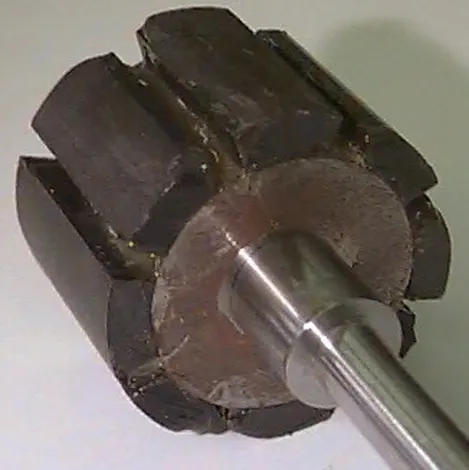
Ferrite magnets are inexpensive; however, they have a low flux density for a given volume. Rare earth alloy magnets are commonly used for new designs. Some of these alloys are Samarium Cobalt (SmCo), Neodymium (Nd), and Ferrite and Boron (NdFeB). The rotor can be constructed with different core configurations such as the circular core with permanent magnet on the periphery, circular core with rectangular magnets, etc.
HALL SENSOR:
Hall sensor provides the information to synchronize stator armature excitation with rotor position. Since the commutation of BLDC motor is controlled electronically, the stator windings should be energized in sequence in order to rotate the motor. Before energizing a particular stator winding, acknowledgment of rotor position is necessary. So, the Hall Effect sensor embedded in stator senses the rotor position.
Most BLDC motors incorporate three Hall sensors which are embedded into the stator. Each sensor generates Low and High signals whenever the rotor poles pass near to it. The exact commutation sequence to the stator winding can be determined based on the combination of these three sensor’s responses.
Working principle and Operation of BLDC Motor:
BLDC motor works on the principle similar to that of a conventional DC motor, i.e., the Lorentz force law which states that whenever a current carrying conductor placed in a magnetic field it experiences a force. As a consequence of reaction force, the magnet will experience an equal and opposite force. In case BLDC motor, the current carrying conductor is stationary while the permanent magnet moves.
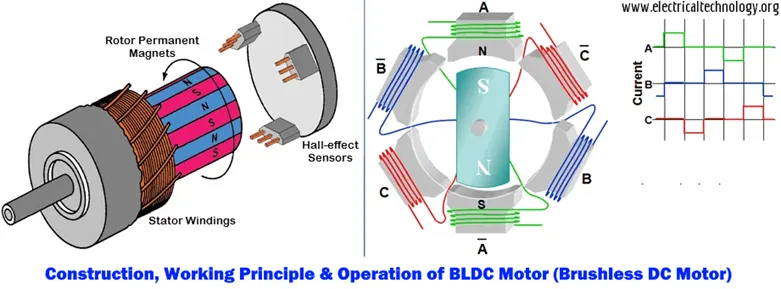
When the stator coils are electrically switched by a supply source, it becomes electromagnet and starts producing the uniform field in the air gap. Though the source of supply is DC, switching makes to generate an AC voltage waveform with trapezoidal shape. Due to the force of interaction between electromagnet stator and permanent magnet rotor, the rotor continues to rotate.
Consider the figure below in which motor stator is excited based on different switching states. With the switching of windings as High and Low signals, corresponding winding energized as North and South poles. The permanent magnet rotor with North and South poles aligns with stator poles causing motor to rotate.
Observe that motor produces torque because of the development of attraction forces (when North-South or South-North alignment) and repulsion forces (when North-North or South-South alignment). By this way motor moves in a clockwise direction.
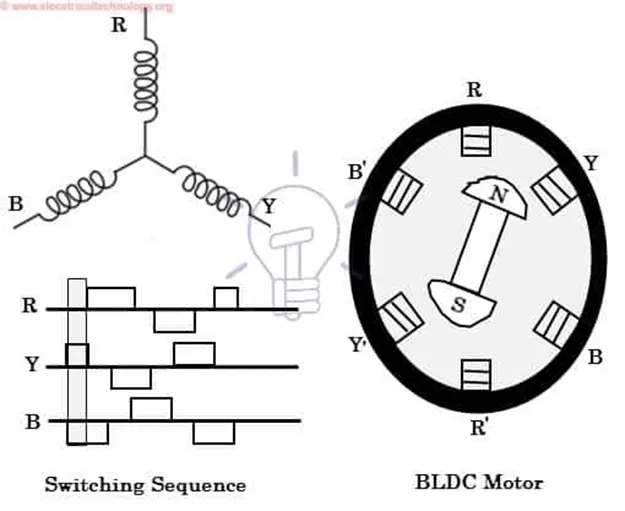
Here, one might get a question that how we know which stator coil should be energized and when to do. This is because; the motor continuous rotation depends on the switching sequence around the coils. As discussed above that Hall sensors give shaft position feedback to the electronic controller unit.
Based on this signal from sensor, the controller decides particular coils to energize. Hall-effect sensors generate Low- and High-level signals whenever rotor poles pass near to it. These signals determine the position of the shaft.
ADVANTAGES OF BLDC:
The advantages of a brushless DC motor over a brushed motors are high power to weight ratio, high speed, nearly instantaneous control of speed (rpm) and torque, high efficiency, low maintenance and low noise due to absence of brushes.
DISADVANTAGES OF BLDC:
These motors are costly due to permanent magnets and electronic commutators are expensive. Need of additional sensors.
APPLICATIONS:
Brushless DC motors find applications in such places as computer peripherals (disk drives, printers), hand held power tools and “vehicles ranging from model aircraft to automobiles” (Electric vehicles, Hybrid Electric Vehicles). In modern washing machines, brushless DC motors have allowed replacement of rubber belts and rear boxes by a direct drive design.