Week-7 Challenge: DC Motor Control
- MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’ is analysed:
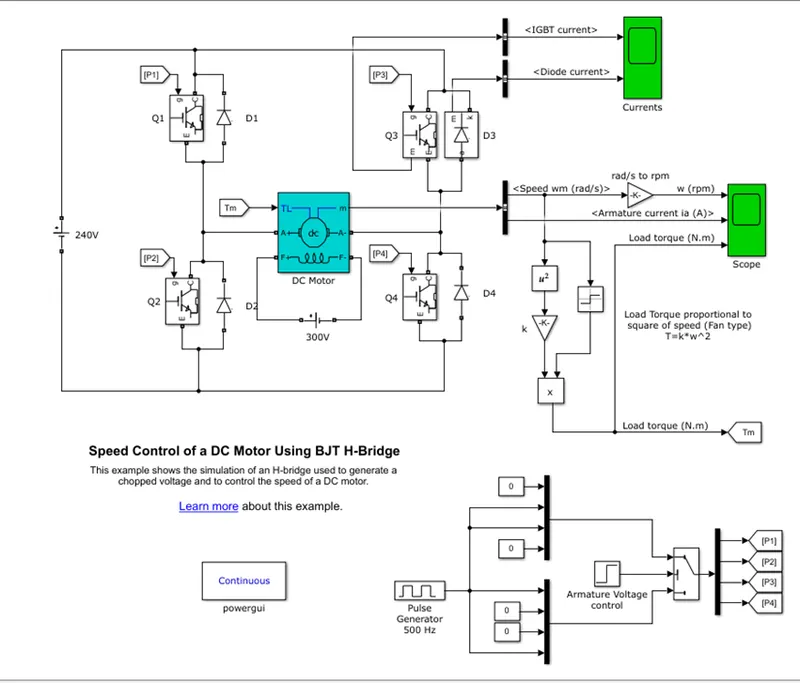
The working of The model is explained below:
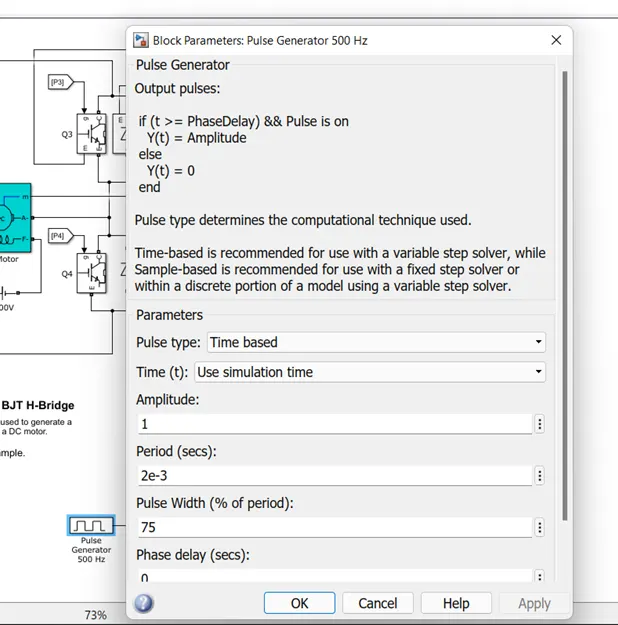
- There is a BJT triggering circuit modelled with a pulse generator. The triggering period of The BJT’s are assigned through duty cycles and pulse width, inside The pulse generator itself. Duty Cycle = Ton/(Ton + Toff).
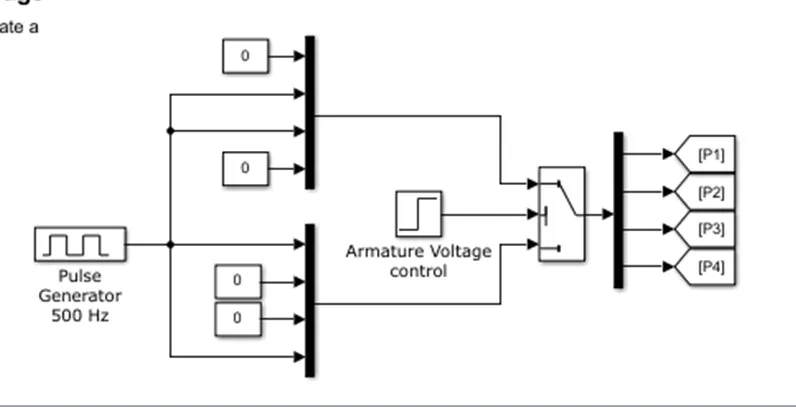
- Then with The help of Mux block, Demux block , Switch and a Step block The triggering circuit is deigned in such a way that The BJT’sQ1 and Q4 is trigerred to get forward motoring and Q2 and Q3 are triggered to get Reverse Motoring actions. Also this triggering signals are conned to The BJT’s through Goto and From blocks.
- When Q1 and Q4 are Triggered, a positive voltage is applied to The motor and The diodes D2 and D3 acts are free-wheeling diodes when They are switched off.
- When Q2 and Q3 are Triggered, a positive voltage is applied to The motor and The diodes D1 and D4 acts are free-wheeling diodes when They are switched off.
- This Type of Circuit with 4 BJT’s Connected in a H pattern with The Load in between is called a H bridge Circuit.
- B. Comment on The armature current shoot-up from The scope results.
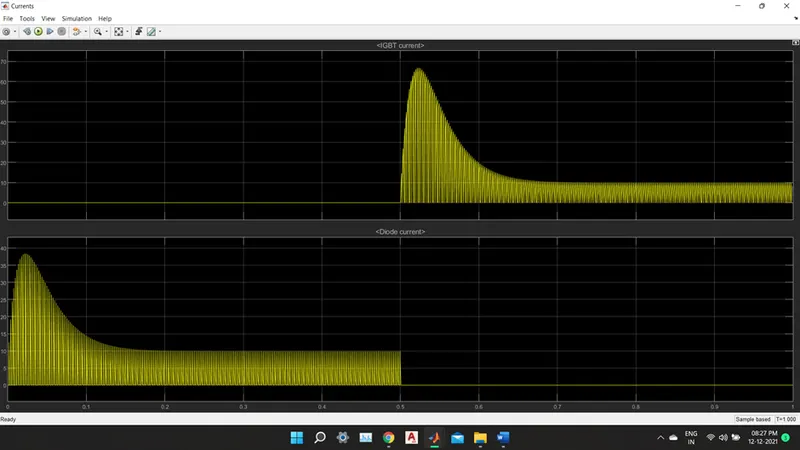
This Plot shows The Current passing through The IGBT - Q3 and Diode - D3. It shows that when The switch Q3 is off on The starting stage, The current flows through The diode on that stage. According to The pulse generator input signal, The current flows through The diode for 0.5 sec of time on The first half and Then when The switch is triggered, The current flows through The IGBT for 0.5 sec on The next half cycle.
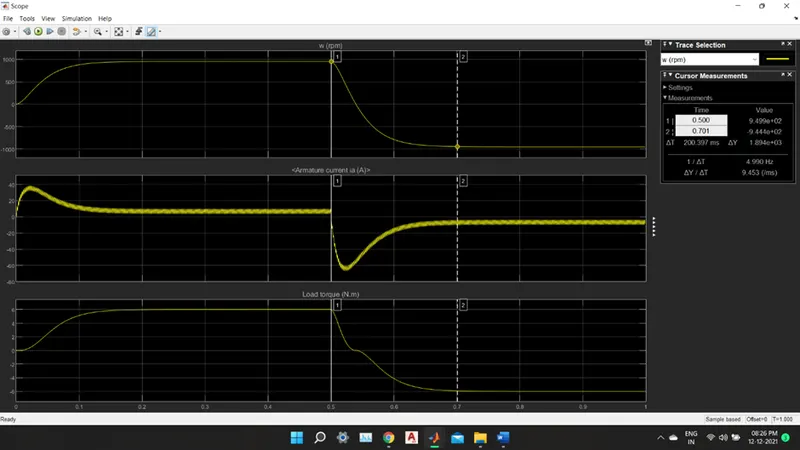
This plot shows The Speed, Armature current, and Load Torque. In The Armature current plot, we can see that There is a armature current shoot up to peak current value on starting. This is due to initial high-power requirement of The motor for The initial acceleration of The motor. After stabilizing The RPM value, The armature current settles down to a minimum value until The next cycle after 0.5 secs. On The next cycle, The motor is on reverse motoring mode and a high negative current is required by The motor for The negative acceleration. This can be noticed on The second half of The plot.
- C. The MATLAB demo model ‘The Four-Quadrant Chopper DC Drive (DC7) block’
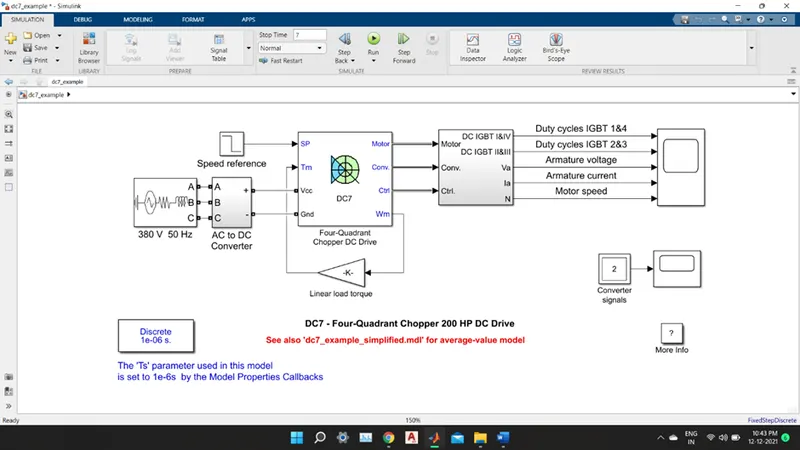
This model shows These characteristics:
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit The DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and The DC7 block.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed. The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system. The current regulatory controls the armature current by computing the appropriate duty ratios of The 5 kHz pulses of The four IGBT devices (Pulse Width Modulation). For proper system behaviour, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
The Main difference between both these models are that the first model was a 2-quadrant operation model and this model is a 4-quadrant model. Because of this reason, this model has a much better triggering cycle when the armature current is much more continuous and the motor operates in a smooth cycle. Also, this Model uses a 3 phase AC supply for the model but our previous model uses a single-phase DC supply. To point out the switching is designed by simscape blocks in this model, where the previous model used IGBT switches. Finally, the most important and notable difference was with the simulation time, this model took a lot more time than the previous model as this model was much more complex than the previous one.
- Two Quadrant chopper using Simulink
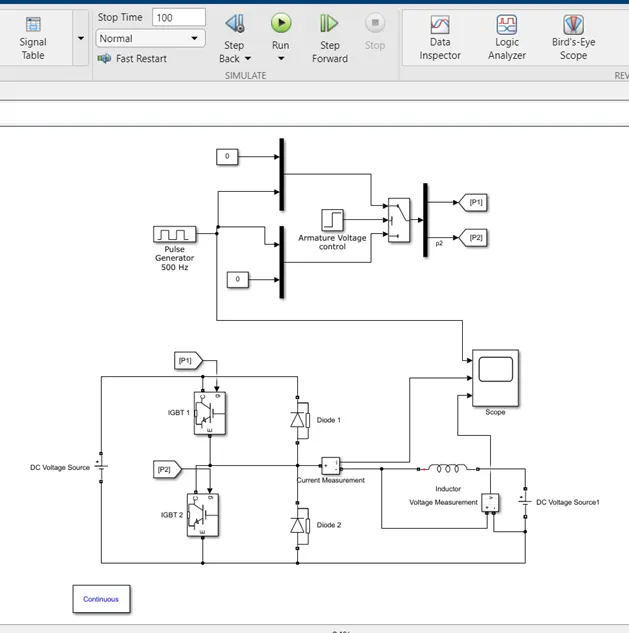
The Two Quadrant Chopper is a Class – C Chopper and it operates in 1st and 2nd Quadrant. In class C chopper the output voltage is always positive and the output current can be positive and negative.
Model:
Working Principle:
- At first, the switch IGBT 1 is turned on and the supply current will flow from positive terminal to negative terminal, which will charge the inductor in the circuit.
- And when the IGBT 1 is turned off, the charged inductor will discharge the current through the Diode 2. The current flows in loop from the inductor to battery to diode and continues till fully discharged.
- Now in the second cycle, IGBT 2 is turned on and the EMF of load will charge the inductor and the current will flow from the DC voltage source 1 to inductor and completes the circuit through IGBT 2.
- And when the IGBT 2 is turned off, the charged current in the inductor discharges through Diode 1.
Output Plots:
Conclusion:
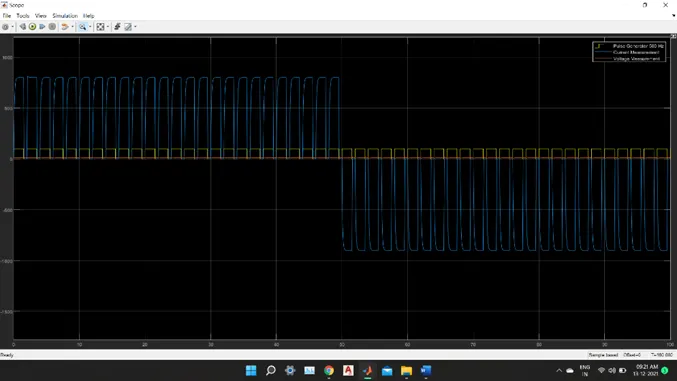
- We can see from the plot that output Voltage is always positive and the output Current is a Pulsating graph which is in positive and negative region.
- When the Chopper IGBT1 or Diode 2 conducts, Load is Positive.
- When the Chopper IGBT2 or Diode 1 conducts, Load is Negative.
- As a Conclusion we can state that the 2 Quadrant Chopper works for DC motor control and Regenerative Braking of DC motor.
- BLDC motor
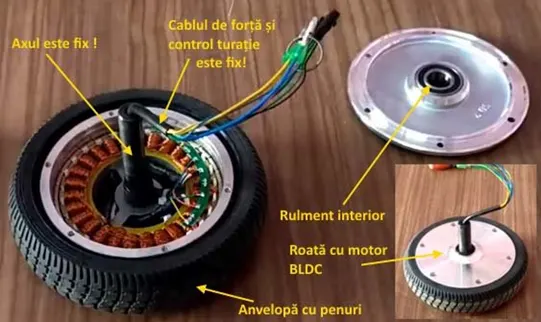
A brushless DC motor (also known as a BLDC motor or BL motor) is an electronically commuted DC motor which does not have brushes. The controller provides pulses of current to the motor windings which control the speed and torque of the synchronous motor.
These types of motors are highly efficient in producing a large amount of torque over a vast speed range. In brushless motors, permanent magnets rotate around a fixed armature and overcome the problem of connecting current to the armature. Commutation with electronics has a large scope of capabilities and flexibility. They are known for smooth operation and holding torque when stationary.
Brushless DC motor has only two basic parts: rotor and the stator. The rotor is the rotating part and has rotor magnets whereas stator is the stationary part and contains stator windings. In BLDC permanent magnets are attached in the rotor and move the electromagnets to the stator. The high-power transistors are used to activate electromagnets for the shaft turns. The controller performs power distribution by using a solid-state circuit.
The advantages of a BLDC motor are:
- Brushless motors are more efficient as its velocity is determined by the frequency at which current is supplied, not the voltage.
- As brushes are absent, the mechanical energy loss due to friction is less which enhanced efficiency.
- BLDC motor can operate at high-speed under any condition.
- There is no sparking and much less noise during operation.
- More electromagnets could be used on the stator for more precise control.
- BLDC motors accelerate and decelerate easily as they are having low rotor inertia.
- It is high performance motor that provides large torque per cubic inch over a vast sped rang.
- BLDC motors do not have brushes which make it more reliable, high life expectancies, and maintenance free operation.
- There is no ionizing sparks from the commutator, and electromagnetic interference is also get reduced.
- Such motors cooled by conduction and no air flow are required for inside cooling.
The disadvantages of a BLDC motor are:
- BLDC motor cost more than a brushed DC motor.
- The limited high power could be supplied to BLDC motor, otherwise, too much heat weakens the magnets and the insulation of winding may get damaged.
Working Principle of a BLDC Motor:
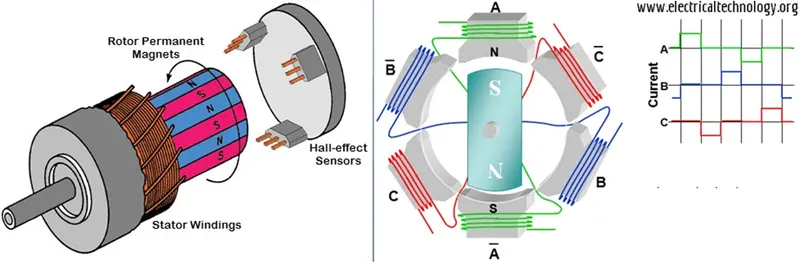
Stator windings of a BLDC motor are connected to a control circuit (an integrated switching circuit). The control circuit energizes proper winding at proper time, in a pattern which rotates around the stator.
The rotor magnet tries to align with the energized electromagnet of the stator, and as soon as it aligns, the next electromagnet is energized. Thus, the rotor keeps running.
Commutator helps in achieving unidirectional torque in a typical dc motor.
Obviously, commutator and brush arrangement are eliminated in a brushless dc motor. And an integrated inverter/switching circuit is used to achieve unidirectional torque.
That is why these motors are, sometimes, also referred as ‘electronically commutated motors.