Week-7 Challenge: DC Motor Control
1 A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
Speed Control of DC motor using BJT H-Bridge is the model analyzed in MATLAB Simulink help documentation.
It uses IGBT and diode combination to get BJT operation.
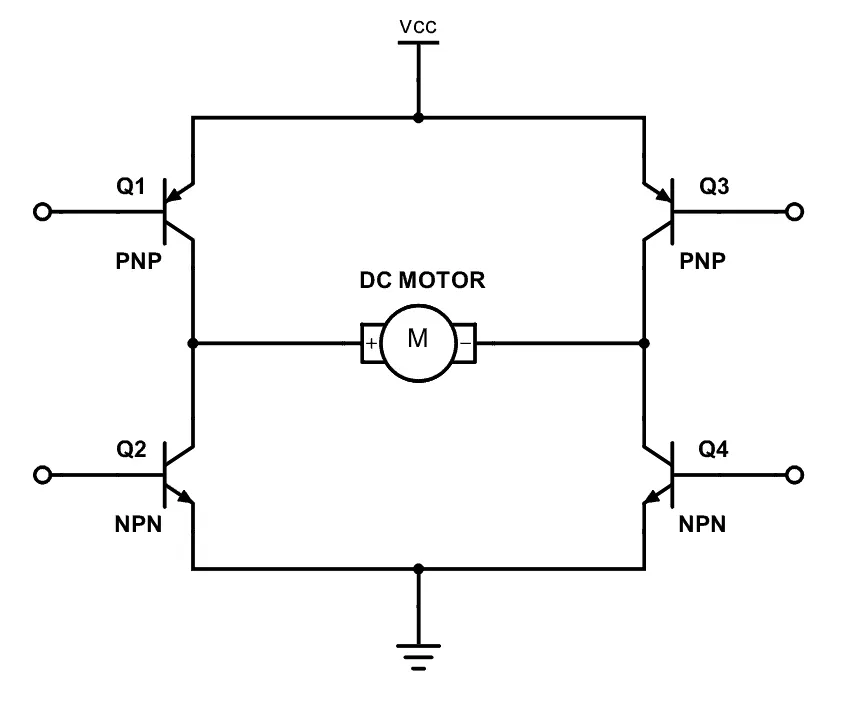
The above figure shows the H-bridge circuit which controls the speed of the DC motor. Here Q1, Q4 operate in one cycle, and Q2, Q3 operate in another cycle.
- The demo model of the Speed Control of a DC motor using BJT H- Bridge
- The below figure is snipped from the Demos of Matlab.
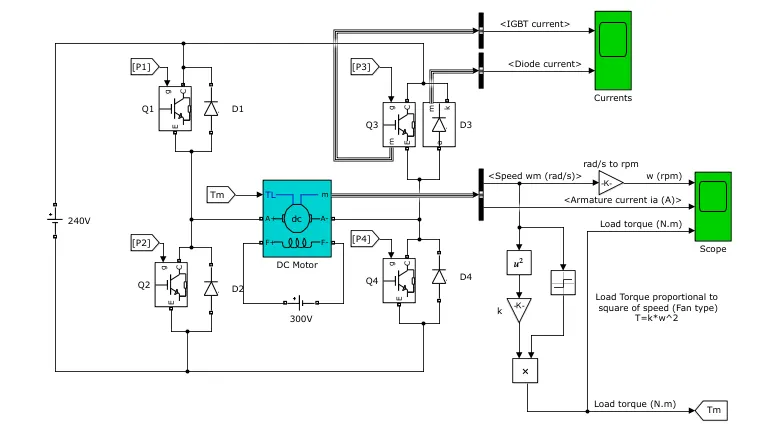
Description:
The Bipolar Junction Transistor (BJT) when used for power switching applications, operates as an IGBT.
When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between collector and emitter (in the range of 1 V).
Therefore, the IGBT block can be used to model the BJT device.
The IGBT block does not simulate the gate current controlling the BJT or IGBT.
The switch is controlled by a Simulink signal (1/0).
The DC motor uses the preset model (5 HP 24V 1750 rpm).
It simulates a fan-type load (where Load torque is proportional to the square of speed).
The armature means voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
The field winding is given with a fixed voltage of 300v.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models).
Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3.
When Q1 and Q4 are fired, a positive voltage is applied to the motor, and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off.
When Q2 and Q3 are fired, a negative voltage is applied to the motor, and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
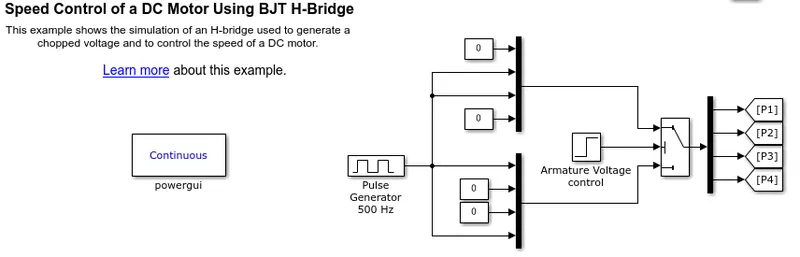
Pulse Generator Generates the signals in pulses. Gate pulse to the IGBTS is given from P1, P2, P3, and P4.
Mux-1 input makes 1 and 4 gates are turned off
Mux-2 and 2 and 3 gates are turned off in mux-1.
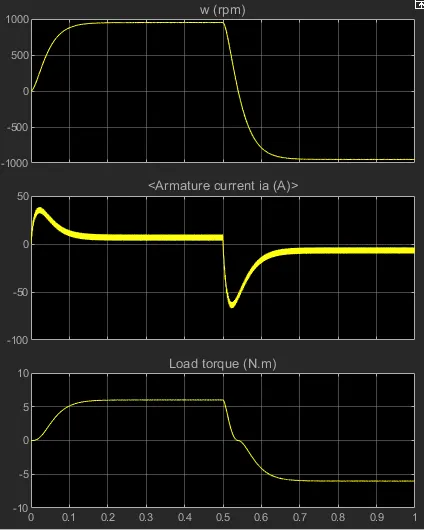
The scope shows the output of Speed, Armature Current, and Torque.
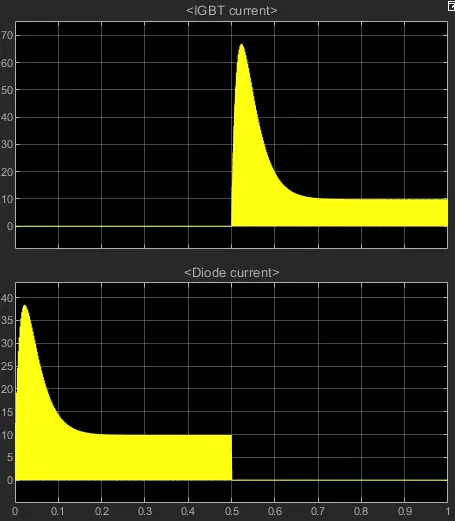
This scope tells that in the positive half cycle diode is allowing current and in the negative half cycle, IGBT is allowing current.
B. Comment on the armature current shoot-up from the scope results.
Armature current changes when switching changes are appearing.
So during switching changes, the current increases to the peak, which can be referred to as the Current shoot-up.
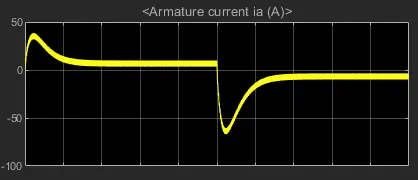
Armature current when Pulse width is 50%
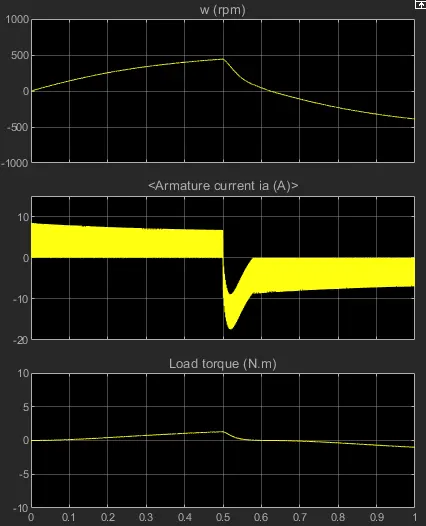
Armature current when Pulse width is 75%
There is a change in armature current shoot up based on the change in Pulse width.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
The Four Quadrant chopper DC Drive block is a predefined block in Simulink.
Path: Simscape / Electrical / Specialized Power Systems / Electric Drives / DC Drives
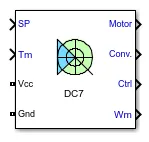
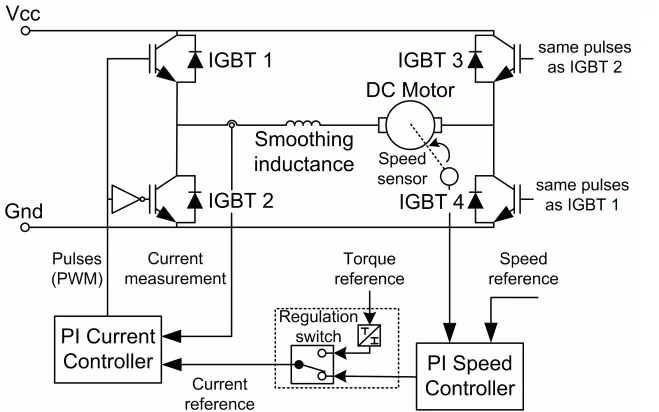
The Four-Quadrant Chopper DC Drive (DC7) block represents a four-quadrant, DC-supplied, chopper (or DC-DC PWM converter) drive for DC motors.
This drive features closed-loop speed control with a four-quadrant operation.
The speed control loop outputs the reference armature current of the machine.
Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived. This duty cycle is then compared with a sawtooth carrier signal to obtain the required PWM signals for the chopper.
Compared with other DC drives, the main advantage of this drive is that it can operate in all
four quadrants (forward motoring, reverse regeneration, reverse motoring, and forward regeneration).
In addition, due to the use of high switching frequency DC-DC converters, a lower armature current ripple (compared with thyristor-based DC drives) is obtained. However, four switching devices are required, which increases the complexity of the drive system.
Internal Block diagram of the DC7 block:
Matlab model for four Quadrant chopper is given below: Four quadrant chopper drive is a combination of H bridge DC Motor speed control operation.
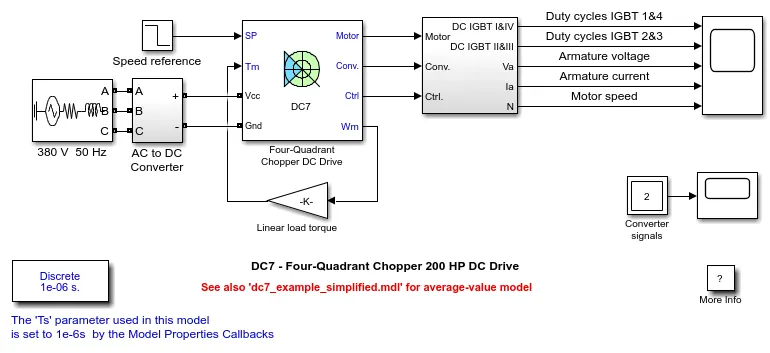
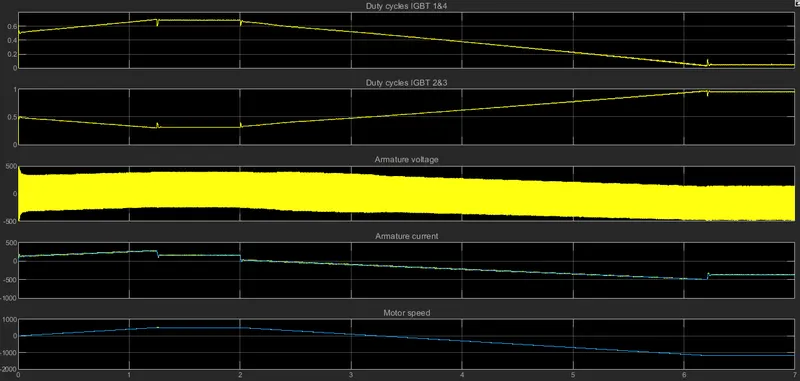
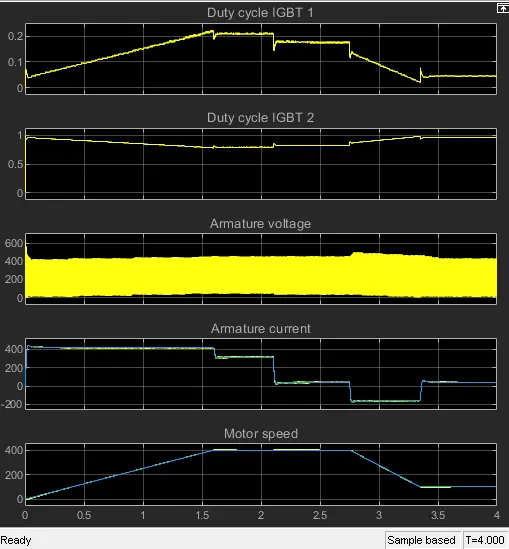
Above Results shows the Four quadrant chopper operation.
Four Quadrant chopper model is developed from the direct model in Matlab library.
It undergoes four operations
forward motoring
reverse regeneration
reverse motoring, and
forward regeneration
H-bridge circuit is mainly used in low current rating technologies like Robotics etc.,
Four Quadrant Chopper circuits are used in industrial as well as commercial applications.
Here the current signal is interrupted with one another to change the direction of rotation of the motor.
PI Controller is used in Four quadrant chopper.
In the H-Bridge model, the controller is not used.
2. Develop a 2-quadrant chopper using Simulink & explain the working of the same with the relevant results.
(Refer to article - Multiquadrant operation of motor )
The Two-Quadrant Chopper DC Drive (DC6) block represents a two-quadrant, DC-supplied, chopper (or DC-DC PWM converter) drive for DC motors. This drive features closed-loop speed control with a two-quadrant operation.
The speed control loop outputs the reference armature current of the machine. Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived.
This duty cycle is then compared with a sawtooth carrier signal to obtain the required PWM signals for the chopper.
The main advantages of this drive, compared with other DC drives, are its implementation simplicity and the that it can operate in two quadrants (forward motoring and reverse regeneration).
In addition, due to the use of high switching frequency DC-DC converters, a lower armature current ripple (compared with thyristor-based DC drives) is obtained. However, for all two-quadrant DC drives, reversible and regenerative operations (reverse motoring and forward regeneration), which are required in most DC drives, cannot be obtained.
The Two-Quadrant Chopper DC Drive block uses these blocks from the Electric Drives/Fundamental Drive Blocks library:
-
Speed Controller (DC)
-
Regulation Switch
-
Chopper
chopper may be required to provide a two-quadrant operation by retaining the current direction in both motoring and braking modes.
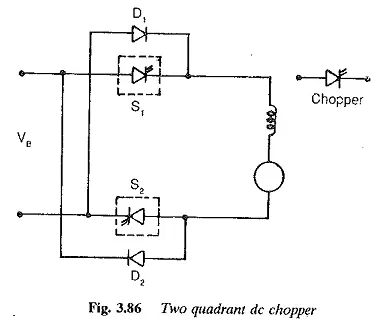
Two Quadrant Chopper operation in Simulink:
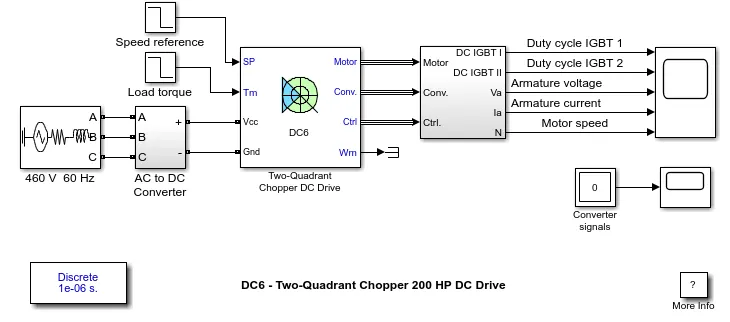
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source.
The armature voltage is provided by an IGBT buck-boost converter controlled by two PI regulators.
The buck-boost converter is fed by a 630 V DC bus obtained by rectification of a 460 V AC 60 Hz voltage source.
In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC6 block.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference (in p.u.) used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed.
The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature over-current and destabilize the system.
The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the two IGBT devices (Pulse Width Modulation).
For proper system behavior, the two IGBT devices have opposite instantaneous pulse values. This generates the average armature voltage needed to obtain the desired armature current.
Scope result of IGBTs, Armature voltage of DC Motor, Armature current and Motor speed.
3. Explain in a brief about operation of BLDC motor.
BLDC motor is an Electronically commutated Motor.
Primary efficiency is the most important feature for BLDC motors.
Rotor is the sole bearer of the magnets and it doesn't require any power. i.e. no connections, no commutator and no brushes.
In place of these, the motor employs control circuitry.
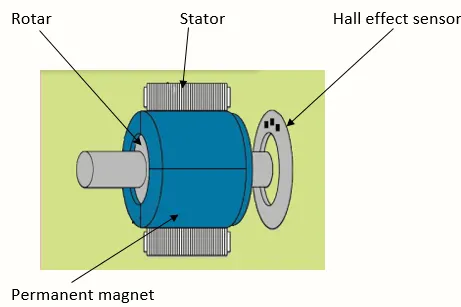
To detect where the rotor is at certain times, BLDC motors employ along with controllers, rotary encoders or a Hall sensor.
Construction:
Rotor:
The permanent magnets attached to the rotor.
The armature windings are located on the stator.
They use electrical commutation to convert electrical energy into mechanical energy.
The main design difference between brushed and brushless motors is the replacement of a mechanical commutator with an electric switch circuit.
A BLDC Motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.
The Brushless motor does not have any current-carrying commutators.
The field inside a brushless motor is switched through an amplifier which is triggered by the commutating device like an optical encoder.
Working:
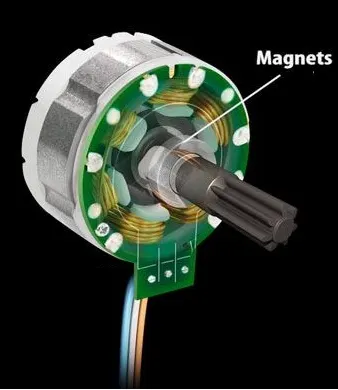
BLDC motor works on a principle similar to that of a Brushed DC motor.
The Lorentz force law states that "whenever a current-carrying conductor placed in a magnetic field it experiences a force".
As a consequence of reaction force, the magnet will experience an equal and opposite force. In the BLDC motor, the current-carrying conductor is stationary and the permanent magnet is moving.
When the stator coils get a supply from the source, it becomes an electromagnet and starts producing the uniform field in the air gap.
Though the source of supply is DC, switching makes to generate an AC voltage waveform with a trapezoidal shape. Due to the force of interaction between the electromagnet stator and permanent magnet rotor, the rotor continues to rotate.
With the switching of windings as High and Low signals, corresponding winding energized as North and South poles. The permanent magnet rotor with North and South poles align with stator poles which causes the motor to rotate.
BLDC motor is used in Electric vehicles like Two-wheelers and Three-wheeler vehicles.