Week-7 Challenge: DC Motor Control
- Run MATLAB demo ‘Speed control of a DC motor using BJT H-bridge’. Modify the model such that armature current doesn’t shoot up when the motor changes direction from forward to reverse.
The BJT when used for power switching applications, operates as an IGBT. When it is conducting, a forward voltage Vf is developed between collector and emitter. Therefore, the IGBT block can be used to model the BJT device.
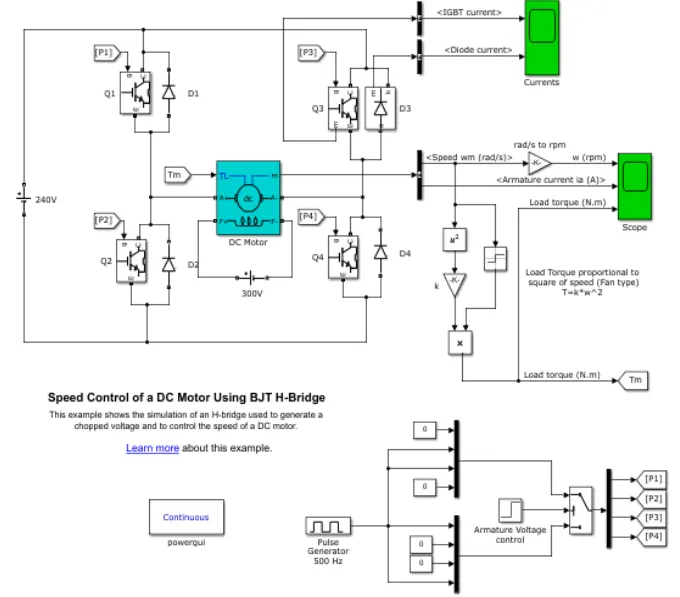
The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal. The DC motor has 5 HP 24V 1750 rpm. It simulates a fan type load. The armature mean voltage can be varied from 0 to 240 V when the duty cycle is varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
The objective is to modify this model such that armature current doesn’t shoot up when the motor changes direction from forward to reverse
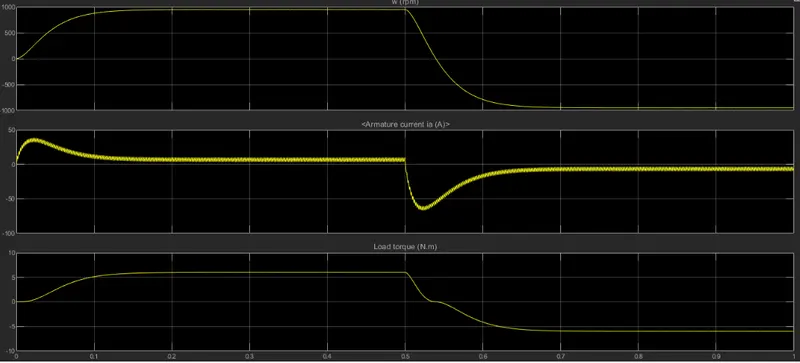
In the above model Speed control of a DC motor using BJT H-bridge the armature starting current is very large then it gradually reduces.
The armature starting current of the DC motor can be controlled by
- Armature control
- Field control
- PWM
- Starter Rheostat.
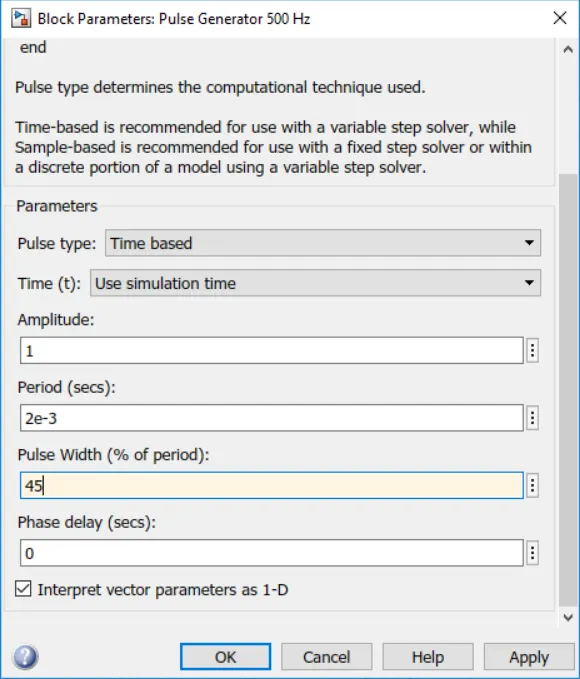
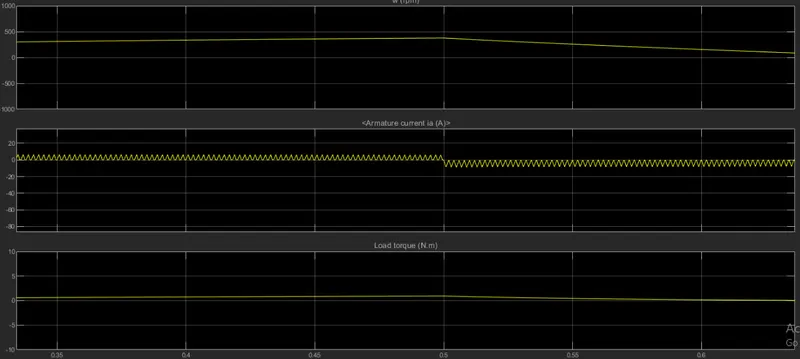
There are many techniques to control armature starting current. In order to control large starting current PWM technique is preferred. The PWM signal is reduced so that the voltage of the motor is reduced. The value of the PWM signal is reduced from 75% to 45% so after changing the value the starting current and negative reverse current does not shoot up. In order to minimize the current deviation, the PWM frequency of 500hz can be increased so the deviation is reduced.
Conclusion:
By varying the PWM value of the signal the starting current can be changed.
Other methods like armature and field control can also be done. By using the 3 point , 4 point starter the value of the starting current can be reduced.
____________________________________________________________________________________________________
- Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
H-Bridge:
An electronic circuit that switches the polarity of a voltage applied to a load. These circuits are often used in robotics and other applications to allow DC motors to run forwards or backward. H-bridge has several operating modes such as motor moves right, moves left, coasting, barking, short-circuiting.
- It can operate in 4 modes
- Regenerative braking is possible.
- Speed and current controllers are available.
- It has a wider range of torque and power.
- Having high efficiency.
Applications:
Electric traction system
Battery operated vehicle
Lift and crane
The Four-Quadrant Chopper DC Drive (DC7)
The new proposed chopper has features to overcome the drawbacks of conventional H Bridge Chopper. This chopper has seven modes of operation such as, driving,field weakening, generator, Parallel mode, regenerative braking, resistive braking and reverse mode.
- This can operate in 2 modes
- Speed and current controllers are unavailable
- Regenerative braking is not possible dynamic braking is possible
- Comparatively narrow range of torque and power
- Low efficient compared to 4 quadrant chopper
Applications:
Inverter circuits
Robotics
Motor controllers
____________________________________________________________________________________________________
- Make a suitable EV model using a DC7 block and make a result report.
The DC7 block is available on Matlab documentation.
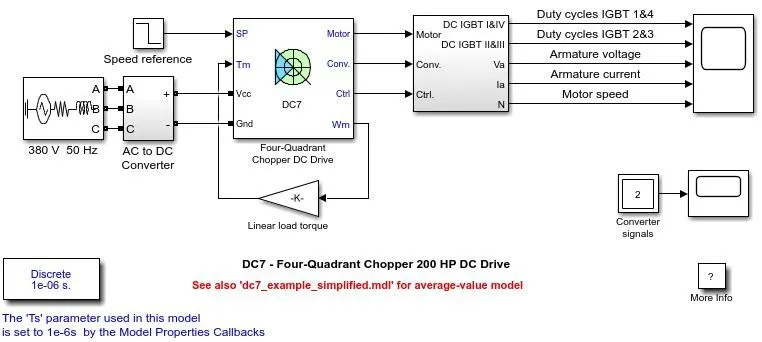
The 200 HP DC motor is separately excited with a constant 150 V DC field voltage source. The armature voltage is provided by an IGBT converter controlled by two PI regulators. The converter is fed by a 515 V DC bus obtained by rectification of a 380 V AC 50 Hz voltage source. In order to limit the DC bus voltage during dynamic braking mode, a braking chopper has been added between the diode rectifier and the DC7 block.
The first regulator is a speed regulator, followed by a current regulator. The speed regulator outputs the armature current reference used by the current controller in order to obtain the electromagnetic torque needed to reach the desired speed. The speed reference change rate follows acceleration and deceleration ramps in order to avoid sudden reference changes that could cause armature overcurrent and destabilize the system. The current regulator controls the armature current by computing the appropriate duty ratios of the 5 kHz pulses of the four IGBT devices. For proper system behavior, the instantaneous pulse values of IGBT devices 1 and 4 are opposite to those of IGBT devices 2 and 3. This generates the average armature voltage needed to obtain the desired armature current. In order to limit the amplitude of the current oscillations, a smoothing inductance is placed in series with the armature circuit.
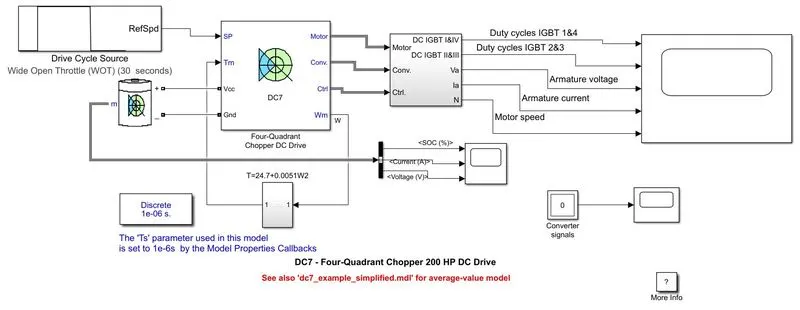
The drive cycle, battery and torque equation is modified.
Result:
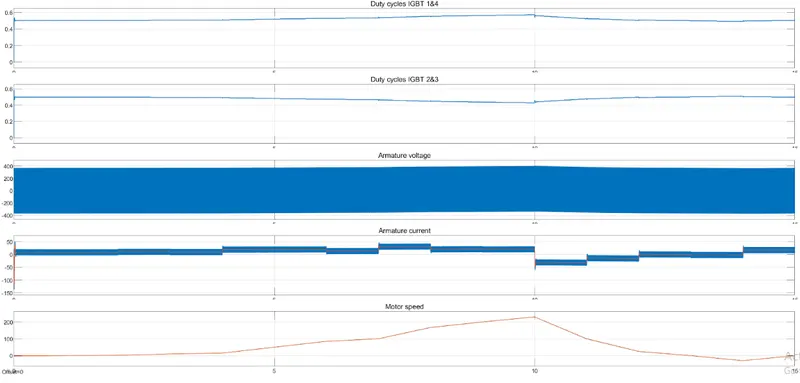
The motor traces the exact path of the duty cycle.The armature current fluctuates but even follows the path of the control.
____________________________________________________________________________________________________