Week 7 Challenge
Load the vehicle parameters. Complete the vehicle model by modelling the remaining equations. Set simulation stop time to 598 sec.
The output should be the vehicle velocity.
answer:
The term "vehiclemodel" refers to the force equations that apply during vehicle dynamics, or when the vehicle moves away from its rest position. Vehicle dynamics is the study of how the forward motion of motorised vehicles, such as cars, planes, and boats, varies in response to driver inputs, propulsion system outputs, ambient variables, air/surface/water conditions, and other factors depict the MATLAB SIMULINK model of the car and driver block.
Where Ftr-resistive force;
Fa-aerodynamic drag resistance force;
Fg-gradient resistance force;
Fr-rolling resistance force;
Fi-inertial resistance force.
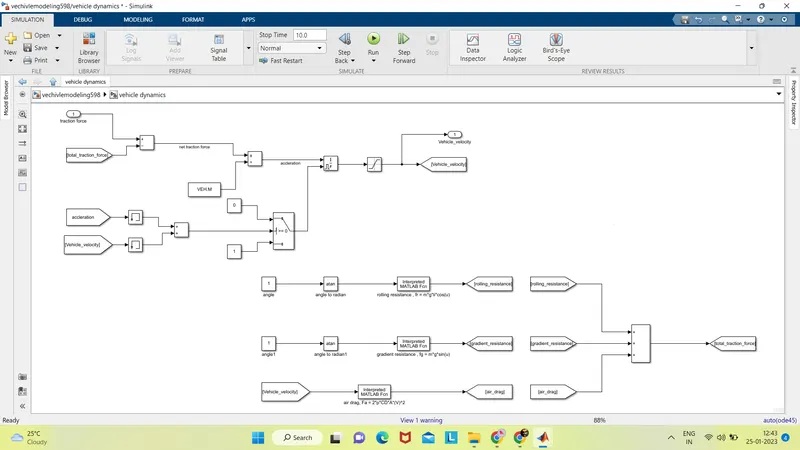
Tractive force is the term used to describe the force created or applied by the vehicle's powertrain. We will now examine the equations for three important forces (aero, rolling, and gradient) and apply them using the Matlab Fcn block.
Aerodynamic drag that is dynamic The force that incoming air applies to a moving boat is known as drag. It is the barrier to physical movement that the air offers. As a result, as a car drives, the air is moved. However, it affects the vehicle's performance and speed. In technical words, depicts the aerodynamic drag or friction that the air provides to a vehicle.
Aerodynamic Drag Fa = 2*p*CD*A*(V)^2
V= velocity (m/sec)
Air density @27°C P = 1.2 (kg/m3)
Vehicle Frontal Area or Projected Area =A (sq.m)
Drag coefficient =CD
Rolling resistance force:The combination of forces that operate against your vehicle's forward motion is known as rolling resistance.
Thevehicle's weight, inertia and gravity, the amount of friction between the tyres and the road surface, and air drag are all factors.
Rollingresistance is what slows you down when youre driving or riding a bike. The greater rolling resistance a vehicle has, the more power it needto go forward.
Rolling Resistance Fr = m*g*mu*cos(u)
The maximum load that may be carried is equal to m. (kg) g = 9.80665 m/s2 = rolling coefficient
A part of a vehicle's weight operates in the opposing direction of its motion when it is ascending an uphill gradient.
The acceleration force is the resistance of the vehicle to changes in speed.
This force pulls you back as you speed, but it pushes you forward when you slow down.
In other words, accelerating requires energy, but decelerating allows you to recover some of that energy, allowing you to traverse a certain distance without using any gasoline.
An easy equation to remember is F=m + a, where m is the mass of the object (vehicle) and an is the acceleration.
gradient Fg = m*g*sin (u)
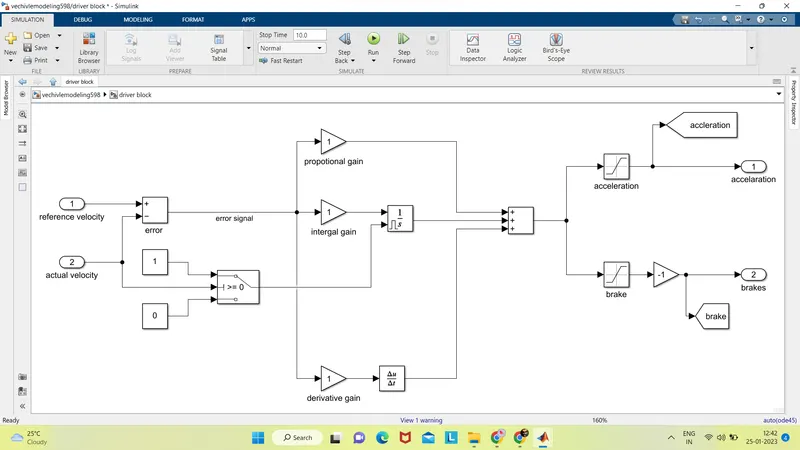
Although the driver block is included in the model above, our attention is solely on the vehicle block.
The driver block is used by us since we requirethe acceleration value to overcome the integral wind up that occurs when translating tractive force to velocity.
As a result, just the vehicle block system and its explanation are included in this section.
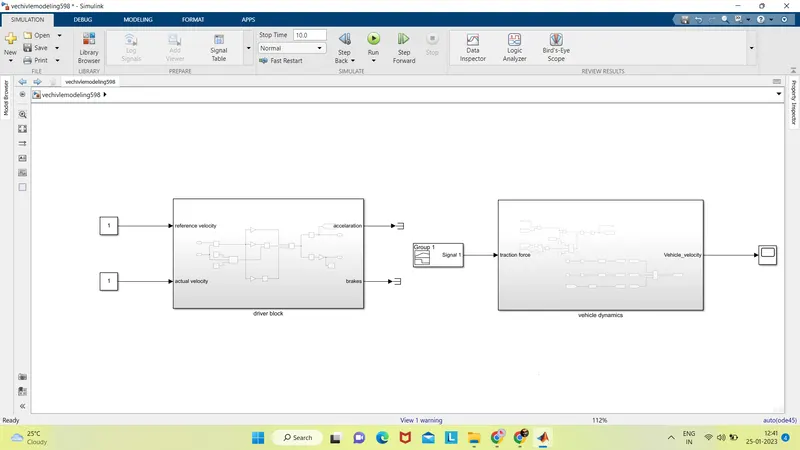
driver blockset
vehicle dynamics
input
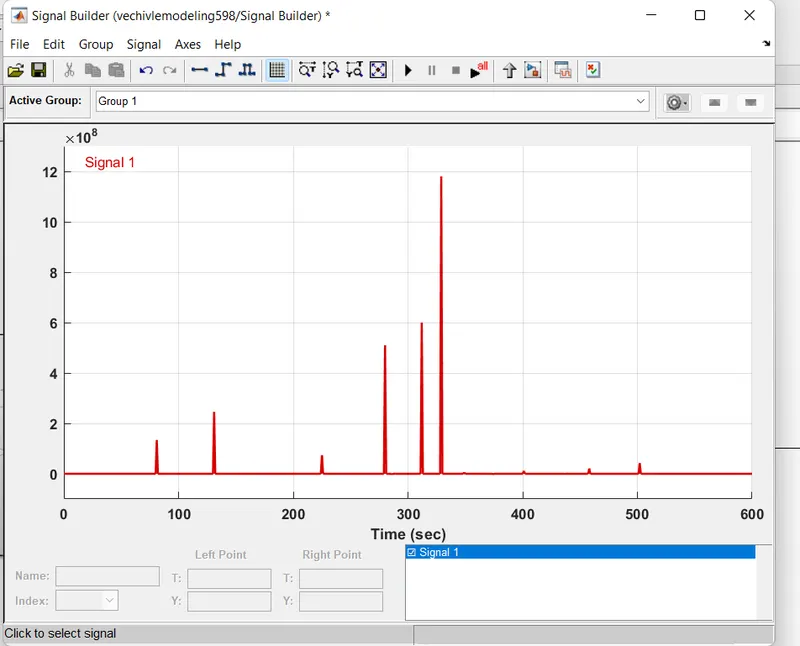
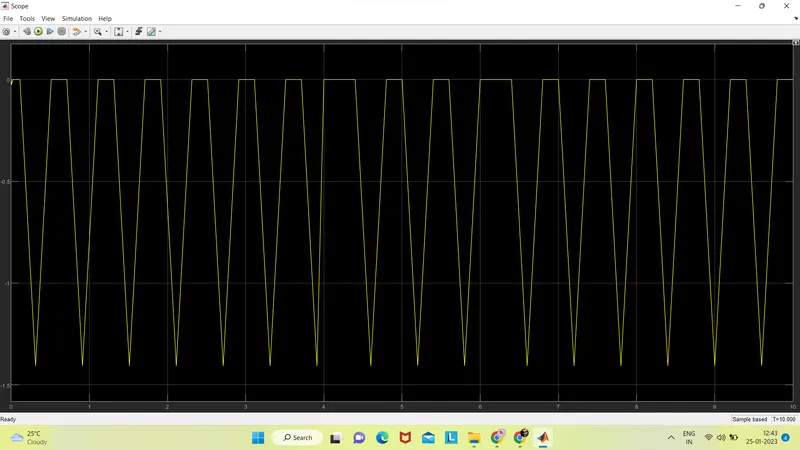
output results
conclusion
the output is inaccurate as we are not connected intersubsytem to provide a referenece block