Week-6 Challenge: EV Drivetrain
1.Which types of power converter circuits are employed in electric and hybrid electric vehicle?
a) AC to DC converter which is called "Rectifier" - It converts AC into Unipolar DC current.
b) DC to AC converter which is called "Inverter" - It converts DC into AC of desired voltage and frequency.
c) DC to DC converter which is called "Chopper" - It converts High voltage DC to low voltage DC (Step down) or Low voltage DC to High voltage DC (Step up)
d) AC to AC converter which is called "Cycloconverter" - It converts the AC of the desired frequency and desired voltage magnitude from the AC supply
2.An Electric Vehicle's powertrain with 72V battery pack in shown in the diagram below. The duty ratio for acceleration operation is 'd1' and for the braking operation the duty ratio is 'd2'
Motor and Controller Parameters:
Rated Armature voltage= 72 V
Rated armature current= 400 A
Ra= 0.5Ω, KΦ= 0.7 Volt second
Chopper Switching frequency= 400 Hz
The vehicle speed-torque characteristics are given by the below equation
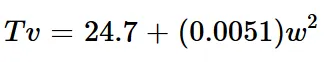
What is EV steady state speed if duty cycle is 70%?
v=battery volt*duty cycle so, v=72*0.7
=50.4
ω= V/Kϕ -Ra/Kϕ^2*T
T= V*Kϕ/Ra-(Kϕ)^2/Ra*w
=50.4*0.7/0.5-(0.7)^2/0.5*w
T =70.56-0.98*w
since Tv=T
24.7+0.0051*W^2=70.56-0.98*W
0.0051W^2+0.98W-45.86=0
To solve the above eq we have to apply the QUADRATIC EQUATION formula,
x=−b±SQRT(b^2-4ac)/2a
x=−0.98±sqrt(0.98−4(0.0051)(−45.85))/2⋅(0.0051)
w=38.92 rad/sec
So, The steady-state speed of the vehicle is 38.92 rad/sec.
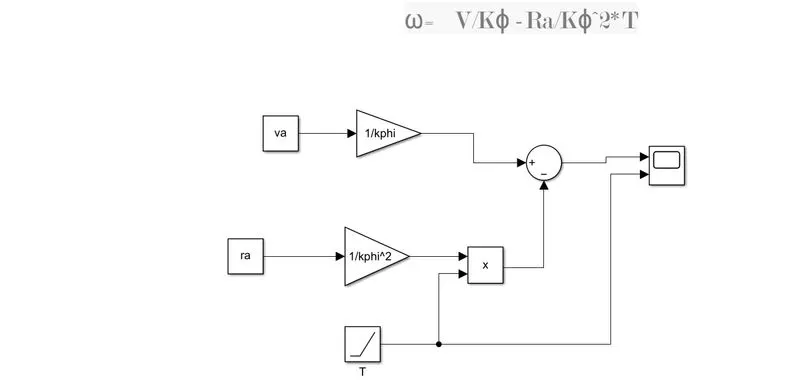
3. Develop a mathematical model of a DC Motor for the below equation using Simulink.
ω= V/Kϕ -Ra/Kϕ^2*T
close all;
clear all;
clc;
d=0.7;
vbt=72;
va=d*vbt;
ra=0.5;
kphi=0.7;
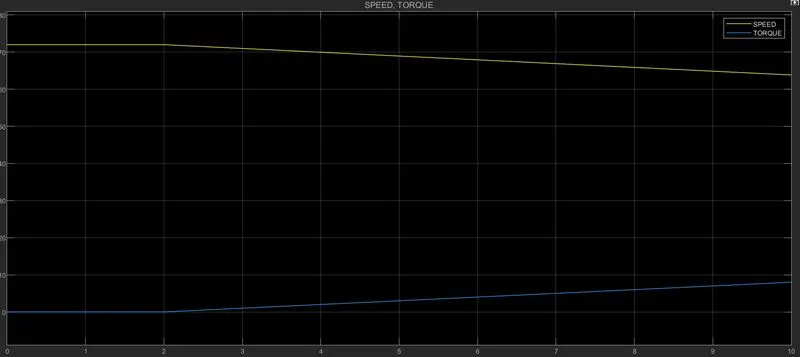
SCOPE RESULT:
From rhe scope result it is clear that the when the speed starts increases from t=2sec torque statrs decreasing
4. Induction Versus DC brushless motors by Wally Rippel, Tesla
Explain in brief about author’s perspective.
BRUSHLESS DC:
With brushless machines, the rotor includes two or more permanent magnets that generate a DC magnetic field (as seen from the vantage point of the rotor). In turn, this magnetic field enters the stator core (a core made up of thin, stacked laminations) and interacts with currents flowing within the windings to produce a torque interaction between the rotor and stator. As the rotor rotates, it is necessary that the magnitude and polarity of the stator currents be continuously varied – and in just the right way - such that the torque remains constant and the conversion of electrical to mechanical energy is optimally efficient. The device that provides this current control is called an inverter. Without it, brushless motors are useless motors.
- One of the main differences is that much less rotor heat is generated with the DC brushless drive.
- Rotor cooling is easier
- peak point efficiency is generally higher for this drive.
- The DC brushless drive can also operate at unity power factor, whereas the best power factor for the induction drive is about 85 percent.
cons:
- brushless DC motor produces no starting torque when directly connected to fixed frequency utility power.
- DC mototr really need the aid of an inverter whose “phase” is maintained in step with the angular position of the rotor.
- Permanent magnets are expensive – something like $50 per kilogram.
- Permanent magnet (PM) rotors are also difficult to handle due to very large forces that come into play when anything ferromagnetic gets close to them.
INDUCTION MOTOR:
The technology behind the induction motor is that it basically uses a 3-phase induction motor which was invented by Nikola Tesla sometime before 1889. Unlike the DC brushless rotor, the induction rotor has no magnets – just stacked steel laminations with buried peripheral conductors that form a “shorted structure.” Currents flowing in the stator windings produce a rotating magnetic field that enters the rotor. In an Induction motor current interacts with the Magnetic field generated by the stator to produce a force which is required for rotor torque.
When a 3-phase induction motor is connected to utility type 3-phase power, torque is produced at the outset. The fact that induction motors are directly compatible with conventional utility power is the main reason for their success.
Induction machines have no magnets and B fields are “adjustable,” since B is proportionate to V/f (voltage to frequency). This means that at light loads the inverter can reduce voltage such that magnetic losses are reduced and efficiency is maximized. Thus, the induction machine when operated with a smart inverter has an advantage over a DC brushless machine – magnetic and conduction losses can be traded such that efficiency is optimized. This advantage becomes increasingly important as performance is increased. With DC brushless, as machine size grows, the magnetic losses increase proportionately and part load efficiency drops. With induction, as machine size grows, losses do not necessarily grow. Thus, induction drives may be the favored approach where high-performance is desired; peak efficiency will be a little less than with DC brushless, but average efficiency may actually be better.
pros:
- When a 3-phase induction motor is connected to utility type 3-phase power, torque is produced at the outset; the motor has the ability to start under load.
- No inverter is needed
cons:
- They cannot operate from DC; AC is a must.
- when operated from utility power, they have limited starting torque and somewhat limited running peak torque capabilities, when compared to DC type machines.
conclusion:
- conclusion is that DC brushless drives will likely continue to dominate in the hybrid and coming plug-in hybrid markets,
- Induction drives will likely maintain dominance for the high-performance pure electrics.