Week-6 Challenge: EV Drivetrain
TITLE - - EV Drivetrain
Aim-
1) Write types of power converter circuits are employed in electric and hybrid electric vehicle.
2) Calculate EV steady state speed when duty cycle is 70%.
3) Develop a mathematical model of a DC Motor for a given euation.
4) write a brief explaination about authors perspective by refering the given blog.
Part 1) types of power converters in EV and HEV.
The power converter is an electrical circuit that converts or changes the electric energy from one form to the desired form optimized for the specific load.
a conveter do the one or more functions and give an output that differs from the input.
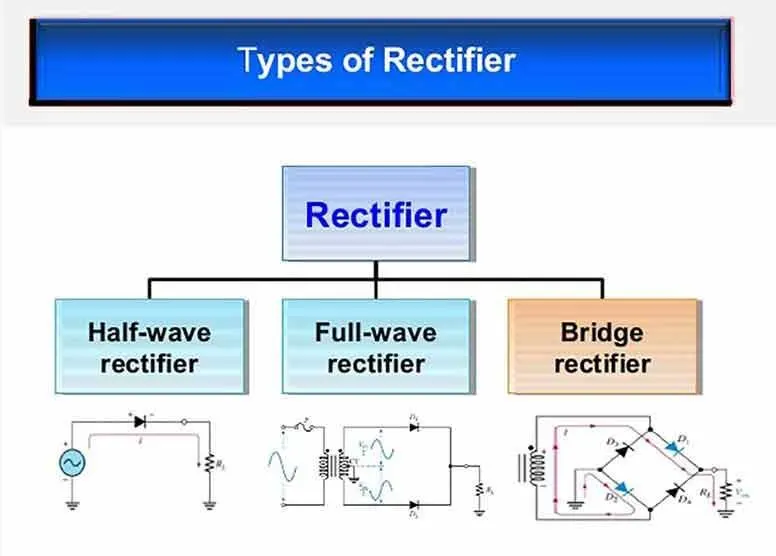
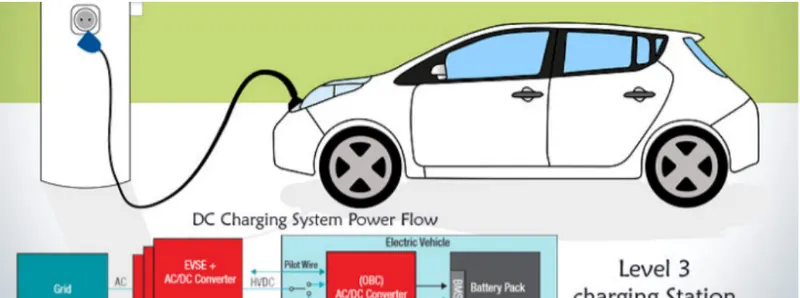
a) Rectifier or AC to DC converter= used to charge the EV battery.
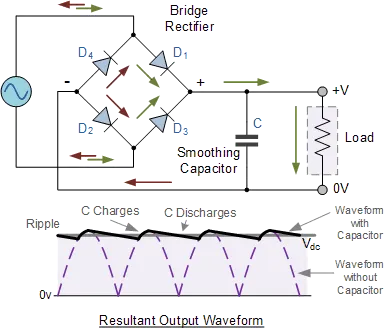
an AC to DC converter is also called a rectifier ,which converts AC supply to the DC supply for the load.
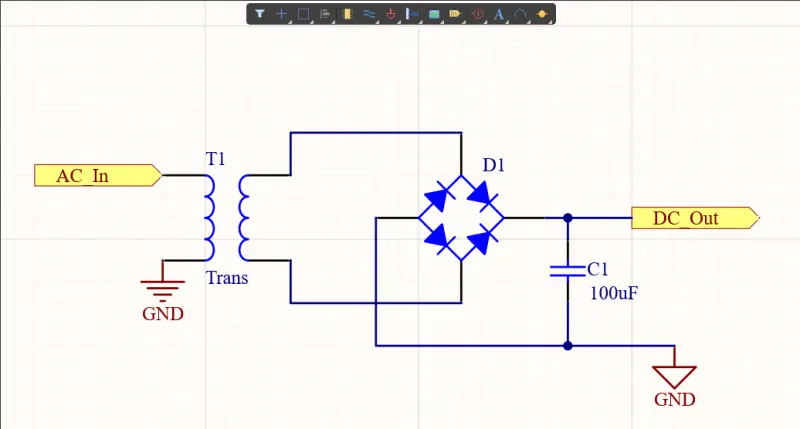
the block diagram of an AC to DC converter (the full wave bridge rectifier) is shown in figure above.
In this type of single phase rectifier ,four individual rectifying diodes are used and they are connected in a closed loop "bridge" configuration to produce the desired output.
the main advantage of this bridge circuit is that it does not require a special centre tapped transformer therefore size and cost are reduces. the single secondary winding is connected to one side of the diode bridge network and the load to the other side as shown in figure.
the smoothing capacitor is used to converts the full wave rippled output of the rectifier into a more smooth DC output voltage.
there are various AC to DC rectifiers used for single phase and three phase.
AC - DC converter (onboard charger) is used for charging the vehicle.
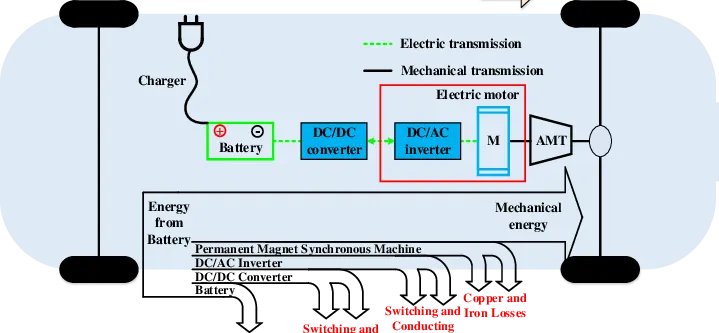
b) DC to AC (inverter ) -used to supply for AC induction motor from a battery.
this static converter are used to convert fixed dc voltage input to variable voltage ,variable frequency ac output voltage and this is called inverters.
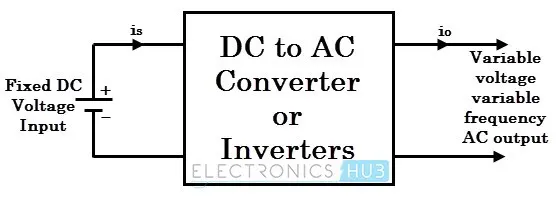
here the fixed DC voltage can be obtained from batteries or by dc link in most of the power electronic converter.
this conversion from DC to AC along with variable supply is produced by varying the triggering angle to the thyristors.
most of the thyristors used in inverters are employed with forced commutation technique.
this is used in the HEV and plug in HEV vehicles are mostly required.
c) DC to DC (chopper) - all car auxilleries need a DC supply with a lower voltage.
Many DC operated applications need different levels of DC voltage from a fixed DC source.
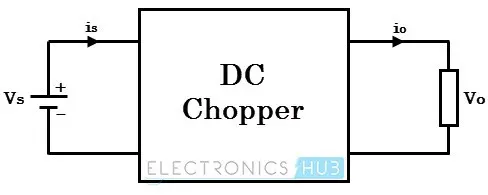
A DC chopper is a static device that converts a fixed input DC voltage to variable DC output or a fixed DC output of different magnitude (which can be lower or higher) than input value.
there are mainly three types of DC to DC converters.
step up type (Boost)=
in this chopper,the output voltage is always greater than input voltage.the configuration of a boost converter is shown in figure below.
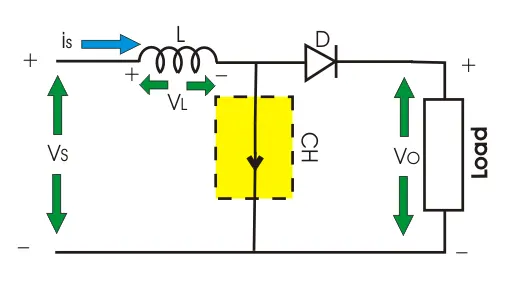
in this switch used which is connected in parrallel with the load. depending upon application this swicth may be SCR,BJT or MOSFET.
A Diode is placed in series with the load that allows the load current to flow when the SCR is turned OFF.When the SCR is turned ON ,the diode is reverse-biased and hence it isolates the load circuit from the source.so the inductor charges to the maximum input voltage source.
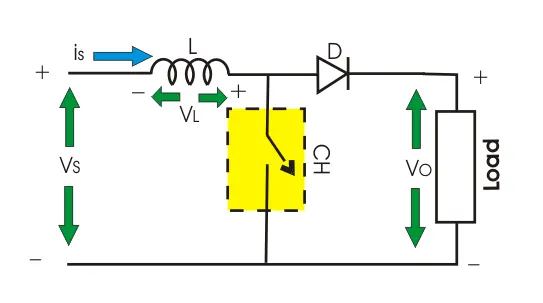
when the SCR is turned OFF,the load gets the voltage from input as well as from inductor.so the voltage appearing across the converter output will be more than the input.here the output voltage is equal to (1/1-d) times the input voltage,where d is the duty ratio (TON/T).by varying this duty ratio,the output voltage will be varied till the load gets desired voltage.
step down type (buck)=
A step down chopper produces an average output voltage lower than the input DC voltage.the circuit for this converter is shown in figure below.
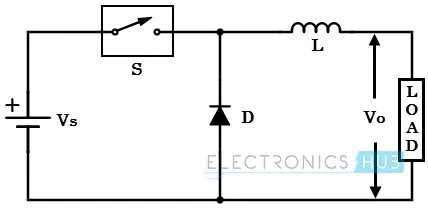
here is the switching component thyristor that switches the input voltage to the load when triggered at particular instants.
a diode acts as a free wheeling diode that allows the load current to flow through it when thyristor is turned OFF.if the diode is absent ,a high induced EMF in inductance may cause damage to the switching device.the average output voltage of the converter is varied by controlling turn ON/OFF period of thyristor.when thyristor is turned ON,the output voltage is same as the input votage and if it is turned OFF ,the output voltage is zero,the output voltage is equal to (TON/T)*Vin.
so ,by controlling the duty ratio K=(TON/T),The output voltage will be increased.
Buck-Boost Chopper=
by continously adjusting its duty cycle,this chopper can be used both in step-down and step-up modes.
this configuration of buck-boost converter is shown in figure below that consist of only one switching device,i.e.one thyristor.
Along with an inductor and diode ,additional capacitor is connected in parallel with this circuit.
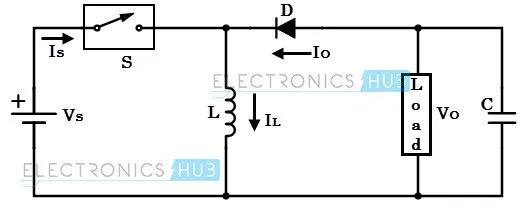
When the thyristor is turned ON,the supply current flows to the inductor through the thyristor and induces the voltage in inductor.
When the thyristor is OFF,the current in the inductor tends to decrease with the induced emf reversing polarity.the output voltage of this converter remains constant as capacitor is connected across the load.
By varying the value of duty ratio to a certain value, the output voltage is lower than the input voltage ,typically in the range 0>=k>0.5 ,thus a buck converter.
And the output is higher than the input voltage if the duty ratio is in the range of 0.5>k>=1,thus act as a boost converter.
Part 2)
An Electric Vehicle's powertrain with 72V battery pack in shown in the diagram below. The duty ratio for acceleration operation is 'd1' and for the braking operation the duty ratio is 'd2'.
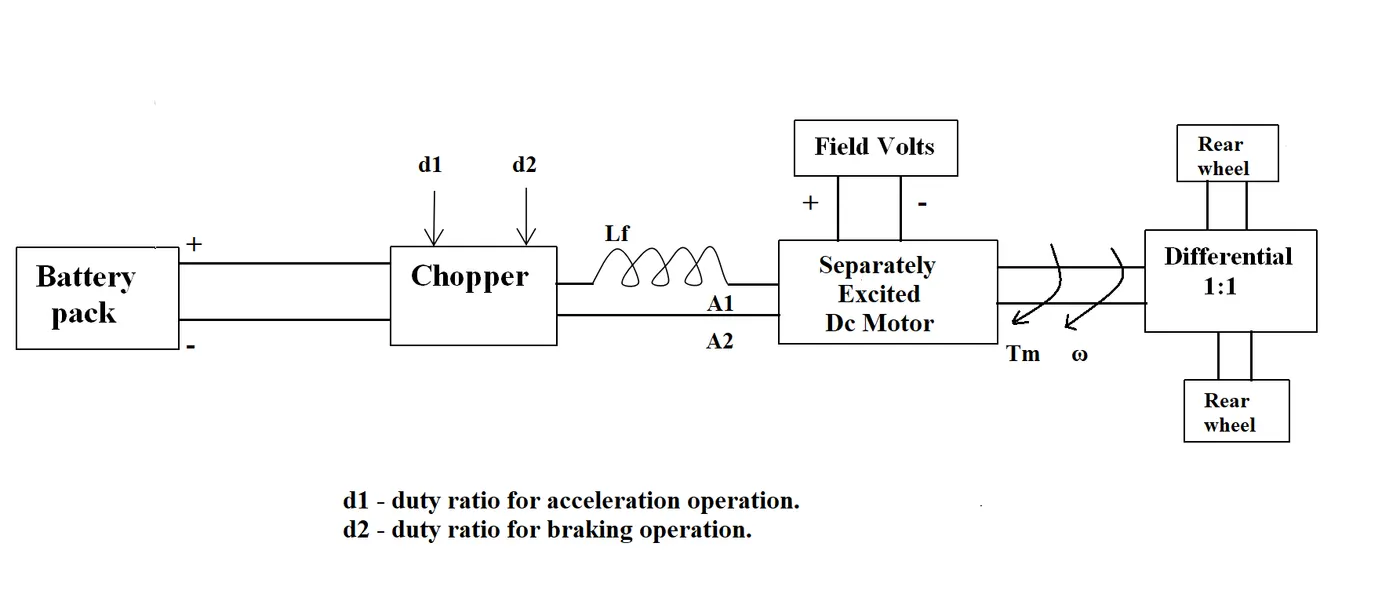
The other parameters of the electric vehicle is given below,
Motor and Controller Parameters:
Rated Armature voltage= 72 V
Rated armature current= 400 A
Ra= 0.5Ω, KΦ= 0.7 Volt second
Chopper Switching frequency= 400 Hz
The vehicle speed-torque characteristics are given by the below equation
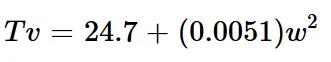
What is EV steady state speed if duty cycle is 70%?
=
Given=
the following input parameters are given
battery pack voltage (V)=72 V
rated armature current = 400 A
armature resistance (Ra)= 0.5
motor constant (K)=0.7
chopper swithing frequency =400 Hz
duty cycle = 70%
Solution=
vehicle output voltage (Vv)= battery voltage (V)*duty cycle
= 72.0*0.70
=50.4 V
So,the vehicle voltage is 50.4 V
Now,equation for vehicle torque is:
Tv = Vv*(Kϕ/Ra) - ((Kϕ)^2/Ra)*w ---------(1)
where,
Tv= vehicle torque (N-m)
Vv = vehicle voltage (Volts)
w= steady state speed of vehicle (rps)
Kϕ= motor constant
Ra= armature resistance.
substituting all the values in equation 1,we get
Tv=50.4*(0.7/0.5)-((0.7)^2/0.5)*w ,
Tv= 70.56 - 0.98*w -------- (2)
now,the vehicle speed torque characteristics is given as,
--------(3)
at steady state,
eq(2)=eq(3) --------(4)
70.56-0.98*w= 24.7+(0.051)*w^2
(0.0051)*w^2+0.98*w-45.85 =0 ------(5)
by solving this equation using quadratic equation formula,we get
x= (-b)±(√b2−4ac/2a)
x=(−0.98) ±(√0.98^2−4(0.0051)(−45.85))/2⋅(0.0051).
w= 38.92 rad/sec.
SO,THE STEADY -STATE SPEED OF THE VEHICLE IS 38.92 rad/sec.
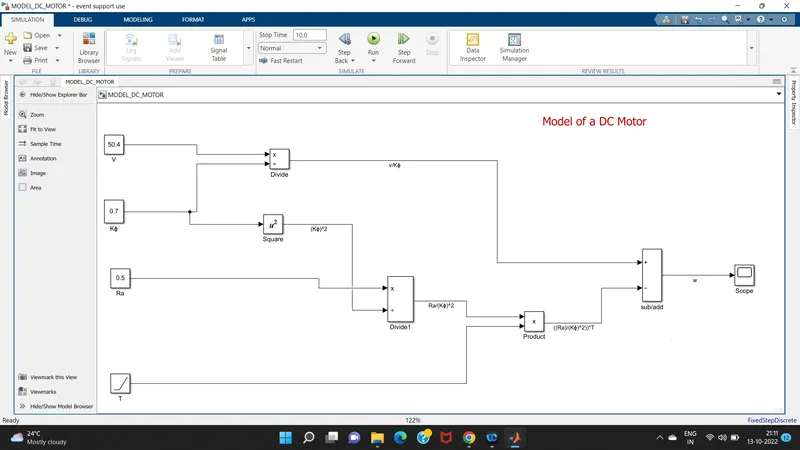
Part 3) Develop a mathematical Model of a DC Motor for the below equation using Simulink.
ω= (V/Kϕ) -(Ra/Kϕ^2 ) .T
for this model we assume
V= 50.4 volts
Kϕ=0.7
Ra=0.5 ohm
and also consider torque as a linearly increasing signal.
model
blocks used =
1)constant=the constant block generates a real or complex constant value signal .use this block to provide a constant signal input.
2)divide=divide one input by another.
3)square=there is a math function block in simulink - math operation ,where you can configure it to perform various math operation including the square function.
4)ramp=the ramp block generates a signal that starts at a specified time and value and changes by a specified rate.
5)product=this block outputs the results of multiplying two inputs.
6) add/sum /sub=this block performs addition /substraction of its inputs.
7) scope=the scope block displays its input with respect to simulation time,the scope allows you to adjust the amount of time and the range of output values displayed.
Explaination=
In this model ,the constant block V=50.4 volt and other constant block Kϕ=0.7 are divided in divide block to get V/Kϕ.
in other divide block ,we devide constant Ra and square of (Kϕ^2) to get (Ra/Kϕ^2 ).
in product block ,we perform the product of (Ra/Kϕ^2 ) and ramp function T to get (Ra/Kϕ^2 )*T.
and finally in sum/substract block we perform substraction of V/Kϕ and (Ra/Kϕ^2 )*T to get w.
Scope response of this model is as shown below
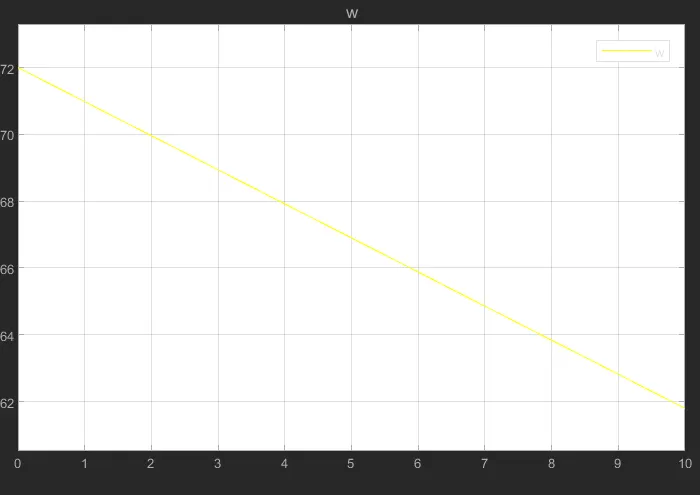
By using value of voltage ,constant,armature resistance ,torque we get the speed value abd speed response curve.
Part 4) Refer to the blog on below topic:
Induction Versus DC brushless motors by Wally Rippel, Tesla
Explain in brief about author’s perspective.
objective: To brief about the blog written by an author from tesla.
the autor wally rippel is a long time of proponent of electric vehicles.before joining of tesla motor ,he was working in AeroVironment ,where he helped to develop the EV1 for genral motors and was featured in the documentary movie,who killed the electric car?he has also worked for the jet propulsion laboratory on electric vehicle battery research,among other projects.when he has a undergraduate student in 1968 built an electric car (a converted 1958 volkswagen microbus) and won the great transcontinental electric car against MIT.
In the begining ,the author describes the dominance of ICE in automobile industry. he explains that no one engine is best but as per requirement they suit for considering price and performance .
he also tells that today we use lithium battery in place of lead acid battery and dc brushless or induction motor in place dc brushed motor,also in place of contactors we use modulating inverters for getting stability.
he discussed topics related to EV technology especially related to DC Brushless motor and induction motor.
DC brushless motor.
he explains,for any motor there are two main parts stator and rotor.
In rotor permanent magnets are used to generate a DC magnetic field ,this magnetic field enters stator which is made up of thin stacked laminations,three sets of distributed winding. and interact with current flowing within the windings to produce a torque interaction between the rotor and stator.
when rotor rotates then there is necessity that magnitude and polarity of the stator currents be continuously varied, for maintaining torque remains constant .for that we use inveter to vary this current and this inverter is used to maintain phase in steps with the angular position of the rotor.
without inverter ,brusless motors are useless motors rotor.it has no starting torque and running peak torque capabilities.
3 phase induction motor
this motor was invented by nikola tesla before 1889,the stator has three sets of 'distributed winding' same as dc brushless motor but rotor has different construction . rotor of 3 phase induction motor has no magnets just steel laminations with buried peripheral conductors with end rings shorted.the rotating magnetic produced by stator enters the rotor so induces voltage exists across the shorted structure that is proportional to the speed difference between the rotor and electrical frequency.
the current flowing in rotor that is rotor magnetic field interact with the original magnetic field to produce force to get desired rotor torque.it is self starting motor and ability to start under load for that no inverter is needed.
this motor has some disadvantages as compared to dc brushless motor,it operate on AC only so AC supply is a must so shaft speed is proportional to line frequency.it has limited starting torque and limited running peak torque capabilities.it is possible to operate this motor on DC supply for that we need inverter by adjusting the inverter frequency but still torque performance is low.
Brushless or induction motor ?
today,all the hybrids are powered by DC brushles drives ,with no exceptions and induction drives have been used in General motors EV-1,the AC Propulsion vehicles ,including the tzero and yhe tesla roadster.
both motor has same stator construction and different rotor construction and inverter controls. dc brushless drives require an absolute position sensor ,while induction drives require only a speed sensor.
one of the main the difference between these motors is that less heat generated in dc brushless drive and it operate at unity power factor whereas induction drive is about 0.85 power factor so energy efficiency is high in dc brushless motor .
In DC Brushless motor ,the magnetic field strength produced by the permanent magnets would be adjustable as per requirement so that losses minimizes and efficiency optimizes but this is not easy to change B with permanant magnets ,this is easy in induction motor since B is proportional to V/f thus the induction machine when operated with a smart inverter has an advantage over a DC brushless machine such that efficiency is optimized.
In DC brushless machine,as machine size grows,the magnetic losses increase proportionately and part load efficiency drops on the other hand with induction, as machine size grows then losses do not grow,thus ,induction drives may be the favored approach where high performance is desired,peak efficiency will be a little less than with DC brushless ,but average efficiency may actually be better.
In DC brushless machine we use permanent magnet in rotors which is very costly and also difficult to handle due to very large forces of magnetic field ,On the other hand no permanent magent is used ,inverter rating is lower so cost appear to be lower and easier to protect .
Induction machines are more difficult to control ,achieving stability over the entire torque-speed range and over temperature is more difficult in induction than with DC brushles .
Inference=
At the end ,the author couldn't choose which drive is better than the other but makes it clear that DC Brushless motor drives will likely continue to dominate in the Hybrid and upcoming Plug-in hybrid markets and induction motor drives will likely maintain dominance for the high-performance pure electric.both drives hardware has so much common mean that we will see induction and dc brushless live and work side by side during the coming golden era of hybrid and electric vehicles.
Conclusion=
1) We have studied and discussed the different types of power converter circuits employd in electric and hybrid electric vehicles.
2) EV Steady-state speed of an EV drivetrain was determined with the given input conditions.
the steady -state speed of the vehicle is 38.92 rad/sec.
3) the mathematical modol for DC motor is developed and scope resonse is shown.
4) lastly,we have studied a Blog on the Topic-
induction versus DC brushless motors by "Wally Rippel",Nikola Tesla and explained in brief about the authors perspective.