Week-6 Challenge: EV Drivetrain
1. Which types of power converter circuits are employed in electric and hybrid electric vehicle?
POWER CONVERTER :
The task of power converter is control the flow of electrical energy by supplying the voltage and current optimally suited for user load .
the large number of atomobiles around the world may cause create the serious problems for envernment and human life . air pullutions , global warming and rapid deplictions in of petrollium resources its may very serious problem .Electric vehical , hybrid electric electric, fuel cell electric vehical , may replace by conventional vehicals near fucture .
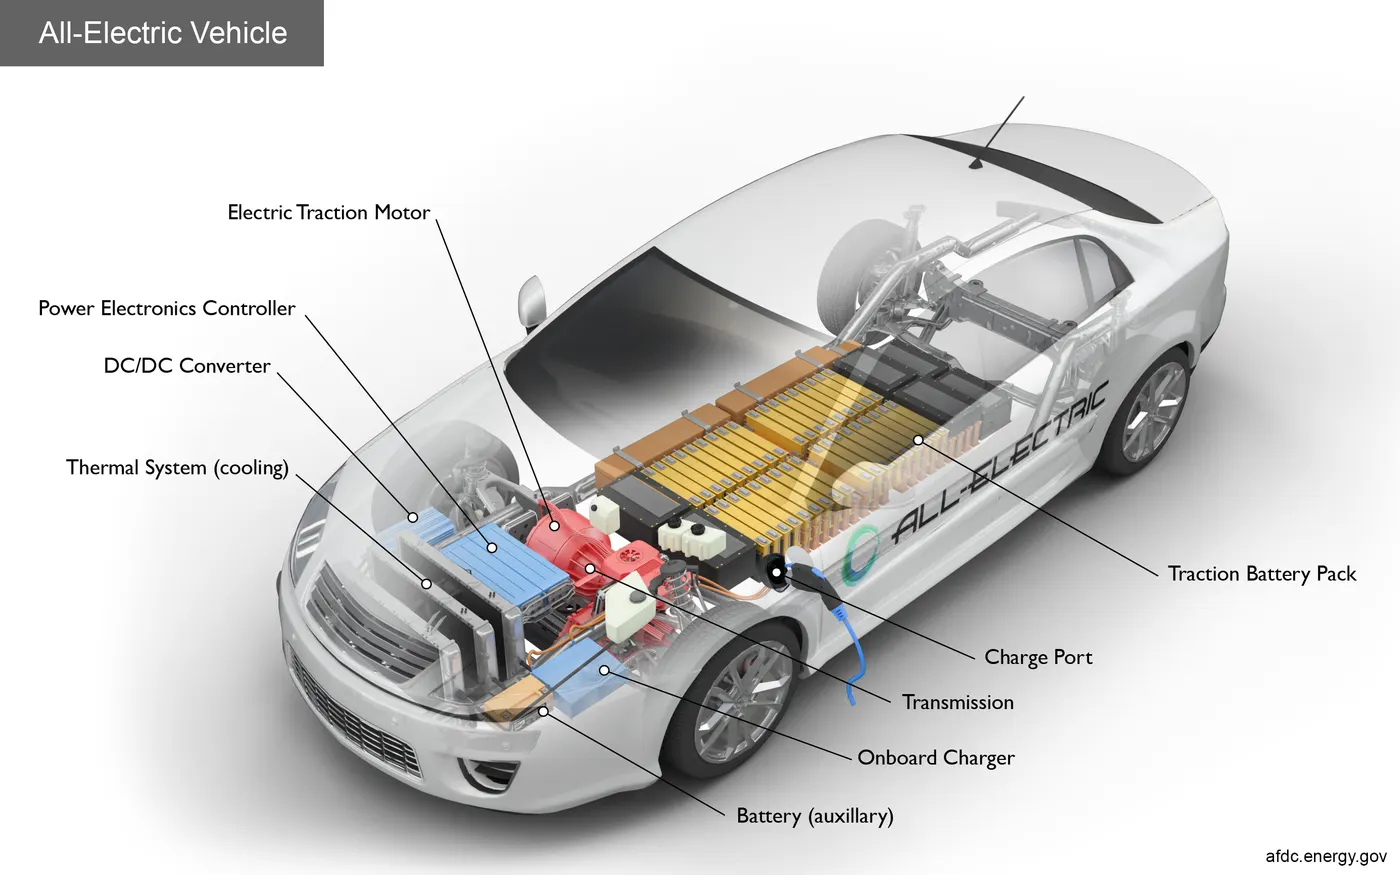
In electrical vehical that uses the the combinations of different energy sources ,fuels cell , super capacitors , and battery foir supplying power to electrical drive system . in ev's the one or more energy source to store the single resorce there by redutions in the system cost , mass , redutions in volume . significant to obtain the better performance . the two ofen used for enegy storage battery and super capacitors .
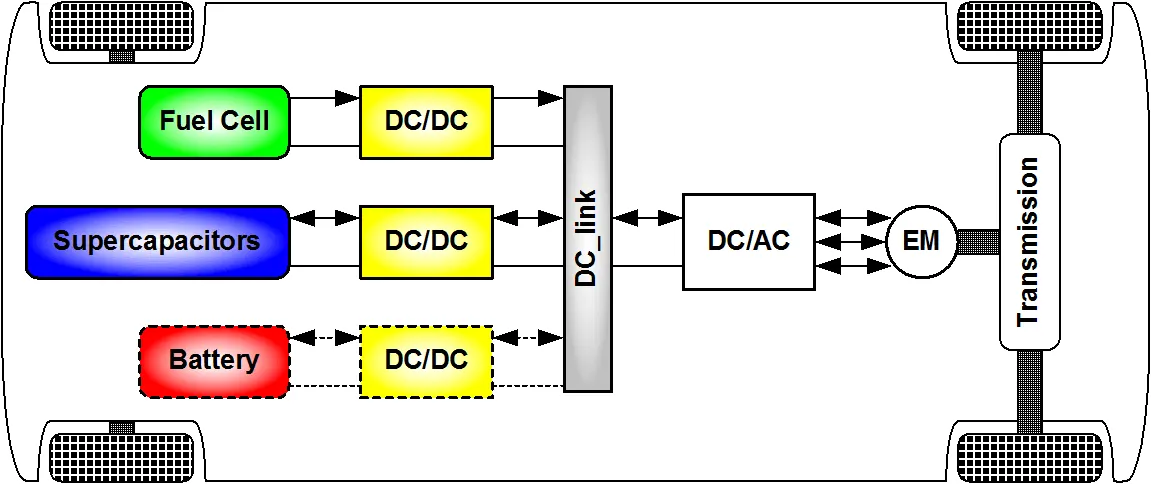
The main component are used in electric vehical are listed below
1- DC-DC converter
2- DC-AC converter
3- motor
4- battery
In electric vehical two main power converter are used .
1- DC-DC conveter
The different configurations of EV power supply show that at least one DC/DC converter is necessary to interface the FC, the Battery or the Supercapacitors module to the DC-link.
In electric engineering, a DC to DC converter is a category of power converters and it is an electric circuit which converts a source of direct current (DC) from one voltage level to another, by storing the input energy temporarily and then releasing that energy to the output at a different voltage. The storage may be in either magnetic field storage components (inductors, transformers) or electric field storage components (capacitors).
DC/DC converters can be designed to transfer power in only one direction, from the input to the output. However, almost all DC/DC converter topologies can be made bi-directional. A bi-directional converter can move power in either direction, which is useful in applications requiring regenerative braking.
The amount of power flow between the input and the output can be controlled by adjusting the duty cycle (ratio of on/off time of the switch). Usually, this is done to control the output voltage, the input current, the output current, or to maintain a constant power. Transformer-based converters may provide isolation between the input and the output. The main drawbacks of switching converters include complexity, electronic noise and high cost for some topologies.
1.1. Non-isolated converters
The non-isolated converters type is generally used where the voltage needs to be stepped up or down by a relatively small ratio (less than 4:1). And when there is no problem with the output and input having no dielectric isolation. There are five main types of converter in this non-isolated group, usually called the buck, boost, buck-boost, Cuk and charge-pump converters. The buck converter is used for voltage step-down, while the boost converter is used for voltage step-up. The buck-boost and Cuk converters can be used for either step-down or step-up. The charge-pump converter is used for either voltage step-up or voltage inversion, but only in relatively low power applications.
1.2. Isolated converters
Usually, in this type of converters a high frequency transformer is used. In the applications where the output needs to be completely isolated from the input, an isolated converter is necessary. There are many types of converters in this group such as Half-Bridge, Full-Bridge, Fly-back, Forward and Push-Pull DC/DC converters . All of these converters can be used as bi-directional converters and the ratio of stepping down or stepping up the voltage is high.
1.3. Electric vehicle converters requirements
In case of interfacing the Fuel Cell, the DC/DC converter is used to boost the Fuel Cell voltage and to regulate the DC-link voltage. However, a reversible DC/DC converter is needed to interface the SCs module. A wide variety of DC-DC converters topologies, including structures with direct energy conversion, structures with intermediate storage components (with or without transformer coupling.
-
Light weight,
-
High efficiency,
-
Small volume,
-
Low electromagnetic interference,
-
Low current ripple drawn from the Fuel Cell or the battery,
-
The step up function of the converter,
Control of the DC/DC converter power flow subject to the wide voltage variation on the converter input.
2: DC -AC converter
its convert direct current (dc) into alternating current (ac) its can be used in other device such as traction motor .
The inverter can be used to controlled the speed of motor by adjusting the frequency of alternating current .
the inverter are capability to change the torque power by adjusting the alternating current parameters .
its invert dc charge into ac charge by driving the moltor in opposite direction and opposite during the regenrative braking . equally important job of inverter is to control the static charge in motors to create the revolving magnetic field .
2. An Electric Vehicle's powertrain with 72V battery pack in shown in the diagram below. The duty ratio for acceleration operation is 'd1' and for the braking operation the duty ratio is 'd2'.
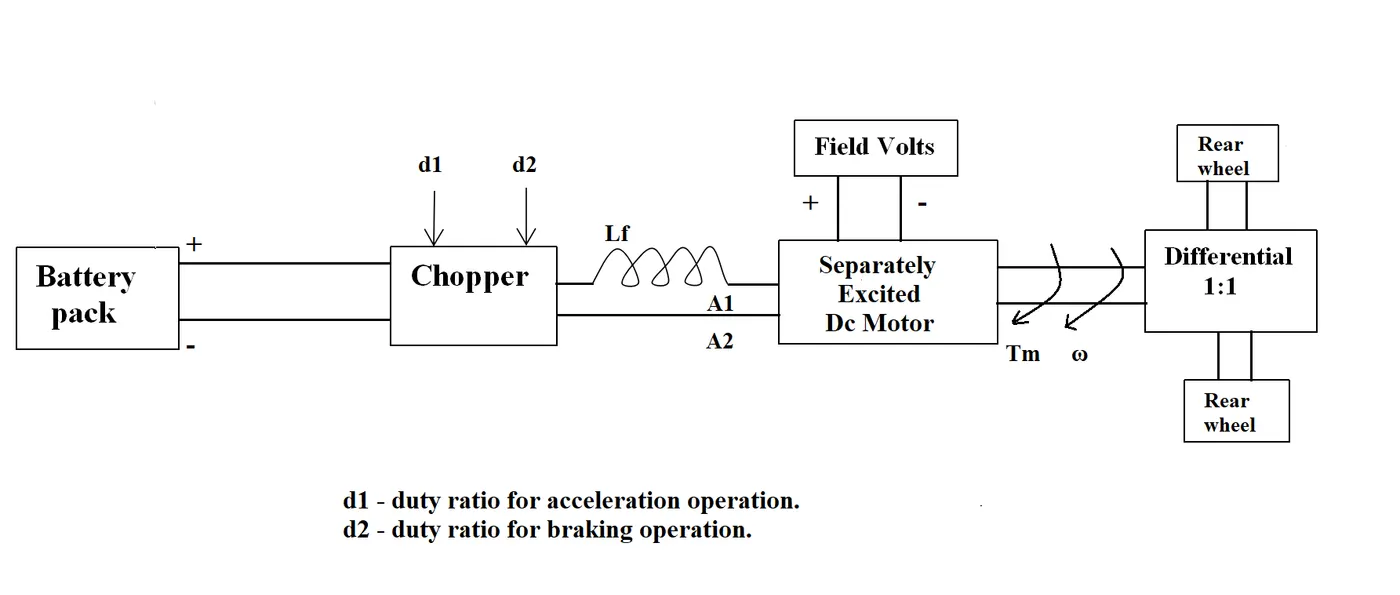
The other parameters of the electric vehicle is given below,
Motor and Controller Parameters:
Rated Armature voltage= 72 V
Rated armature current= 400 A
Ra= 0.5Ω, KΦ= 0.7 Volt second
Chopper Switching frequency= 400 Hz
The vehicle speed-torque characteristics are given by the below equation
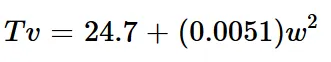
AIM:
duty cycle = 70% =0.7
voltage = armature voltage *duty cycle
v= 72* 0.7= 50.4 v
T= motor torque
Ra= armature resistance
motor constant =kΦ
w=angular speed of the motor
Torque equation of motor
Tm= (vkΦ/Ra) -((kΦ)^2/Ra).w )
Tm= ((50.4*0.7)/0.5)-((0.7)^2/0.5)*w)
Tm= 70.56-0.98w ................................(1)
Tv= 24.7+ (0.0051)*w^2.......................(2)
equating above equations (1) and (2)
70.56-0.98w= 24.7+ (0.0051)*w^2
so we get quadratic equation
0.0051 w^2+0.98w -45.86=0
In order to find out the above quadratic equations
ax2 + bx + c = 0.
x = −b ± √(b2 − 4ac) /2a.
substituting equations in above formula
here we get w= 38.23 and w= -230. 03 rad/sec
the steady state angular speed is 38.23 rad/sec .
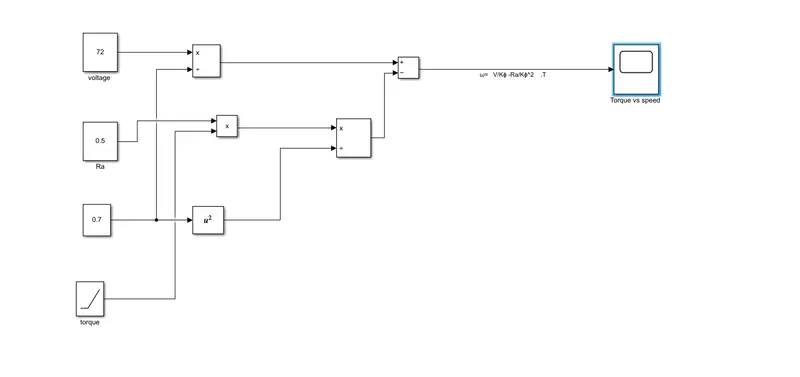
3. Develop a mathematical model of a DC Motor for the below equation using Simulink.
ω">ω= V/Kϕ">ϕ -Ra/Kϕ">ϕ^2 .T
below mathematical model shown
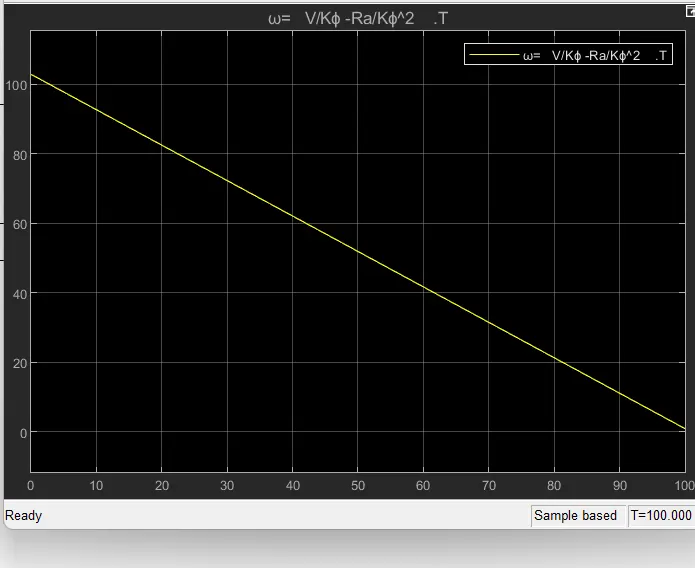
result :
4: indution motor vs brushless dc motors .Explain in brief about author’s perspective.
Induction motor:
When a 3-phase induction motor is connected to utility type 3-phase power, torque is produced at the outset; the motor has the ability to start under load. No inverter is needed. (Were an inverter needed, Tesla’s invention would have been useless until sometime in the 1960s.) The fact that induction motors are directly compatible with conventional utility power is the main reason for their success. In contrast, a brushless DC motor produces no starting torque when directly connected to fixed frequency utility power. They really need the aid of an inverter whose “phase” is maintained in step with the angular position of the rotor.
While 3-phase induction motors have great utility, they also have some severe limitations. They cannot operate from DC; AC is a must. Shaft speed is proportionate to line frequency. Hence, when used with utility power, they are constant speed machines. Finally, when operated from utility power, they have limited starting torque and somewhat limited running peak torque capabilities, when compared to DC type machines.
Add an inverter (without any feedback control) and it becomes possible to power an induction machine from a battery or other DC source; variable speed also becomes possible simply by adjusting the inverter frequency. Still, torque performance is low compared with DC machines. Add some feedback loops such that the inverter produces the exact frequency that the motor desires,” and the induction motor is now capable of competing with DC and DC brushless for vehicle applications.
2: brushless motor
One of the main differences is that much less rotor heat is generated with the DC brushless drive. Rotor cooling is easier and peak point efficiency is generally higher for this drive. The DC brushless drive can also operate at unity power factor, whereas the best power factor for the induction drive is about 85 percent. This means that the peak point energy efficiency for a DC brushless drive will typically be a few percentage points higher than for an induction drive.
In an ideal brushless drive, the strength of the magnetic field produced by the permanent magnets would be adjustable. When maximum torque is required, especially at low speeds, the magnetic field strength (B) should be maximum – so that inverter and motor currents are maintained at their lowest possible values. This minimizes the I² R (current² resistance) losses and thereby optimizes efficiency. Likewise, when torque levels are low, the B field should be reduced such that eddy and hysterisis losses due to B are also reduced. Ideally, B should be adjusted such that the sum of the eddy, hysteresis, and I² losses is minimized. Unfortunately, there is no easy way of changing B with permanent magnet.
we can say that indution dc brushless motor can be highly dominant in case PHEV .
indutions motors are highly prefered in the pure EV vehical .