Week-6 Challenge: EV Drivetrain
Ans.1)
In electric and hybrid electric vehicle, power electronic is responsible for converting and controlling electric power in system. Some of the major power electronic components and functionalities are used in electric vehicle system. These include inverter, converter, and on-board charger. Operations at high voltage or high current can be efficiently executed by utilizing power electronic devices, as they deliver faster switching rate at higher efficiency. In addition, power electronics control both unidirectional as well as bidirectional flow of energy, depending on the usage, and the regenerated energy can be sent back to utility.
The three types of converter used in electric vehicle are:
AC - DC Converter:-
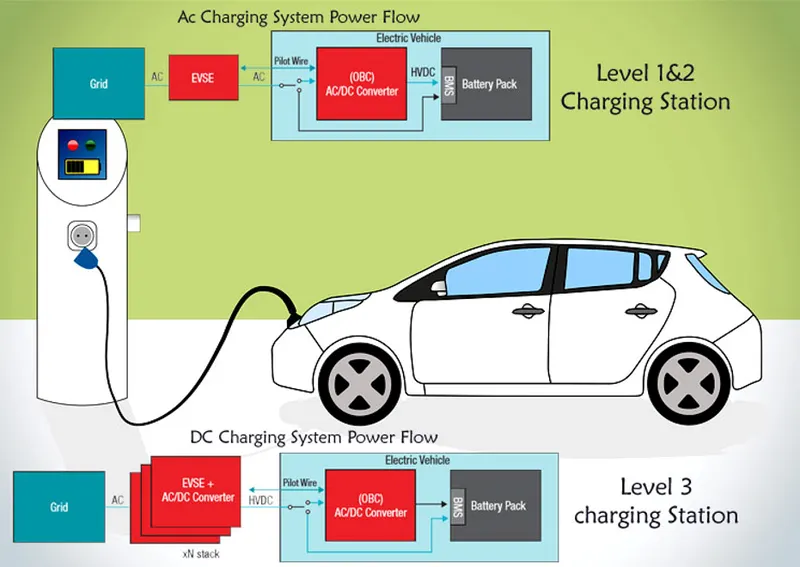
AC to DC converters are most commonly used in Plug-in Hybrid Electric Vehicles (PHEV) & Plug-in Electric Vehicles (PEV). These vehicles get their propulsion power from an external electricity source (charging stations) which is alternating current. The battery needs to be charged using a direct current source. For this purpose, AC to DC converter is employed in a PHEV & PEV.
DC - DC Converter:-
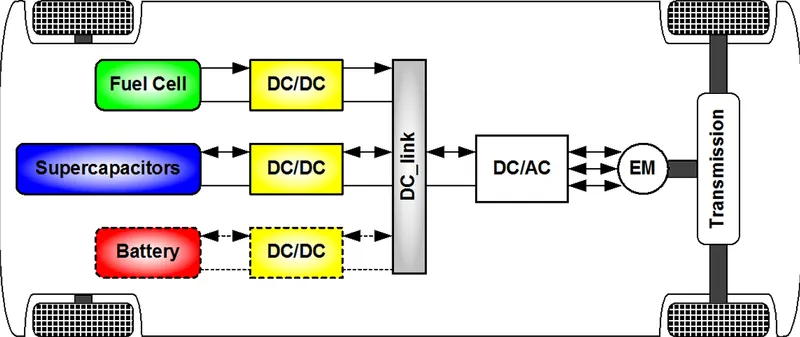
A DC to DC converter is a category of power converters and it is an electric circuit which converts a source of direct current (DC) from one voltage level to another, by storing the input energy temporarily and then releasing that energy to the output at a different voltage. The storage may be in either magnetic field storage components (inductors, transformers) or electric field storage components (capacitors).
DC/DC converters can be designed to transfer power in only one direction, from the input to the output. However, almost all DC/DC converter topologies can be made bi-directional. A bi-directional converter can move power in either direction, which is useful in applications requiring regenerative braking.
DC - AC Converter:-
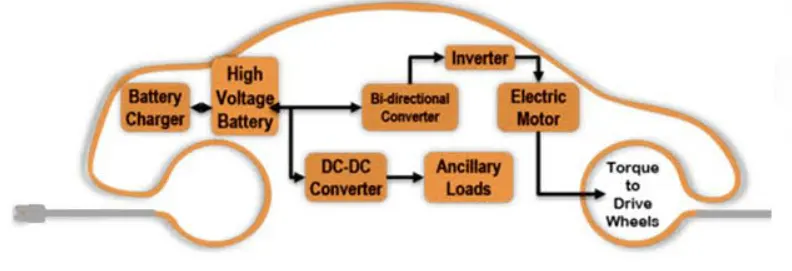
An inverter is a device that converts DC power to the AC power used in an electric vehicle motor. The inverter can change the speed at which the motor rotates by adjusting the frequency of the alternating current. It can also increase or decrease the power or torque of the motor by adjusting the amplitude of the signal.
Ans2) Given,
Battery pack voltage (V) = 72V
Rated armature current = 400 A
Armature Resistance (Ra) = 0.50
Motor constant (Kϕ) = 0.7
Chopper Switching frequency= 400 Hz
Duty Cycle = 70%
Tv = 24.7 + (0.0051) ω2..................eqn(1)
Vehicle Output Voltage (V) is given by,
Vv = Battery Voltage (V) * Duty Cycle
V=72*0.70
Thus, Vehicle voltage = 50.4V
Now, torque equation for motor,
T = VKϕ/Ra – ((Kϕ)2/Ra)*ω
T = 50.4*0.7/0.5 – ((0.7)2/0.5)*ω
T = 70.56 - 0.98 ω....................eqn(2)
solving equation (1) & (2),
comparing both torque of vehicle and torque of motor,
24.7 + (0.0051) * ω2 = 70.56 - (0.98) * ω
0.0051 ω2 + 0.98 ω - 45.86 = 0
by solving this by quadratic equation we get,
we get 2 values of ω as
ω = 38.915 rad/sec
and
ω = -231.072 rad/sec
So, the EV steady state speed if duty cycle is 70% = 38.915 rad/sec .
Ans3).Given,
ω = V/Kϕ - Ra/Kϕ^2 .T
We assumed the parameter,
V= 200,
Kϕ =0.7,
Ra = 0.5,
T = 80,
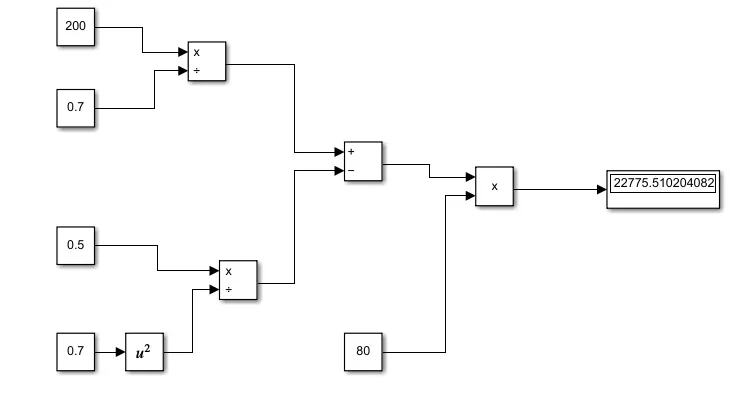
So before plotting a function, we need to identify the basic blocks which are required for carrying out the plotting of a function in simulink.So, the fundamental blocks which are required for our equation are as follows.
1) Constant :-

So, for the given example, we have three contant such as, 200,0.7 & 0.5.
2) Square :-
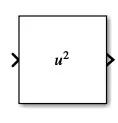
In the given example, we need to use the square blocks for a value of constant 0.7.
3) Multiplication:-
So, after divide and adding all the blocks & fixing the connection, we need to use the multiplication block for getting the final output as mentioned in the given example.
4) Divide:-

we need to use the divide block for getting the final output as mentioned in the given example.
5) Add block :-
Default Add Block
So, after getting the above default block named 'Add block', we need to change the sign from ++ to +- as wherever is required according to question,then want to double click on above block and change the default sign.
7) Display:-
The Display block shows the value of the input data. You can specify the frequency of the display.
The simulink model is as shown below:
Ans4).
The Author describes the dominance of Internal Combustion Engines (ICE) in the world of automobile industry and also discuss different types of engines. He explains that all engines were similar and it was up to the user to select according to their requirement.
Then he explains the working of both 3 phase induction motor and a brushless DC motor. Now the author has done comparison between these two technologies and stated some advantages and disadvantages of each.
Induction motor have some advantages like: it has no magnets. The motor has the ability to start under load. No inverter is needed. Some disadvantages of Induction motors are: They cannot operate from DC: AC is a must. Shaft speed is proportionate to line frequency. Hence, when used with utility power, they are constant speed machines. When operated from utility power, they have limited starting torque and somewhat limited running peak torque capabilities, when compared to DC type machines.
Brushless DC motor have some advantages like: much less rotor heat is generated with the DC brushless drive. The peak point energy efficiency for a DC brushless drive will typically be a few percentage points higher than for an induction drive. Some disadvantages of Brushless DC motor are: as machine size grows, the magnetic losses increase proportionately and part load efficiency drops. Permanent magnets are expensive and difficult to handle due to very large forces that come into play when anything ferromagnetic gets close to them.
Finally the author couldn't choose which drive is better than the other but makes it clear that DC brushless drives will likely continue to dominate in the hybrid and coming plug-in hybrid markets, and that induction drives will likely maintain dominance for the high-performance pure electrics.