Week-4 Challenge WOT Condition Part-2
1. What is the difference between mapped and dynamic models of engine, motor, and generator? How can you change the model type?
Powertrain provides two different types of engine models:
- Mapped Models,
- Dynamic Models
Mapped models are made to run based on the available data tableT.his type of modelling is less accurate. The lookup tables value are based on the values of brake torque, commanded torque and engine speed. Mapped engine models are suitable for analysis and design activities that do not require enigne subsystem dynamic characteristics,for example in egine and transmission powertrain matching analysis for fuel economy,emissions and performance trade-offs.
Dynamic models:
This type of model uses real time data fed by the user at run time for modelling. This model is more accurate than mapped engine model. This type of model is used when the data of subsystems of a vehicle is required. We can calculate : Brake torque, fuel flow, port gas mass flow, exhaust temperature, exhaust mass flow rate and exhaust emissions.
-----------------*---------------------*---------------
Mapped Engine: Mapped Engine is the default settings in powertrain blockset. It is used to measure to measure performance parameters of the vehicle by using standard lookup tables which are prefed to the system. This type of modelling is less accurate. The lookup tables value are based on the values of brake torque, commanded torque and engine speed. If any other parameter like Input engine temperature is selected then lookup table values are also a function of the temperature parameter. The data extracted from lookup tables are: air mass flow, fuel flow, emission data, exhaust temperature and efficiency. This data is used to find out other parameters which are needed by the end user.
Dynamic Engine: This type of model uses real time data fed by the user at run time for modelling. This model is more accurate than mapped engine model. This type of model is used when the data of subsystems of a vehicle is required. We can calculate : Brake torque, fuel flow, port gas mass flow, exhaust temperature, exhaust mass flow rate and exhaust emissions.
Mapped Motor: The mapped motor works in torque control mode. This type of motor is used when the user requires a faster simulation and doesn't have the knowledge of motor parameters. The output torque and reference torque is compared and changes are made. Input torque or speed can be specified, electrical losses and maximum motor power and torque can be defined.
Dynamic Motor: In the dynamic motor a three phase interior permanent magnet synchronous motor (PMSM) is used. The block uses three phase input voltages to regulate the individual phase currents, allowing control of the motor torque or speed. This block is used when the user knows what parameters are to be used in that particular simulation. This motor is more accurate.
Mapped Generator: The mapped generator block is also similar like other blocks. Most of the data required is taken from the lookup tables corresponding to the given input parameters. Its simulation time is less.
Dynamic Generator: The dynamic generator involves users entering the parameters manually during the run time for their particular applications. The results take time and are more accurate
---------------- -------------------- ----------------
Motor power block from the model Ev reference Application
By running the model from help—we may get this by sequentially double-clicking the : passenger car, Electric plant, motor trq cmd, motor,
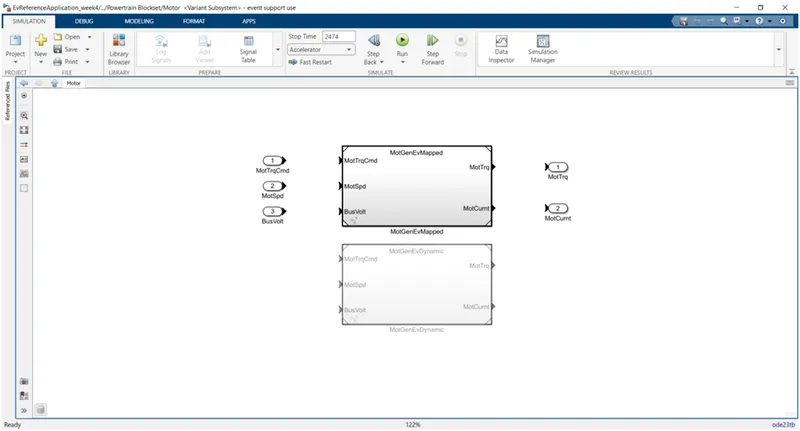
- Mapped Models
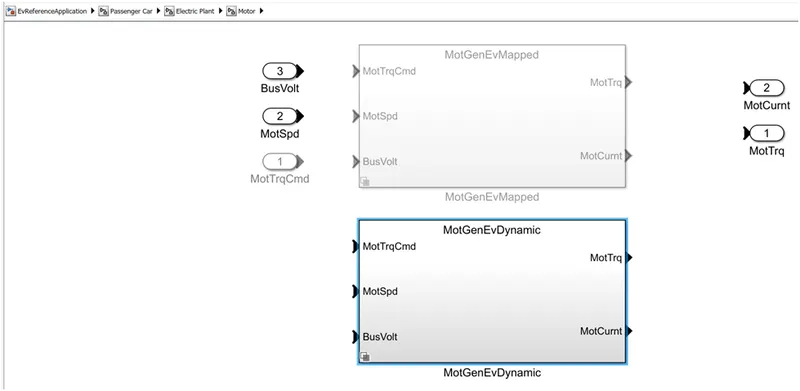
EV Mapped :
Run simulations with available data that is given in the lookup tables. Advantage of having this type of configuration is that we can give data that is as per our requirement and specifications. Mapped engine models are basically used in applications involving design that doesn’t require dynamics characteristics.
By double clicking on Mapped block we may get this below block set :
------------- ------------------------ --------------------------
EV Dynamic Models: This type is defined as the actual model that represents actual components. Dynamic model consists of actual motor and motor controller along with interior permanent magnet controller. This is real time simulations and provides results based on real time scenarios. The time it takes to generate results is comparatively longer than mapped type. These are suitable for designing control that depends on dynamics characteristics and subsystem.
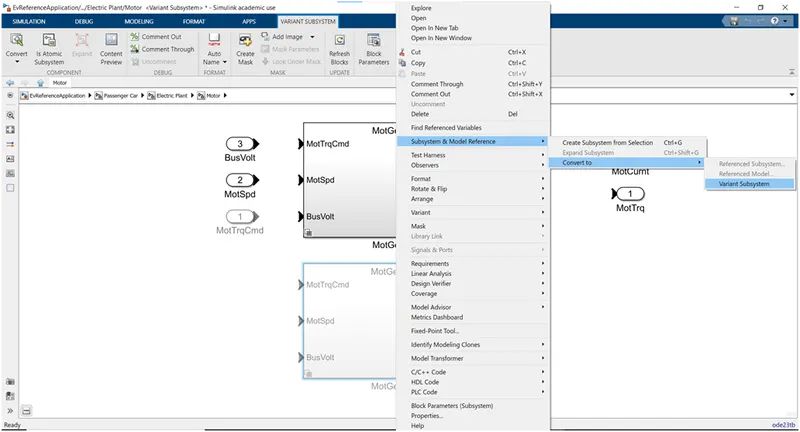
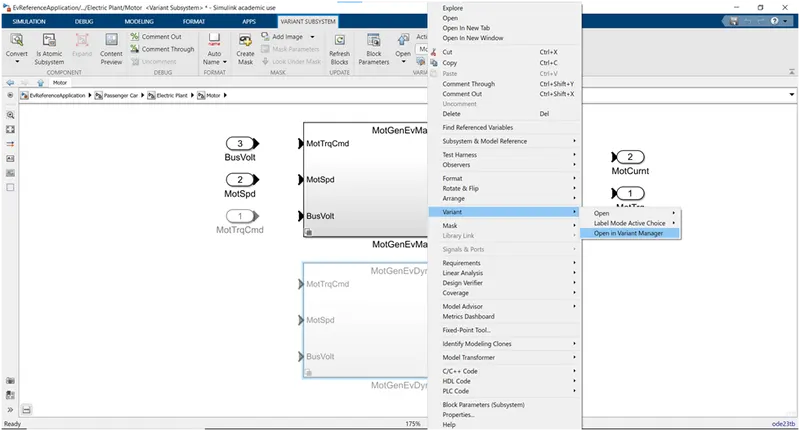
To change from one model type (Mapped) to another model type (Dynamic) follow below steps.
As a 1st step-- right click on Mapped model and select Subsystem & Model reference, convert to and then select Variant Subsystem to activate Variant subsystem option.
Secondly right click Dynamic block and select Variant, further select open in Variant Manager.
Right click MotGenEvDynamic and select “Set as label mode active choice”
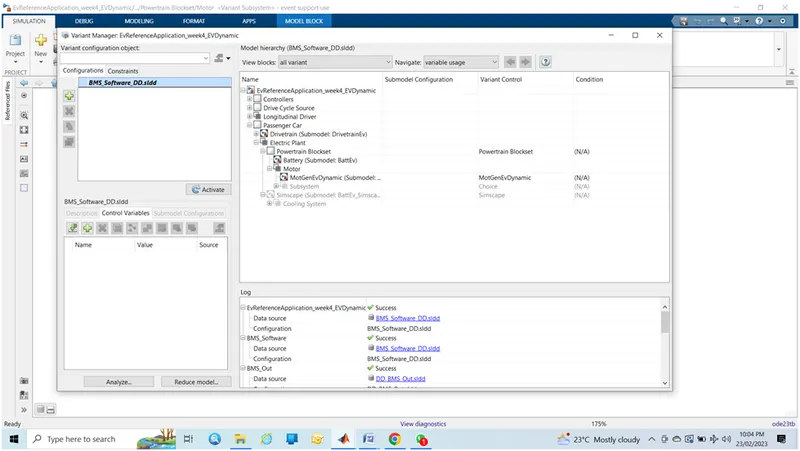
Now the desired block (Dynamic) will be activated..
--------------------** ------------------------** -----------------------
2. How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Miles per Gallon is a criterion that relates the distance travelled by a vehicle and the amount of fuel consumed which is a scale to measure the fuel consumption related to the driving pattern.
MPGe: In the US to compare the efficiency of gasoline vehicle with the BEVs, PHEVs or FCEVs MPGe unit was formulated. MPGe stands for Miles Per Gallon Equivalent. It has been found that 1 gallon of gas has the same amount of energy as 33.7 kwh of electricity.
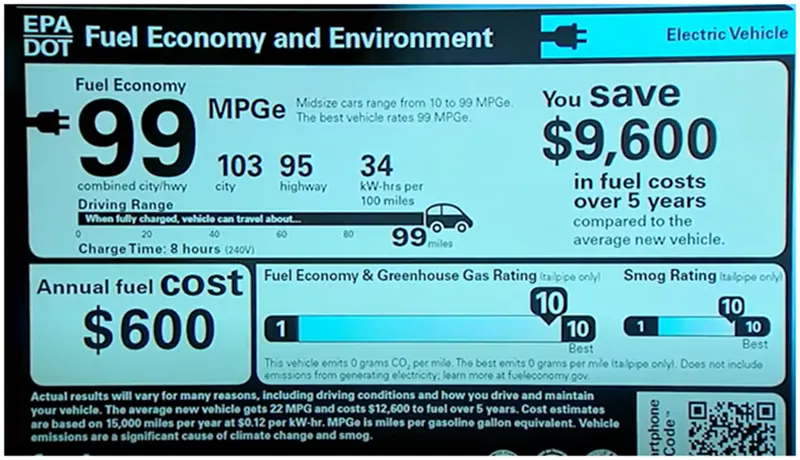
The above rating is given by EPA (Environmental Protection Agency). Here only one fuel economy is given as it runs only by electricity as it is a BEV.
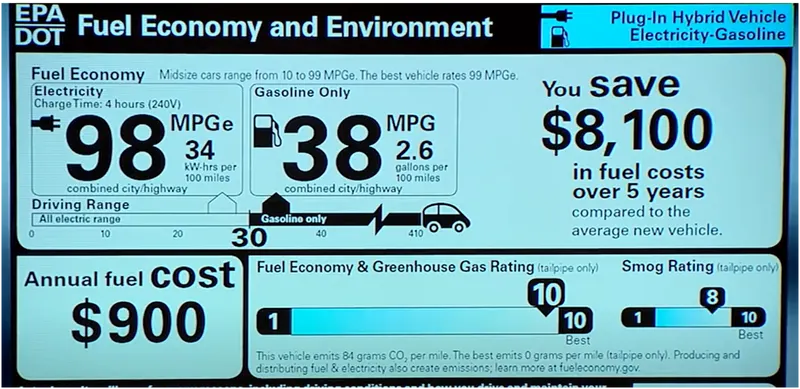
The above rating has two values as it is a PHEV. One is for pure EV mode and other one is for pure engine mode.
Eg. A battery propells the vehicle for 3.125 miles per kwh capacity of battery. So,
3.125 miles/kwh * 33.7 kwh/gallon = 105 MPGe
In the model it is calculated by this block:
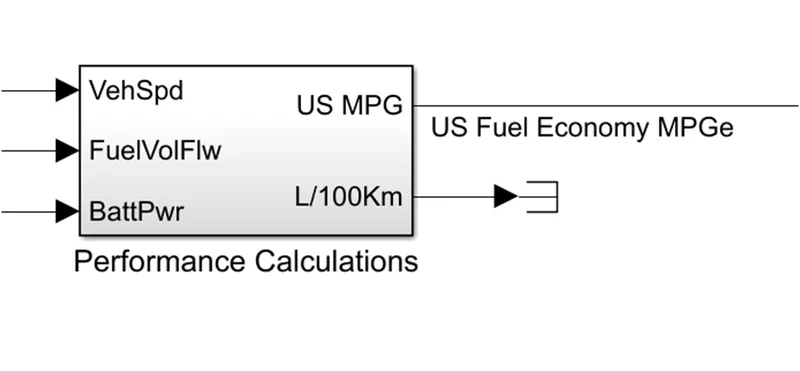
Vehicle speed and battery power are two different factors that are considered to model fuel flow.
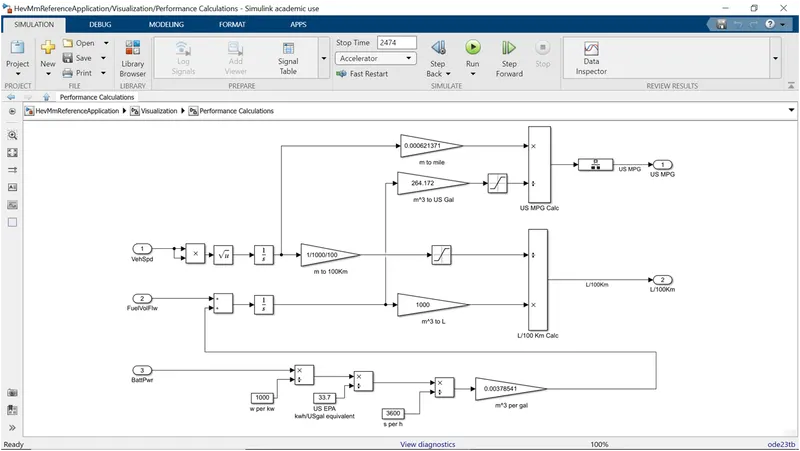
The above image has two fuels electricity and fuel. As discussed earlier 1 gallon of gas equal to 33.7 kwh of electricity.
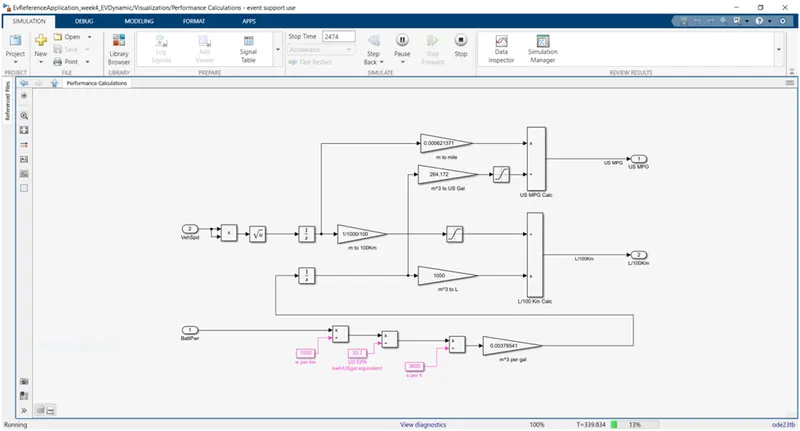
So battery power is first converted into KW (W/1000) then its divides by 33.7 kwh. The fuel equivalent of battery is added to the fuel flow. Using the vehicle speed and time the distance of travel is calculated. Then distance is converted into miles by conversions. Then as we have the fuel flow in m^3 and distance in miles. We can calculate the fuel efficiency.
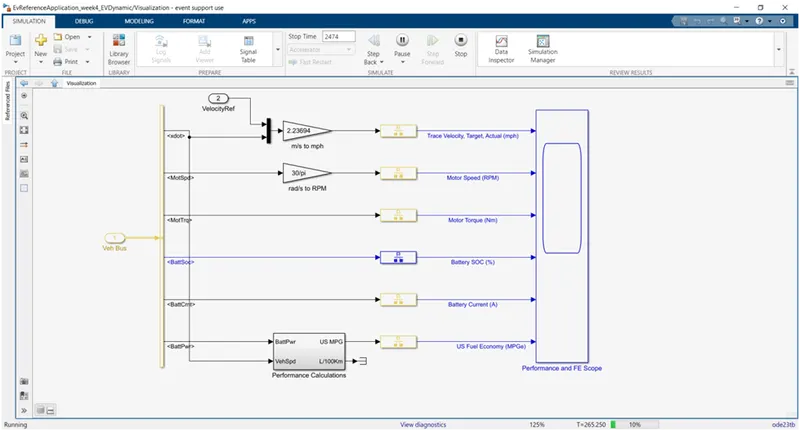
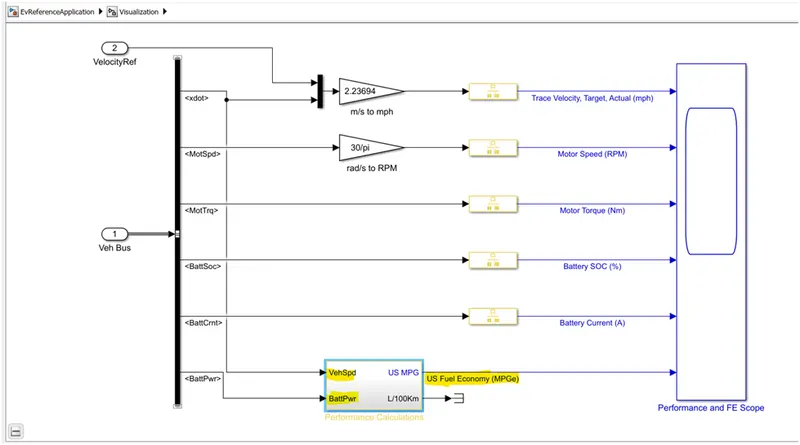
Vehicle speed is integrated first to determine the value of distance with respect to time. Then Unit conversion is done to get the desired output.
-------------------------**----------------------------**------------------
3. Run the HEV Reference Application with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
With the help of a document on Hybrid Electric Vehicle with WOT cycle from MathWorks we can use the command “autoblkHevStart” in the command Window to activate the Simulink block diagram.
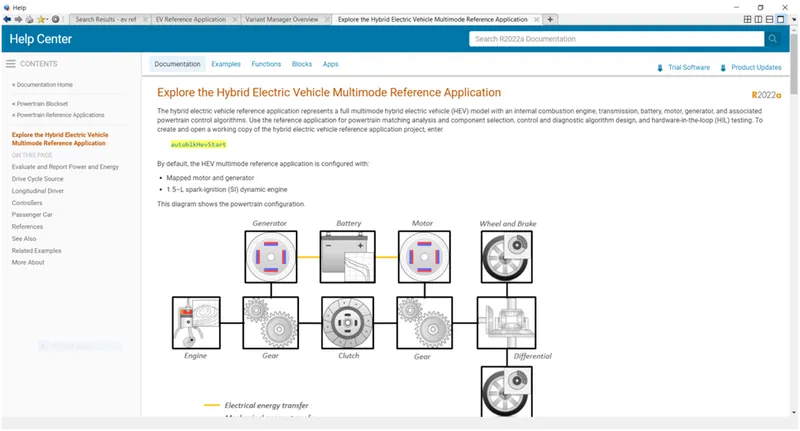
Case1: Without grade and wind velocity parameters.
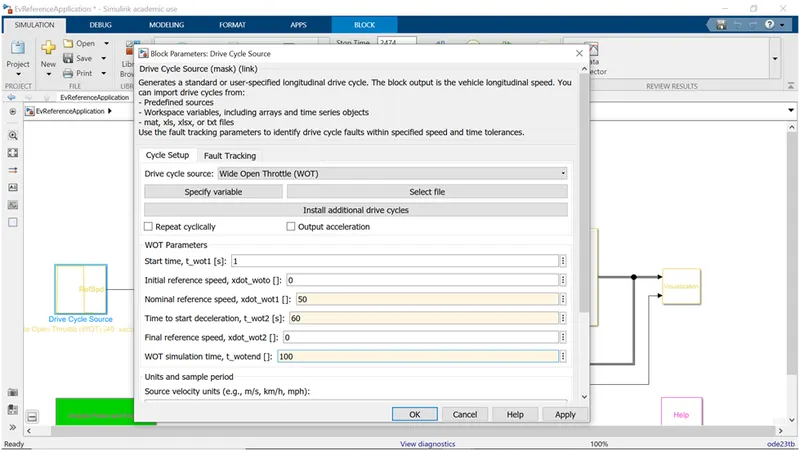
From the options available in drive cycle block, we can select WOT since its our desired type of drive cycle.
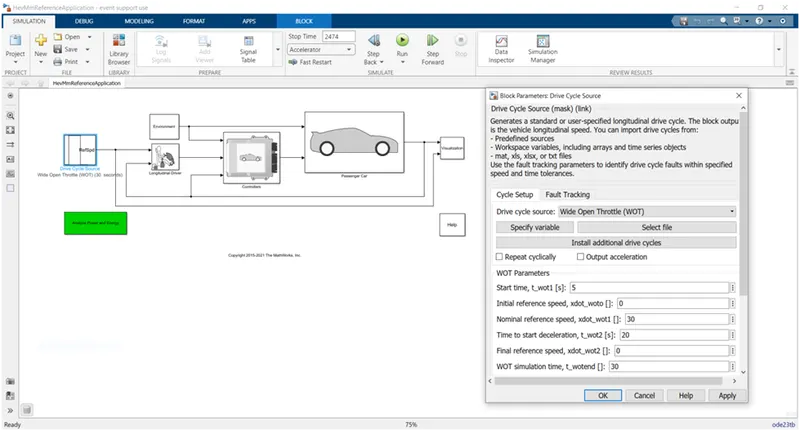
Start time, Nominal reference speed, time to start deceleration and final reference time are taken as per the above image.
Now to obtain the results to understand the parameters such as battery SOC, Velocity and fuel economy : model made to Run:
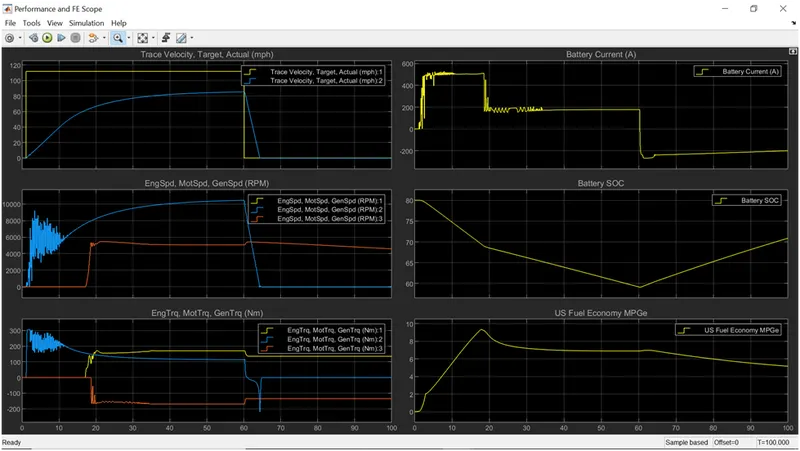
From the above graphs we can see that,
Trace Velocity target and actual graph: The yellow line indicates the desired path and blue line is the actual path. So it can be seen that battery power is not enough to meet the requirements of the grade and wind velocity.
Battery Current Graph: When the vehicle is accelerating the battery current is also increasing. When the velocity is constant the current requirement also becomes constant. When the deceleration starts the battery current becomes negative indicating regenerative braking.
Battery SOC: The battery SOC keeps on depleting until regenerative braking starts. This increases the SOC.
Engine, Motor and Generator Speed: Initially only motor is used to start the vehicle as motor has high initial torque. Later generator (red graph) kicks in charging the battery when SOC drops below 70%. Engine graph can't be seen as it may have overlaped with generator
Engine, Motor and Generator Torque: Motor torque is high initially (blue line) and then engine kicks in at a later stage (yellow line). Generator torque (red line) is negative as its charging the battery.
- Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
use the command: ''autoblkEvStart''
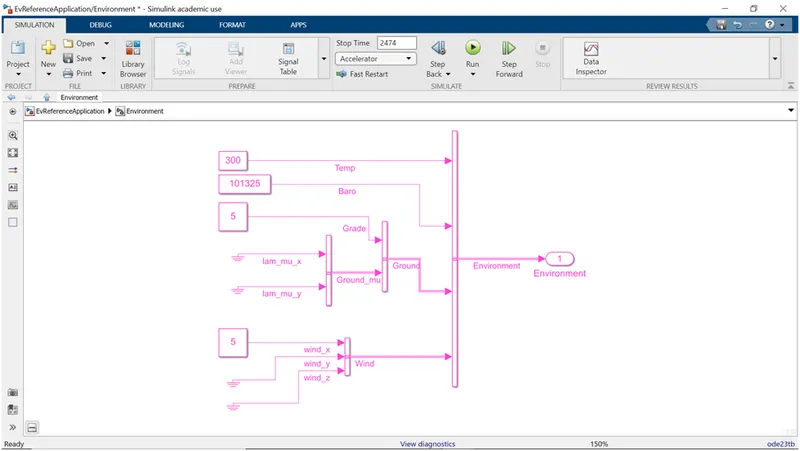
Now simulating the EV with WOT drivecylce, wind velocity as 5m/s, grade as 5 degree and keeping the rest of the parameters same as above HEV case.
We get the following performance graphs:
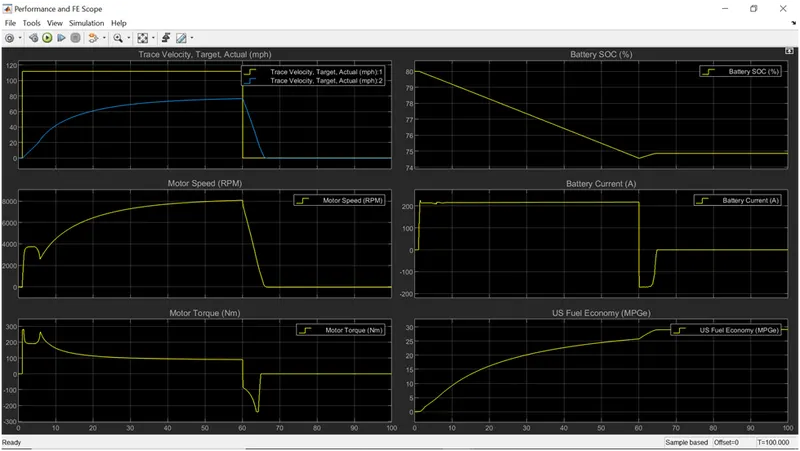
After comparing the graphs of both EV and HEV following conclusions can be drawn:
- The first graph (target and actual velocity graph) performance is almost same. the reason could be that in that region only motor was operating so the performance in both EV and HEV is similar.
- The battery current drawn by HEV initially is upto 500 A and later decreases to 200 A. This can be attributed to the fact that initially only motor takes all the load and later engine kicks in so motor load drops thus current drawn by motor reduces. And during the deceleration it is seen that negative current (regenerative braking) flows for a longer time in HEV as compared to EV. So we can say that, regenerative braking is more aggressive in HEV.
- SOC improvement of almost 15% is seen in HEV during deceleration and only 2% improvement can be seen in EV during deceleration. This can be understood by the same reason explained in point 2.
- Motor torque and motor speed are stable in EV and they keep fluctuating a lot in HEV during the starting. Also, the peak RPM of the motor in EV is less than HEV. These differences can be attributed to the fact that the battery power of an EV is more than HEV.
-
The battery current capacity of pure EV is much higher compared to that of HEV since in EV battery is the only driving unit.
-
The fuel economy of EVs is significantly greater than HEV. This is because an electric motor is more efficient than an engine.
-
Comparison: Considering the pure electric and Hybrid electric vehicles with the same load conditions, the fuel economy in Miles per Gallon can be used to determine the efficiency criteria. For purely electric vehicles, it is evident from the graph that the efficiency is greater than that of hybrid electric vehicles.
------------------**-------------------------**--------------------------------------**---------------------**----------------