Week-7 Challenge: DC Motor Control
Question1:
1. A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
B. Comment on the armature current shoot-up from the scope results.
C. Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
-----------------
A. Explain a MATLAB demo model named ‘Speed control of a DC motor using BJT H-bridge’.
The Bipolar Junction Transistor (BJT) when used for power-switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between the collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device
let us understand the basic concept of speed control using H bridge configuration.
Most DC motors have two terminals because they are series type (armature and field windings are connected in series) DC motors.
Image showing H-Bridge circuit used for controlling direction of rotation of a DC Motor
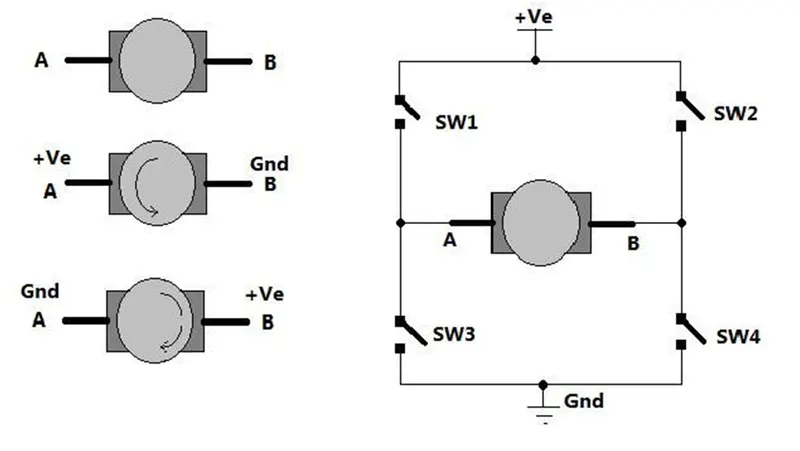
As shown in the figure there are two terminals ‘A’ and ‘B’ of the DC motor. Now if we connect terminal A with +Ve supply and terminal B with –Ve supply or ground the current will flow from the motor from A to B and the motor will rotate in one direction – say clockwise (CW) or forward direction. Now as shown in the second figure we change the supply terminals. Now B is connected with +Ve and A is connected to the ground. The current will flow from the motor from B to A and the motor will rotate in another direction (counter-clockwise – CCW or reverse).
The arrangement to get a reversible supply is shown on the right side of the figure. Four switches are connected between the +Ve supply and ground and the DC motor is connected in between two switches as shown. Such a circuit arrangement is known as an H-bridge because it looks like the letter ‘H’ (H-bridge circuits are most widely used in DC motor drivers). Let us see how it gives reverse supply to the motor.
If SW1 and SW4 are pressed simultaneously then the current will flow from +Ve – SW1 – A – B – SW4 – Gnd. So the motor will rotate in one direction. Open (release) SW1 and SW4 to stop the motor. Now if SW2 and SW3 are pressed current will flow from +Ve – SW2 – B – A – SW3 – Gnd. So the motor gets reverse supply and it will rotate in another direction.(Caution: care has to be taken that SW1 and SW3 or SW2 and SW4 must not be pressed simultaneously otherwise it will short-circuit the supply)
Circuit Diagram of H-Bridge built by transistor for controlling DC motor speed and rotation
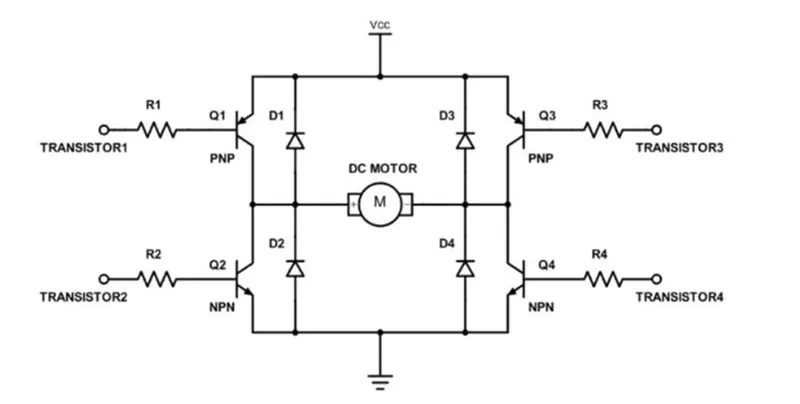
The circuit replaces the switches with NPN-type transistors. Diodes are given for the current to freewheel as the DC motor is an RLE load where the current cannot change direction instantaneously. We all know that a transistor works as a switch. For the NPN transistor if we give enough +Ve input to the base it will turn ON (Saturation region) and if we give 0 input it will be turned OFF (Cut off region). So in this circuit, if Q1 and Q4 are turned ON simultaneously the motor will rotate forward and if Q2 and Q3 are turned ON then the motor will rotate in the reverse direction.
In order to vary the speed of the DC motor, we have to change the voltage applied to the DC motor. This could be achieved with the help of Pulse width modulation
Graph showing Pulse Width Modulation for controlling the speed of DC Motor
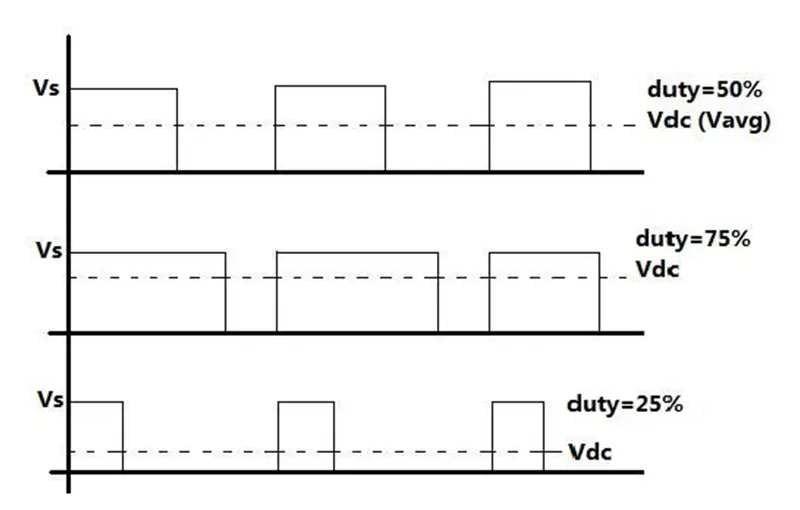
Pulse width modulation means varying the width (duty) of the pulse. Width means ON time Ton of pulse. The average output voltage (Vdc or Vavg) is given by equation
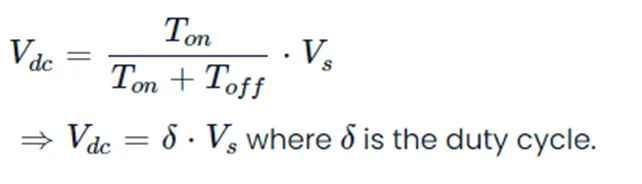
The voltage directly depends upon Ton. As shown in the above figure if duty is 50% the average output voltage Vdc is exactly half of Vs. If duty is increased to 75%, Vdc also increases to 3/4th of Vs and if duty is decreased to 25%, Vdc reduces to 1/4th of Vs. Thus as pulse width varies the average output voltage varies. So we have to apply PWM to the DC motor to vary its speed.
The example below shows the Simulink model of an H-bridge used to generate a chopped voltage and control the speed of a DC motor.
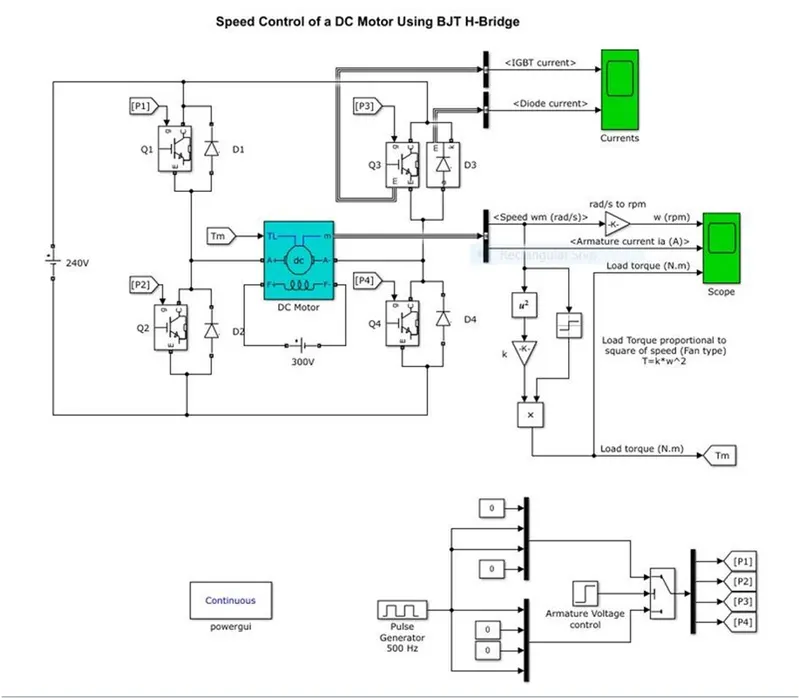
The Bipolar Junction Transistor (BJT) when used for power-switching applications, operates as an IGBT. When it is conducting (BJT operating in the saturated region), a forward voltage Vf is developed between the collector and emitter (in the range of 1 V). Therefore, the IGBT block can be used to model the BJT device
The IGBT block does not simulate the gate current controlling the BJT or IGBT. The switch is controlled by a Simulink® signal (1/0). The DC motor uses the preset model (5 HP 24V 1750 rpm). It simulates a fan-type load (where Load torque is proportional to the square of speed). The armature means voltage can be varied from 0 to 240 V when the duty cycle (specified in the Pulse Generator block) is varied from 0 to 100%.
The H-bridge consists of four BJT/Diode pairs (BJT simulated by IGBT models). Two transistors are switched simultaneously: Q1 and Q4 or Q2 and Q3. When Q1 and Q4 are fired, a positive voltage is applied to the motor, and diodes D2-D3 operate as free-wheeling diodes when Q1 and Q4 are switched off. When Q2 and Q3 are fired, a negative voltage is applied to the motor, and diodes D1-D4 operate as free-wheeling diodes when Q2 and Q3 are switched off.
Note: The DC motor used in the Simulink model is a separately excited DC motor and NOT a DC series motor. That is the reason why a DC voltage of 300V is given to the field windings.
1 (b) : Comment on the armature current shoot-up from the scope results.
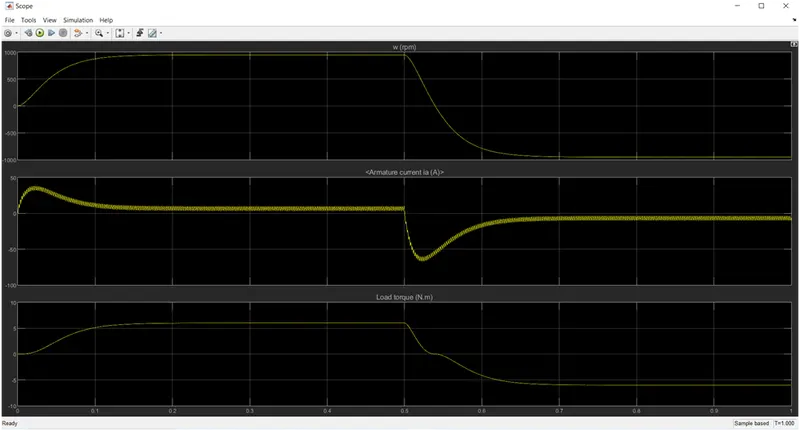
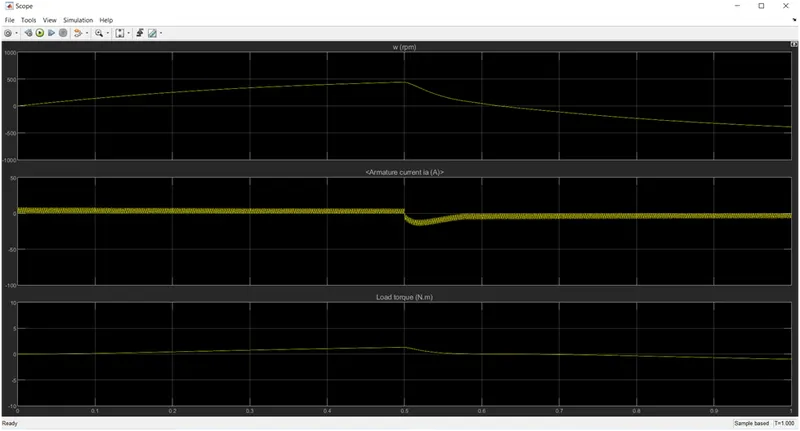
Simulation Output analysis based on pulse width selections:
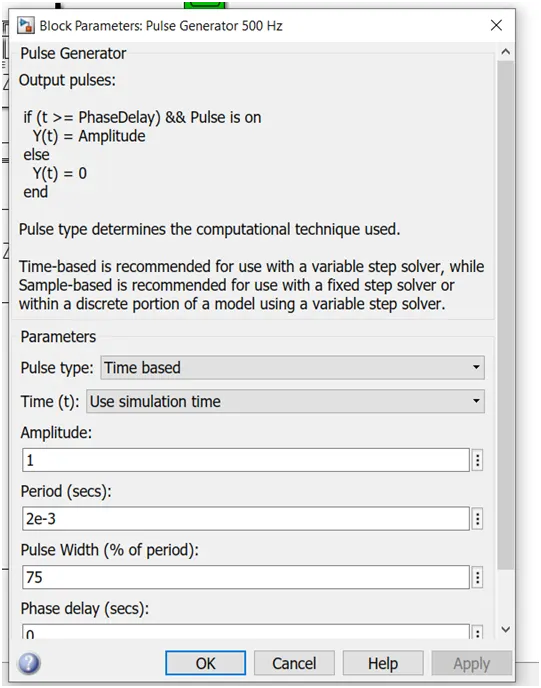
Pulse Generator Parameters:
Period: 2 milliseconds
Pulse Width (% of period) : 75%
2.)
Period: 2 milli seconds
Pulse Width (% of period) : 50%
40%
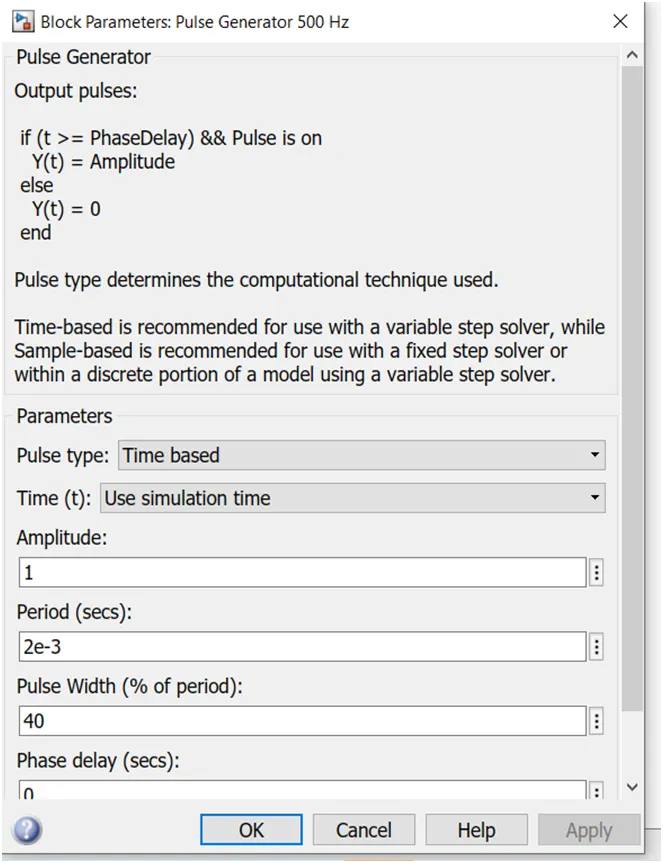
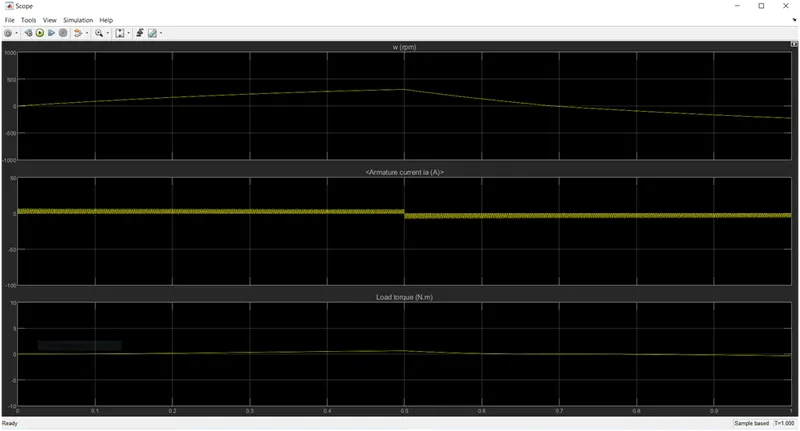
Initially, there is a spike in the armature current. This is because in a DC motor,
Ia=(V−Eb) / Ra
where Ia is the armature current, Vis the supply voltage, Ebis the back emf, and Rais the armature resistance.
At starting, Eb=0 as speed=0 at starting.
Therefore
Ia=V/Ra and Ra is a very small value.
Hence Ia is huge and that reflects in the graph
Therefore when pulse width decreases, the voltage applied across the DC motor decreases and the armature current finally decreases.
In these three plots, the value of this current shoot-up is decreasing and the 3rd plot has an almost smooth current flow.
Conclusion: To get a stable and smoother current flow we need to decrease and control the duty cycle.
----------------------**---------------------------
1.c)Refer to the help section of ‘The Four-Quadrant Chopper DC Drive (DC7) block’. Compare it with the H-bridge model.
The Four-Quadrant Chopper DC Drive (DC7) block represents a four-quadrant, DC-supplied, chopper (or DC-DC PWM converter) drive for DC motors. This drive features closed-loop speed control with the four-quadrant operation. The speed control loop outputs the reference armature current of the machine. Using a PI current controller, the chopper duty cycle corresponding to the commanded armature current is derived. This duty cycle is then compared with a sawtooth carrier signal to obtain the required PWM signals for the chopper.
The Four-Quadrant Chopper DC Drive block uses these blocks from the Electric Drives/Fundamental Drive Blocks library:
In matlab help section DC-7 four quadrant chopper 200 HP DC drive and we get this model.
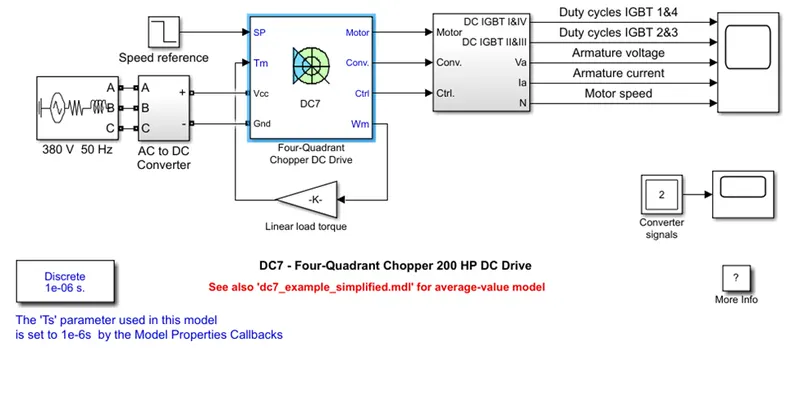
In above four quadrant chopper DC drive DC7 block model, 3 phase voltage source and AC to DC converter rectifier bridge and braking chopper are added to four quadrant dc chopper dc7 block. The armature voltage is provided by IGBT converter controlled by two PI regulators.
Now from this model, we discuss only four quadrant chopper DC chopper which image is below show
Speed Controller (DC)
Regulation Switch
Current Controller (DC)
Chopper
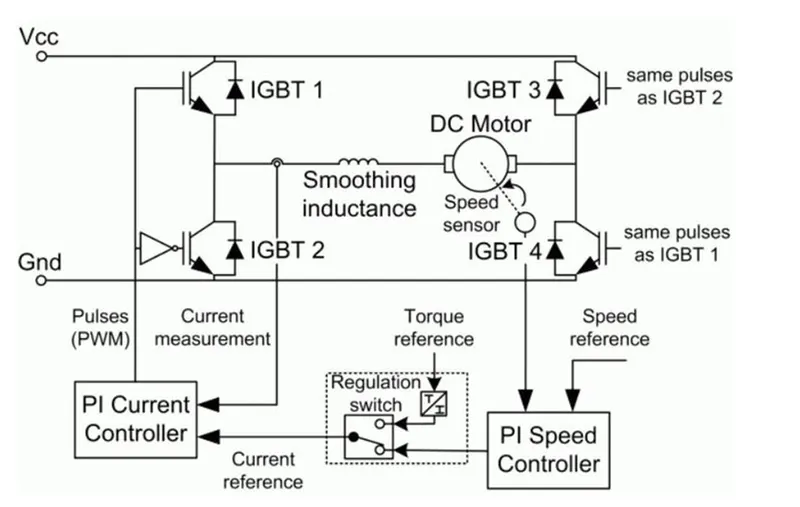
The above figure shows the schematic of the 4-quadrant chopper DC drive.
The four quadrant operation:-
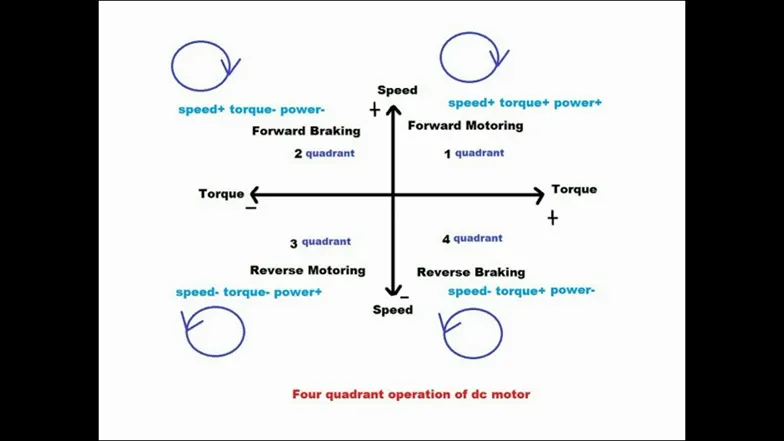
Quadrant 1 (forward motoring)
CH1 turned on
When the CH 1 is turned on, CH1 and CH4 conduct and output voltage v0 and output current i. these both are positive and power flow source to load, the inductor store the energy and the motor rotate in a forward direction so it’s called forward motoring.
CH 1 turned off
When the CH1 is turned off , CH4 and D2 conduct, positive current free whiling through CH4 and D2 motor rotate forward direction and output voltage zero and output current is i. these value of current is positive and inductor releases the energy.
Quadrant 2(forward regenerative braking)
CH2 turned on
Assume that motor running in forward direction. Here CH2 is operated so CH2 and D4 is conduct, output voltage is v0 and current is in negative directive which produce Eb. This behaves like generator and inductor store energy.
CH2 turned off
CH2 is off then D1 and D4 is conduct so voltage v0 positive and current is negative and inductor release energy which is flow load to source direction and power fed from load so this is called forward regenative braking.
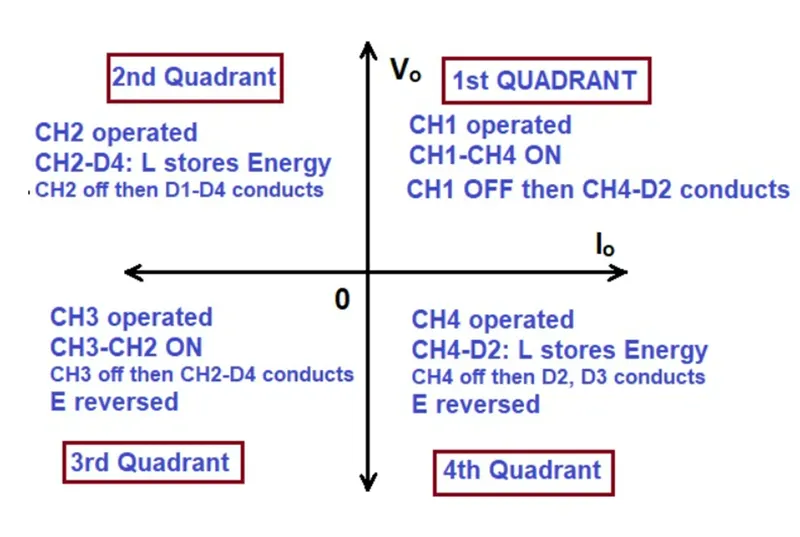
Quadrant 3(reverse motoring)
CH3 turned on
Polarity od back efm is must be in reverse. Here CH3 is on so CH3 and CH2 is conduct output voltage is negative and current is negative, power is flow source to load and inductor is store energy and motor rotate in reverse direction so we called reverse motoring.
Ch3 turned off
CH3 is turned off so CH2 and D4 is conduct and negative current free whiling through CH2 and D4. Current is negative and voltage is zero, inductor is release energy and motor still running in negative direction.
Quadrant 4 (reverse regenerative braking)
CH4 turned on
The polarity of the back emf must be in reverse. Let us assume that the motor rotate reverse direction. CH4 is operated, CH4 and D2 is conducted, the output voltage is zero and the current is positive so Eb is positive. So that machine behaves generator and inductor store the energy.
CH4 turned off
When CH4 is turned off then D2 and D3 is conducted. Load voltage is negative but current is positive and power fed back to the source. So that is called as reverse regenerative braking.
Comparison of four quadrant chopper Vs H- bridge model
- Four quadrant chopper can operate in four quadrant forward motoring, reverse motoring, forward regenerative braking, reverse regenerative braking.where H- bridge model is operate only in two quadrant forward motoring and reverse motoring.
- Four quadrant chopper can regenerative braking features are available where H-bridge model does not allow this feature.
- Higher efficiency in four quadrant chopper compare to H-bridge and less maintenance required in four quadrant chopper.
- Four quadrant chopper is used in numerous applications in power switching devices and electronic devices where H-bridge circuit is mostly used in robotics applications for DC motor reverse and forward directions.
---------------------- ** ----------------------------------------
Qn. 2)Develop a 2-quadrant chopper using simulink & explain the working of the same with the relevant results;(Refer to article - Multiquadrant operation of motor)
Type C chopper or Two Quadrant class A chopper:
Class-C or Type-C Chopper is a category of the chopper that can operate in the first as well as second quadrants. This basically means that the power can either flow from source to load or load to source in this chopper. This kind of chopper is also known as a Two Quadrant Class-A chopper
Operation or Working of Class-C or type C:
As we know, a Class A and Class B chopper operates in the first and second quadrants respectively. Therefore, if we connect both these types of the chopper in parallel then it is possible to have chopper operation in the first as well as second quadrants. In fact, Class-C or Type-C chopper is obtained by the parallel connection of the Class-A and Class-B chopper. The figure below shows the circuit diagram of this type of chopper.
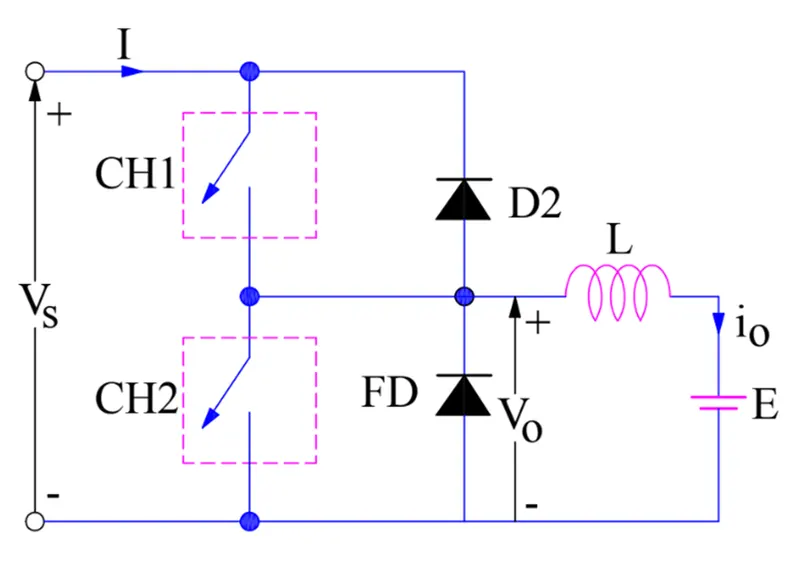
We can notice that chopper CH1, free-wheeling diode (FD), and load are forming Class-A Chopper whereas chopper CH2, D2, and Load are forming Class-B chopper. Both these choppers are connected in parallel. To obtain the first quadrant operation we should switch ON chopper CH1 and for getting the second quadrant operation we should switch ON chopper CH2.
Case 1: When CH1 is switched ON/OFF
When chopper CH1 is switched ON, source Vs directly gets connected to the load and hence, load voltage Vo is equal to source voltage. The direction of load current is from source to load as shown in the circuit diagram which is assumed positive.
When CH1 is switched OFF, the free-wheeling diode FD comes into the circuit as it gets forward biased and hence shorts the load. Therefore, the output voltage Vo becomes zero. However, the io continues to die down through the FD and L in the same direction as shown in the circuit diagram. Thus, the average output voltage Vo and current Io are positive and hence the operation of the chopper is in the first quadrant.
--
Case 2: When CH2 is switched ON/OFF
When chopper CH2 is switched ON, load DC source E drives current through CH2 and load. The direction of this current io will be opposite to that shown in the circuit diagram and hence is assumed negative. Output voltage Vo is zero during this time. When CH2 is made OFF, diode D2 gets forward biased, and hence the current into the source from the load. The output voltage is Vs at this time as the load is connected to the source through D2 during the OFF time of chopper CH2. Thus, the load current is always negative i.e. operation of the chopper is within the second quadrant.
The average load voltage is always positive but the average load current may be positive or negative. Therefore, power flow may be from the source to load (first quadrant operation) or load to the source (second quadrant operation). The operating region of the Class-C or Type-C chopper is shown below by hatched area
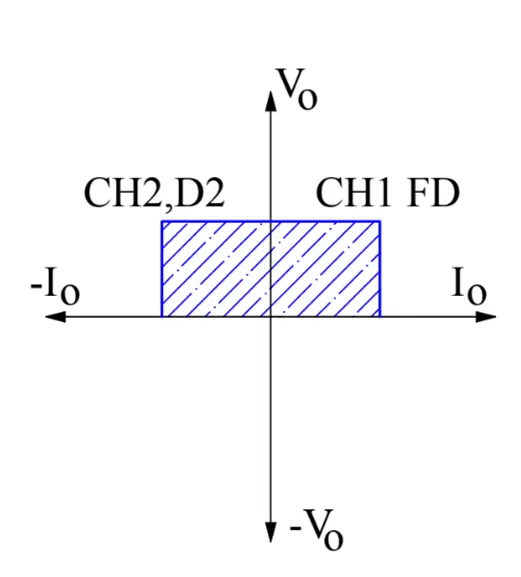
CAUTION: Choppers CH1 and CH2 should not be ON simultaneously as this would lead to a direct short circuit on the supply lines.
Application: Class-C or Type-C choppers are used for motoring and regenerative braking of DC Motors
Realization using Simulink
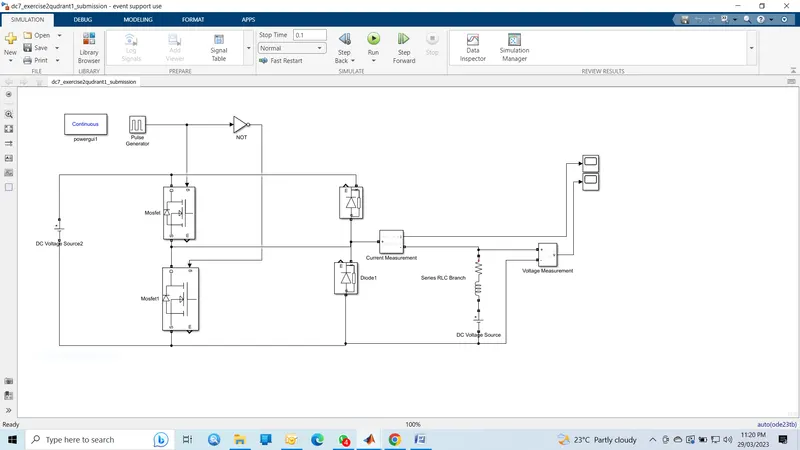
Hence, the Simulink model corresponding to the circuit diagram is built using basic Simulink blocks. The pulse generator is used with the NOT gate to prevent misfiring of the MOSFETs so that they do not conduct at the same time which results in a short circuit.
Pulse generator Parameters:
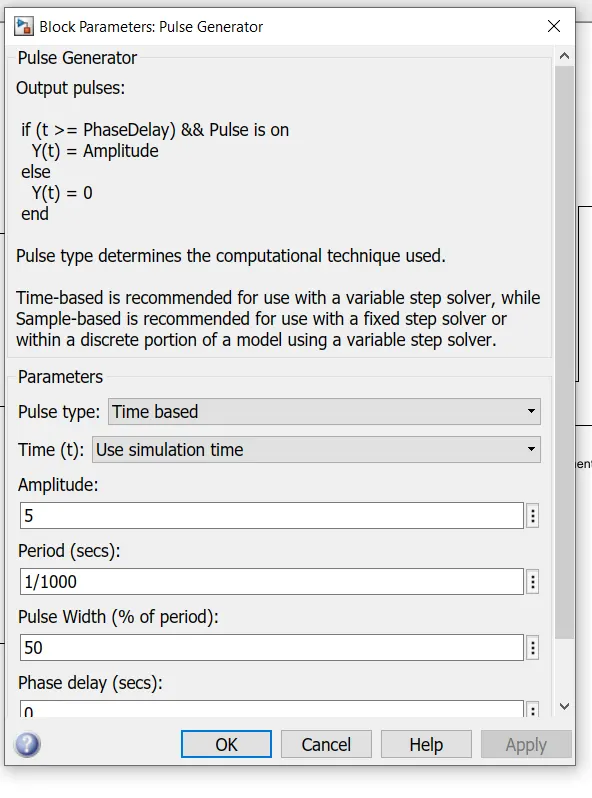
An amplitude of 5 is chosen so that we could see the pulses clearly.
DC Voltage Source Parameters:
Source side: 24V
Load side: 12V
Simulink Output:
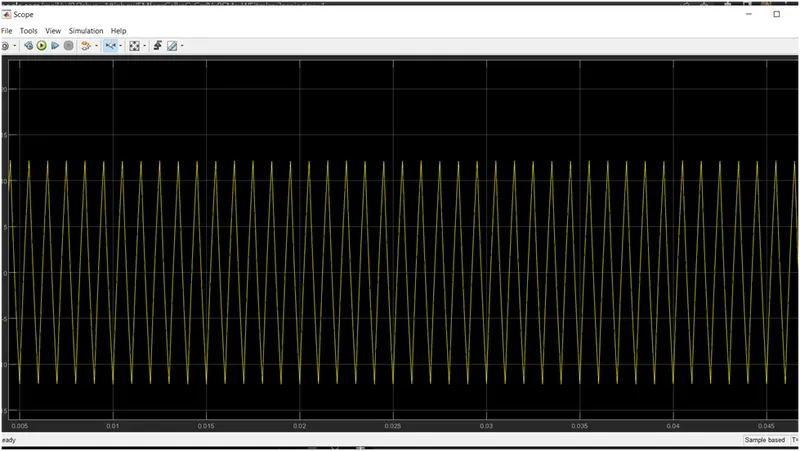
current:
current flow: on both directions
voltage :
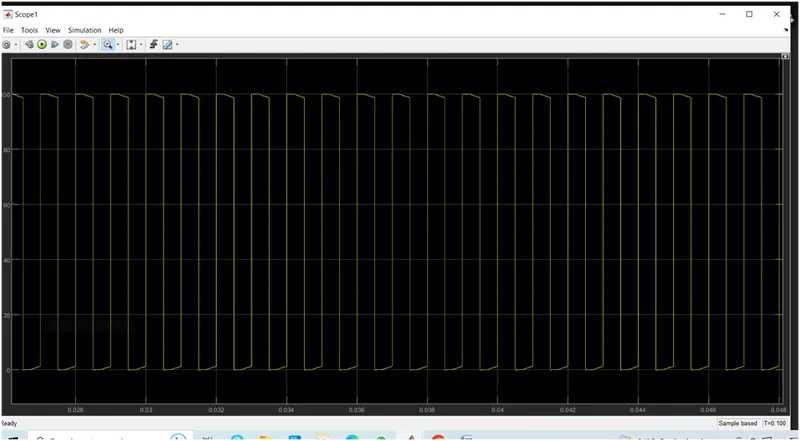
voltage remains positive only .
Hence, we could see clearly that the voltage is always positive but the current becomes both positive and negative. Hence, the Type C chopper is simulated and verified.
-------------------**-----------------------------**-------------
Qn.3)Explain in a brief about the operation of the BLDC motor.
Brushless DC electric motors are also known as electronically commutated motors (ECMs, EC motors). Primary efficiency is the most important feature for BLDC motors. Because the rotor is the sole bearer of the magnets and it doesn’t require any power. i.e. no connections, no commutator, and no brushes. In place of these, the motor employs control circuitry. To detect where the rotor is at certain times, BLDC motors employ controllers, rotary encoders or a Hall sensor.
Construction:
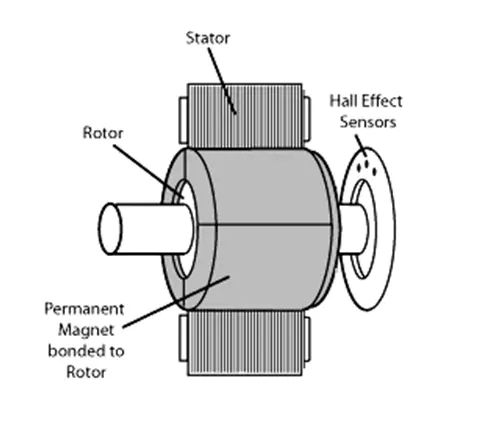
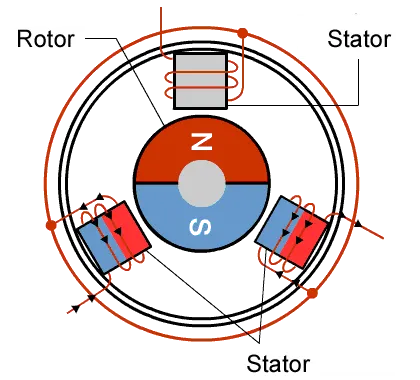
In this motor, the permanent magnets attached to the rotor. The current-carrying conductors or armature windings are located on the stator. They use electrical commutation to convert electrical energy into mechanical energy. The main design difference between brushed and brushless motors is the replacement of the mechanical commutator with an electric switch circuit. A BLDC Motor is a type of synchronous motor in the sense that the magnetic field generated by the stator and the rotor revolve at the same frequency.
The brushless motor does not have any current-carrying commutators. The field inside a brushless motor is switched through an amplifier which is triggered by the commutating device like an optical encoder
Working:
BLDC motor works on a principle similar to that of a Brushed DC motor. The Lorentz force law which states that whenever a current-carrying conductor is placed in a magnetic field it experiences a force. As a consequence of reaction force, the magnet will experience an equal and opposite force. In the BLDC motor, the current-carrying conductor is stationary and the permanent magnet is moving.
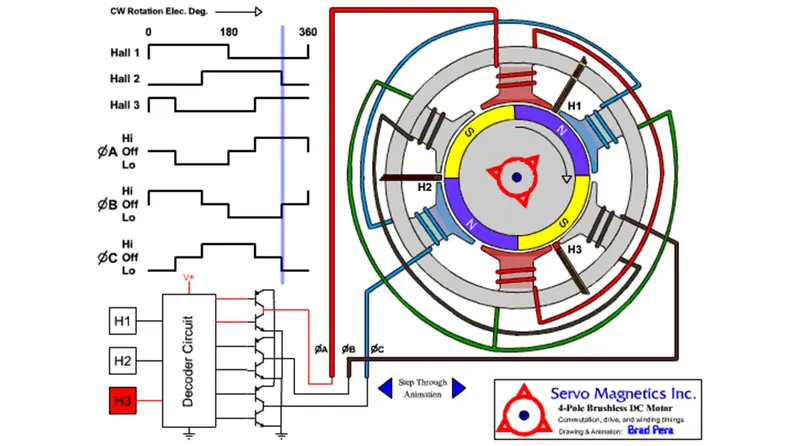
When the stator coils get a supply from the source, it becomes an electromagnet and starts producing the uniform field in the air gap. Though the source of supply is DC, switching makes to generate an AC voltage waveform with a trapezoidal shape. Due to the force of interaction between the electromagnet stator and permanent magnet rotor, the rotor continues to rotate.
With the switching of windings as High and Low signals, corresponding winding energized as North and South poles. The permanent magnet rotor with North and South poles aligns with the stator poles which causes the motor to rotate.
Advantages of BLDC motor:-
BLDC motors give a high power-to-weight ratio.
We can have control on torque and speed -- instantaneous control.
We get high efficiency, low maintenance because of brushless, high speed.
--------------------------------*** -----------------------------------**---------------------------------