Week-4 Challenge WOT Condition Part-2
- What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Mapped Model : The Model is known as mapped mode when it works with the pre-defined data i.;e, in the foam of lookup tables
To implement mapped mode we have to specify the electrical torque with a torque- speed or max.motor power –torque.Also it have specify the electrical losses as a single operating point which estimate loss across the operating range measured loss or measure efficiency.
Battvolt & Mtrspd & TrqCmd : Provide an Input port for subsystem or model.
Info & BattCurr & MtrTrq : Provide an Output for the subsystem or model.
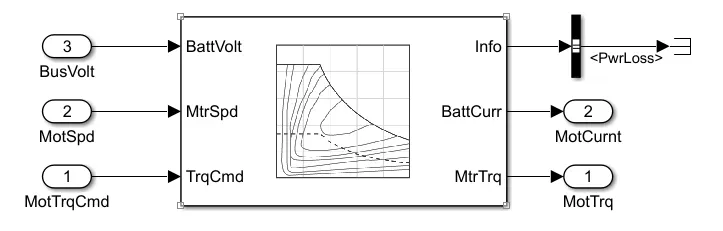
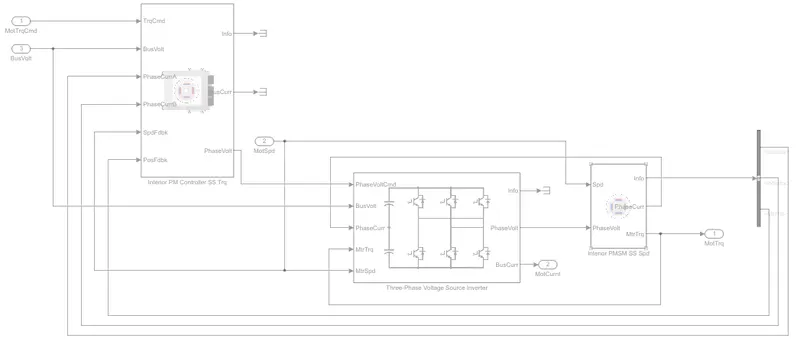
Dynamic models are those model which response is related to the components.these components are Inveerter, phase controller, feedback circuits.
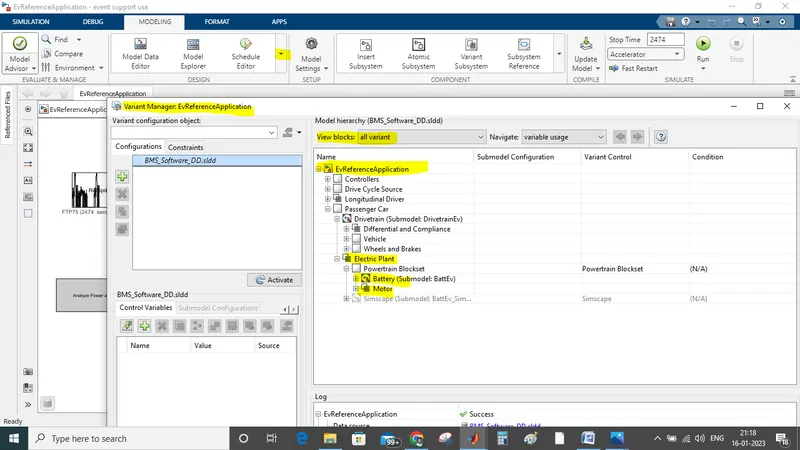
change model type
Modelling > (view block) all variant > select the model accordingly.
2.How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
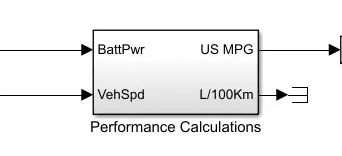
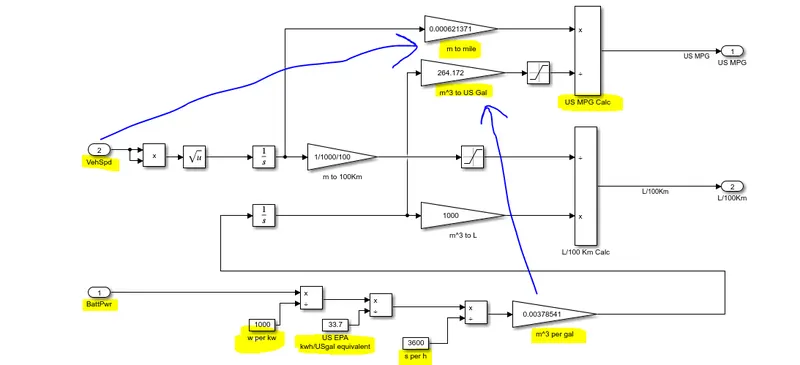
- vehicle speed data : calculate the traveled distance in meters then converted it is to miles.
- Battery power data : find power used in kWh then it is converted to gasoline-equivalent using US EPA value by dividing with 33.7 As per EPA 1 gallon of gasoline is equal to 33.7 kWh
- Dividing distance traveled in miles by the number of gallons, we can get miles per gallon.
- In HEV this gallon(gasoline equivalent of battery power) is added with gallon used by IC engine then calculation of miles per gallon can be done.
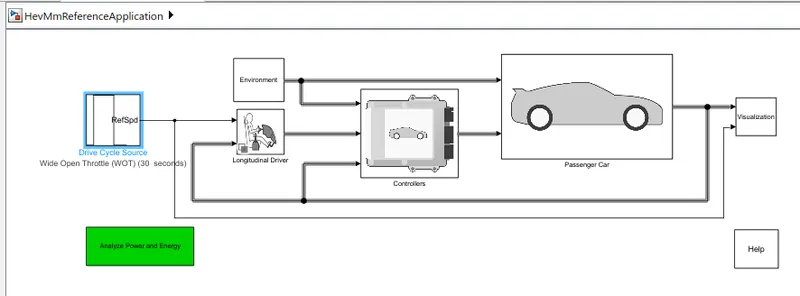
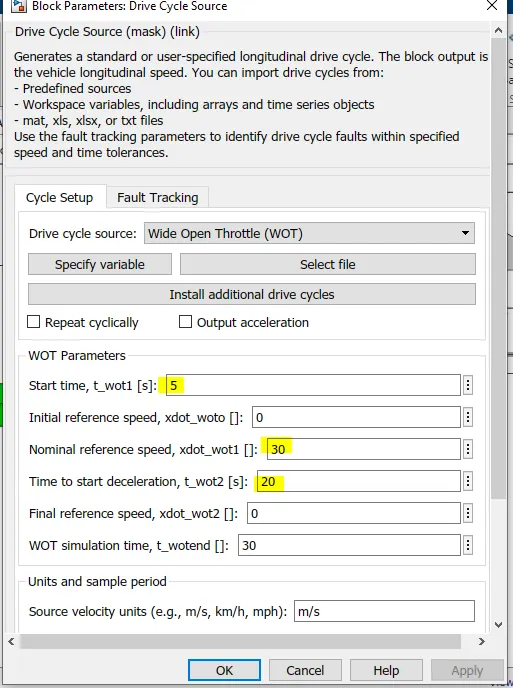
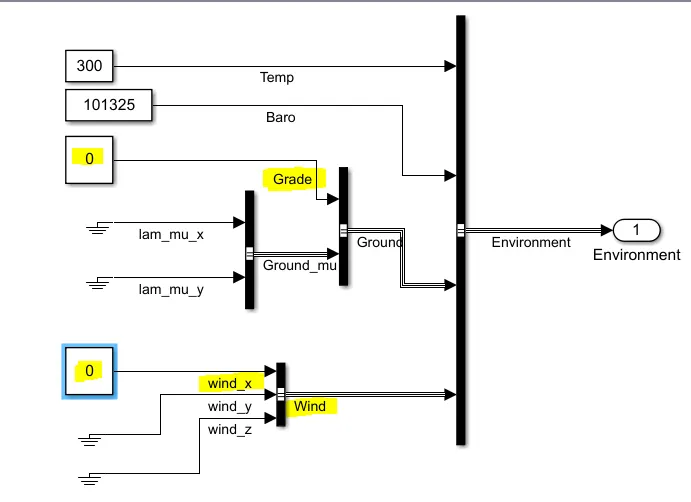
3. Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results
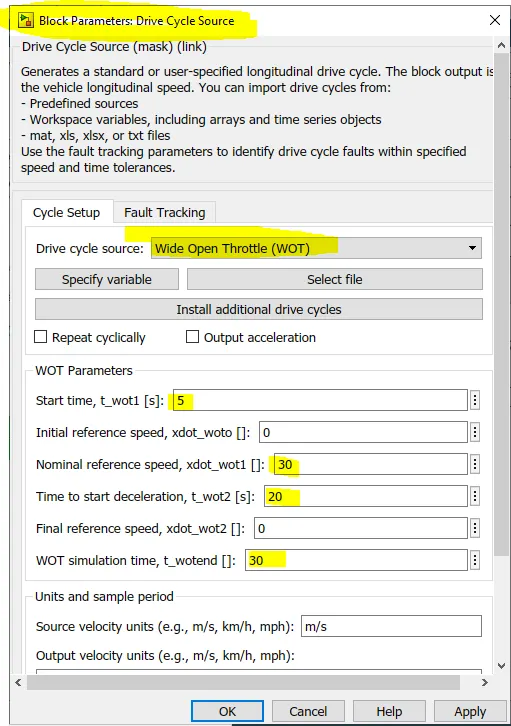
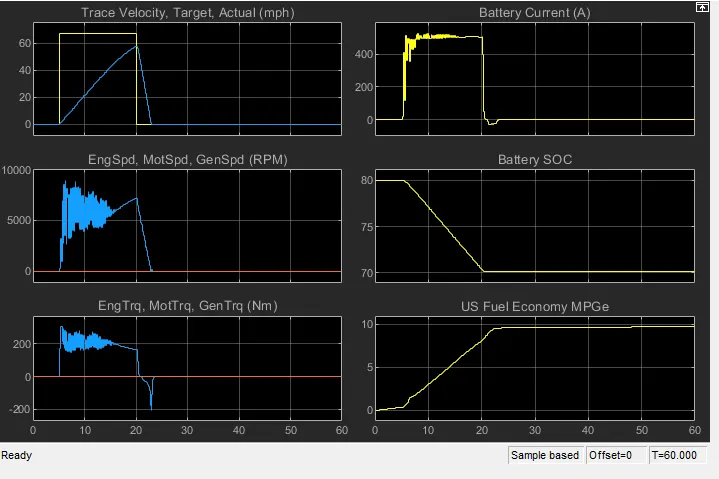
Initally
Grade=0 & Wind = 0
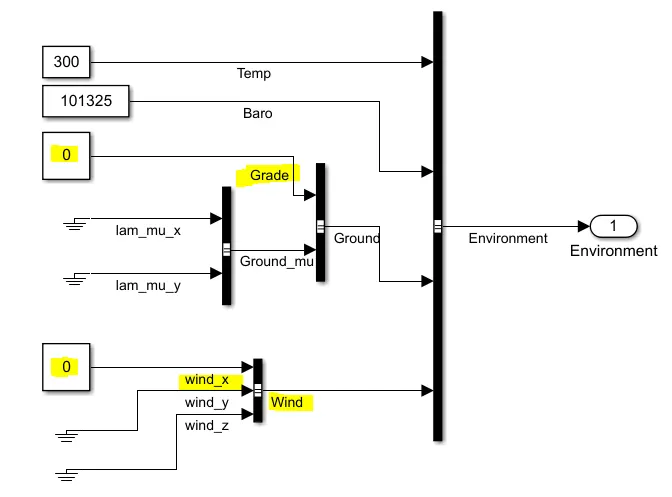
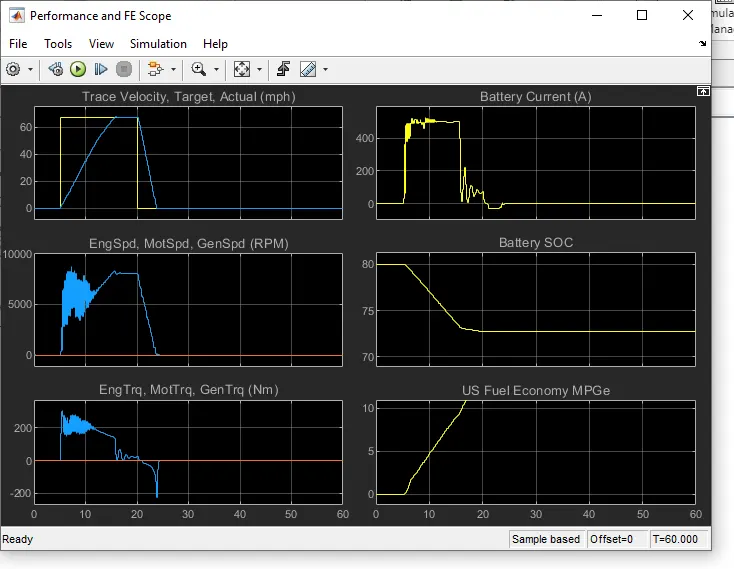
Grade= 7 & wind = 10m/s
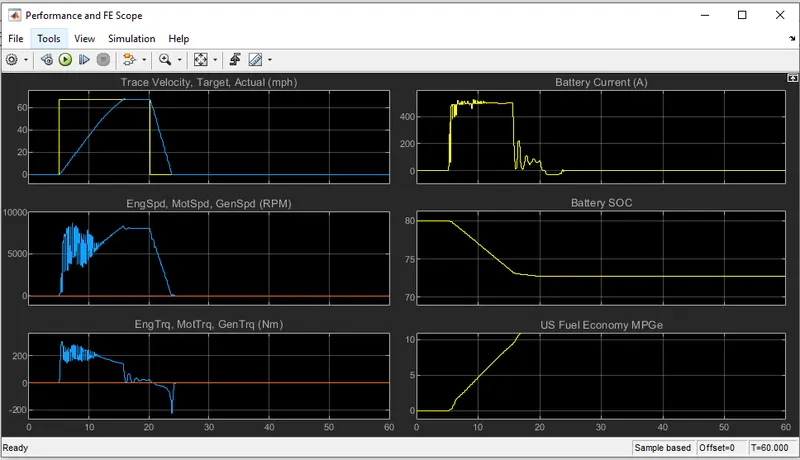
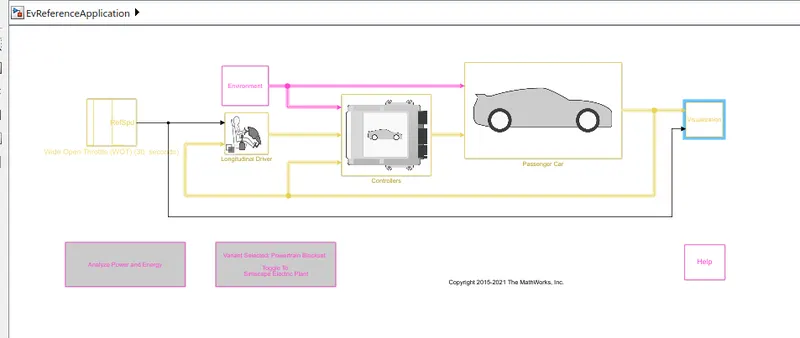
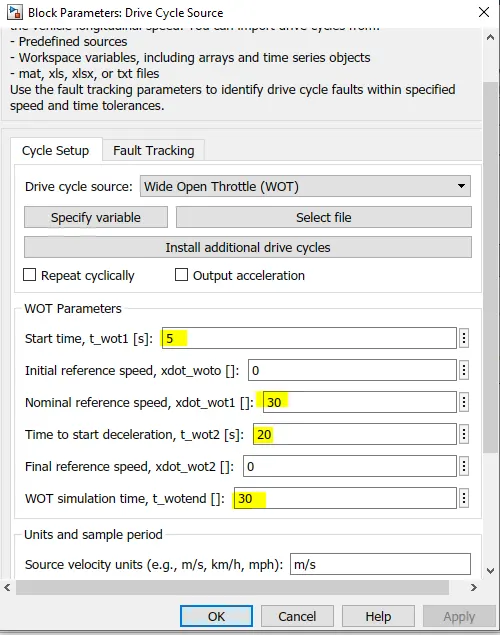
4.Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
Pure Electric Powertrains
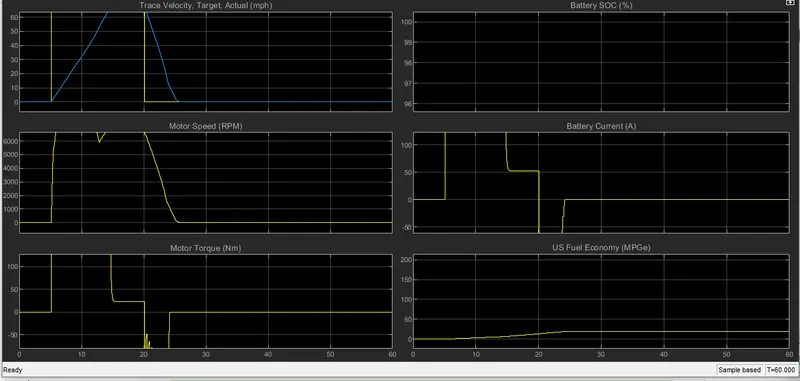
Time for the peak velocity is less for HEV as compared to EV