Week-4 Challenge WOT Condition Part-2
Aim:
- To study about the powertrain block set which includes full EV reference and HEV reference applications.
- We will also be changing the parameters and also studying how the basic calculations are performed.
Objective:
- What is the difference between the mapped and dynamic model of engine, motor and generator? How can you change model type?
- How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
- Run the HEV Reference Application with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
- Keeping all other parameters the same, compare the simulated results of hybrid and pure electric powertrains.
Theory:
Wide Open Throttle (WOT)
- Wide-open throttle (WOT) refers to an internal combustion engine's maximum intake of air and fuel that occurs when the throttle plates inside the carburetor or throttle body are "wide open", providing the least resistance to the incoming air.[1] In the case of an automobile, WOT is when the accelerator is depressed fully, sometimes referred to as "flooring it."
- In the case of a diesel engine, which does not have a throttle valve, WOT is the point at which the maximum amount of fuel is being injected relative to the amount of air pumped by the engine, generally in order to bring the fuel-air mixture up to the stoichiometric point. If any more fuel were to be injected then black smoke would result.
- At wide-open throttle, manifold vacuum decreases. The higher manifold pressure in turn allows more air to enter the combustion cylinders, and thus additional fuel is required to balance the combustion reaction. The additional air and fuel reacting together produce more power.
MODEL 1:
Difference between the mapped and dynamic model of engine, motor, and generator:
- Mapped model of engine, motor and generator represent macro behavior as a set of lookup tables (motor speed, power torque, brake torque, air mass flow, fuel flow, exhaust temperature, efficiency and emissions). In these tables we already have assigned values as it has a real time block i.e. a mapped motor lookup table in this can map the available motor data.
- A dynamic model of engine, motor, and generator is an actual model that shows the real components in which it is manually fed and has sample rates less than 1 second. Power electronics simulations are mostly performed dynamically. It is used to perform subsystem transient simulation for more detailed experiment i.e. in this we have an actual PM controller and 3 phase voltage source inverter.
- The mapped model takes less time than dynamic as it is less detailed and has a working range of 1 second.
Changing of model type:
- To change the model type we must enter into the corresponding block and then we must double click on the passenger car block.
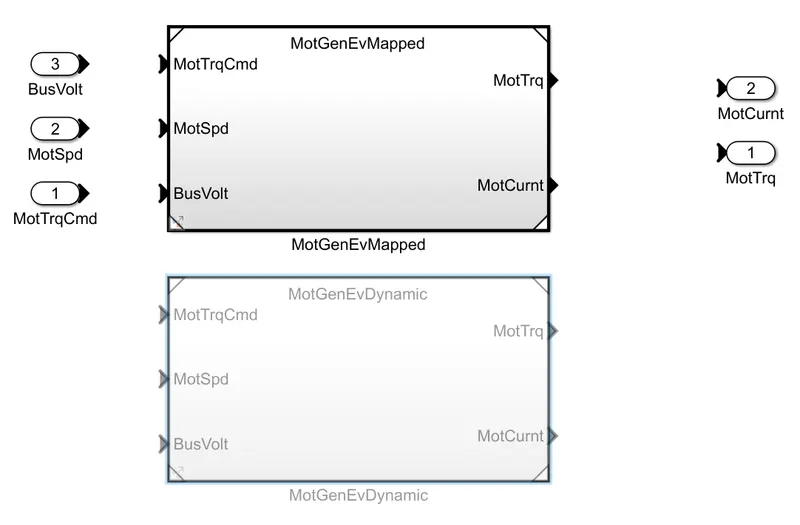
- Click on the Modelling tab and in that click on Model explorer.
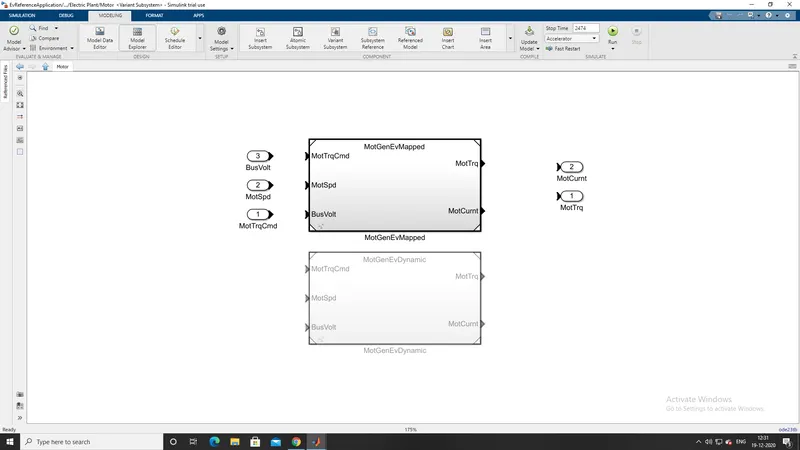
- Click on the Modelling tab and in that click on Model Explorer. Once you click on that you will see the below window.
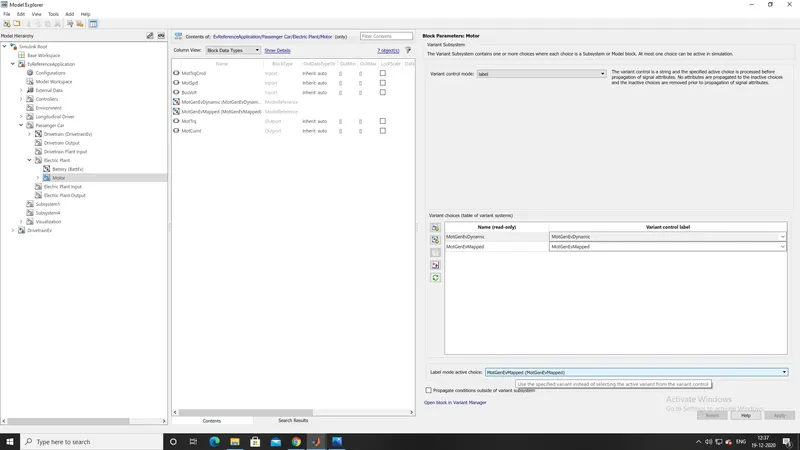
- You can see that the mapped model is loaded ie it is in Active choice. So click on the marked space and select the Dynamis motor.
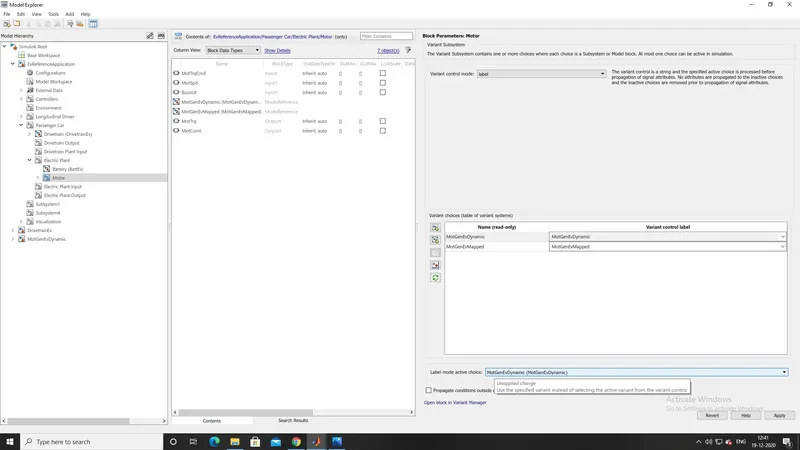
- Once you change the model to Dynamic motor click on Apply.
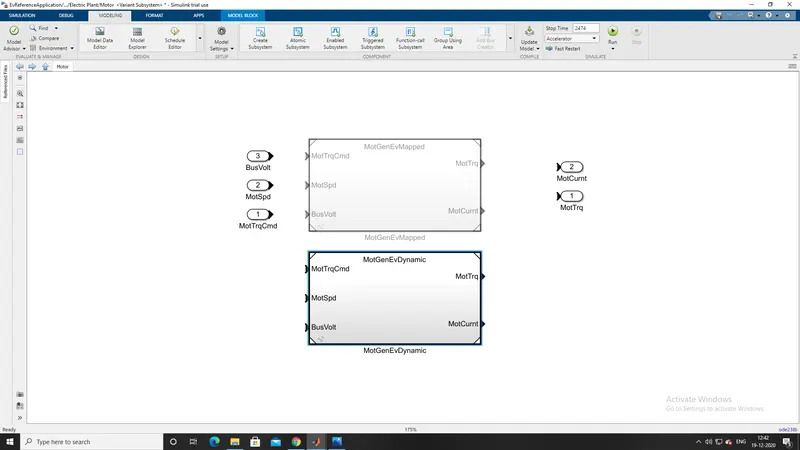
- You can see that once you click apply the Dynamic Model is Active.
Model 2:
- In order to study about how the model calculates the miles per gallon, we must first enter the corresponding block which is done by first clicking the visualization block.
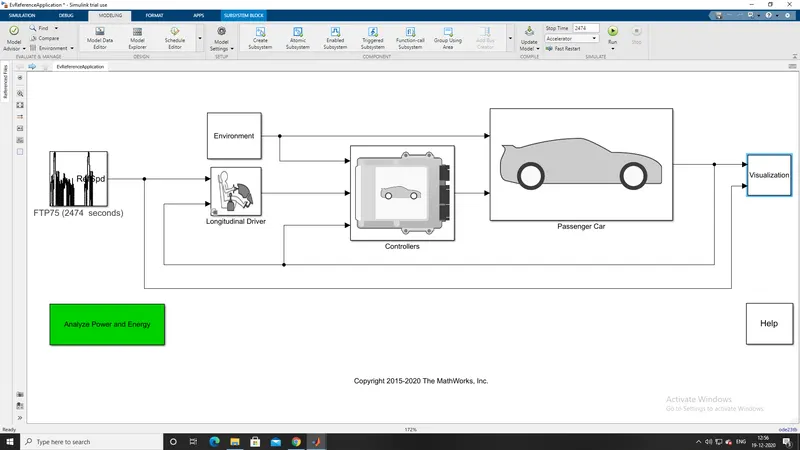
- And then entering the performance calculations block we can see the detailed calculations.
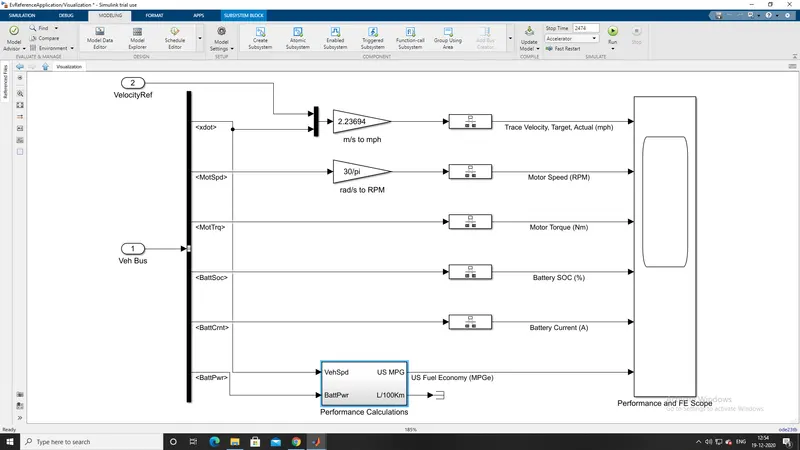
- You can see that we are calculating the Mileage in Miles per gallon and the other mileage unit liters per 100-kilo meter is terminated.
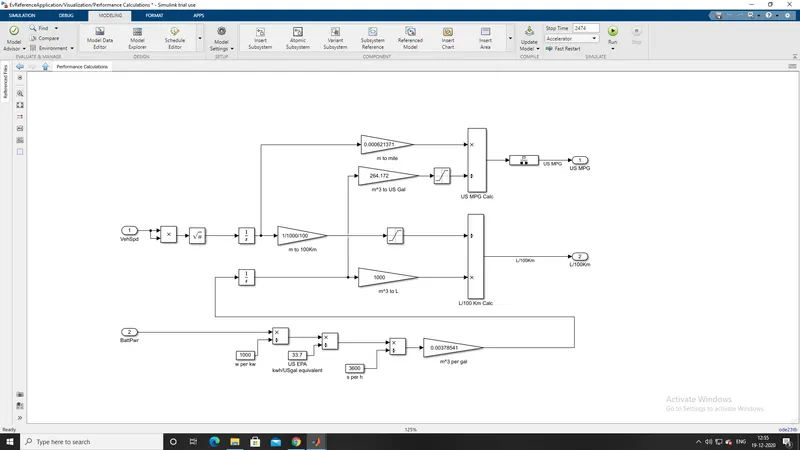
- First, we need to convert the Battery power(w) to Gallon. So first we will be converting the Watt to kilowatt so we will be dividing it by 1000. To convert the Kw to gallon we will be dividing it by 33.7.
- To Convert gallon/hr to gallon/s it is divided by 3600. This value is further multiplied by 0.00378541 to convert gallon to m3.(1gallon=0.0037L).
- Fuel from the Engine will come in the same unit m3/s and will be added with the battery power then it is integrated with respect to time to get m3 volume of fluid. This is then multiplied with 264.172 to convert to Gallon.
- In order to find the distance traveled we will be using the velocity input and will be squaring and finding the square root to avoid negative numbers. Then this value will be integrated to find the distance.
- This distance will be in m so we will be multiplying it with 0.0006213 to convert to the mile.
- Now the results from mile and gallon will be divided to give the result mile per gallon.
Factors affecting fuel flow are :The rate at which we accelerate and decelerate.
- The speed at which we travel.
- The distance we want to cover.
- The grade of the slope we travel and the load the vehicle is carrying.
- The environmental conditions like temperature, wind velocity etc.
MODEL 3&4:
- To elaborate on the results of the Hev and Ev vehicle first we will be running the HEV vehicle simulation at WOT without any change in grade and Air velocity.
- HEV vehicle simulations with no change in Wind velocity and Grade.
- You can see that all are default values.
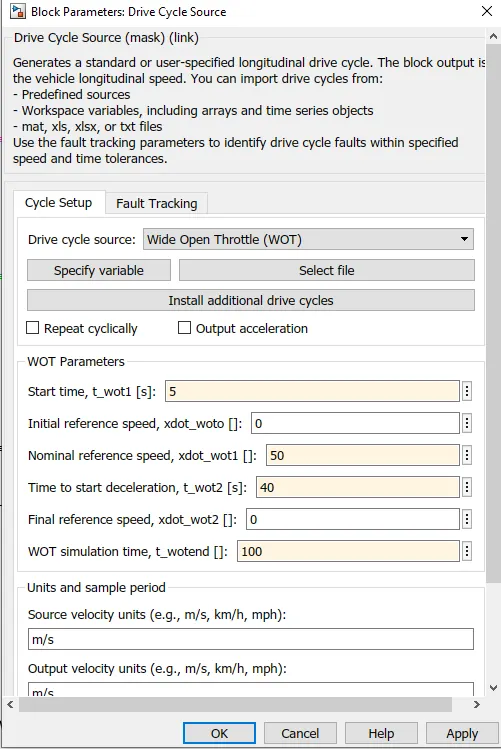
- Change the Drive cycle you want to run for this case we will be using a WOT cycle. We can provide the Initial reference speed, Time to deceleration, and WOT simulation time.
Graph-1(All default value without any change in wind and grade)
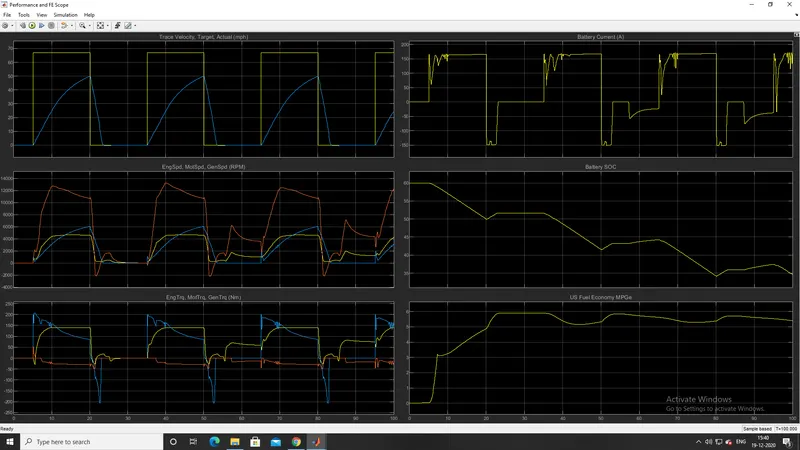
Now I will be introducing wind velocity and grade and will be comparing both the results for the HEV simulation.
Graph-2 :(Including a Velocity of wind and Grade for HEV)
- Wind velocity=10
- Grade=12
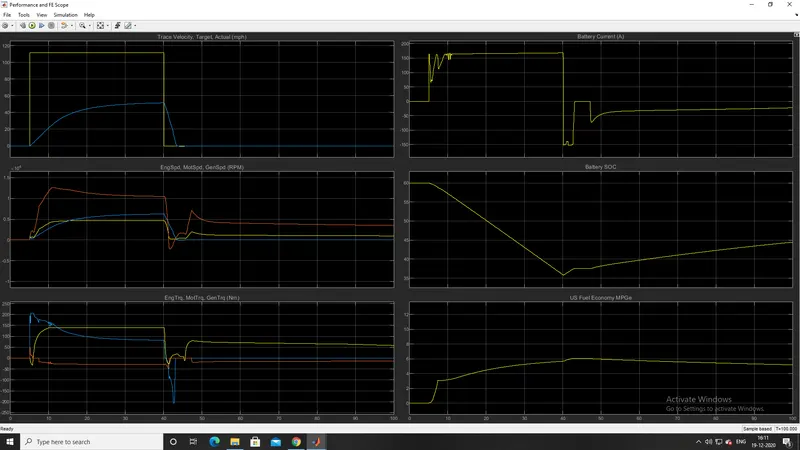
From the two graphs, we can see that the Battery Soc and current is similar in both cases but the Fuel economy of the second case is less compared to the first case this is because more fuel will be consumed when you go on a slope with an opposing wind velocity.
Also, the Trace velocity achieved in the first case is more compared to the second case. For both cases when the vehicle attains maximum velocity, the battery SOC decreases to 65% after which the battery starts to recharge.
Now we will be running the same simulation for the EV vehicle with a Wind velocity of 10 and a grade of 12.
Graph-3:
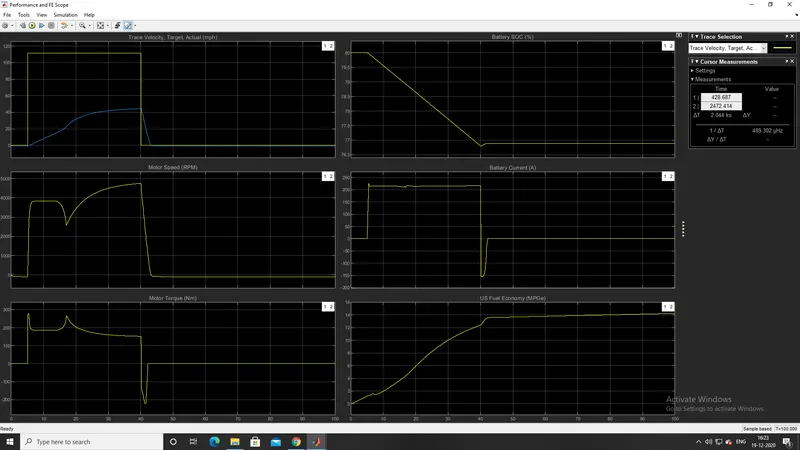
- We can see from both the graphs that the velocity acquired by the HEV is more than that of the Electric vehicle.
- Also since the Ev vehicle is completely based on battery the Soc of the EV vehicle is better at the end compared to the HEV.
- The motor speed in the Hev is better than of the electric vehicle this may be because the motor will have considerable help from the engine.
- We can also see that the fuel economy of the Electric vehicle is more than that of the Hybrid vehicle.
- The difference between mapped and dynamic mode was discussed and the steps to changed the model type was discussed.
- The calculation of vehicle speed and battery to miles per gallon was explained and the factors considered to model fuel flow was discussed.
- The HEV reference application was simulated by changing the drive cycle source and changing the parameters of grade and wind velocity and the plots were discussed.
- Comparison was done for the change HEV and EV reference application and the plots were discussed.