Week-4 Challenge WOT Condition Part-2
1)
Mapped models:
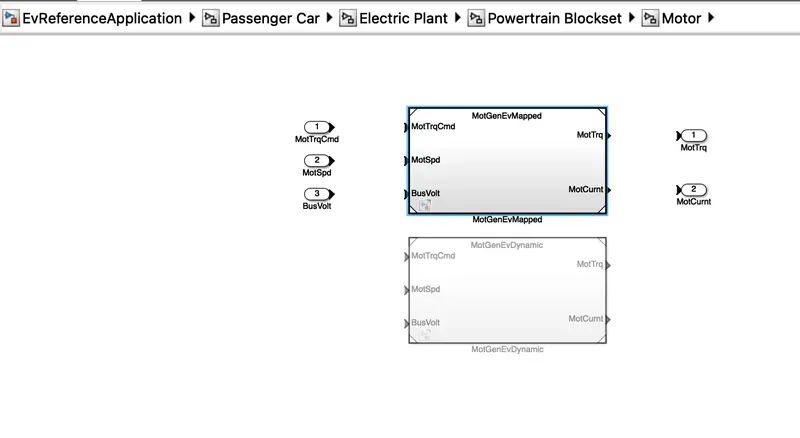
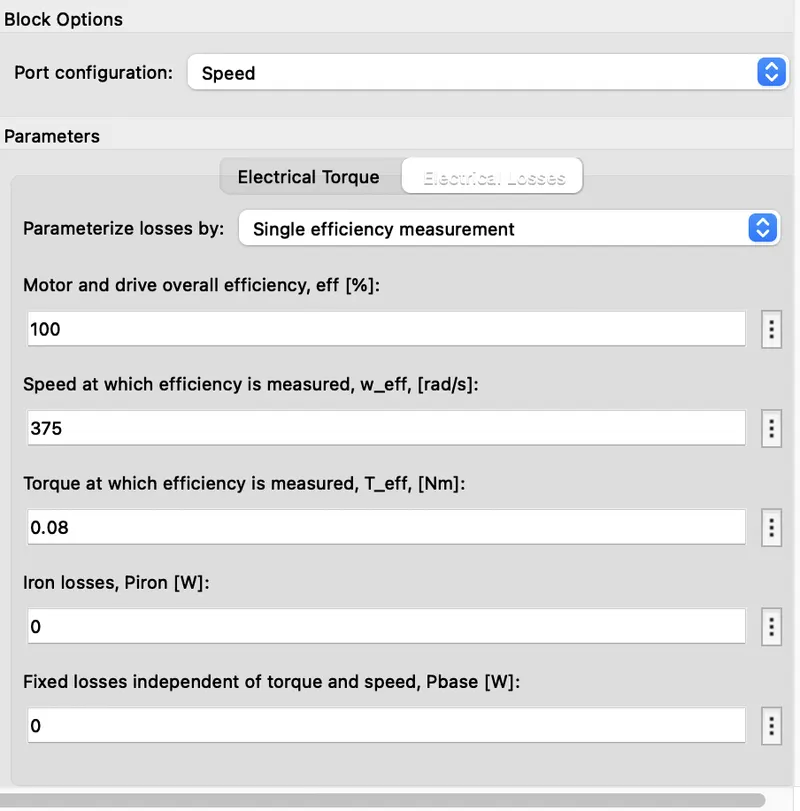
Mapped models are those type of models that comes into use when the behavior of a certain type of model is not of our interest or is not required to redesign and can be modeled with predefined values in the form of lookup tables. The Mapped Models such as motor, engine and generator give us an ease to use these parts for simulation just by saving some of the specific values manually or by providing it as an input from the system itself that will serve as the input values of the models.
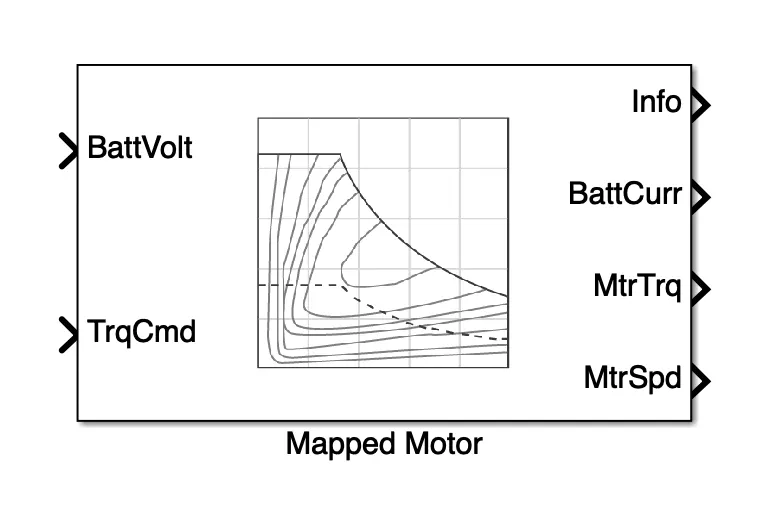
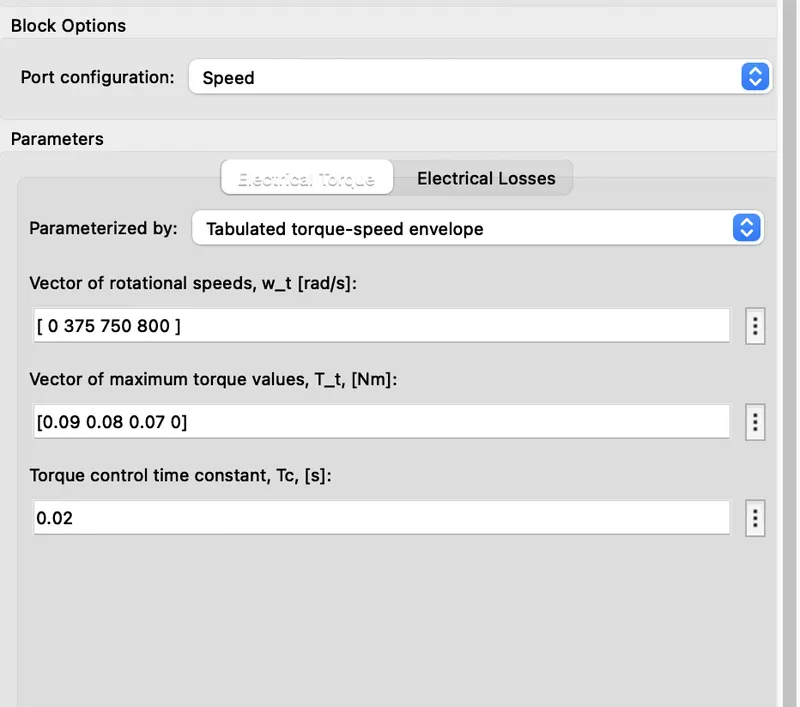
For Example here in mapped motor the input are asked for the Battery input voltage and the Torque required for the particular simulation. Also we can see the values to fed for the model is Rotational Speeds, Maximum Torque, efficiency, speed at particular efficiency, etc.. These models are helpful as they are ready to use maodels for simulation.
Dynamic Models :
The dynamic model uses real-time input/output from all the sub-systems.
This is a better model system than mapped because the system is more deep and descriptive. This gives the user to analyze point by point.
Due to the elaborate and descriptive nature of the dynamic system, hence takes more time to simulate as compared to the mapped model.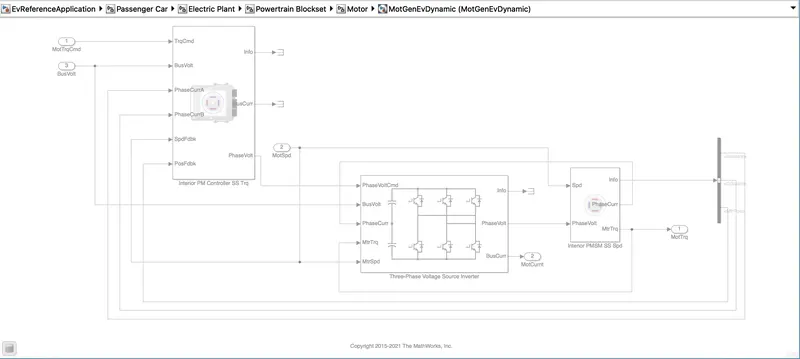
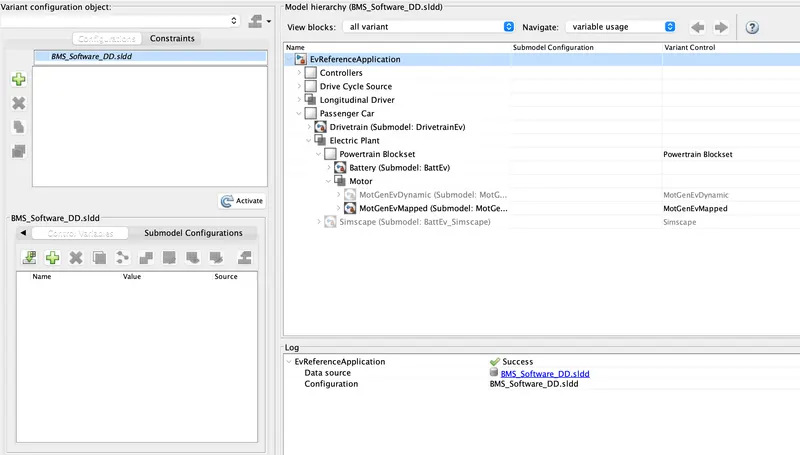
Changing the model type of EV model powertrain blocks
By using the variant manager in the modeling tab, and by selecting mapped or dynamic models.
___________________________________________________________________________________
2)
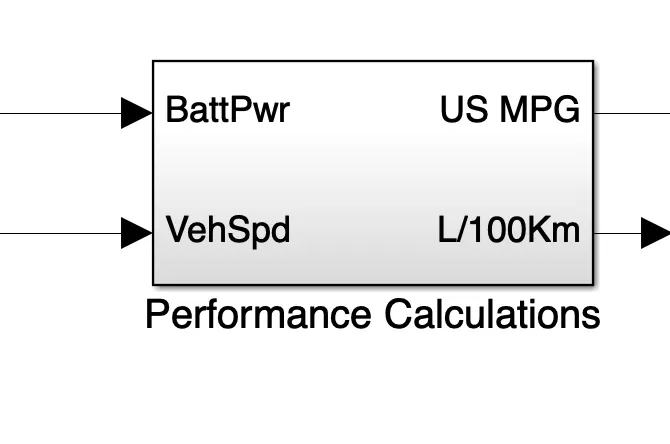
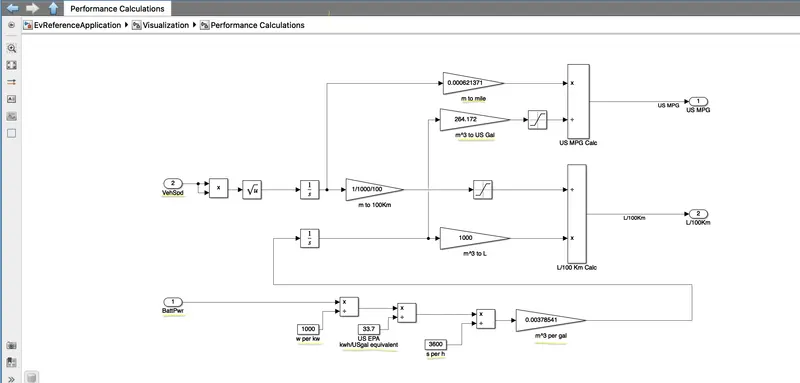
The vehicle speed is fed to the system in the name of "VehSpd" which is then, battery power data is used to find the power used in kWh, this is then converted to gasoline-equivalent using US EPA value which is calculated by dividing by 33.7(1 gallon of gasoline is equal to 33.7 kWh). By dividing the distance traveled in miles by the number of gallons, we can get the measurement in miles per gallon. In the case of HEV, this gallon is added with the gallon used by the IC engine then miles per gallon is calculated.
_________________________________________________________________________________
3)
The EV reference model and HEV reference model are not being executed in MATLAB with frequent errors like "BattEvlib" not found when simulated using Powertrain blockset, and "BMS_outlib" when Simscape is used.
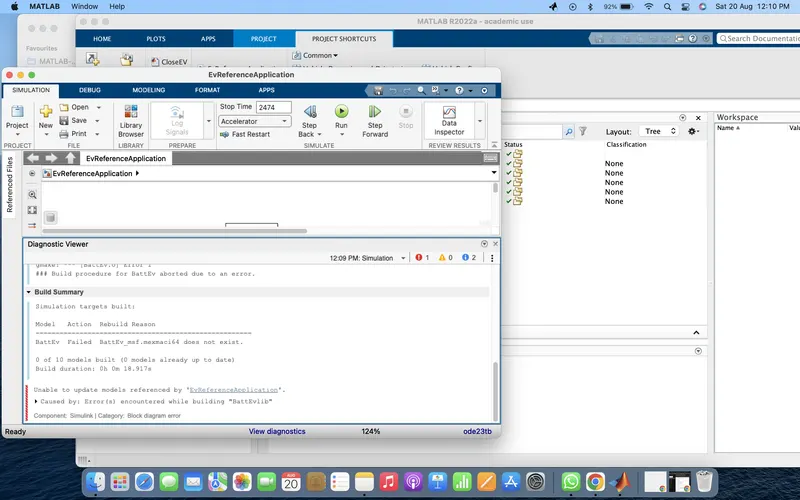
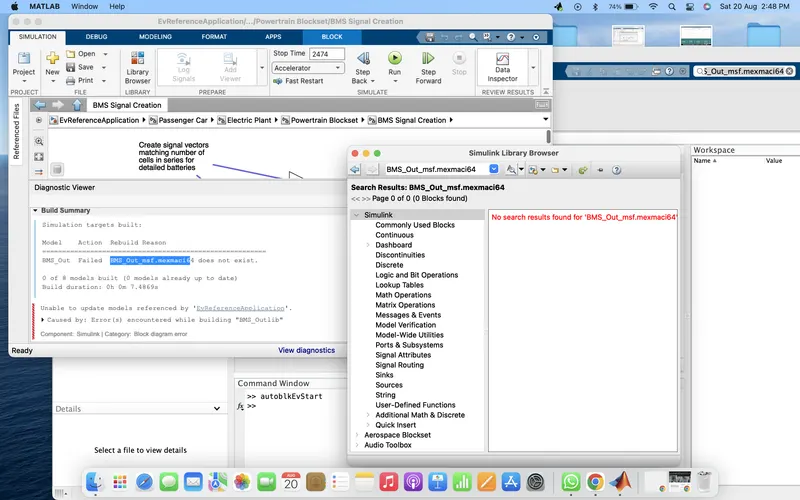
This was the problem I faced while performing the 4th week assignment.
I raised this issue on Forum, got a call from skill-lync and a mentoring session was assigned. But the session wasn't fruitful for the error in my Laptop.
I reinstalled MATLAB 3-4 times.
Tried using Online MATLAB on browser, it was slow and was breaking out frequently.
I also tried the online source of MATLAB for the error resolution. But didn't succeed