Week-4 Challenge WOT Condition Part-2
EV LIVE BATCH:-21
1. What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Ans:- In order to aee the differences between Mapped model & Dynamic Model of engine,Motor & Generator, we have to open "EV Refence Application" from the help menu of MATLAB window. which looks like as follows:-
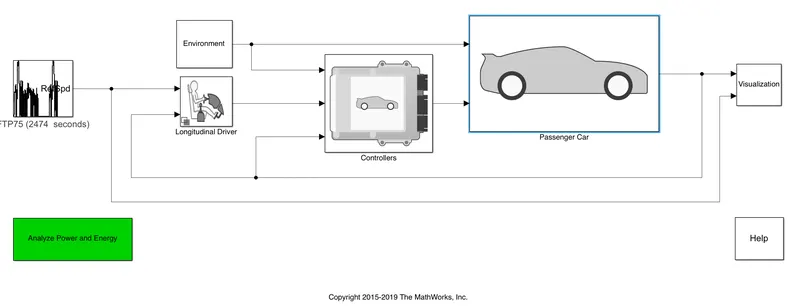
In this model, we can see that there are some powertrain blocks are used such as:-
- FTP75 drive cycle
- Longitudinal driver
- Environment Subsystem
- Controller block
- Passenger Car subsystem
- Visualization block
so in order to discuss about the Mapped model & Dynamic mode of Motors & generators, we have to open the Passanger Car Subsystem
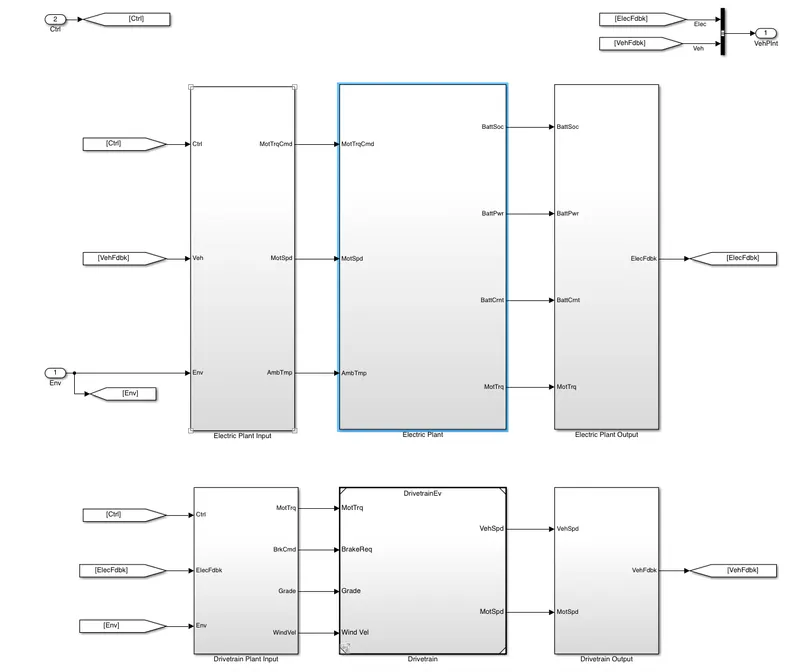
- Then double click on the Electric Plant Subsystem,
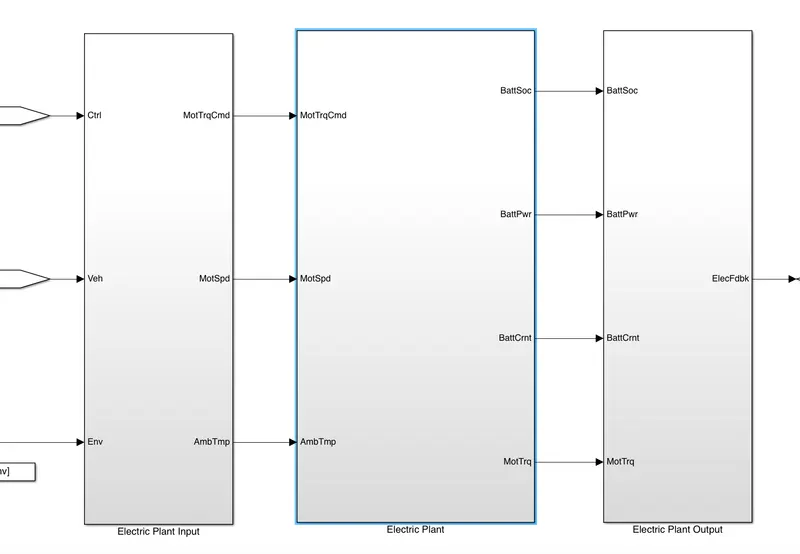
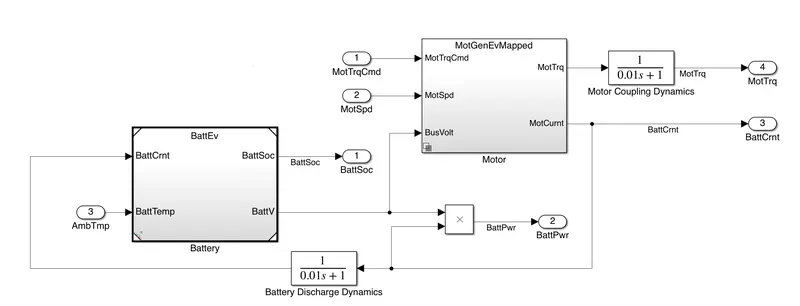
- Then Open the Motor Subsystem:-
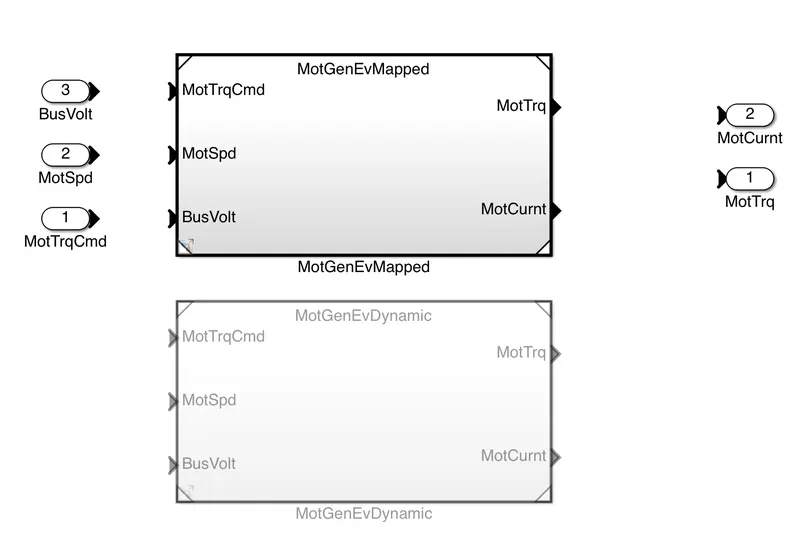
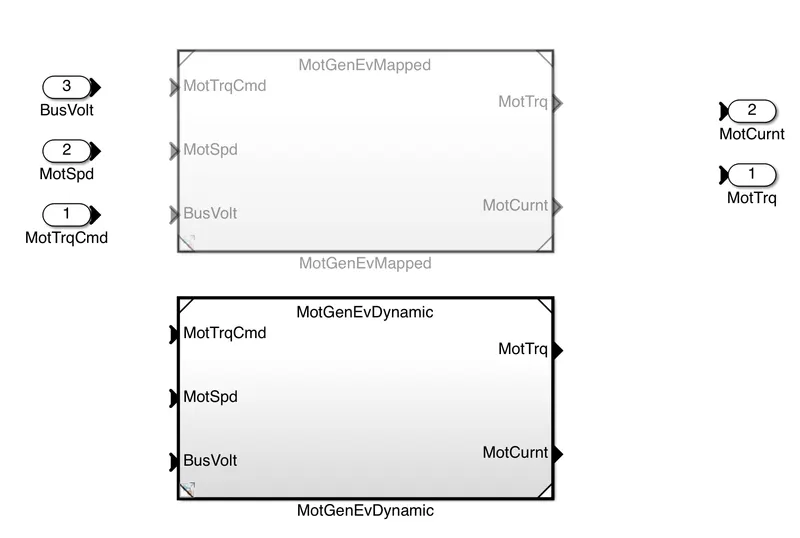
- Inside the Motor subsystem, both Mapped Model & Dynamic Model are available. we can simulate one model at a perticular time which means that if Mapped Model is activated at that time the Dynamic model will remain deactivate & vice-versa.
(1) Mapped Model:-
- When we open the Mapped model we can see that
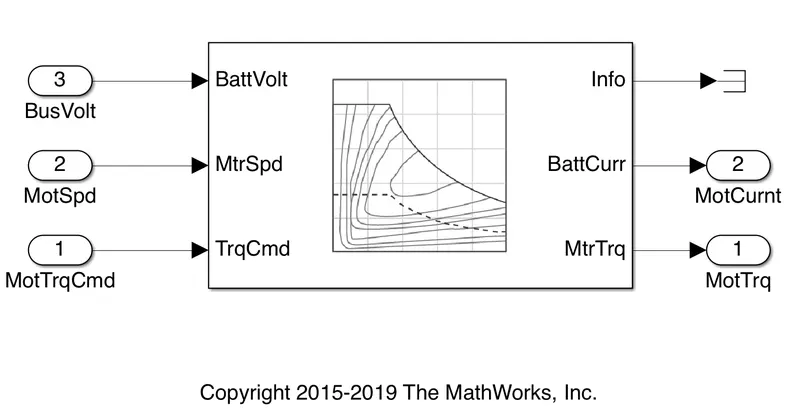
- Mapped models are such type of model in which the data or values for required parameters(inputs) are pre-assigned in a look-up table.
- The output values are stored for the corrresponding given input values of the engine motor and generator.
- Accuracy of Mapped model is not very high.
- This type of model requires very less time to simulate.
- As the inputs are pre-assigned in a llok up table, therefore the outputs can be calculated as per the look-up table information. which means that outputs are stored corresponding to every single inputs.
- so calculations are very fast.
- here input parameters such as:- Brake torque,Fuel flow,Air mass flow etc & outputs are may be exhaust temperature, efficiency & emmisions.
(2) Dynamic Model:-
- If we open the Dynamic model inside the Motor subsyatem, then we can get
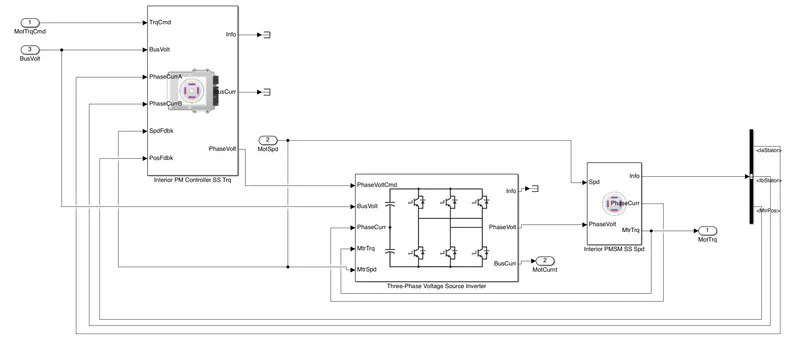
- Dynamic Models are such type of models in which we used the real-world based conditions as input.
- here we don't require Look-up tables to calculate the outputs.
- we can see in this model, there are many feedback signals are used which will increase the accuracy of the output.
- here we can see that Dynamic model used outputs (as feedback signals) from various subsystems to generate the main outputs.
- It runs by real time simulation where the required input from the drive cycle is taken and for that individiual real time simulation gets performed and summing all the results of the subsystem gives the output for the simulation.
- Accuracy of Dynamic model is very high as it consists of feedback signals.
- But these model takes more time to simulate as it simuate the real world conditions.
- In this type of model, calculations are time consuming.
(*) Method to Change the Model type:-
- In order to change the Model type means From Mapped Model to Dynamic Model & vice-versa, then we have to open the Motor subsystem which is inside the Electric Plant Subsystem which is inside the Passenger Car subsystem of the "EvReferenceApplication" simulink model.
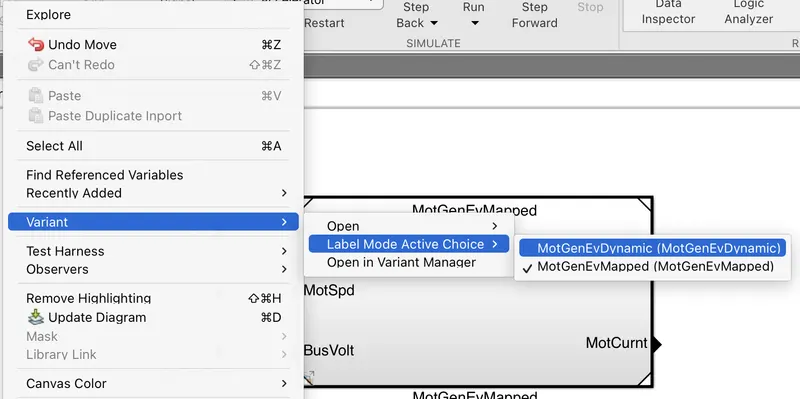
- Bydefault Mapped model is set when we open the model. then in order to change from mapped model into Dynamic mode, we have to follw the next procedure
- Right click on that page then go to Variant, then click on the Label Mode Active Choice then choose MotGenEvDynamic(MotGenEvDynamic) to select the Model as Dynamic model.
- Then we can see the Model type has changed sucessfully from Mapped Model into Dynamic Model.
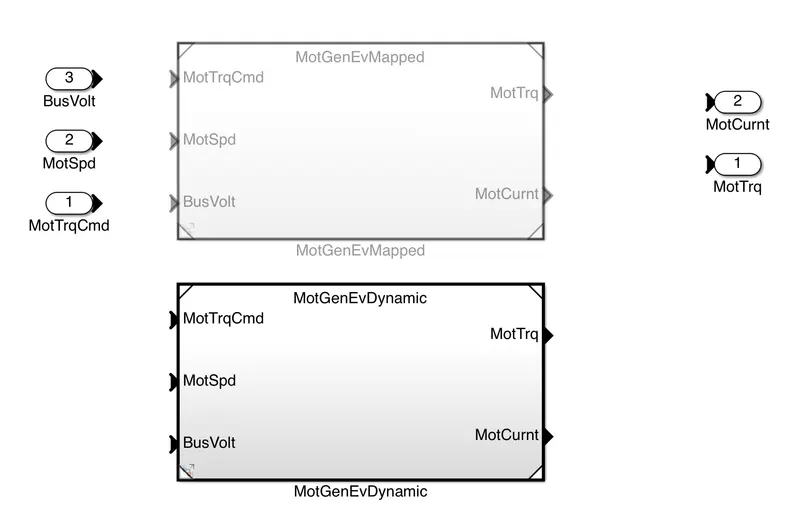
- If we want to change the model again from Dynamic to Mapped model then we can follow the above discussed procedure.