Week-4 Challenge WOT Condition Part-2
EV 17TH LIVE BATCH
1. Que:-
Ans- powertrain blockset provides two types of combustion engine models maped and dynamic.
Mapped engine:-
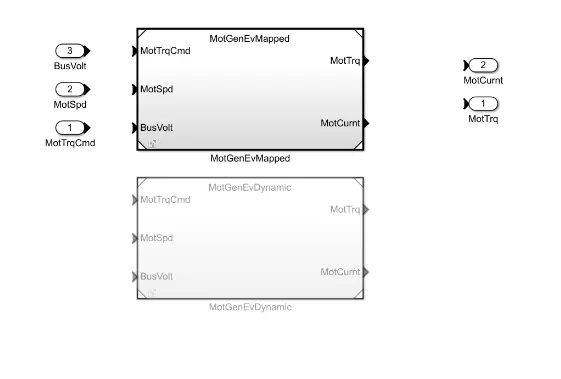
- Mapped engines represent macro engine behaviour as a set of lookup tables( brake torque,fuel flow,air masflow,exhaust temperature,efficiency and emissions) as functions of commanded load and measured engine speed.
- Mapped engine model are suitable for analysis and design activities that do not require engine subsystem dynamic characteristic, for example in engine and transmission powertrain matching analysis for fuel economy,emission and performance trade offs.
Dynamic engine:-
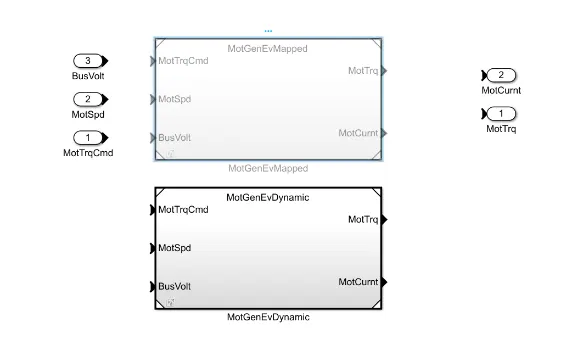
- Dynamic engine decompose engine behaviour into individual component models that account for engine dynamics, most notably intake airflow and turbo charger dynamic.
- Dynamic engine models are suitable for designing control,estimator and diagnostic,algorithms that depend on dynamic subsystem states for example in closed loop AFR (air fuel ratio) control algorithm development.
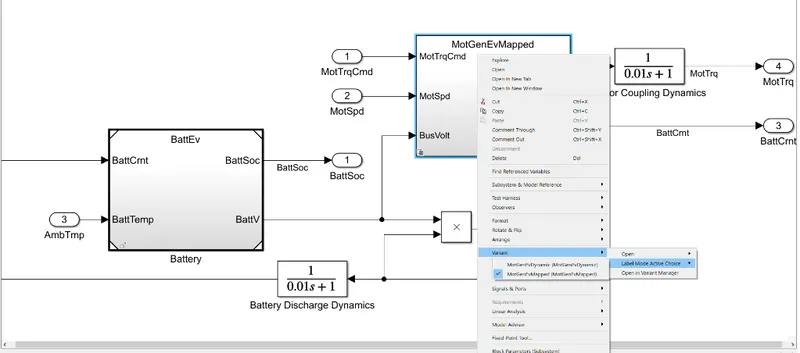
we can switch between mapped and dynamic engine by following below procedure;
1.open the ev model in simulink.
2.enter the passenger car block by double clicking it.
3.then go to electric plant block.
4.inside the motor block right click to find the variant option.
2.Que:-
Miles per gallon (mpg) & miles per gallon equivalent(mpge):
for a conventional gasoline vehicle, the fuel efficiency is calculated via miles per gallon(mpg). however fuel efficiency for hybrid ev is calculated via miles per gallon equivalent(pge). mpg is the number of miles your car can drive per gallon of gas.calculated that 33.7kw hr of electricity is equivalent to one gallon of gas.
we should go inside ev reference block that is performing calculation.
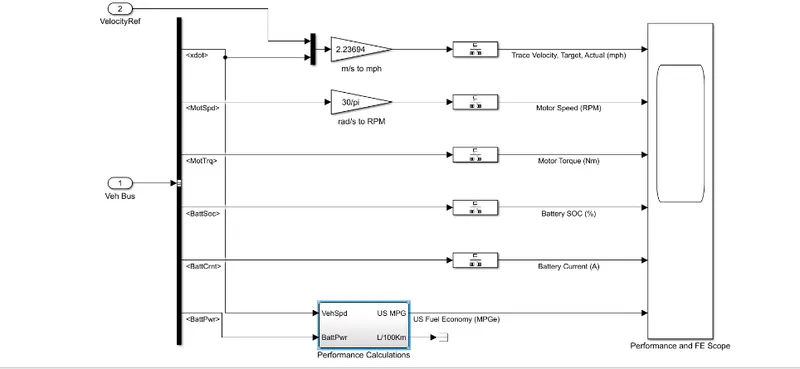
inside this block will get actual mpg calculations.
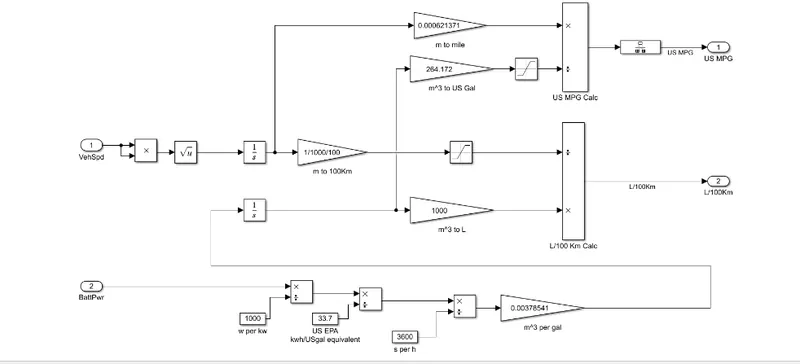
Here, three different inputs are taken into considerations,
1.vehicle speed
2.fuel flow
3.battery power
The vehicle speed inputs is in m/s which is converted into miles by multiplying with 0.000621371.
similarly the lg of fuel is converted into cubic meter by multiplying by 1/(1000*0.739) this cubic meter value then converted into gallon by multiplying with 264.172 miles value and gallon value is used to find mpg of vehicle. now the battery value is initially converted from watt to kwh by dividing with 1000 and then to gallon equivalent by again dividing it with 33.7(33.7 kwh=1 gallon) then divide the value by 3600 to get in per sec and multiply by 0.0037854 into get the value in cubic meter per gallon.
3.Que:-
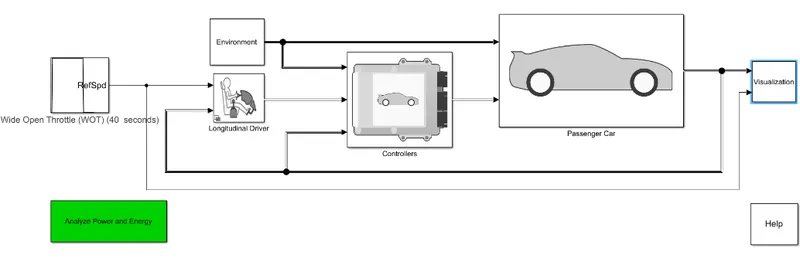
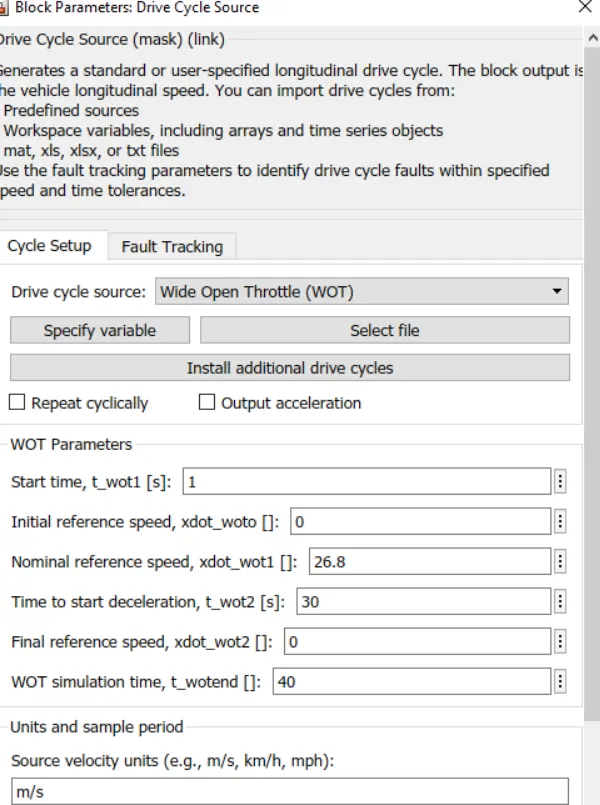
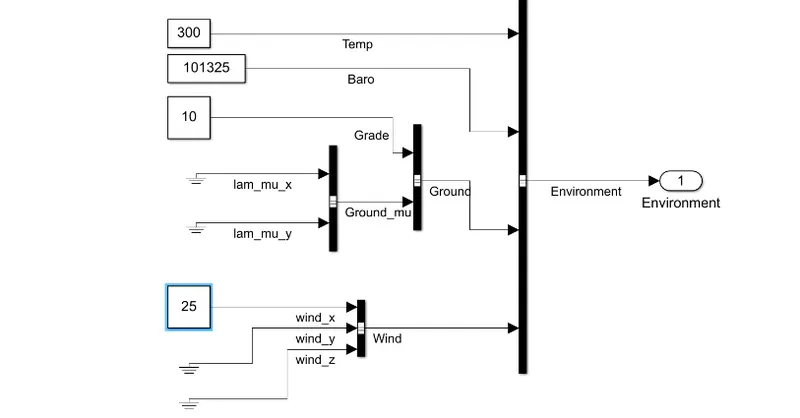
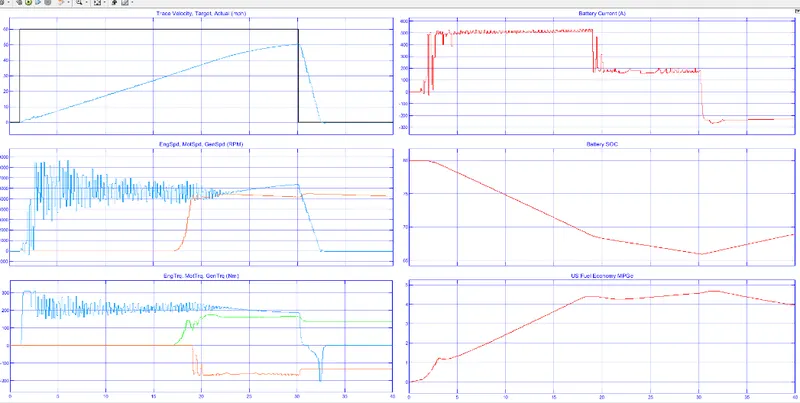
here we have changed drive cycle to WOT with a sample time 40 sec. we have also altered environment block and changed wind speed to 25m/s & garde to 10.
environment block:
Results:
Conclusion:
plot 1:
trace velocity,target,actual
top velocity achieved = 50.1mph
time taken to accelerate = 29.034sec
time taken to deaccelerate = 2.471sec
plot 2:
motor&engine rpm
top motor rpm = 5712 rpm
top engine rpm = 5451 rpm
plot 3:
motor&engine torque
maximum motor torque = 306.6N-m
maximum engine torque = 174.7N-m
plot 4:
Battery current
Thye battery current is at its maximum value of 167 ampere.
plot 5:
Battery soc
The battery soc will falls 80 to 65% during acceleration of vehicles and it increase slightly 65 to 70 % during de acceleration due to regenerative braking.
plot 6:
fuel economy
maximum fuel economy achieved = 4.675
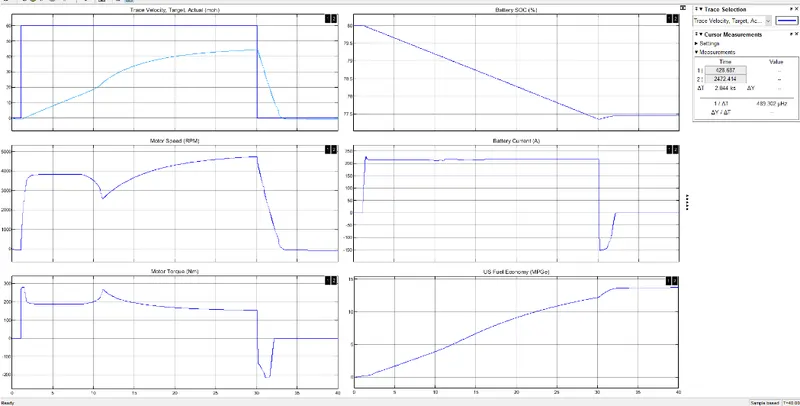
4.Que:
simulated results of hev:
simulated results of ev:
Conclusion:
1.The top speed is achieved by hev is more than ev.
2. The battery current capacity of pure ev is much higher compared to that hev since in ev battery is the only driving unit.
3. Higher fuel economy is achieved in case of pure ev.