Week-4 Challenge WOT Condition Part-2
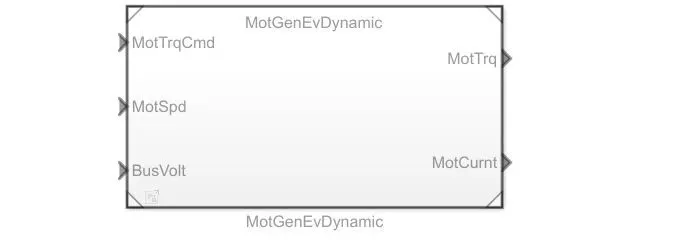
Question1:What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
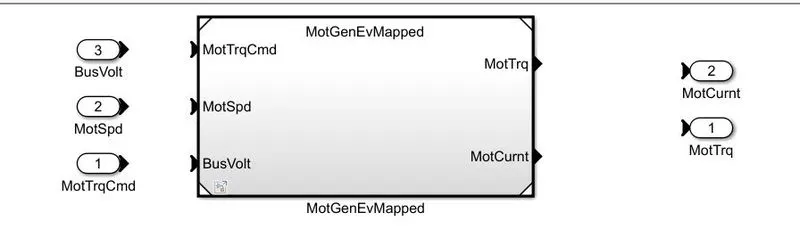
Powertrain blockset provides two types of combustion engine models:mapped and dynamic
mapped engine:
mapped engines represent macro engine behaviour as a set of look up tables(brake torque,fuel flow,air mass flow,exhaust temperature,efficiency and emissions) as functions of load and measured engine speed.
mapped engine models are suitable for analysis and design activities that do not require engine subsystem dynamic characteristics,for example in engine and transmission powertrain matching analysis for fuel economy,emissions and performances trade offs
dynamic engine:
dynamic engine decompose engine behaviour into individual component models that account for engine dynamics most notably intake airflow and turbo charger dynamics
dynamic engine models are suitable for designing control estimator and diagnostic algarithms that depend on dynamic subsystem states ,for example in closed loop AFR(air fuel ratio) control algorithm development
we can switch between mapped and dynamic engines by following below procedures
1.open the ev model in simulink
2.enter the passenger car block by double clicking it.
3.then go to electric plant block
4.inside the motor block right click to find the variant option.
Question2:How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
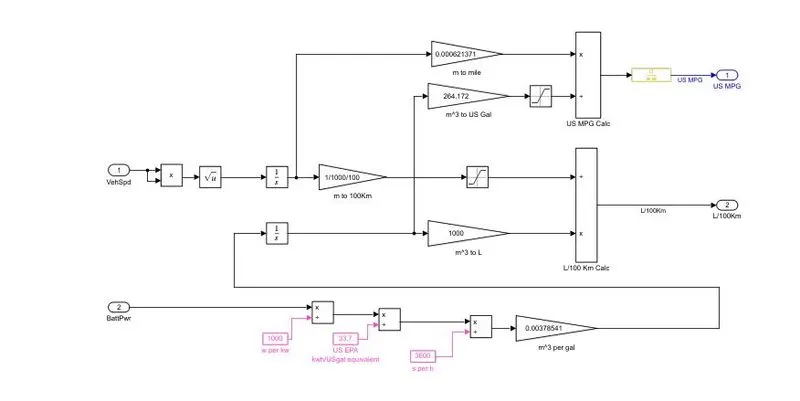
the inputs are
1.vehicle speed
2.fuel volume flow
3.battery power .
the above image has two fuels electricity and fuel .as discused earlier 1 gallon of gas equal to 33.7 kwh of electricity so battery power is first converted into kw(w/1000)then its divides by 33.7kwh.the fuel equvivalent of battery is added to the fuel flow .using the vehicle speed and time the distance of travel is calculated into miles by conversions .then as we have the fuel flow in m^3 and distance in miles .we can calculate the fuel efficiency.
Question3:Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
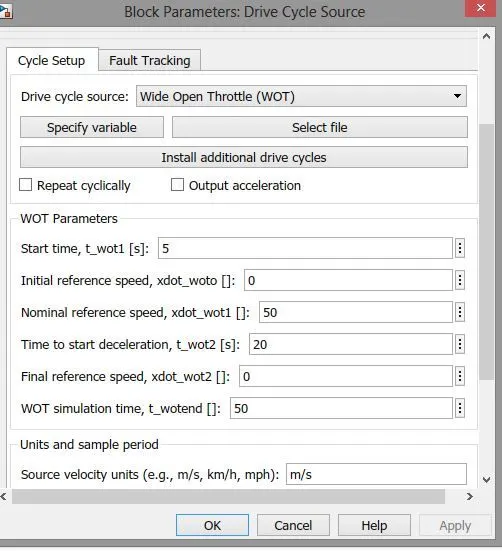
use the command autoblkhevstart in command window to open the hev reference application .then double click drive cycle source block then change WOT cycle. also give the parameters like speed ,WOT duration time ,final speed max speed and time to simulation
model:
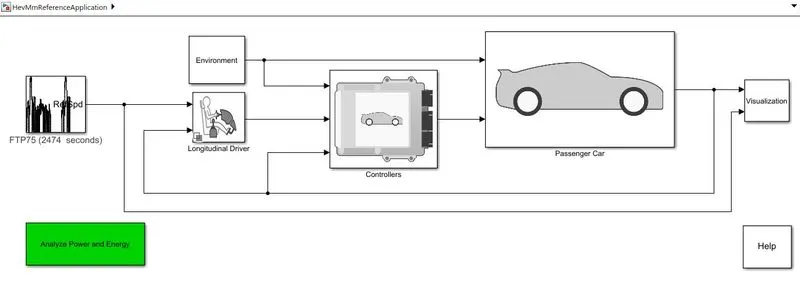
here we have to changed drive cycle to WOT with sample time 40 seconds
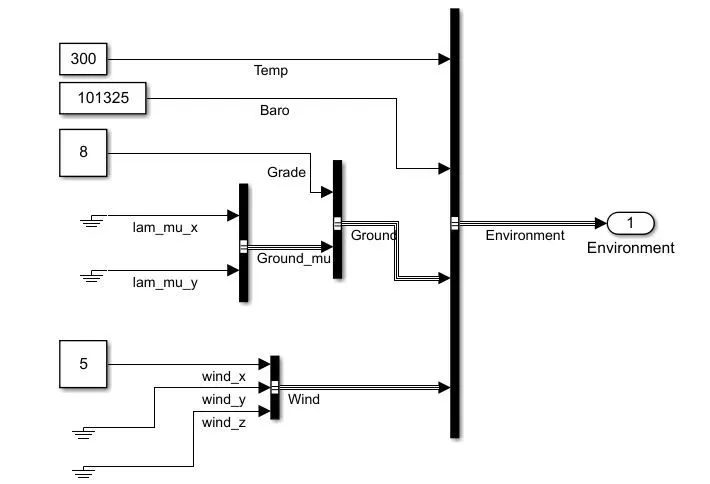
we have also altered environment block and changed wind speed to 25m/s and grade to 10.
environment block:
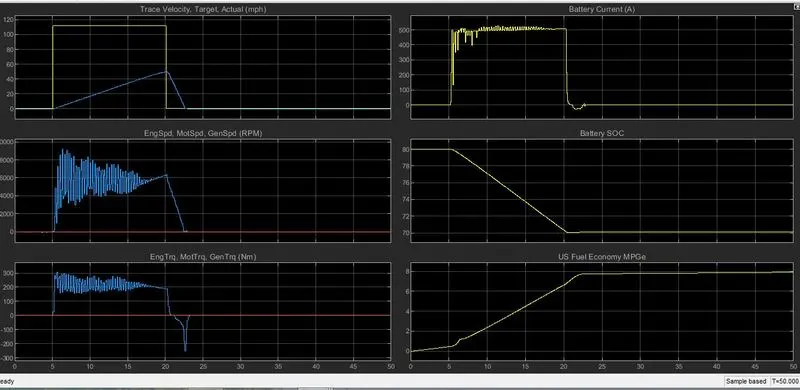
results:
Question4:Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
HEV results:
EV results:
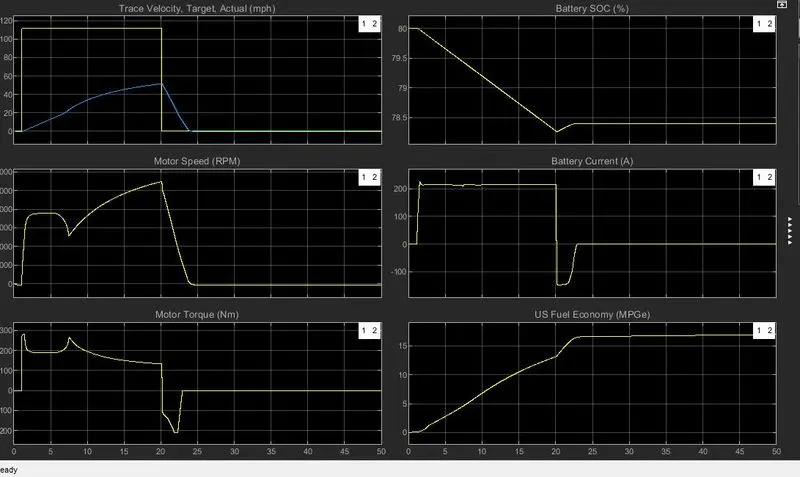
after completing the graphs of both EV and HEV following conclusions can be drawn:
the graph performance is almost same the reason is motor was operating so the performance in both EV and HEV is similar.the battery current drawn by HEV decreases intially only motor takes all the load and later engine kicks so motor load drops thus current drawn by motor reduces.andduring the decelration it is seen that current flows for a longer time in HEV as compared to EV so we can say that regenarative braking is more aggressive in HEV.
motor torque and motor speed are stable in EV and keep fluctuating a lot in HEV during the starting.also the peak rpm of motor in EV is less than HEV.