Week 3 - Solving second order ODEs
programming for animated simple pendulum:

%inputs
b = 0.05;
g = 9.81;
l = 1;
m = 1;

%initial condition
theta_0 = [0;3];

%time points

t_span = linspace(0,20,100);

%solve ODE
[t,results]=ode45(@(t,theta) ode_func(t,theta,b,g,l,m),t_span,theta_0)
%ploting
plot(t,results(:,1));
hold on
plot(t,results(:,2));
xlabel('time')
ylabel('plot')
grid on
title('angular displacement and angular velocity w.r.t time','color','r')


x = results(:,1);
ct = 1;
for i = 1:length(x)
    x1 = l*sin(x(i));
    y1 = -l*cos(x(i));
    x0 = 0;
    y0 = 0;

    figure(2)
    plot([-0.5 0.5],[0 0],'linewidth',5,'color','g')
    hold on
    plot([x0 x1],[y0 y1],'linewidth',5,'color','black')
    plot(x1,y1,'o','markersize',15,'markerFacecolor','y')
    axis([-2 2 -2 2])
    title('damping of simple pendulum')
    legend('support rod','length of pendulum','bob')
    hold off
    pause(0.02);
    M(ct) = getframe(gcf)
    ct = ct+1;
end


movie(M)
videofile=VideoWriter('simple pendulum.avi','uncompressed AVI')
open(videofile)
writeVideo(videofile,M)
close(videofile)

function for ode45:

function [dtheta_dt] = ode_func(t,theta,b,g,l,m)

theta1 = theta(1)
theta2 = theta(2)
dtheta1_dt = theta(2);
dtheta2_dt = -(b/m)*theta2-(g/l)*sin(theta1);
dtheta_dt = [dtheta1_dt;dtheta2_dt];

end
explanation:
1.firstly 2nd order ODE is converted into first order ODE by using ode function
putting the input parameters as given in the question as input valves
b = 0.05
g = 9.81
l = 1
m = 1
2.after that take angular displacement and angular velocity also time between 0 and 20 in intervals of 100 usimg linspace command
theta_0 = [0;3]
t_span = linspace(0,20,100)
3.to solve the ODE function using the following inbuilt command
ode45(@(t,theta) ode_func(t,theta,b,g,l,m),t_span,theta_0)
4.for loop is used for getting automatic valves instead of manual valves
5.using plot command we have to drawn the supporting rod length of pendulum using different colors for indication
using markersize command i have drawn the bob with diameter and for color i have used markerFaceColor
6.hold off is used for not repeating the length of pendulum when it is oscillating and ct command is used for counting the lines one to another
7.for animation we have to use movie(M) command
movie(M)
videofile=VideoWriter('simple pendulum.avi','uncompressed AVI')- it is used for file name in avi format
open(videofile)- it opens the file
writeVideo(videofile,M)- it is used to writes the video file
close(videofile)-closes the videofile
8.legend command used for indicating the bob supporting rod and length of the pendulum in graph
9.title command used for giving the title in graph
errors:
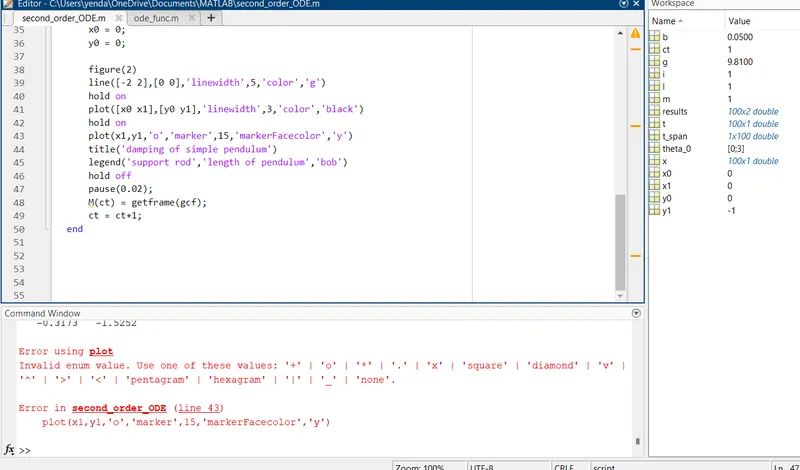
i have used marker instead of markersize and after that the i have got the plot
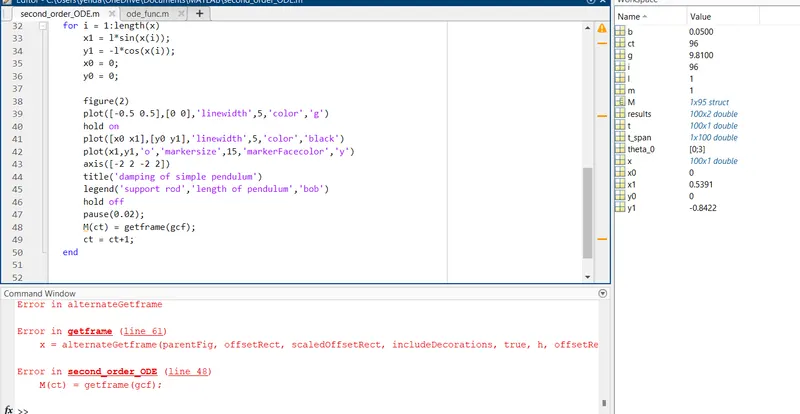
syntax error
youtube link :
https://youtu.be/jM_9LxhaF_Q