Week-4 Challenge WOT Condition Part-2
| S.No | Mapped Model | Dynamic model |
| 1. | Its a user defined block (Look up table ) | It can be generatednby using inbuilt blocks |
| 2. | which consist of values with respect to time and other parameters. | Its a premodeled item. |
| 3 | It requires high attention to work with complex models. | Only the parametrs has to be addressed according to the requirement |
| 4 | Calculations and execution will be on faster model. | Due to high data informartions, execution speed must be low. |
| 5. | Disturbances, losses and other factors inclusion is bit difficult. | Parameters can be changed, if it as the availability |
1. Difference between mapped model and dynamic model
Steps to change the type:
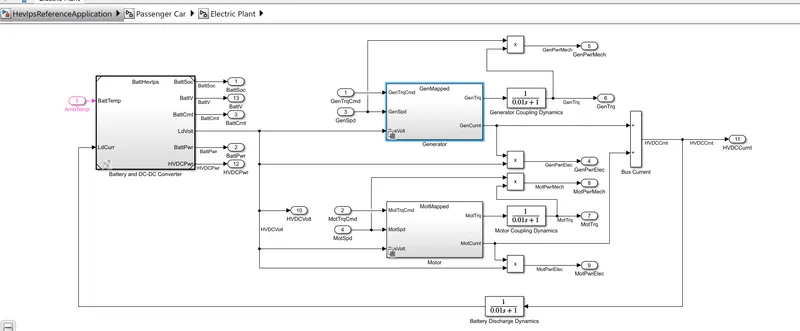
after selecting the particular block, we can make the selectionwith mapped and dynamic modelled. i have selected , Generator model.
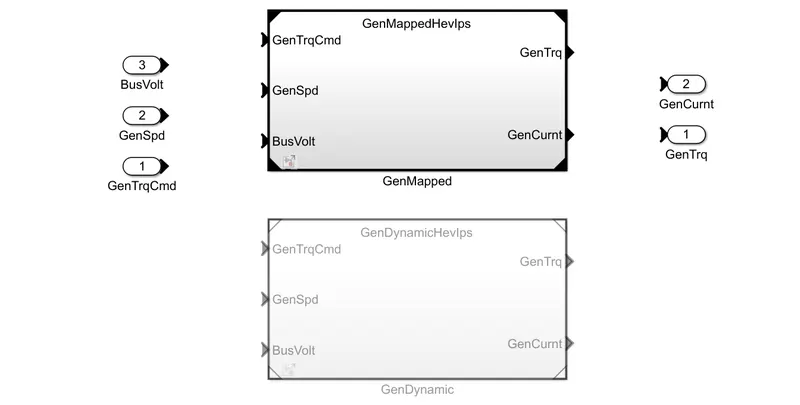
In the above image , if we hav to select the dynamic model, then the mapped model has to be deactivated and Dynamic model has to be enabled by the varient option.
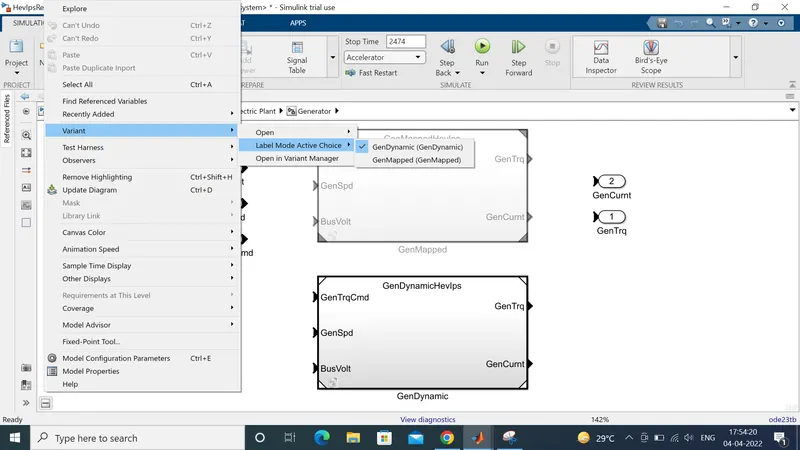
Now we can save the model, then we can observe the output as per the changes.
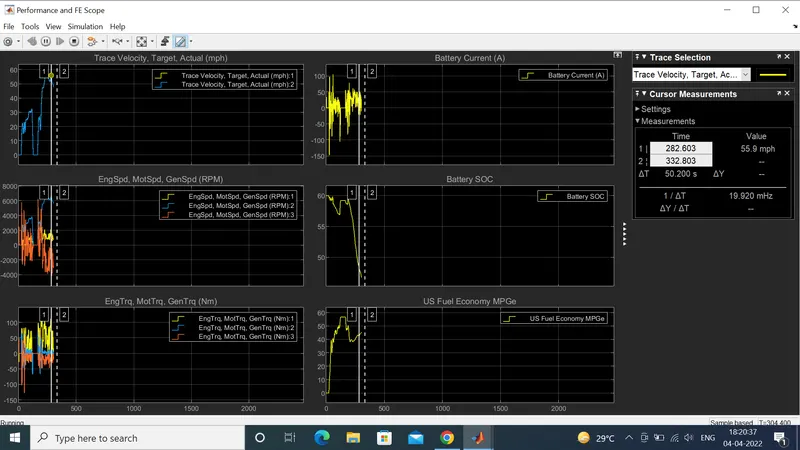
Since the model is having dynamic block, the execution spped is slow, we can got below graph for the realtime execution time as30min with the same simulation time as 2474.
2. MPG calculations:
MPG is represented as miles per gallon or miles per gasoline. How many miles are crossed with the usage of 1 gallon of fuel is denoted in MPG. this is a metric approach.Equivalent SI approch is kmph.
1 liquid gallon = 3.78liters
264.17 us gallon= 1000Liters
1m=0.000621371 miles,
Since this is a metric standard, the countries like america, canada and some other countires also referring this method to identify the vehicle milage.
MPG conversion block in model file
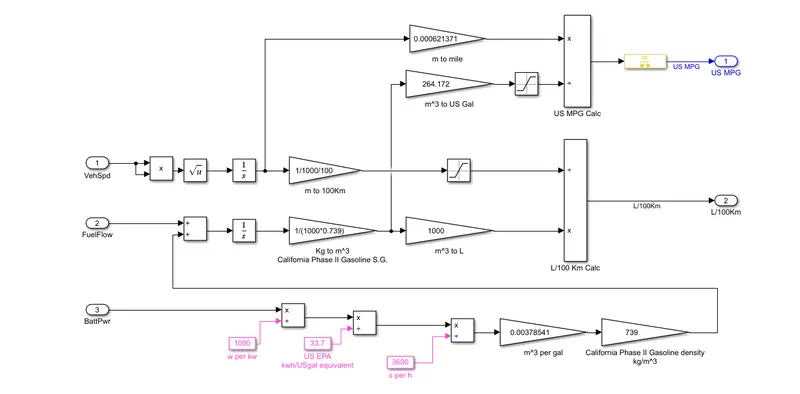
so the above values are multiplied and divided for miles conversion.
Rate transition block is used to convert the data from one rate to another rate.
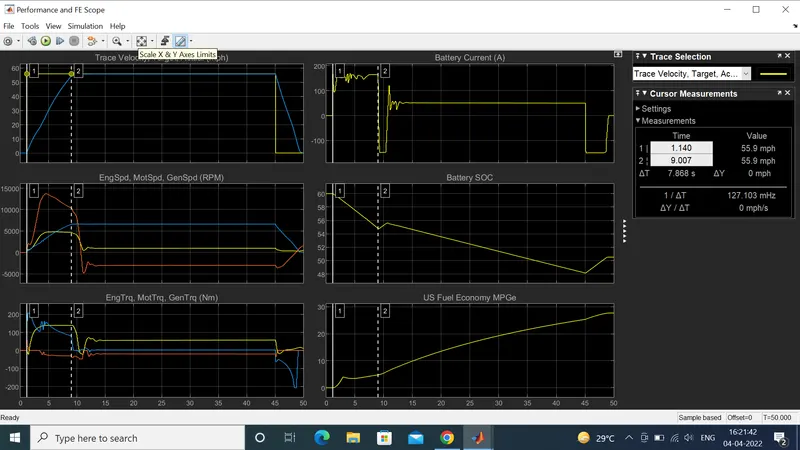
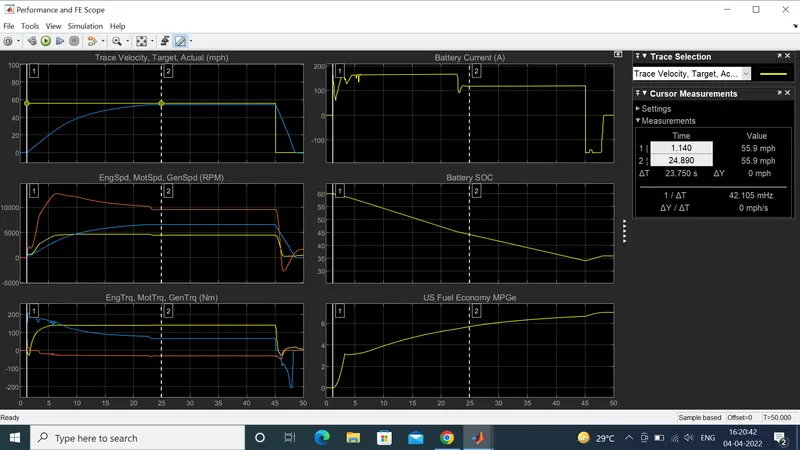
3. Hybrid Electric vehicle with power split up eaxmple had been considered to compare the normal results with defualt value and with change in Gradability , wind velocity.
Here, Gradability is considered as 10deg and wind velocity as 10m/s.
default output
output waveform for change in parameters:
Gradability:10
Wind Velocity:10m/s
Conclusion:
- Time taken to reach the desired speed increased with comparing with case II. this has happened because of gradability, so that the vehicle has taken more power from battery. We can identify the SOC change in both the cases.
- In case I SOC is limited to 48%, where as in case two SOC is keep on reducing upto34%.
4. pure EV
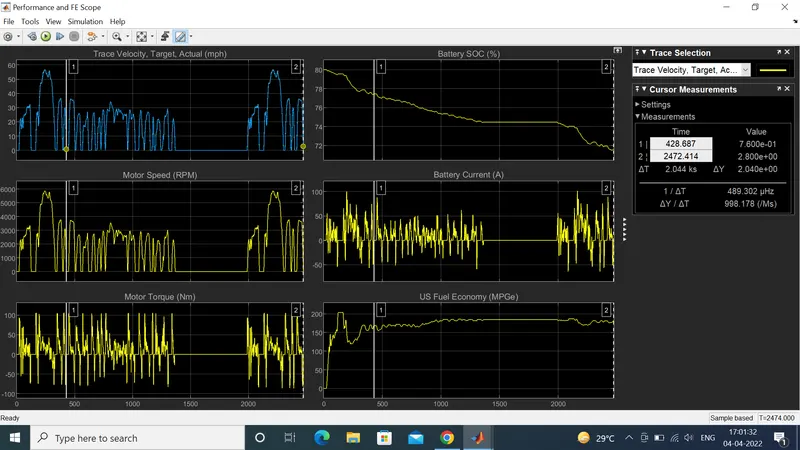
- From the above image,we can understand that, the vehicle SOC is keep on reducing upto 72%.
- during the certain duration, if drivecycle signals becomes zero, SOC also reacts for it, in this duration the charge is not utilised by any of the components, so the SOC remain constant.
- while comparing drive cycle with motor speed, both the varioations are in line.
- Motor torque approches positive value, when the drive cycle signal accelerates from low value to high. In other hand, while reaching the low speed, from high speed, the motor torque approches negative value.
Hybrid Elecric Vehicle:
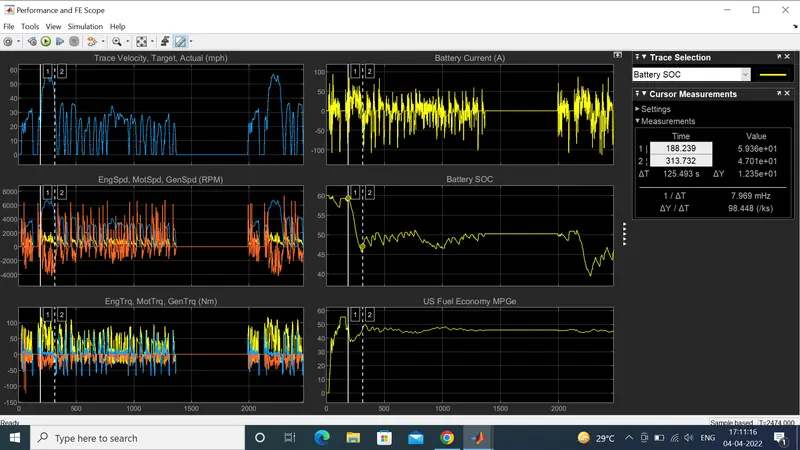
During the high speed, battery loosing the state of charge and while decelerating the SOC is getting improved, this is happening because of Generator which is coupled with planetary gear.