Week-4 Challenge WOT Condition Part-2
Q1)What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
| TYPE |
DYNAMIC MODEL |
MAPPED MODEL |
| Engine |
|
|
CHANGE MODEL TYPE :
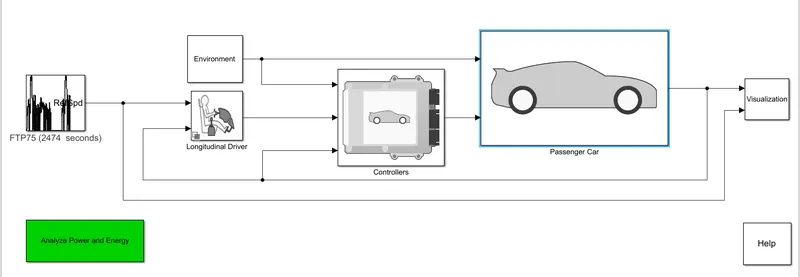
- These is a cisi reference application taken from matlab documentationwe select the passenger car block this block have a engine plant input ,type of engine,rngine plant output.
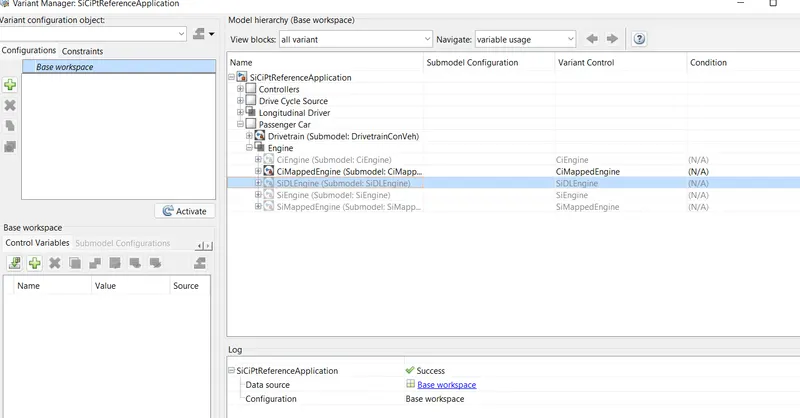
- we select engine block,this block have a si engine,si mapped engine, ci engine ,ci mapped engine,sidl engine.
- then right click on the engine block then select varient and lable mode active choice and choose the type of engine in the reference model
- another type is choose modeling option in matlab and choose varient manager
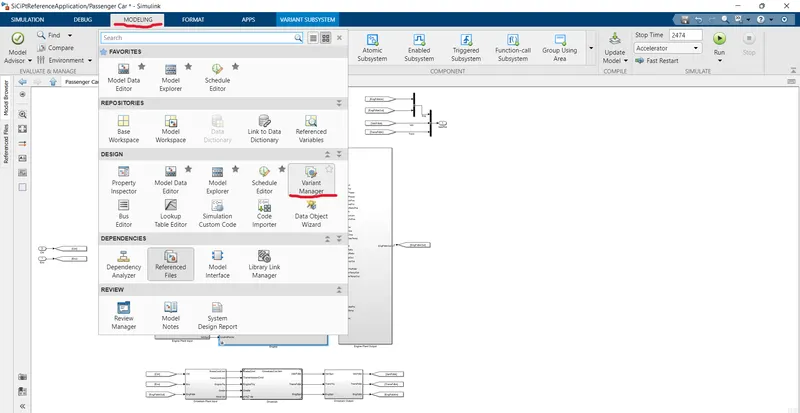
change the lable mode in below image.
Q2) How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
miles per gallon is a fuel economy rating detrmined by how far a car travel on a gallon of gasoline or diesel. although the metric version would be kilometer per litre.
for example
1MPG=0.42514KM/L,
in these model miles per gallon calculated using performance calculation block
when the input is vehicle speed and fuel flow
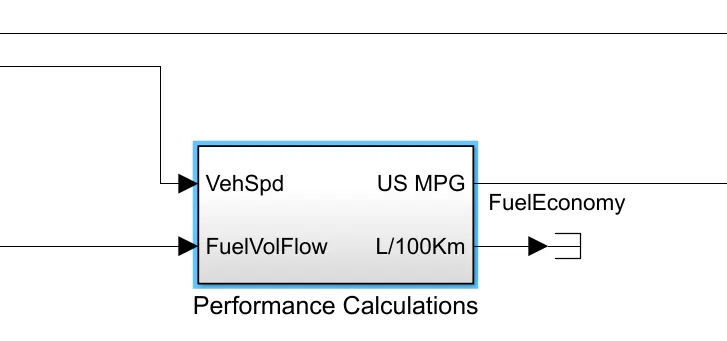
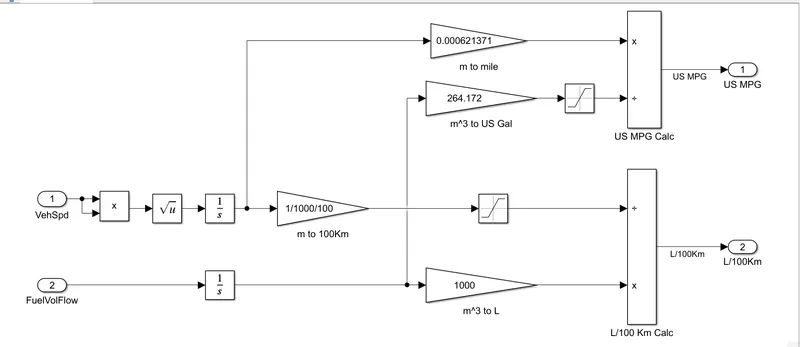
in above image MPG calculated using vehicle speed and vehicle fuel flow
fuel is integreated then multiply with 264.172 and veh speed is multiply twise and integrated then multiply with 0.000621371
output of vehicle speed and fuel flow respectively multiply and added then MPG is calculated
these is calculation for miles per gallen using model.
Q3)Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block
we select the HEV reference application with the help of matlab documentation
first we see the application with FTP75
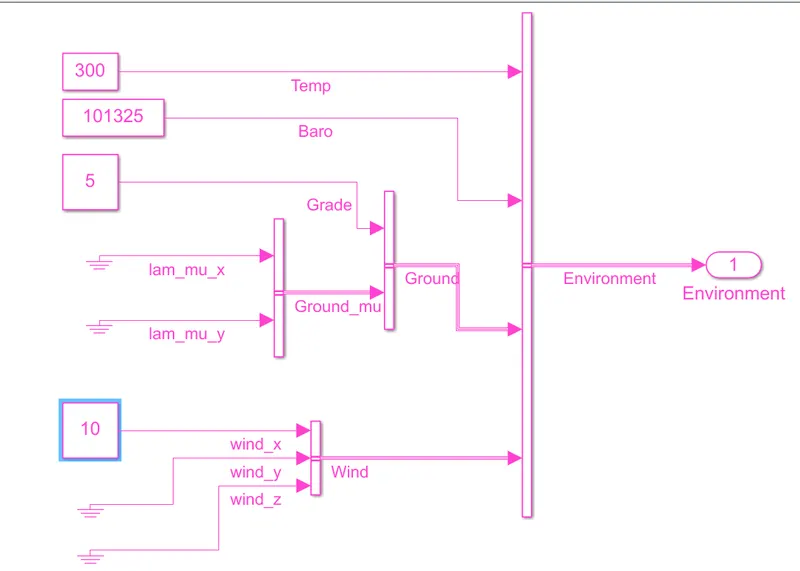
i change the FTP75 into WOT drive cycle also change grade and wind velocity in environmental block
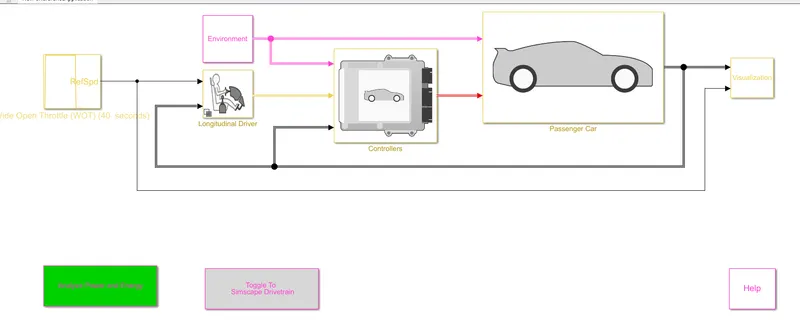
actual image of HEV application is shown in below image
these is image of environment block and change the grade value 0 to 5,wind velocity 0 to 10
then run the simulation.
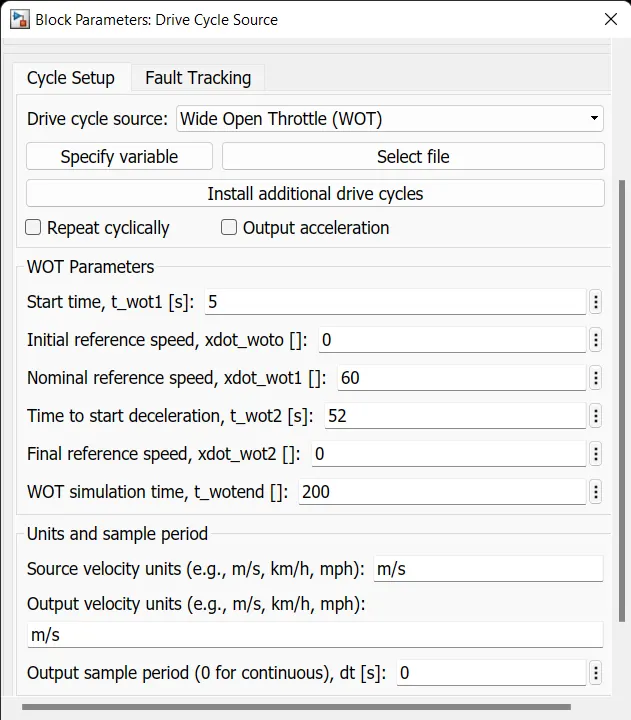
im change the WOT drive cycle parameters . WOT simulation run time fixed for 200 sec and reference speed fixed for 60
Output of simulation:
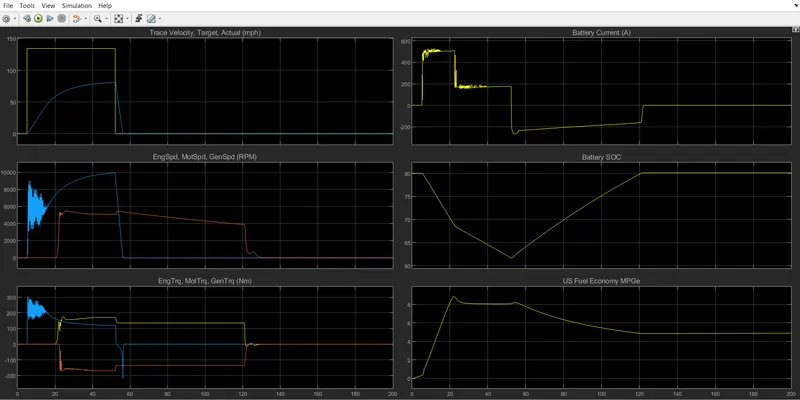
from the output increase the grade and wind velocity also increase the battery current,eng speed ,motor speed also increase the torque of motor and engine.
effect of WOT drive cycle , reference speed 60 and 52 sec deceleration this is condition the conditions are satisfied in output .
Q4) Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
we select the HEV reference application with the help of matlab documentation
first we see the application with FTP75
i change the FTP75 into WOT drive cycle also change grade and wind velocity in environmental block
actual image of HEV application is shown in below image
same WOT parameters are used and the grade and wind velocity values are not changed values are put zeros then run the simulation .
output of simulation (pure electric vehicle):
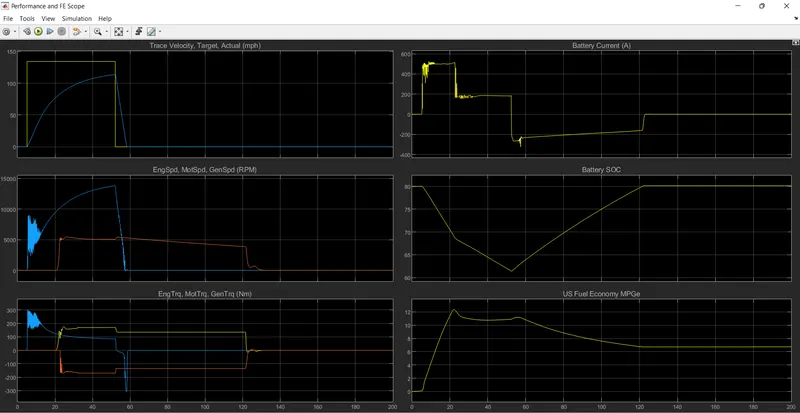
output of simulation (change values):
comparision:
in above images are pure and hybrid electric vehicles output
from the output actual speed ,torque,battery currnt all are caused some differences
in normal vehicle
top speed reached for any environment problems didn't affect the vehicle so the engine speed increased and battery current is normal
in environment change vehicle
top speed can't be reached . for wind and grade velocity was changed.