Week-4 Challenge WOT Condition Part-2
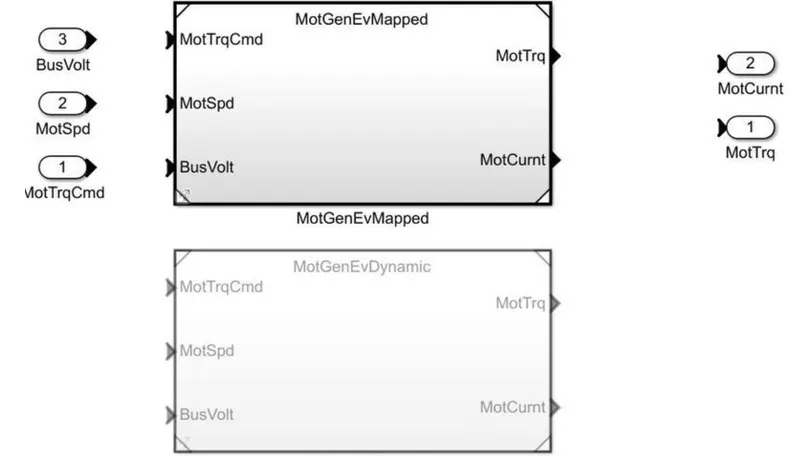
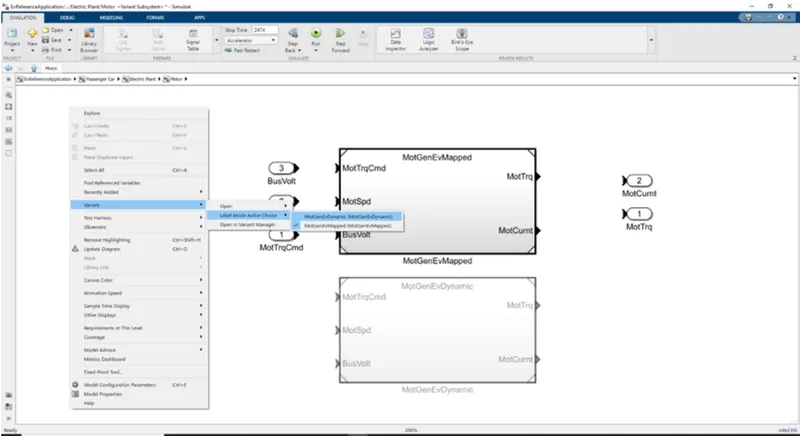
- What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
- How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
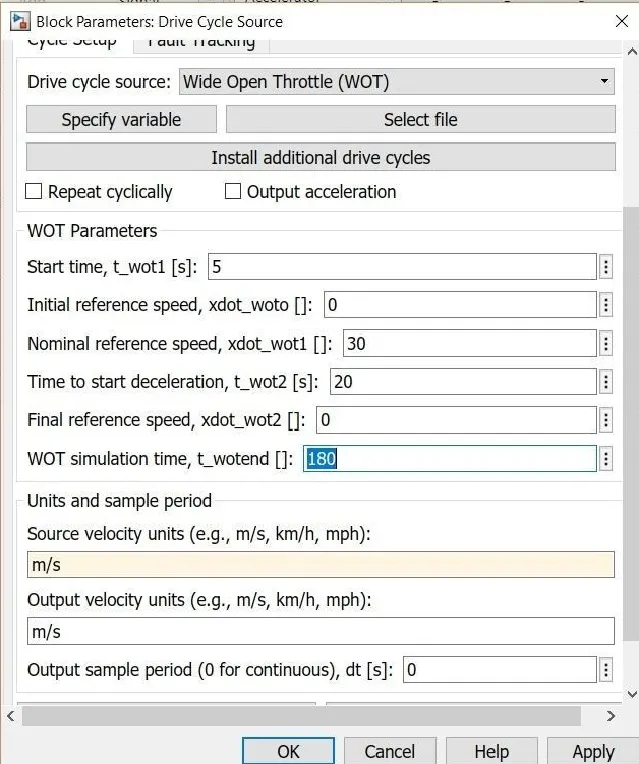
- Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
- Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
the difference between mapped and dynamic model of engine, motor and generator
Power train blockset can provide two types of engine models. such as mapped and dynamic.
Mapped engines represented as macro engine behavior as a set of look up tables such as brake torque ,fuel flow,air mass flow,exhaust temperature,efficiencies and emissions as functions of commanded load and measures engine speed dynamic engines decompose engine behavior into individual components model that used for account for engine dynamics ,we can switch between engine model types based on our application ,dynamic model is suitable for engine control,estimator and diagnostic algorithms that depends on dynamic subsystem states.for example in engine and transmission powertrain matching analysis for fuel economy,emisions and performance tradeoffs.
we can change the model type:-
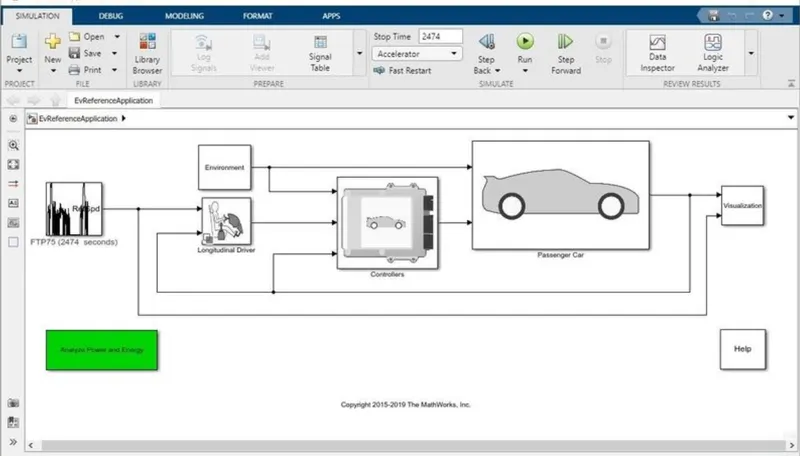
ev reference application in powertrain blockset of matlab that model which consist of drive cycle,environment conditions,longitudinal driver controller and passenger car.
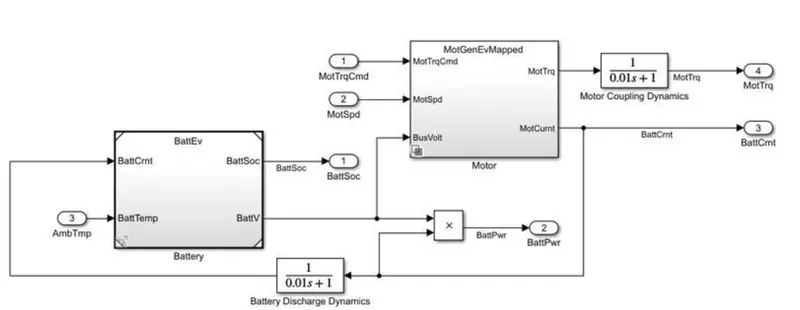
HEV reference aplication model
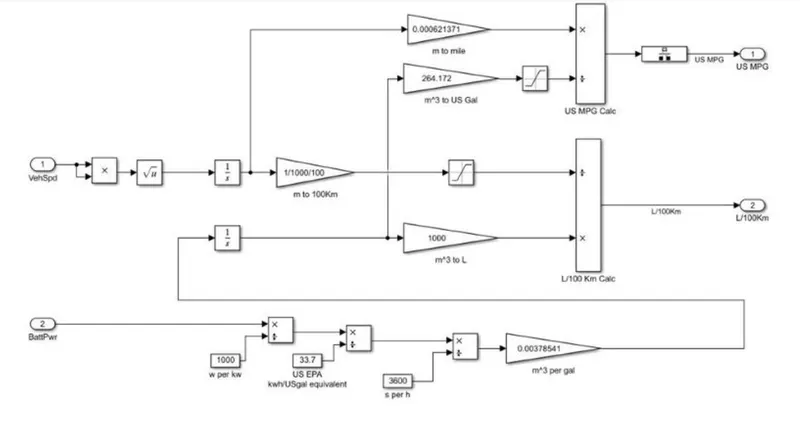
Factors considered in model fuel flow:-
1.vehicle speed
2. Battery power capacity should be high and vehicle power consumption should be low for higher mpeg.
Solution 3 HEV Reference application with wot drive cycle
The hybrid electric vehicle reference applicatuion represents a full multimode hybride electric model with the internal combustion engine.
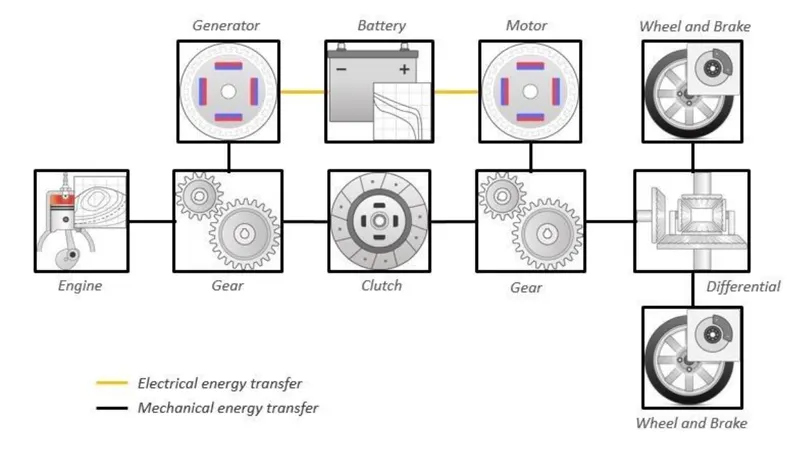
Description
1.it consists of various subsystems which are similer to EV Reference aplication but the complexity is more in HEV reference application model.
Result:
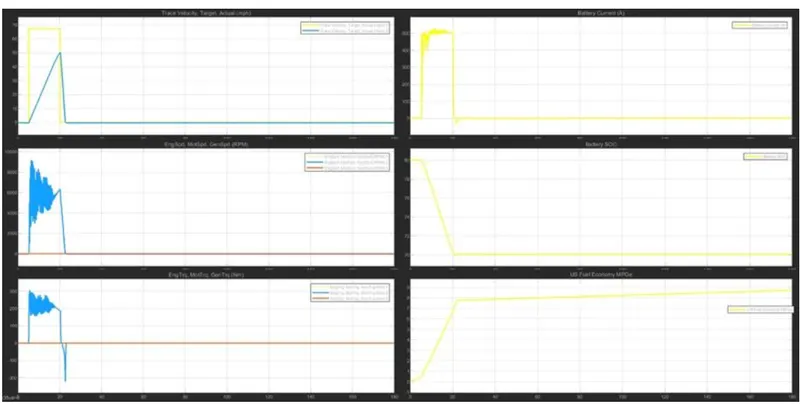
The terget velocity was able to achieve 67.1mph.The battery current was increased upto 500 amps and maintained for a duration of 14 second.
The engine torque increases initially.
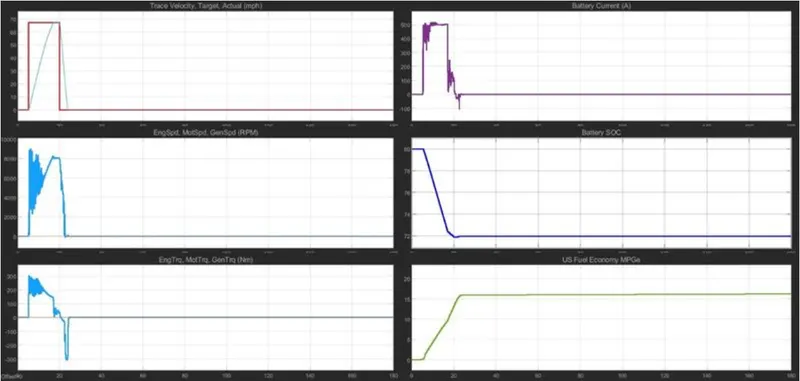
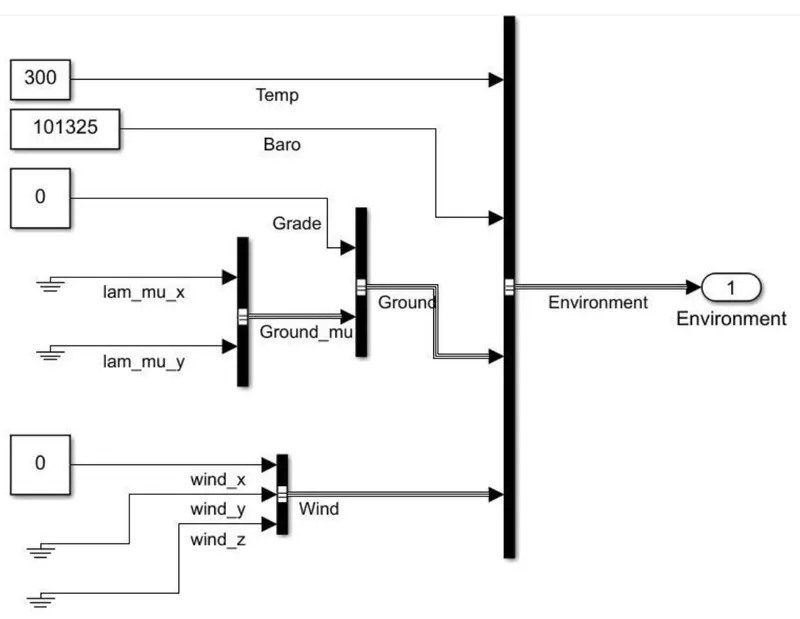
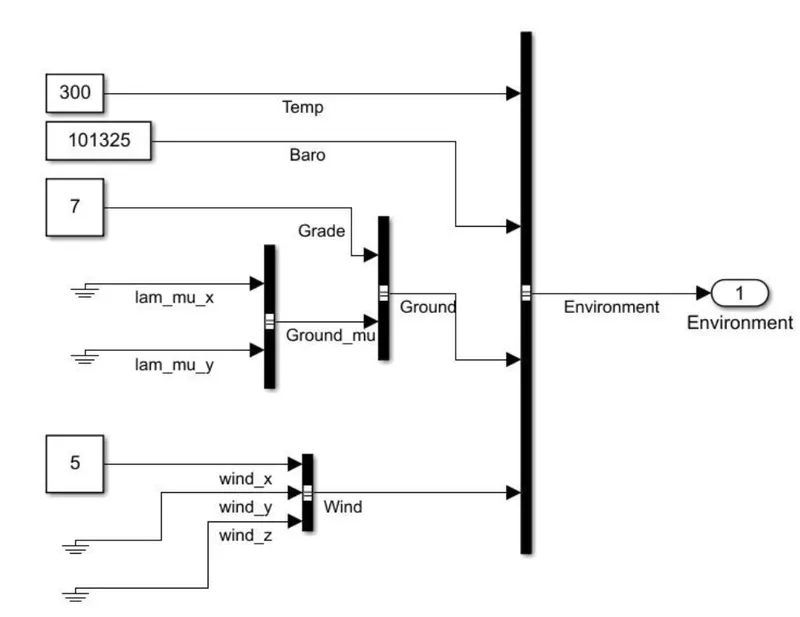
Now changinhg the environment subsystem in the specification of HEV reference application.
RESULT:
The terget velocity was only able to achieve 50.4 mph.the battery current was increased by 500 amps.
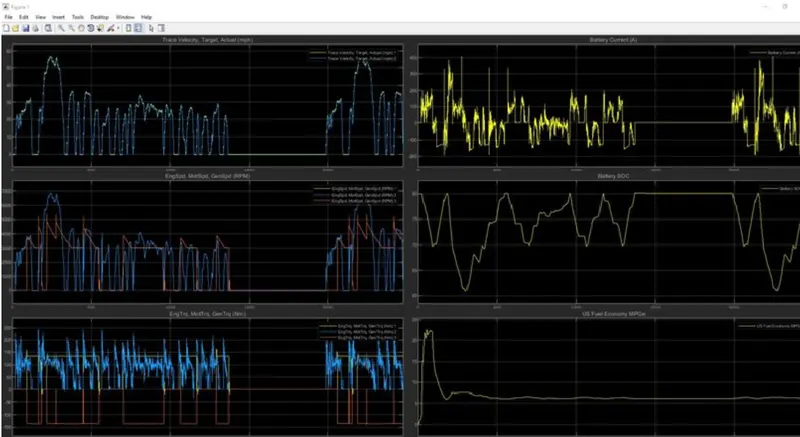
This is the graph
conclusion:
1.The motor speed is high for HEV as compared to EV.
2. Battery current is continuously changing in HEV due to charging and discharging while in pure EV ,the battery current consistently dropping