Week-4 Challenge WOT Condition Part-2
Main Objective-
1. What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
2. How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
3. Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
4. Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
1. What is the difference between mapped and dynamic model of engine, motor and generator? How can you change model type?
Difference between Mapped and Dynamic models
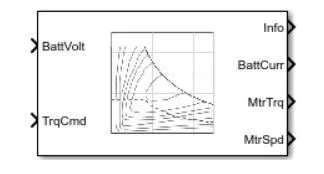 Mapped SI engine Mapped CI engine Mapped Motor
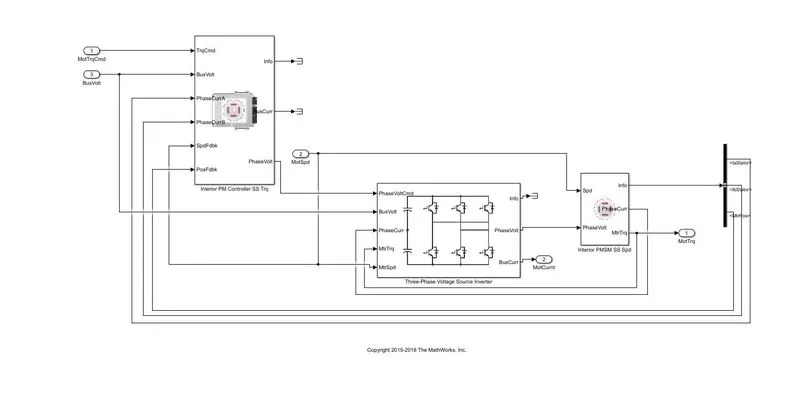 Dynamic Motor
Steps to change the model type:
Step1. Open the simulink model of powertrain blockset which is available in MATLAB documentation (type Powetrain blockset in search bar and choose the reference model from the options). Step2. Double click on the passenger car block to enter and open the block. Step3. There you will find the engine plant. Right click on the engine plant and select variant. Step4. In variant click on label model active choice and there you choose mapped or dynamic model for required calculation.
We can also change the model type by simply switching the model type and activating the other model based on application. Dynamic Engine model is suitable for the design of control algorithms, evaluation and diagonosis. Whereas mapped model is suitable for analysis and design that does not require dynamic characteristics.
_____________________________________________________________________________________________________________
2. How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Miles per gallon (or MPG) is fuel economy rating which can be determined by how much miles the vehicle is travelled per gallon fuel. In the case of EV vehicle this is measured by how much electrical energy is consumed by motors and the peripheries while travelling a certain distance. Factors considered to model MPG are vehicle speed, fuel flow and battery power.
The amount of Fuel Energy required to move a engine powered car through a distance is determined and then it is compared to the eqivalent amount of electric energy required to move the car throgh the same distance and is expressed as the miles per gallon. The powertrain blockset has a model that calculates the miles per gallon for all kinds of vehicle.
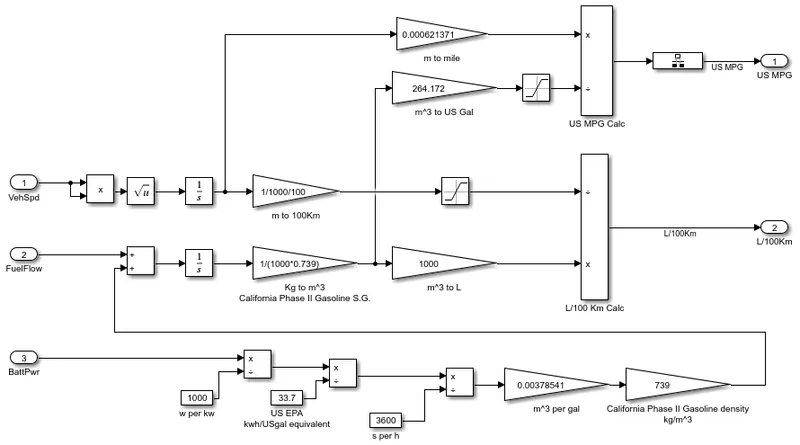 `
The above model takes the input of the Vehicle speed , Fuel flow and Battery power to calculate the fuel consumption and the equivalent battery consumption and calculates the miles per gallon.
Calculation of Vehicle Speed and Fuel Flow
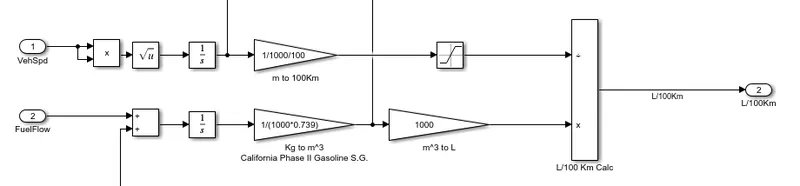
- The Vehicle speed is a important factor while considering the fuel consumption at that particular time,so to determine the fuel consumption throughout the drive cycle.
- To convert speed to Distance we can Integrate the velocity with respect to time. so we used the integral block as shown in the block diagram above.
- Then the Fuel flow is expressed as the mass flow rate (i.e) the amount of fuel at each moment in Kg/Sec. Now integrating this will result in the mass of the fuel and by using this 1 we convert it to the volume and by multiply by 1000 to get it in Litres.
- By comparing the two results we can get the amount of litre consumed to Run for 100km.
Calculation of Battery Power
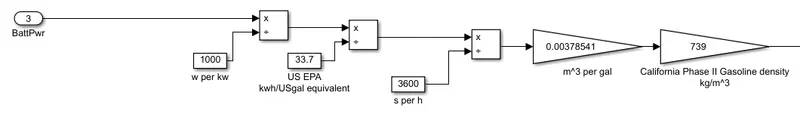
- The amount of Energy from battery power required to propel the vehicle Equivalent to that of the Engine is calculated here.
- The battery power is given in watts and it is converted to Kw by dividing with 1000.
- Then we convert the power into energy by multiplying with the time into KWh.
- Then we convert the Energy from kWh to equivalent energy in US gallon of automotive gasoline by dividing with 33.7. since we get the energy in US Gallons equal in KWh we are trying to get the energy of equivalent LIS Gallons per seconds and we do this by dividing with 3600 and we convert the hour to seconds.
- Then multiplying with 0.00378541 we convert the US Gallons per sec to the volume of the fuel flow in (mA3/ s) and then we multiply with 739 (California Phase Il Gasoline density) (i.e) mA3/s * kg/mA3 which gives the result as mass flow rate kg's.
- Then finally the Battery energy equivalent in kg/s is given as a input for the fuel flow parameter in order to find the equivalent US Gallons enegy and estimate the Miles per Gallons.
Calculation of Miles per Gallon
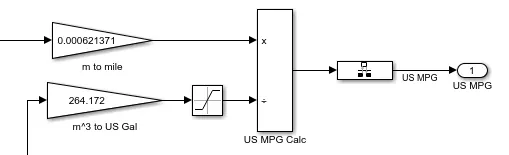
- Then the inputs from the vehicle speed (i.e) the Distance we found (in meters) is taken into the calculation and it is converted to the miles by multiplying with 0.000621371.
- Then the inputs from fuel flow (Battery energy + Fuel energy) taken in mA3 and is converted into equivalent US Gallons by multiplying with 264.172.
- Then the two inputs Miles covered and equivalent US Gallon is further divided and the result is got in Miles / Gallon.
____________________________________________________________________________________________________________
3. Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
Hybrid Electric Vehicle- A hybrid electric vehicle (HEV) is a type of vehicle that combines a conventional internal combustion engine (ICE) system with an electric propulsion system powered by battery. The presence of the electric powertrain is intended to achieve either better fuel economy than a conventional vehicle or better performance. Example of HEV is Toyota Prius, Land Rover Range Rover Sports HEV.
Powertrain Blockset™ provides fully assembled reference application models of automotive powertrains, including gasoline, diesel, hybrid, and electric systems. It includes a component library for simulating engine subsystems, transmission assemblies, traction motors, battery packs, and controller models. Powertrain Blockset also includes a dynamometer model for virtual testing. MDF file support provides a standards-based interface to calibration tools for data import.
Powertrain Blockset provides a standard model architecture that can be reused throughout the development process. You can use it for design tradeoff analysis and component sizing, control parameter optimization, and hardware-in-the-loop testing. You can customize models by parameterizing components in a reference application with your own data or by replacing a subsystem with your own model.
In the powertrain blockset there are six types of vehicle reference model including conventional ic engine type, electric and hybrid electric model which we can select from for the simulation. Here we can select the input parameters as we wish and can run the simulation to check the results.
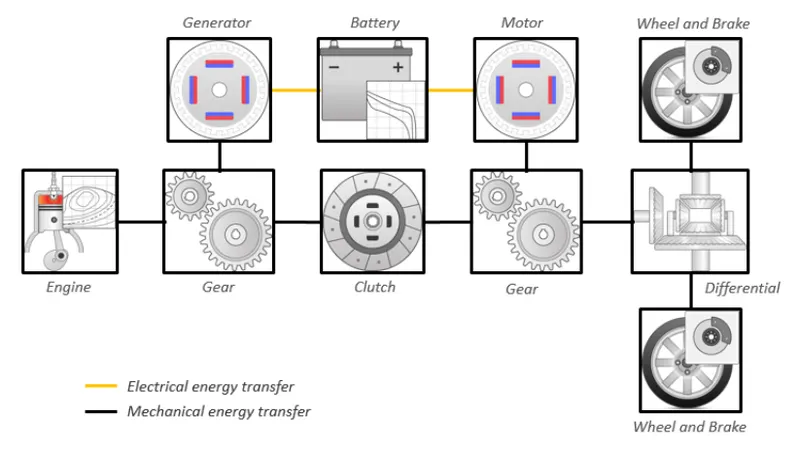
Here we used Hybrid electric vehicle multimode reference model for the simulation which is shown above. We performed the simulation three times by changing the values of Wind velocity and Grade for each case to compare the effect and change in efficiency or performance of the given HEV.
There are totally six which is created during the simulation which can be seen in the result below. Each plot shows a particular result and the plots are made in such a way that there is a cursor measurement and if we change the cursor on one plot the cursor moves on the otherplots too which paves way to study the result in a better way. The cursor enables us to study the behaviour of other result parameters corresponding to the acceleration of the vehicle.
Case1
The Total time for the simulation = 100 seconds
The Top speed of this cycle = 80 mph
Time to start deceleration = 50seconds
The Grade angle = 0 degrees
The wind velocity = 0 m/s
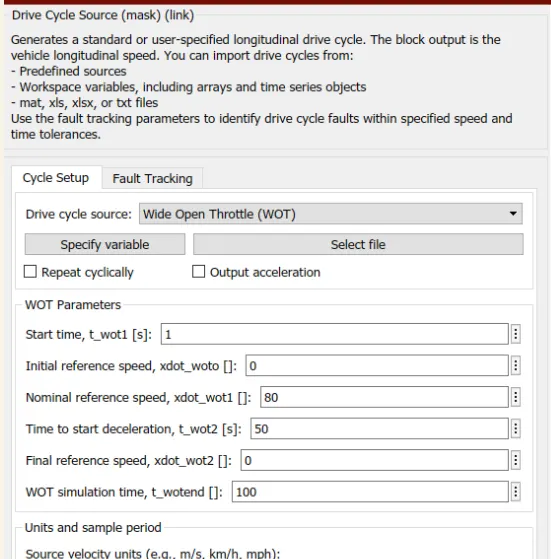
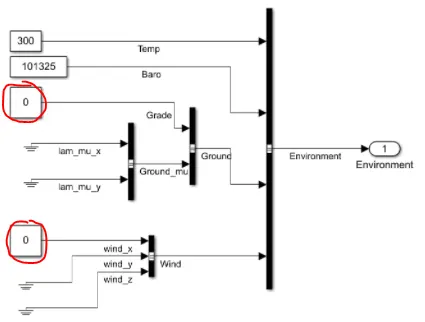
Result for Case1
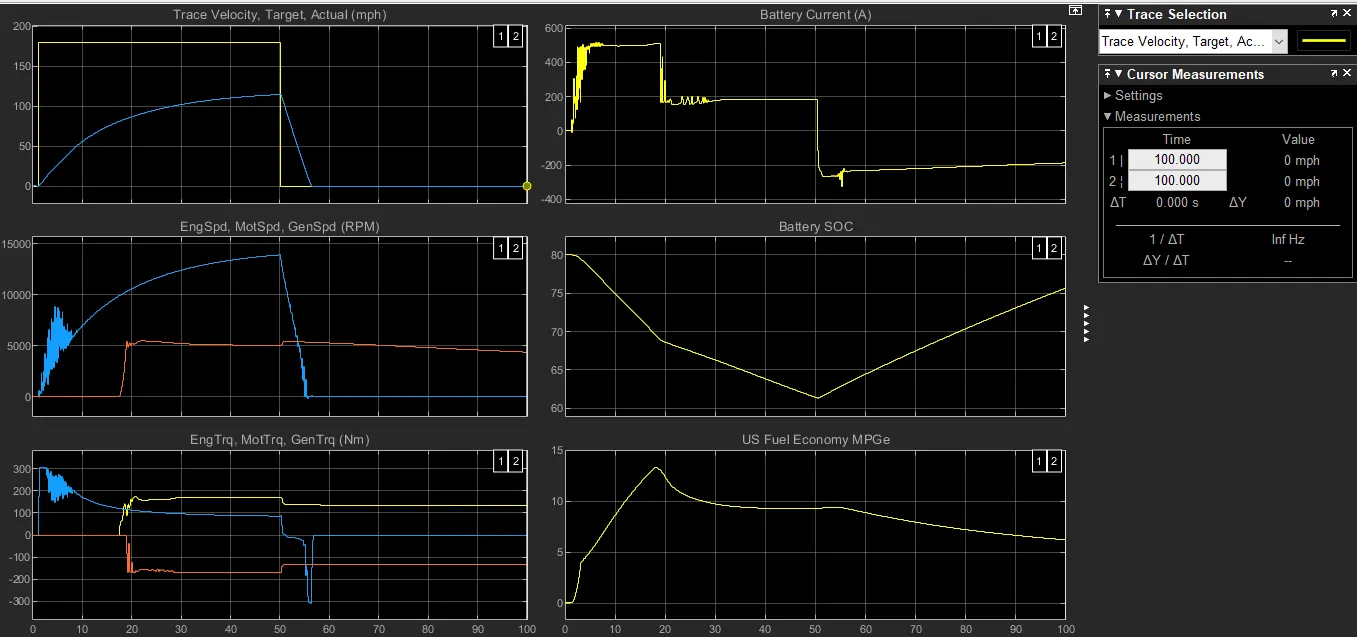
plot 1:
Shows the velocity of the vehicle with respect to the Drive cycle data with the Time scale on the x axis.
The acceleration time to reach 80 mph - 16.7 seconds
The deceleration time from 80 to minimum = 6.2 seconds
plot 2:
Shows the changes in speed of the Engine,motor and Generator in Rpm throughout the drive cycle.
Peak Engine speed = 4780 Rpm
Peak Motor speed = 9497 Rpm
Peak Generator speed = 13690 Rpm
plot 3:
Shows the Torque characteristics and its changes of engine,motor and generator in (Nm) throughout the drive cycle.
Peak Engine torque = 138.7 Nm
Peak Motor torque = 206.7 Nm
Peak Generator torque = 42.2 Nm
plot 4:
Shows the Battery Current values (A) and its changes for various acceleration inputs as per the Drive cycle.
The peak current discharge from the battery = 163.5A
The peak current charging to the battery = -150.86 A
Plot 5:
Shows the Battery state of charge SOC (%) and its changes corresponding to the driving inputs.
The state of charge decreased from 60% to 39.8% of charge in a time period of 49.3 seconds , for the specified driving conditions.
Plot 6:
Shows the Fuel Economy as Mile per Gallons for the corresponding input driving conditions.
The maximum miles that the car can run per gallon of fuel equivalent = 46 Miles,for the given vehicle at the specified driving conditions.
Case2
Total time for the simulation = 100 seconds
The Top speed of this cycle = 80 mph
Time to start deceleration = 50seconds
The Grade angle = 8 Degrees
The wind velocity = 10 m/s.
Result for Case2
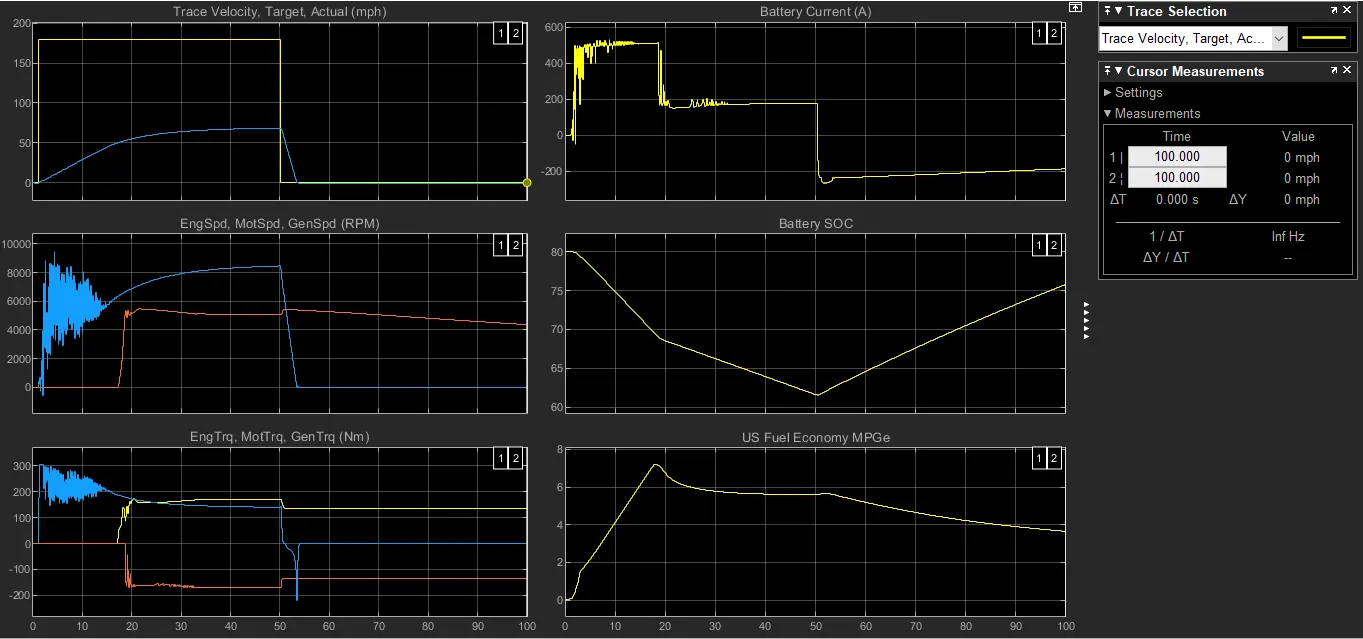
In all the results we can observe some changes from the previous case. Though the vehicle parameters and the drive cycle are the same ,here we have considered some changes in the environment blocks by adding some hill climb angles and wind velocity. The changes in the results are given below.
plot 1:
Shows the velocity of the vehicle with respect to the Drive cycle data with the Time scale on the x axis.
The top speed of 80 mph cannot be achieved as we have some additional forces acting and so the car can only run upto 67.2 mph
The acceleration time to reach top speed of 67.2 mph = 44.5 seconds
The deceleration time from 80 to minimum = 5.06 seconds
plot 2:
Shows the changes in speed of the Engine,motor and Generator in Rpm throughout the drive cycle.
Peak Engine speed = 4676 Rpm
Peak Motor speed = 8103.5 Rpm
Peak Generator speed = 12858.5 Rpm
plot 3:
Shows the Torque characteristics and its changes of engine,motor and generator in (Nm) throughout the drive cycle.
Peak Engine torque = 139.6 Nm ; Peak Motor torque = 206.4 Nm
Peak Generator torque = 48.2 Nm
plot 4:
Shows the Battery Current values (A) and its changes for various acceleration inputs as per the Drive cycle.
The peak current discharge from the battery = 167.6A
The peak current charging to the battery = -152.46 A
Plot 5:
Shows the Battery state of charge SOC (%) and its changes corresponding to the driving inputs.
The state of charge decreased from 60% to 25.98 % of charge in a time period of 49.3 seconds , for the specified driving conditions.
Plot 6:
Shows the Fuel Economy as Mile per Gallons for the corresponding input driving conditions.
The maximum miles that the car can run per gallon of fuel equivalent = 17.93 Miles,for the given vehicle at the specified driving conditions.
Final observation from the above two cases:
- We can see that the simulation 1 without the inclusion of hill climbing conditions and the wind drag velocity is much more efficient when compared to the simulation which includes the hill climbing conditions and the wind drag velocity.
- The vehicle was not able to achieve the required top speed though using the highest possible current discharge of that same battery used before.
- The state of charge also shows that the discharge is also high compared to the simulation 1
- The Fuel Economy is also down to half of the previous simulation.
- So one can say, it is evident that the efficiency of no load vehicle is high compared to the vehicle with additional loads acting on them and also we have visualized this using the Powertrain blockset.
_____________________________________________________________________________________________________________
4. Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
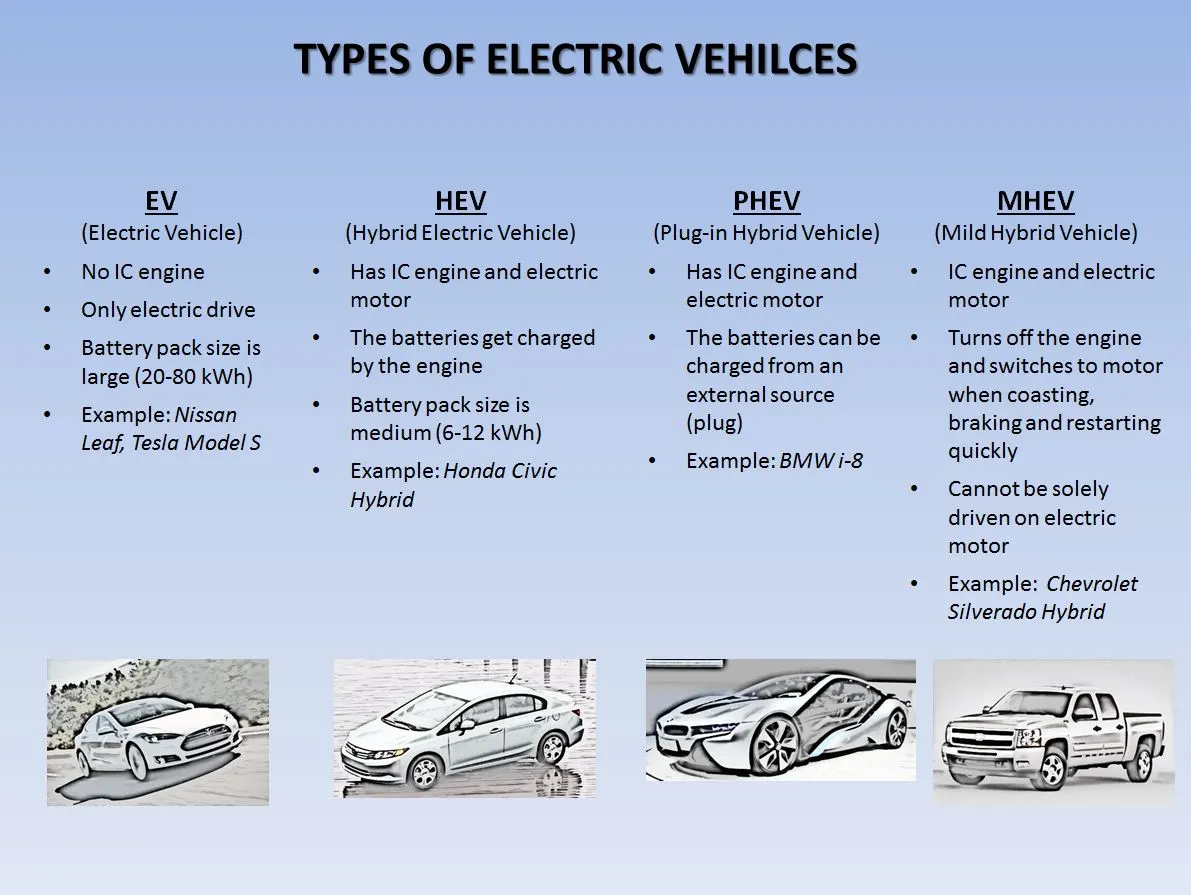
Reference model for the Fully electric and Hybrid electric vehicle is given below
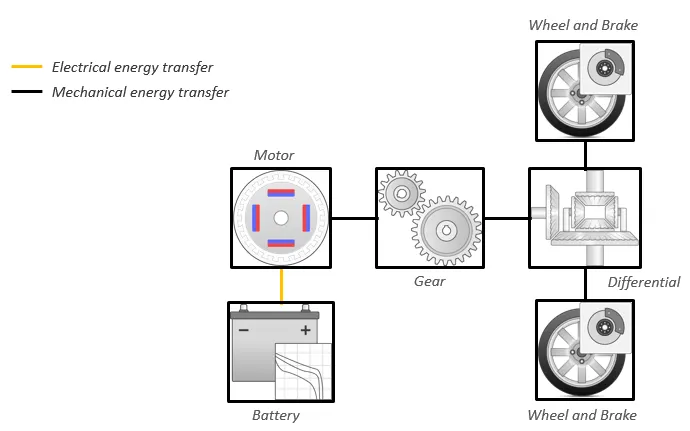
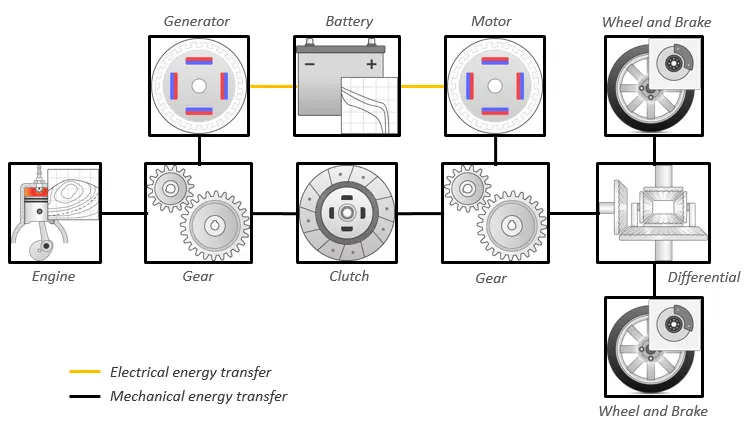
Note- Here the value of the each parameter like grade, wind velocity, pressure, temperature, battery module, etc are kept same for both EV and HEV vehicles to check the result of their effect of efficiency and performance. In both case for EV and HEV FTP 75 drive cycle is used for the simulation.
For Fully Electric Vehicle(Or BEV)
- Environment block has the external factors like grade, wind, temperature, pressure.
- For driver there is an input of reference drive cycle and the actual speed from the vehicle.
- In the controller block there exists sub blocks as electric control module.
- In passenger car there is only electric plant.
- In the scope block all the plots will be visualised.
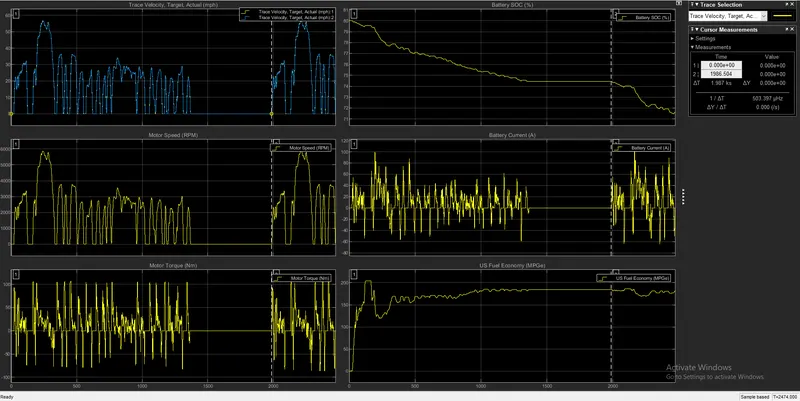
For Hybrid electric Vehicle(or HEV)
- Environment block has the external factors like grade, wind, temperature, pressure.
- For driver there is an input of reference drive cycle and the actual speed from the vehicle.
- In passenger car there is only electric plant, ic engine plant and generator plant.
- In the scope block all the plots will be visualised.
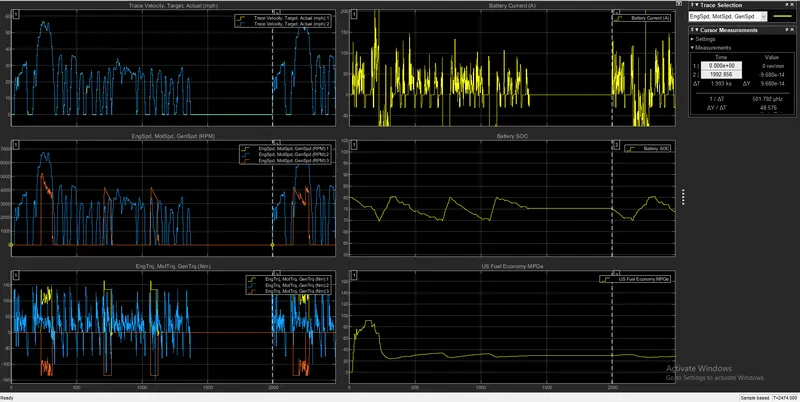
Final observation from the simulation
- As compared to the HEV the SOC for EV is continuosly discharge when compared to the HEV as in HEV there is both operations of IC and battery in HEV.
- As compared to HEV, EV has more fuel economy as it is totally runs on battery power and no fuel is supplied as in IC HEV.
- But if any grade is present at the final charge of the EV it cannot work with full efficiently as HEV, as in HEV it can be powred from IC engine.
- As compared to the HEV there are no emissions in this EV.
- An external charge is required once SCO of EV is zero but in HEV an IC can charge the battery of HEV.