Week-4 Challenge WOT Condition Part-2
Aim: To provide solutions for the following questions,
- What is the difference between the mapped and dynamic model of engine, motor and generator? How can you change the model type?
- How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
- Run the HEV ReferenceApplication with the WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
- Keeping all other parameters the same, compare the simulated results of hybrid and pure electric powertrains.
1 . What is the difference between the mapped and dynamic model of engine, motor and generator? How can you change the model type?
Mapped Model:
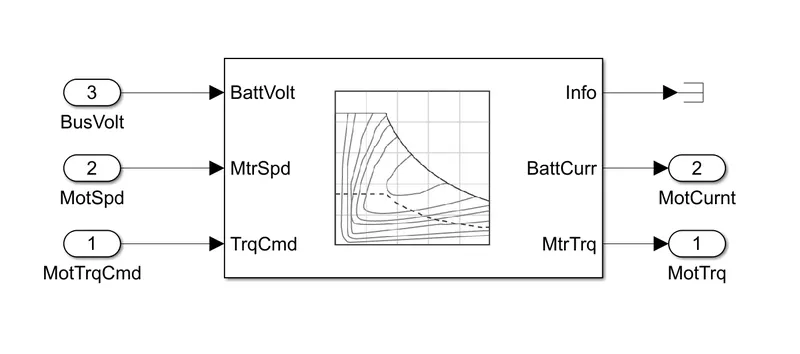
- The mapped model is one type where the data points are pre_assigned in lookup tables.
- The engine or motor torque required is sensed and the motor or engine block generates the requiered torque output just as required simply without considering the real time motor or engine, parameters
- The output values are stored for the corrresponding given input values of the engine motor and generator.
- The accuracy of this type is not that high but the simulation will be done in much less time as it does not run by real time parameters.
Dyanamic Model:
- The dyanamic model in other hand uses the combination of the outputs from various subsystems to generate the output.
- It runs by real time simulation where the required input from the drive cycle is taken and for that individiual real time simulation gets performed and summing all the results of the subsystem gives the output for the simulation.
- As per the drive cycle requirements the initial Bus voltage ,current is given along with the vehicle feedback so that it runs the actual simulation at that particuclar moment throught the drive cycle.
- The accuracy of this model is very high as it considers the real outputs from all the subsystem to generate the output.
- The simulation will take very long time to complete as it has so many individual simulations running by all the subsystem of the engine , motor/generator.
- The figure below shows the working phase of the dyanamic model.
Procedure : Open EV reference application model, then go to passenger car subsystem block from there open electric plant there we get both of the mapped and dynamic block systems.The below is the mapped model considered as default for EV vehicle application along with dynamic model which is comment out.
If we want to change the model we need to right click and select the variant, select label mode active choice then select MotGenEvDynamic.
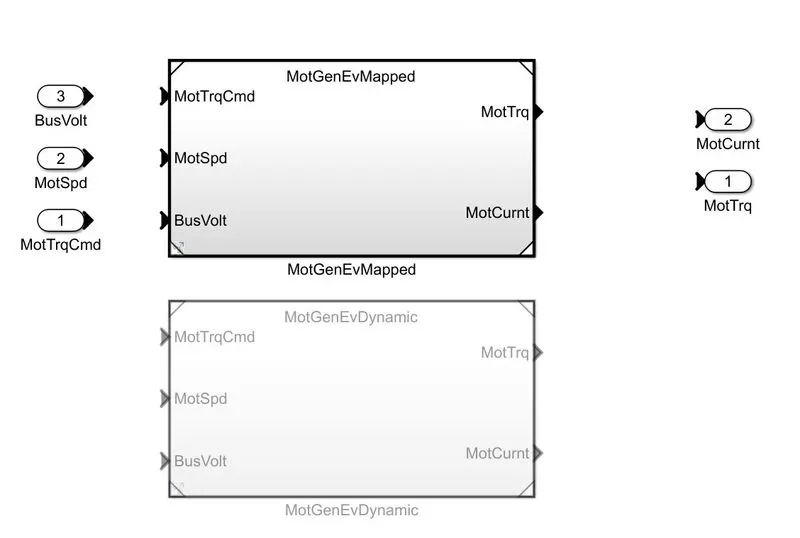
- Actual mapped model uses a mapped motor and inputs from the controller which gives output as battery currrent and motor torque.
- Dynamic model is an actual model going to represent the actual components of system . we can use any of the two models for vehicle design and modelling. It contains the Interior PM controller, three phase voltage source inverter and internal permanent magnet synchronous machine(PMSM).
Conclusion: so the difference between both the models and changing one model to another is explained.
2 . How does the model calculate miles per gallon? Which factors are considered to model fuel flow?
Fuel Efficiency is an important parameter that helps determine the engine efficiency of the Vehicle. In case of the electric vehicle, Battery capacity (state of charge) is converted into miles per gallon for the Vehicle performance comparison.
Miles per gallon is different for every category of Vehicle. Here we are going to look into different categories of vehicles, one is Hybrid Electric Vehicle and the other one is a pure Electric Vehicle.
Hybrid Electric Vehicle Model:-
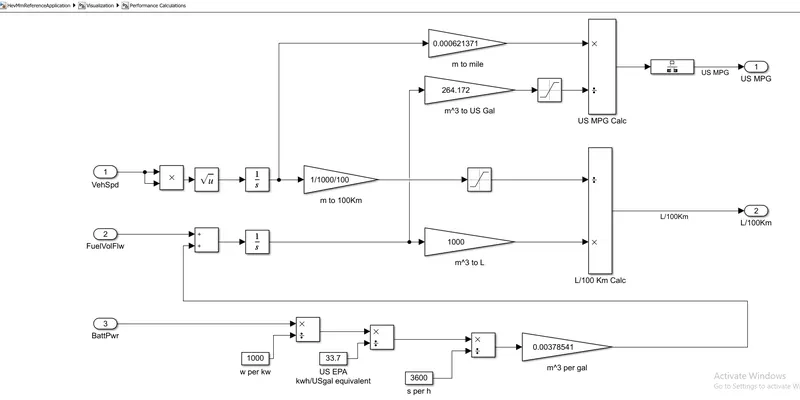
Based on the model it is observed that the Miles per Gallon is calculated based on 3 important categories,
a) Battery Power
b) Fuel Volume Flow rate
c) Vehicle Speed
Battery Power:
Based on the observation from the block diagram, the following steps have been carried out to convert the output value in m^3 per gal.
i) First the output value is divided by 1000, so that w can be converted into Kw. (product block is used)
ii) Kwh/USgal equivalent is obtained by dividing the end result by 33.7. (product block is used)
iii) Then Kwh to Kws is obtained by 3600. (product block is used)
iv) Finally using the Gain block the obtained result is multiplied with 0.0037 to get the values in m^3 per gal.
Fuel Volume Flow rate:
i) The value of the Fuel volume flow rate is added along with output obtained from the Battery power (m^3 per gal) using the sum block.
ii) The output obtained from the sum block is then using the Integrator block to m^3.
iii) The m^3 is converted into L by multiplying 1000 with it. Another output (US Gal) is also obtained by multiplying 264.17. This is followed by connecting it to the "Saturation" block.
Vehicle Speed:
i) Vehicle Speed is also an important parameter to determine the Fuel efficiency of the vehicle. Here in this block, it is observed that in order to avoid the negative sign in the input Vehicle speed by splitting the values and multiply the same using the product block. The same is taken square root (using root square block) to attain the same value without the negative sign. This is then followed by an integrator block to obtain the distance. This distance (in meters) value is diverted then into 2 routes one is to obtain the km and the other is a mile.
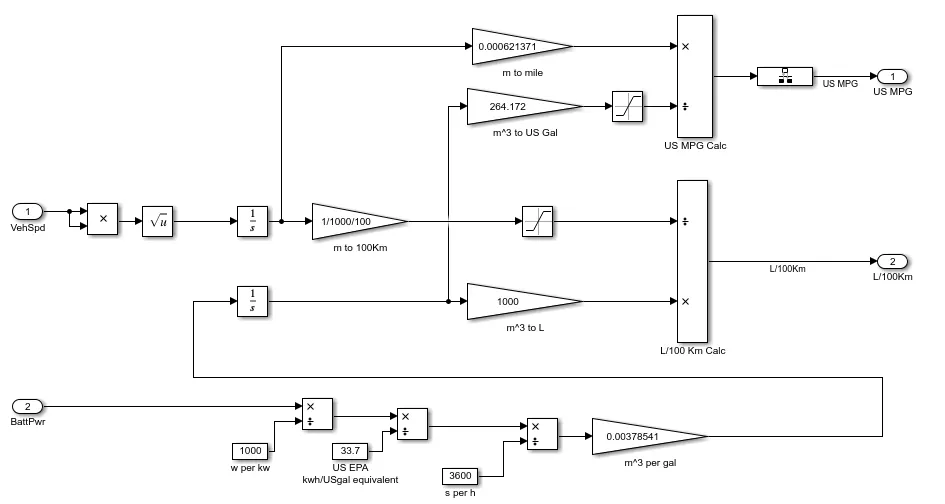
In the pure EV, the Miles per gallon is determined only by 2 factors,
a) Vehicle Speed
b) Battery Power
This is shown in the below model. The procedure to calculate the miles per gallon is the same.
3. Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
- A hybrid electric vehicle (HEV) is a type of hybrid type that combines a conventional Internal combustion engine (ICE) system with an electric propulsion system
- The presence of the electric powertrain is intended to achieve either better fuel economy than a conventional vehicle or better performance.
- Example of HEV is Toyota Prius.
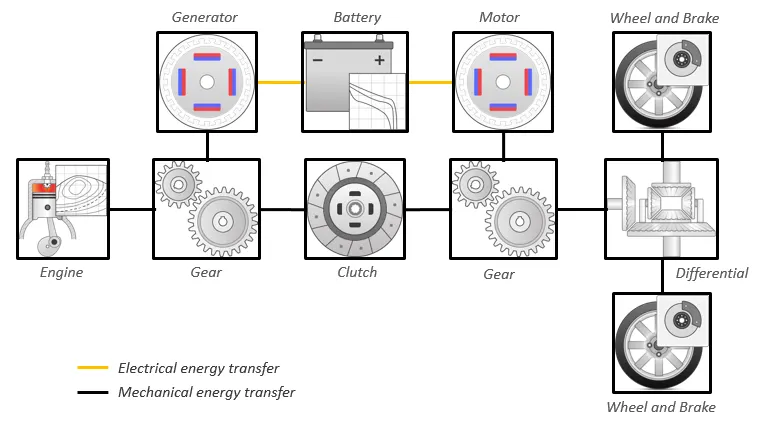
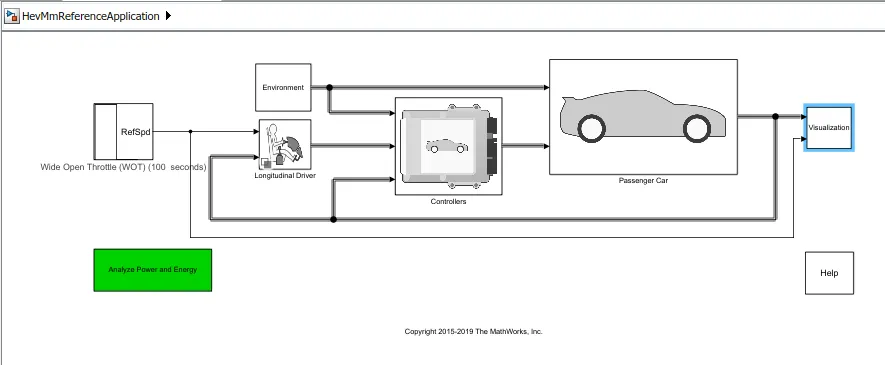
- In the powertrain blockset we have selected the hybrid electric vehicle and this is the simulink model .
- Here we can select the input parameters as we wish and we can Run the simulation to check the results.
Case 1:-
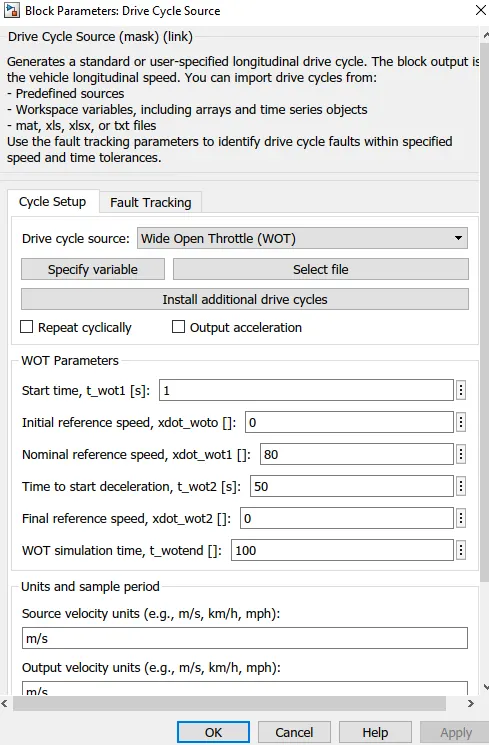
Simulation condition:-
The simulation is done for Hybrid electric vehicle with Wide open Throttle Drive cycle.The Total cycle time = 100 seconds
The Top speed of this cycle = 80 mph
Time to start deceleration = 50seconds
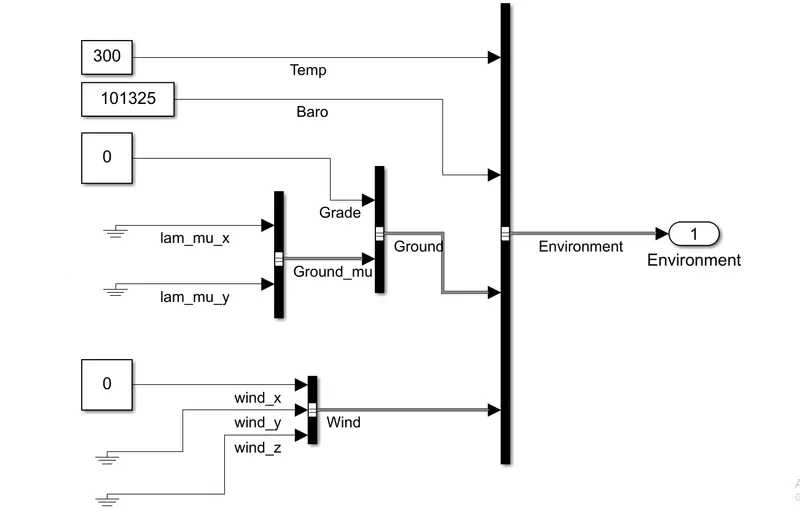
The Grade angle = 0 degrees
The wind velocity = 0 m/s
Environment block:-
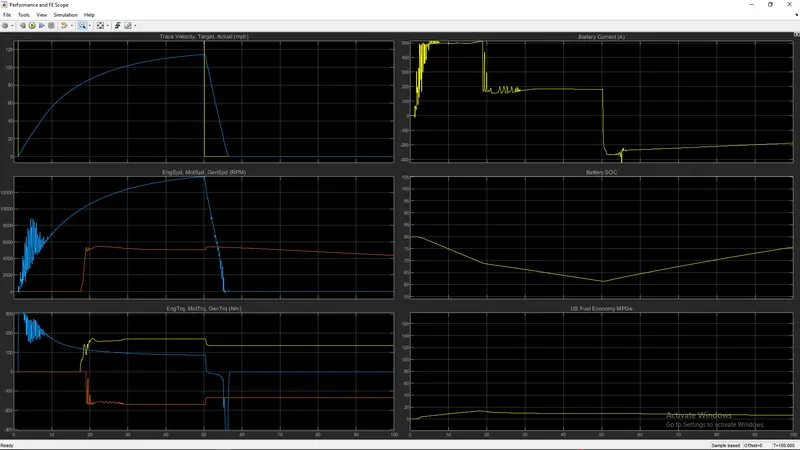
- The above figure shows the results for the simulation and there are totally six plots in them.
- Each plot shows a particular result and the plots are made in such a way that ,there is a cursor measurement and if we change the cursor on one plot the cursor moves on the otherplots too which paves way to study the result in a better way.
- The cursor enables us to study the behaviour of other result parameters corresponding to the acceleration of the vehicle.
plot 1:
Shows the velocity of the vehicle with respect to the Drive cycle data with the Time scale on the x axis.
The acceleration time to reach 80 mph - 16.7 seconds
The deceleration time from 80 to minimum = 6.2 seconds
plot 2:
Shows the changes in speed of the Engine,motor and Generator in Rpm throughout the drive cycle.
Peak Engine speed = 4780 Rpm
Peak Motor speed = 9497 Rpm
Peak Generator speed = 13690 Rpm
plot 3:
Shows the Torque characteristics and its changes of engine,motor and generator in (Nm) throughout the drive cycle.
Peak Engine torque = 138.7 Nm
Peak Motor torque = 206.7 Nm
Peak Generator torque = 42.2 Nm
plot 4:
Shows the Battery Current values (A) and its changes for various acceleration inputs as per the Drive cycle.
The peak current discharge from the battery = 163.5A
The peak current charging to the battery = -150.86 A
Plot 5:
Shows the Battery state of charge SOC (%) and its changes corresponding to the driving inputs.
The state of charge decreased from 60% to 39.8% of charge in a time period of 49.3 seconds , for the specified driving conditions.
Plot 6:
Shows the Fuel Economy as Mile per Gallons for the corresponding input driving conditions.
The maximum miles that the car can run per gallon of fuel equivalent = 46 Miles,for the given vehicle at the specified driving conditions.
Case 2:-
Simulation Condition:
The simulation is done for Hybrid electric vehicle with Wide open Throttle Drive cycle.
The Total cycle time = 100 seconds
The Top speed of this cycle = 80 mph
Time to start deceleration = 50seconds
The Grade angle - 8 Degrees
The wind velocity = 10 m/s.
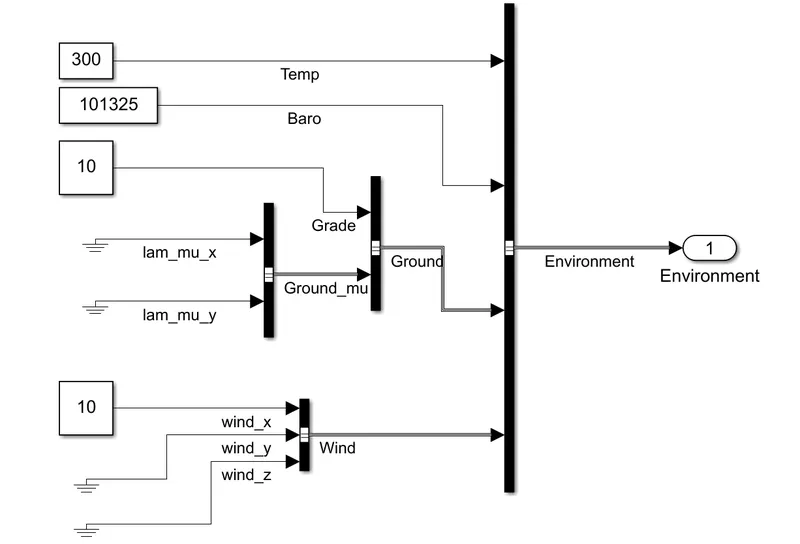
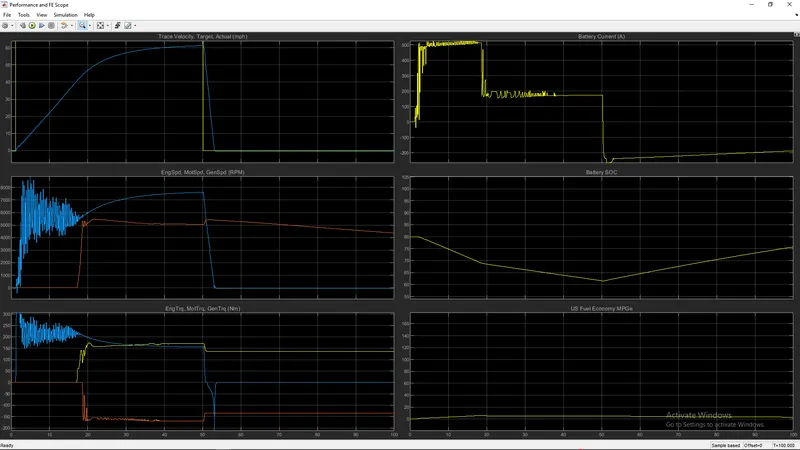
- In all the results we can observe some changes from the previous case
- Though the vehicle parameters and the drive cycle are the same ,here we have considered some changes in the environment blocks by adding some hill climb angles and wind velocity.
- The changes in the results are given below.
plot 1:
Shows the velocity of the vehicle with respect to the Drive cycle data with the Time scale on the x axis.
The top speed of 80 mph cannot be achieved as we have some additional forces acting and so the car can only run upto 67.2 mph
The acceleration time to reach top speed of 67.2 mph = 44.5 seconds
The deceleration time from 80 to minimum = 5.06 seconds
plot 2:
Shows the changes in speed of the Engine,motor and Generator in Rpm throughout the drive cycle.
Peak Engine speed = 4676 Rpm
Peak Motor speed = 8103.5 Rpm
Peak Generator speed = 12858.5 Rpm
plot 3:
Shows the Torque characteristics and its changes of engine,motor and generator in (Nm) throughout the drive cycle.
Peak Engine torque = 139.6 Nm ; Peak Motor torque = 206.4 Nm
Peak Generator torque = 48.2 Nm
plot 4:
Shows the Battery Current values (A) and its changes for various acceleration inputs as per the Drive cycle.
The peak current discharge from the battery = 167.6A
The peak current charging to the battery = -152.46 A
Plot 5:
Shows the Battery state of charge SOC (%) and its changes corresponding to the driving inputs.
The state of charge decreased from 60% to 25.98 % of charge in a time period of 49.3 seconds , for the specified driving conditions.
Plot 6:
Shows the Fuel Economy as Mile per Gallons for the corresponding input driving conditions.
The maximum miles that the car can run per gallon of fuel equivalent = 17.93 Miles,for the given vehicle at the specified driving conditions.
Observation:
- The simulation results for both the cases is found and we can see that the simulation 1 without the inclusion of hill climbing conditions and the wind drag velocity is much more efficient when compared to the simulation which includes the hill climbing conditions and the wind drag velocity.
- The vehicle was not able to achieve the required top speed though using the highest possible current discharge of that same battery used before.
- The state of charge also shows that the discharge is also high compared to the simulation 1
- The Fuel Economy is also down to half of the previous simulation.
- So one can say, it is evident that the efficiency of no load vehicle is high compared to the vehicle with additional loads acting on them and also we have visualized this using the Powertrain blockset.
4 .Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
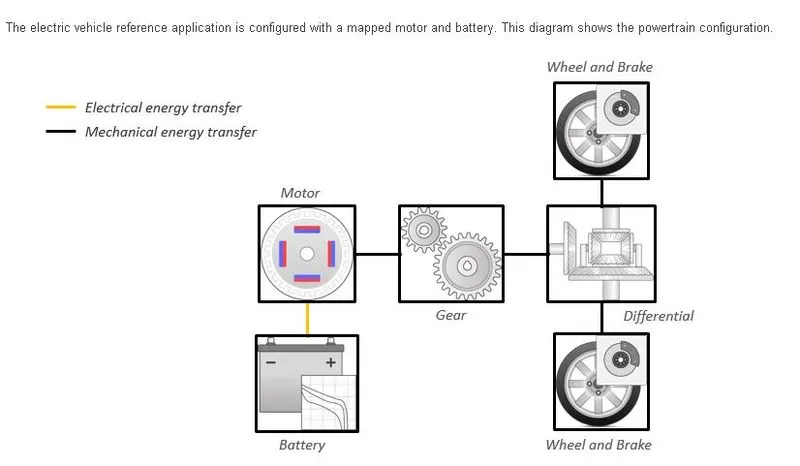
EV image showing vehicle components involved:
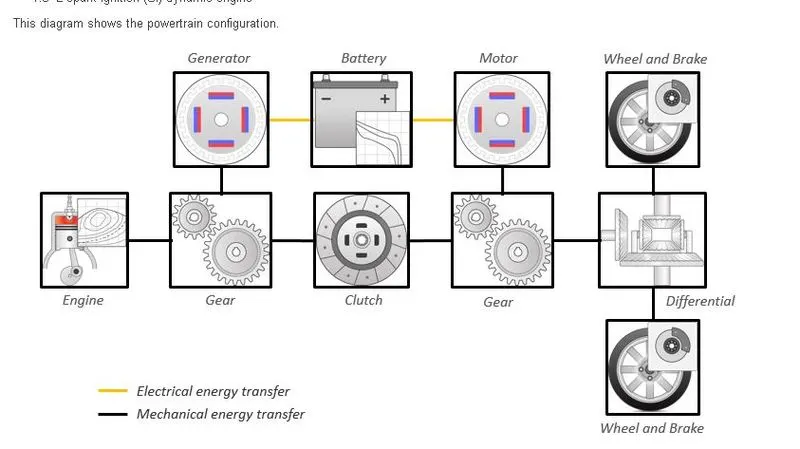
HEV image showing vehicle components involved:
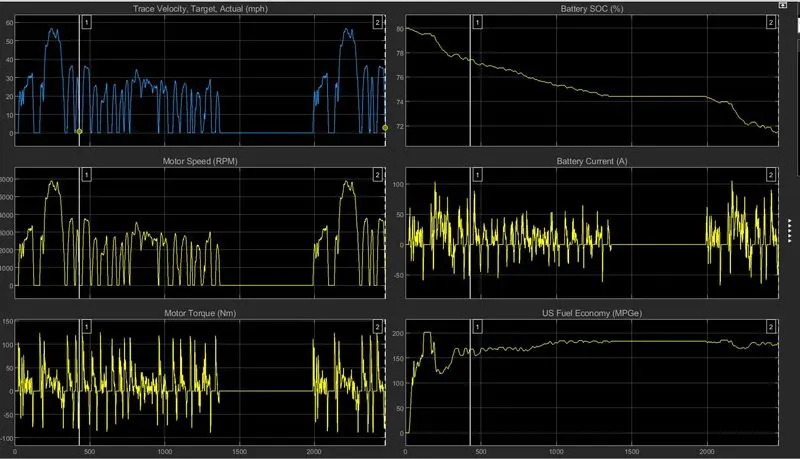
Output simulation result of EV vehicle with FTP 75 drive cycle as default keeping all the other parameters same:
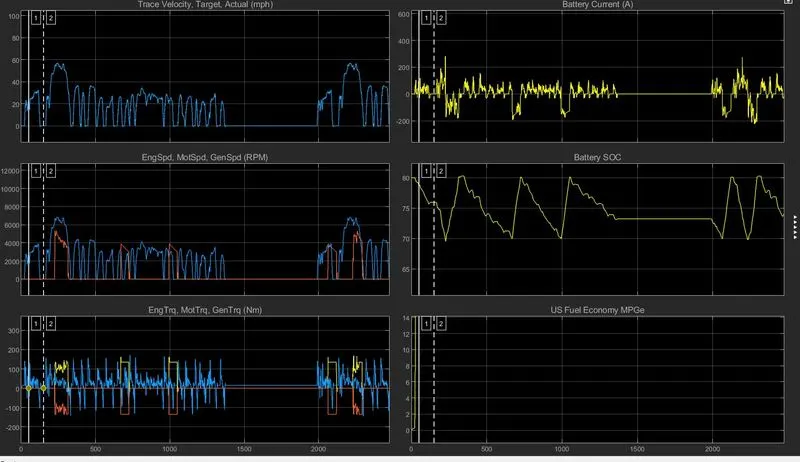
Output simulation result of HEV vehicle with FTP 75 drive cycle as default keeping all the other parameters same:
Comparision of results of HEV & EV with FTP Drive cycle keeping all the parameters same as default :
1)(A)Trace velocity of EV: Both the trace & target velocities are overlapping each other following the FTP 75 drive cycle
(B)Trace velocity of HEV: Both the trace & target velocities are overlapping each other following the FTP 75 drive cycle
2)(A)Motor speed of EV(RPM): The motor maximum speed is 5800 rpm following the FTP 75 drive cycle .
(B)Motor speed of HEV(RPM): The motor maximum speed is 7000 rpm following the FTP 75 drive cycle where as the engine & generator speeds are overlapping each other with the maximum value of 5500rpm might be used less to operate the vehicle compared to motor.
3)(A)Motor torque of EV(Nm): Torque reached to a maximum value of 130Nm when the vehicel is at initial starting condition at speed zero as per the input drive cycle of FTP 75 . Following the drive cycle the torque is less when the vehicle reaches to the maximum speed where ever in the drive cycle and with the decelearation of vehicle the torque is reduced to zero and reaches to negative value from there it has again able to reach its maximum value with the vehicle coming to zero speed or at vehicle intial standstill condition.
(B)Motor torque of HEV(Nm): Motor torque maximum at vehicle starting condition will be reduced as the vehicle speed increases following the drive cycle. Here in HEV apart from the motor, engine with generator is also operated to drive the vehicle as per the torque and power requirement of vehicle but both torques values are positve and negative always in all the instants where it is required to run the vehicle.
4)(A)Battery SOC of EV (%):The battery state of charge (soc) will decrease as long as the vehicle is running using the battery power but whenever the vehicle is decelerating the battery will be recharged again upto an extent which depends on the deceleration time of the vehicle called regenerative braking mode.
(B)Battery SOC of HEV (%) : Here the battery operating regions are set between 80% -70% and may be useda thermistor control method to operate the battery charging and discharging limits. Here the vehicle can use both the battery power and fuel at a time according to the power requirement. According to the vehicle operating mode either the battery state of charge or the fuel is going to get consumed by the vehicle. But whenever the vehicle is decelerating the battery will be recharged again upto an extent which depends on the deceleration time called regenerative braking mode of the vehicle and also the battery charging power is supplied by the vehicle when it is running with the engine mode from the generator so the battery can be recharged in both ways either in regenerative braking mode or in engine mode.
5)Battery current of both EV & HEV in (Amp): The vehicle draws a less, moderate to high current according to the acceleration requirement of vehicle at any instant in the drive cycle when the vehicle is operated in EV mode but the battery current is increased again when the battery is recharged either by the regenerative mode or by the engine generator. But the vehicle consumes fuel when it is operated in engine mode. of 500 amp to accelerate the vehicle as wot condition and the current value has come down to 180 ampere before the vehicle decelerates and again starts building from a negative 250 amps to zero value in the regenerative braking mode.6)US fuel economy (MPG): The fuel economy is almost close to zero and never increased through out the time period.
Note: In HEV vehicle as per the battery operating regions set by the controller the battery charging and discharging currents are inbetween (-250 amp to 300 amp) maintained through out the drive cycle.
6)(A)Fuel Economy of EV (Miles per gallon) : Fuel economy initially started from zero and reached to a maximum 200 after it is continued inbetween 150 to 180 as per the drive cycle pattern. so any where the fuel economy depends on the driving cycle.
(B)Fuel Economy of HEV (Miles per gallon) : Fuel economy only able to reach 14(MpEG) and maintained from initial zero condition because the vehicle operated with both battery mode and engine mode simultaneously and alternatively.
Conclusion:
1)Velocity of the vehicle is attained in both EV and HEV modes according to the input drive cycle.
2)Maximum power and torque requirement of vehicle is satisfied only when the vehicle operated in HEV mode where both motor and engine can operate at the same time which is not the case with EV vehicle.
3)Battery Soc and Battery current is well maintained by implementing the suitable cotroller method and also the drive cycle pattern of the vehicle.
4)Fuel economy is maximum when the vehicel operated in EV mode only and less when operated either with engine mode or by using both engine and battery modes simultaneously.