Week-4 Challenge WOT Condition Part-2
Aim: To understand the basics of Powertrain Blockset.
Objective:
- To write what is the difference between the mapped and dynamic model of engine, motor and generator? How the model type can be changed?
- To describe how does the model calculate miles per gallon? and which factors are considered to model fuel flow?
- To run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block. Comment on the results.
- To compare the simulated results of hybrid and pure electric powertrains, keeping all other parameters same.
Powertrain Blockset
Powertrain Blockset provides fully assembled reference application models of automotive powertrains, including gasoline, diesel, hybrid, and electric systems. It includes a component library for simulating engine subsystems, transmission assemblies, traction motors, battery packs, and controller models. Powertrain Blockset also includes a dynamometer model for virtual testing. MDF file support provides a standards-based interface to calibration tools for data import.
Powertrain Blockset provides a standard model architecture that can be reused throughout the development process. We can use it for design tradeoff analysis and component sizing, control parameter optimization, and hardware-in-the-loop testing. We can customize models by parameterizing components in a reference application with our data or by replacing a subsystem with our model.
To model a powertrain system for our project, we can select a reference application based on the powertrain type. Each reference application includes plant models, controllers, a longitudinal driver, and drive cycle data.
The reference applications come with a Simulink Projects configuration. Simulink Projects enables management and version control for top-level model files, component model files, and scripts.
Reference applications serve as a starting point for our system model. To tailor a reference application to our powertrain project, parameterize the components in the reference application using data from a domain-specific tool, a test bench, or a vehicle. Depending on our application and powertrain configuration, we might need to select the type of component models and further customize the system model.
The component library in Powertrain Blockset provides blocks of physical systems and controllers for:
- Propulsion
- Transmission
- Drivetrain
- Energy storage
- Longitudinal vehicle dynamics
- Drive cycle data and longitudinal driver
All the models in Powertrain Blockset, including the reference applications and components in the library, are fully open for customization. We can use Simulink Projects to manage model variants including variant selection, version management, and comparison.
Powertrain Blockset provides two types of combustion engine models: mapped and dynamic. Mapped engines represent macro engine behaviour as a set of lookup tables (brake torque, fuel flow, air mass flow, exhaust temperature, efficiency, and emissions) as functions of commanded load and measured engine speed. Dynamic engines decompose engine behaviour into individual component models that account for engine dynamics, most notably intake airflow and turbocharger dynamics.
We can switch between engine model types based on your application. Dynamic engine models are suitable for designing control, estimator, and diagnostic algorithms that depend on dynamic subsystem states, for example, in closed-loop AFR control algorithm development. Mapped engine models are suitable for analysis and design activities that do not require engine subsystem dynamic characteristics, for example, in engine and transmission powertrain matching analysis for fuel economy, emissions, and performance tradeoffs.
Both the SI and CI engine models run in real-time for hardware-in-the-loop (HIL) testing.
Q1. a) What is the difference between the mapped and dynamic model of engine, motor and generator?
|
Mapped
|
Dynamic
|
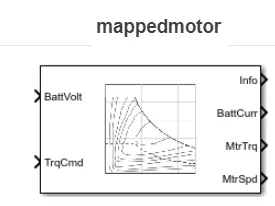
Mapped Model for Electric Motor
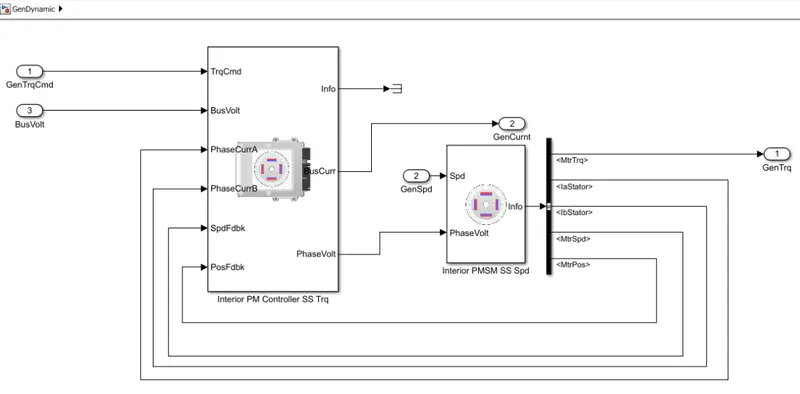
Dynamic Model for Electric Motor
Q1. b) How can you change the model type?
We can switch between mapped and dynamic model types based on the application:
- Open the powertrain module blocks for the required vehicle.
- Click on passenger car/vehicle block and select an electric plant or engine.
- Right-click on Engine/EV motor/generator based on the vehicle model and select subsystem & model reference.
- In subsystem & model reference selecting option convert to the variant subsystem.
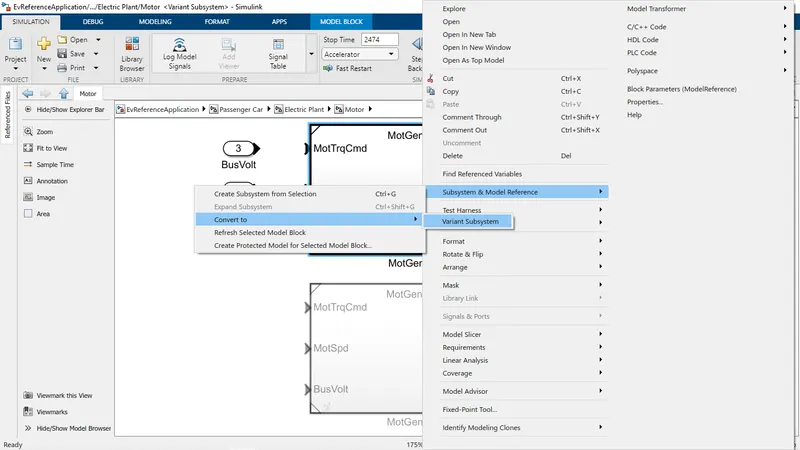
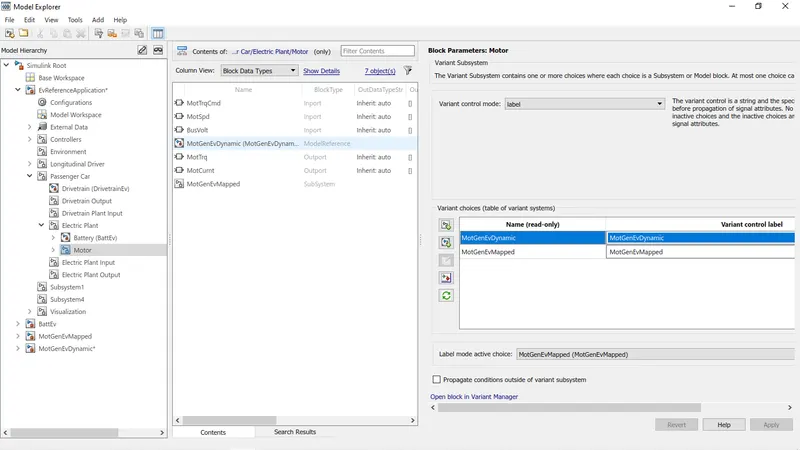
- Then by using model explorer
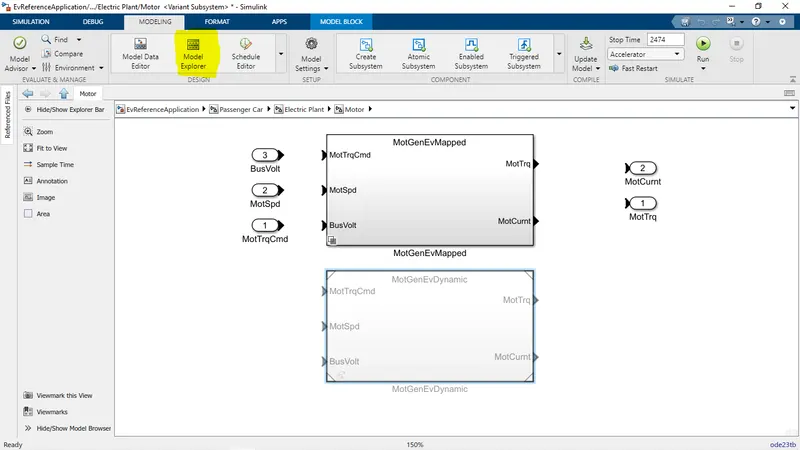
- The model type can be changed as shown in the below image.
Q2. a) How does the model calculate miles per gallon?
Miles per Gallon: Miles per gallon (MPG) is a fuel economy rating determined by how far a car can travel using one gallon of gasoline or diesel for a conventional IC Engine vehicle. In the case of an electric vehicle, this is a measure of how much electrical energy is consumed by the battery pack to travel a fixed distance.
Per gallon of gasoline-equivalent for electric cars:
Burning one gallon of gas produces 121.3MJ. To generate the same amount of heat by way of electricity, it takes 33.7 kilowatt-hours (kWh). So if an electric vehicle can travel 100 miles on 33.7 kWh of electricity, then we can rate it at as 100 MPGe.
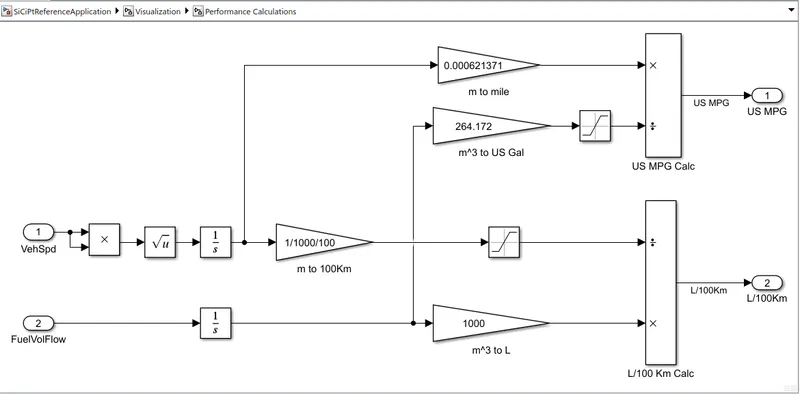
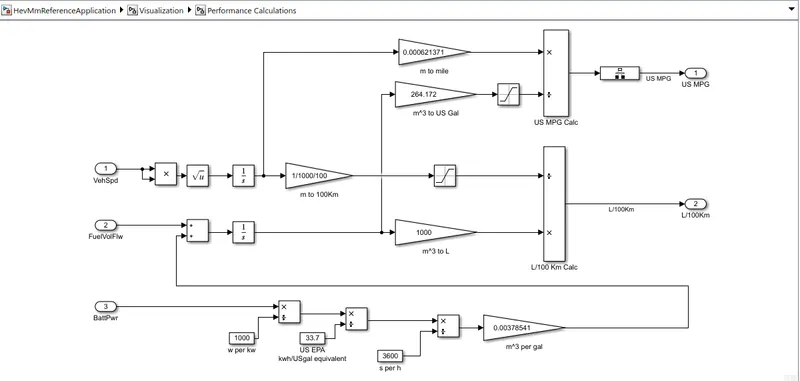
The power train block set has a model that calculates the miles per gallon for all kinds of vehicles.
- For Conventional Vehicle
- For hybrid electric vehicles-
- For electric vehicles-
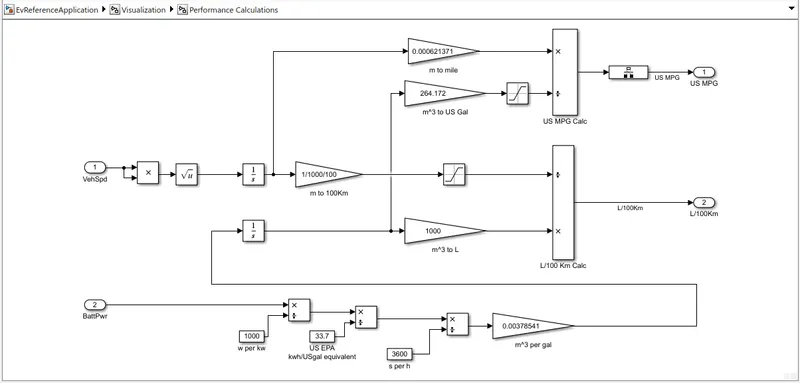
The model takes an input of vehicle speed, fuel flow and battery power to calculate fuel consumption and the equivalent battery consumption to calculate the miles per gallon.
Vehicle speed & Fuel flow:
- Vehicle speed is an important factor while considering the fuel consumption at that particular time, to determine fuel consumption throughout the drive cycle.
- To convert speed to Distance, Integrate speed with time doing the same of converting the velocity to get the distance covered by integrating.
- Then the Fuel flow is expressed as the mass flow rate (i.e) the amount of fuel at each moment in kg/Sec. Now integrating this will result in the mass of the fuel and by using this 1/(1000*0.739) we convert it to the volume and multiply by 1000 to get it in Litres.
- By comparing the two results we can get the amount of litre consumed to Run for 100km.
Battery Power:
- The amount of energy from battery power required to propel the vehicle Equivalent to that of the Engine is calculated here.
- The battery power is given in Watts and it is converted to kW by dividing with 1000.
- Then converting the Energy from kWh to equivalent energy in US gallon of automotive gasoline by dividing with 33.7. since we get the energy in US Gallons equal in kWh, to get the energy of equivalent US Gallons per seconds dividing with 3600 and we convert the hour to seconds.
- Then multiplying with 0.00378541 converting the US Gallons per sec to the volume of the fuel flow in (m3/s) and then we multiply with 739 (California Phase II Gasoline density) (i.e) m3s×kgm3m3s×kgm3 which gives the result as mass flow rate kg/s.
- Then finally the Battery energy equivalent in kg/s is given as an input for the fuel flow parameter to find the equivalent US Gallons energy and estimate the Miles per Gallons.
Calculating Miles per Gallon:
- The inputs from the vehicle speed (i.e) the Distance we found (in meters) are taken into the calculation and it is converted to the miles by multiplying with 0.000621371.
- Then the inputs from fuel flow (Battery energy + Fuel energy) taken in m^3 and are converted into equivalent US Gallons by multiplying with 264.172.
- Then the two inputs Miles covered and equivalent US Gallon are further divided and the result is got in Miles / Gallon.
Q2. b)Which factors are considered to model fuel flow?
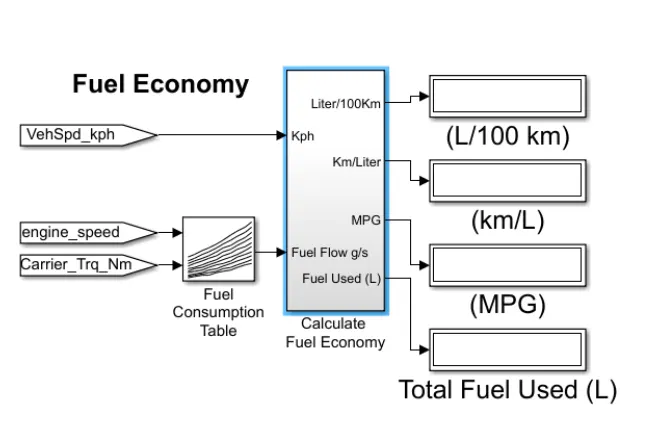
Factors considered in the model fuel flow are Fuel Economy and Fuel Consumption:
Fuel Economy:
The fuel economy of an automobile relates distance travelled by a vehicle and the amount of fuel consumed. Consumption can be expressed in terms of volume of fuel to travel a distance, or the distance travelled per unit volume of fuel consumed. Since fuel consumption of vehicles is a significant factor in air pollution, and since the importation of motor fuel can be a large part of a nation's foreign trade, many countries impose requirements for fuel economy. Different methods are used to approximate the actual performance of the vehicle. The energy in the fuel is required to overcome various losses (wind resistance, tire drag, and others) encountered while propelling the vehicle, and in providing power to vehicle systems such as ignition or air conditioning. Various strategies can be employed to reduce losses at each of the conversions between the chemical energy in the fuel and the kinetic energy of the vehicle. Driver behaviour can affect fuel economy; manoeuvres such as sudden acceleration and heavy braking waste energy. However electric cars do not directly burn fuel, and so do not have fuel economy per se, but equivalence measures.
Note:- In the case of pure Electric Vehicle (EV) the term Miles Per Gallon Equivalent (MPGe) is used.
While the use of MPG and other measures of fuel efficiency work well for liquid fuels, MPG is not a useful measurement for electric, compressed natural gas, liquid natural gas, or hydrogen fuel cell vehicles since those sources of power are not sold by the gallon. This makes it difficult to compare fuel economies of vehicles using alternative fuels. This problem is resolved by introducing a gasoline gallon equivalent (GGE) or diesel gallon equivalent (DGE) - defined to be the amount of an alternative fuel needed to equal the amount of energy in one gallon of gasoline or diesel, respectively. The definitions used by the United States for fuel economy purposes.
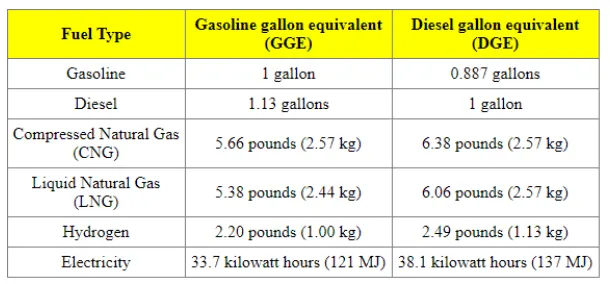
The above table contains the amount of various alternative fuels equal in energy to one gallon of gasoline or one gallon of diesel (GGE or DGE). Units are first given in the official government-defined units and then in SI (metric) units.
Here the value 33.7 kWh is the battery power required to get the energy equivalent to the energy which is obtained by consuming the 1 gallon of gasoline. It is calculated by the United States Environmental Protection Agency (EPA).
A study about electric fuel conversion is provided through the reference mentioned in the report.
Below are the sample Stickers Provided by EPA for some HEV & EV vehicles:-
1) For HEV: HEV has both MPGe & MPG notations cause it works on both conventional gasoline engine & Battery Electic power as well.
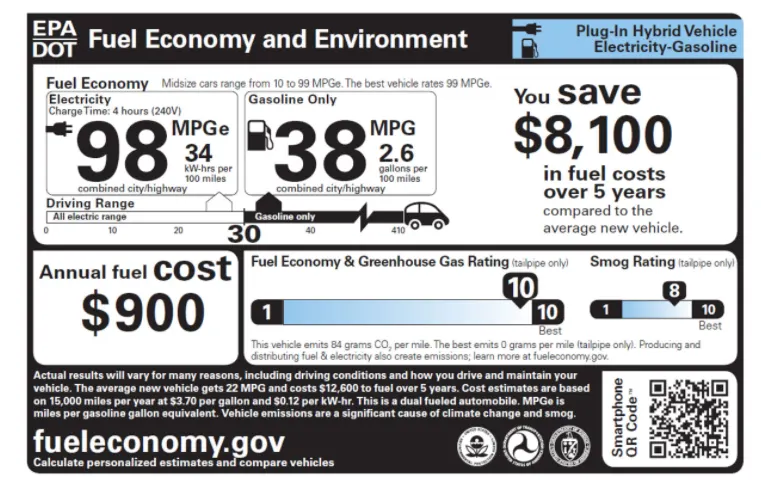
2) For pure EV: Pure EV has only MPGe notation cause it works on Battery alone.
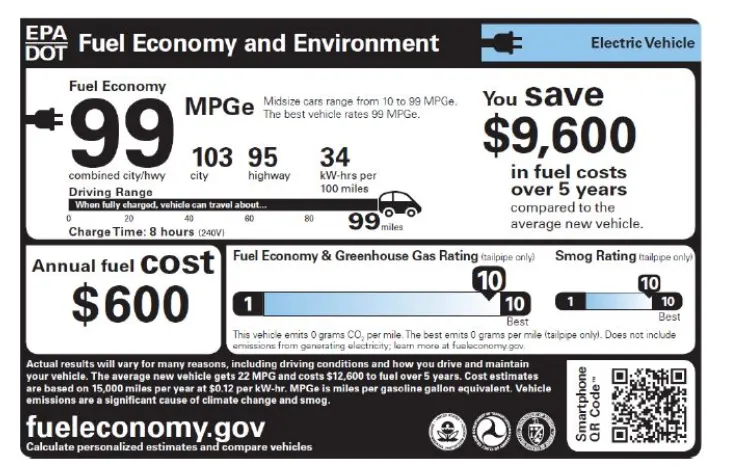
All the notations are discussed through the references mentioned in the report below.
Q3. a) Run the HEV ReferenceApplication with WOT drive cycle.
Hybrid Electric Vehicle:
A hybrid electric vehicle (HEV) is a type of hybrid vehicle that combines a conventional internal combustion engine (ICE) system with an electric propulsion system hybrid vehicle drivetrain. The presence of the electric powertrain is intended to achieve either better fuel economy than a conventional vehicle or better performance. There is a variety of HEV types and the degree to which each function as an electric vehicle (EV) also varies. The most common form of HEV is the hybrid electric car, although hybrid electric trucks (pickups and tractors) and buses also exist.
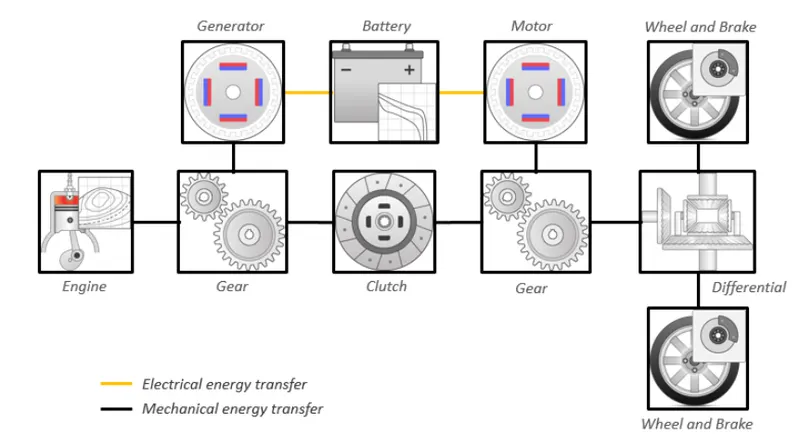
Simulink Model for HEV:-
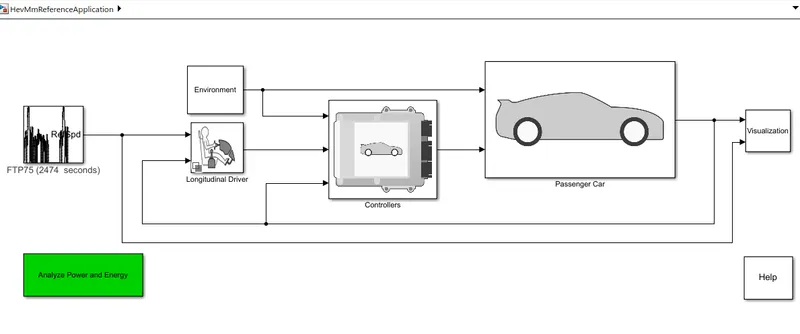
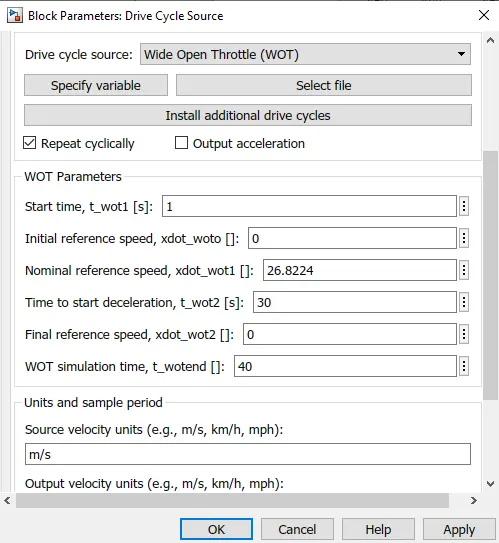
WOT conditions:-
Environment Conditions:- Grade = 5; & Wind Velocity = 10 m/s
Result:- Below results can be seen through the scope in the Visualization block.
1) HEV with WOT with default Environment conditions.
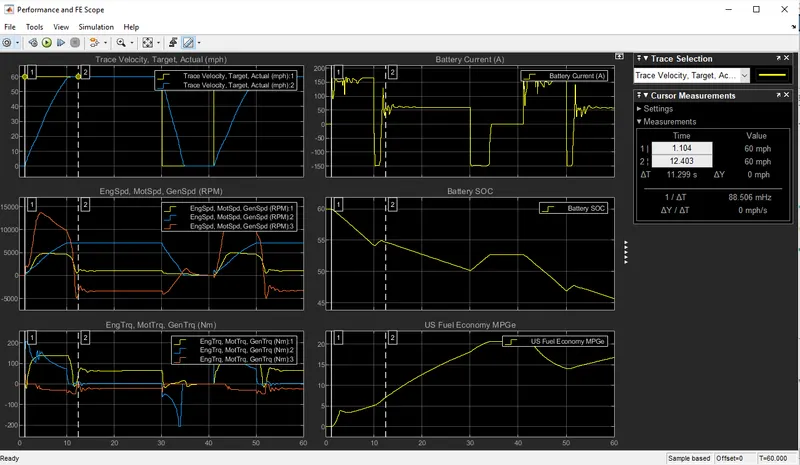
2) HEV with WOT with Environment conditions.
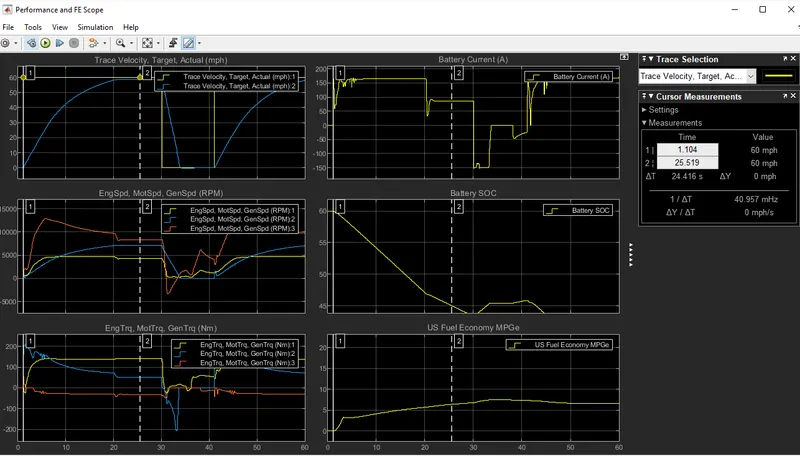
From the above results;
Graph 1:- Trace velocity – Target vs Actual
The yellow indication is the target path and the blue indication is the actual vehicle speed. Here it is seen that vehicles requited around 20 sec to attend the maximum speed toward the target path by using battery power own. After that vehicle starts to decelerates.
Graph 2:- Engine, Motor & Generator Speed.
As the battery is fully charged, at initial condition, only motor speed (blue indication) is used which high at starting because of resistance due to slope & wind velocity. The engine speed (yellow indication) is overlapped with generator speed (orange indication) indicating both running at on the same rpm. Initial there is no need for engine & generator speed as the motor is fulfilling the requirement to achieve the maximum speed of the vehicle. Therefore they are at 0 rpm. But when the battery will discharging Or when the State of Charge (SOC) becomes below 70% then only Engine will start to rotate to provide & maintain the speed of the vehicle & so far generator will also start to charge the battery at the same time. Hence their rpm are the same.
Graph 3:- Engine Torque, Motor Torque & Generator torque
As the battery is being used at the start, so torque will also maximum for the motor in this case until the vehicle acquires its maximum speed. Once the vehicle reached at a constant speed, the torque requirement will reduce. Here also when there is deceleration, the torque value becomes negative indicating no need of toque. Also, it becomes constant once the battery goes into charging state cause now, here Engine torque is being used due below 70% SOC. Also, generator torque will be negative indicating that Electric Motor is charging & in this period Engine has overcome the torque requirement of the vehicle successfully.
Blue indication – Motor Torque
Yellow indication – Engine Torque
Orange indication – Generator Torque
Graph 4: - Battery Current
Battery current is a simple term. When a vehicle uses Electric Motor then only it is used to generate power for the Motor. When the vehicle decelerates, then no current is extracted to produce power for the motor. From the graph also you can see, the current requirement becomes stable while charging the mode of the battery.
Graph 5:- SOC
Sate of Charge (SOC) is important for battery-driven vehicles. From the graph, it can be seen that when the battery used is bellowed 70%, it goes in charging mode & hence SOC is also increased due to charging of the battery through the generator. Hence it can be used further once it gets fully charged.
Graph 6:- MPGe
The graph shows the miles per gallon equivalent require to run the vehicle.
Q4. Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
Pure Electric Vehicle:
An electric vehicle (EV) is a vehicle that uses one or more electric motors or traction motors for propulsion. An electric vehicle may be powered through a collector system by electricity from off-vehicle sources, or maybe self-contained with a battery, solar panels, fuel cells or an electric generator to convert fuel to electricity. EVs include, but are not limited to, road and rail vehicles, surface and underwater vessels, electric aircraft and electric spacecraft.
EV Reference Application Model with WOT:-
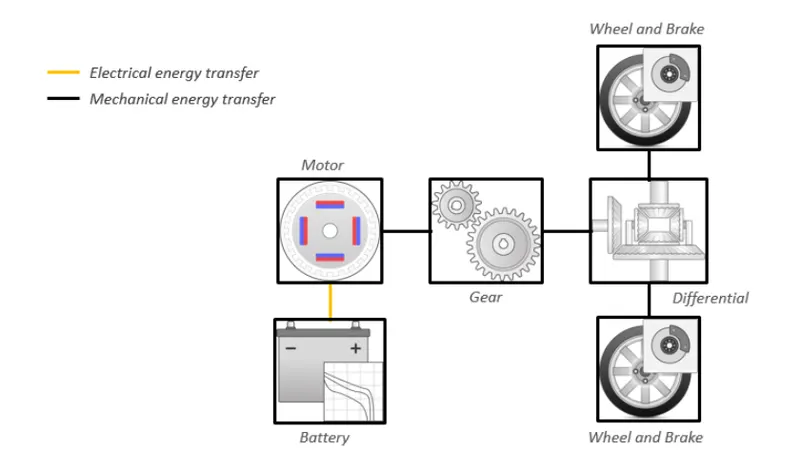
Simulink Model for EV:-
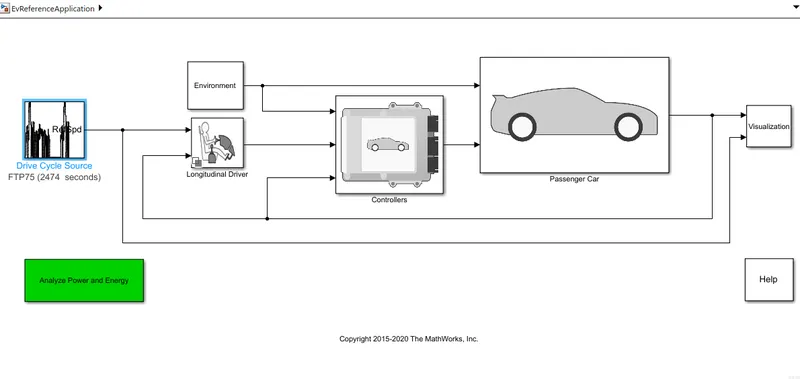
Simulation Condition:
Since comparing an electric vehicle against a hybrid electric vehicle, it is important to have a level playing field. Thus, running the vehicle along the same drive cycle and comparing variables that are important to the consumer and the environment i.e. efficiency, range and MPGe.
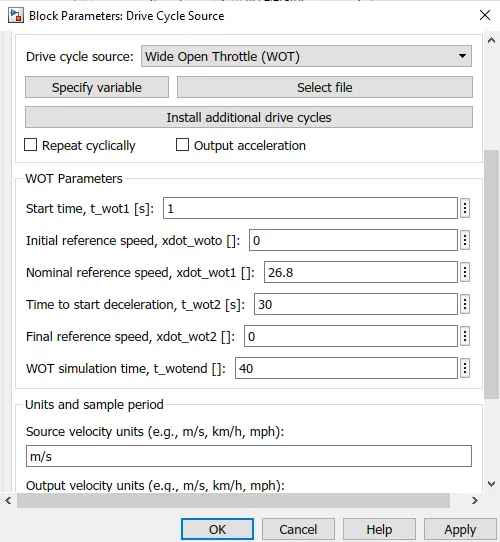
For the first block keeping the input drive cycle i.e Wide Open Throttle(WOT) same as used earlier, Changing the grade and wind velocity, keeping all other parameters as default.
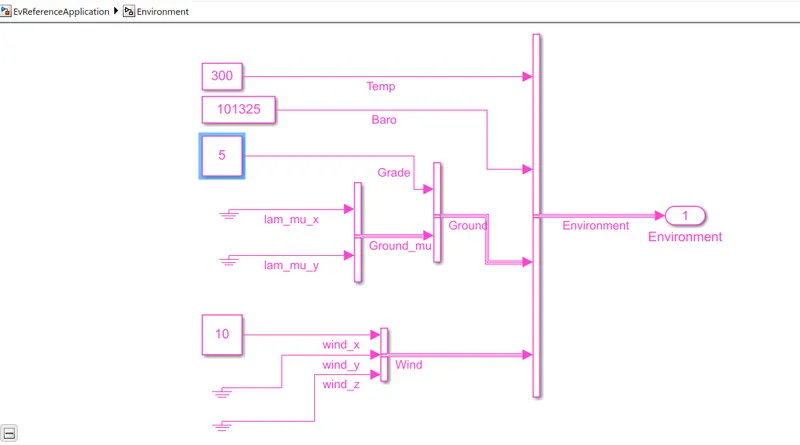
Environment Conditions:- Grade = 5; & Wind Velocity = 10 m/s
Results:
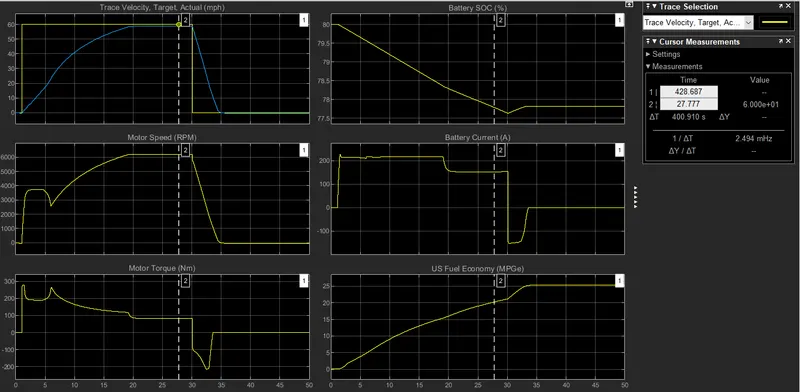
From the above graphs:-
Pure EV can achieve less velocity than that of HEV. HEV can attend velocity above 60 mph but in pure EV velocity is less than 60 mph.
Motor speed in rpm is also less than that of HEV. But path tracing is the same as that of HEV.
But Motor torque of pure EV is almost the same as that of HEV.
Battery current uses is almost half in pure EV to produce power as that of HEV.
Also as battery use is less, battery draining is low & it can be seen from the SOC graph. From the SOC graph, it can be seen that for the same parameters battery uses is 5 times more in the case of HEV than that of pure EV, battery drains fast in the case of HEV.
Fuel economy is also almost double in the case of pure EV than that of HEV.
Comparison and conclusion for Pure electric vs Hybrid vehicle with same conditions:
- In a full-electric vehicle, less top speed is achieved as compared to HEV. The electric vehicle is capable of producing more values of Motor speed and Motor torque compared to the hybrid vehicle's motor alone, but hybrid electric vehicle combines the torque of both motor and it's the engine it is higher than the electric vehicle's torque, this helps in pulling the HEV at higher top speed as compared to the pure electric.
- As the pure electric car uses Lithium-ion battery and HEV uses the Nickel-metal hydride battery, the discharging capacity and the rate of charging is higher in the pure electric car. As it can discharge at a fast rate the motor can produce a high amount of torque instantly compared to the HEV. Battery SOC plot shows the battery efficiency of the pure electric to be higher than the HEV and this is also due to the battery type used in these cars.
- The efficiency of the electric car is higher than the HEV which is evident from the miles per gallon numbers of both of these cars.
- The electric vehicle produces zero emissions whereas the hybrid one's produce waste gas emission.
Conclusion-
- Mapped model is simple & suitable for the static problem where we can compromise on accuracy while dynamic is suitable for complex problems requires high accuracy.
- Miles per gallon block uses data from vehicle speed & battery power in MPGe.
- Adding gradeability & wind resistance causes the vehicle to achieve less acceleration & top speed at same battery capacity & MPGe achieved is also less(vehicle becomes less economic).
- The electric vehicle is best suited where initial acceleration & max power is not much of importance & MPGe is required at higher side. While on another hand, Hybrid vehicle is best suited where initial acceleration & max power is an important factor with little compromising on MPGe. So pure electric vehicle is more economical.
REFERENCES:-
https://www.mathworks.com/help/autoblks/ug/explore-the-electric-vehicle-reference-application.html
https://www.edmunds.com/fuel-economy/decoding-electric-car-mpg.html
https://www.epa.gov/fueleconomy/plug-hybrid-electric-vehicle-learn-more-about-new-label
https://www.epa.gov/fueleconomy/interactive-version-electric-vehicle-label