Week 3 - Solving second order ODEs
Aim : To stimulate the motion of a simple pendulum with damping
Principle : The following ODE represent the eaquation of a motion of a simple pendulum with damping
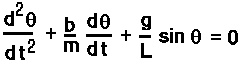
where
b = damping coeffiecient
L = length of the pendulum
m = mass of the pendulum
g = 9.81m/s^2
since the above equation is in second order we have convert it into first order
assume
thetha = thetha1
dthetha1/dt = thetha2
hence the above equation becomes
dthetha2/dt + b/m thetha2 + g/l sin(thetha1)
the above equation in array form
d/dt[thetha1,thetha2] = [thetha2, -b/m thetha2 - g/lsin(thetah1)
asumming the time is 0 to 20
Angular displacement = 0
Angular velocity = 3 at t=0
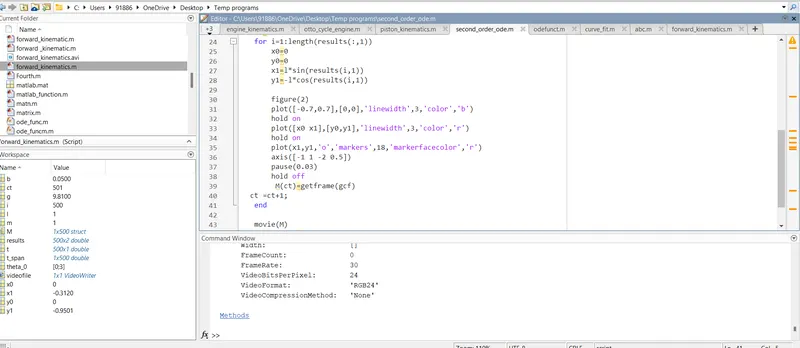
Program 1
clear all
 close all
 clc

 %inputs
 b = 0.05;
 g = 9.81;
 l =1;
 m=1;

 theta_0 = [0;3];

 t_span = linspace(0,20,500);
 [t, results] = ode45(@(t,thetha) odefunct(t,thetha,b,g,l,m),t_span,theta_0)

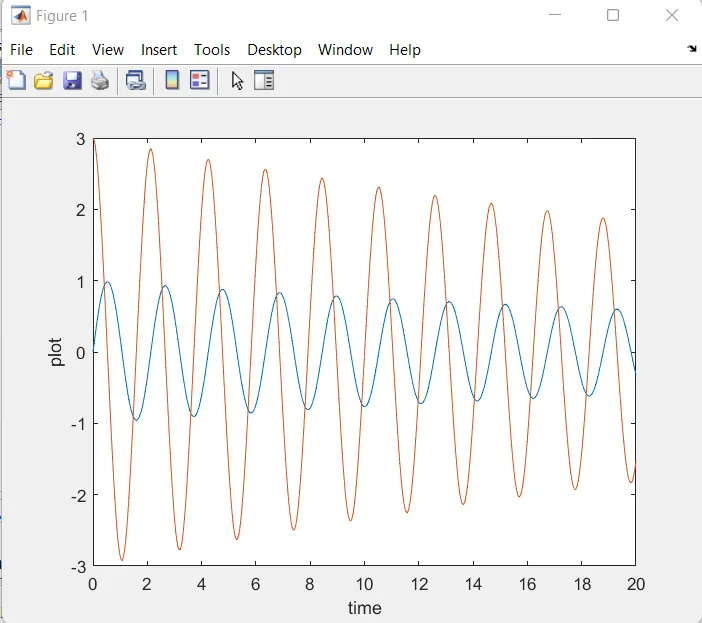
 plot(t,results(:,1));
 hold on
 plot(t,results(:,2));
 xlabel('time');
 ylabel('plot');
hold off

%for animation of the pendulum
ct =1
 for i=1:length(results(:,1))
     x0=0
     y0=0
     x1=l*sin(results(i,1))
     y1=-l*cos(results(i,1))

     figure(2)
     plot([-0.7,0.7],[0,0],'linewidth',3,'color','b')
     hold on
     plot([x0 x1],[y0,y1],'linewidth',3,'color','r')
     hold on
     plot(x1,y1,'o','markers',18,'markerfacecolor','r')
     axis([-1 1 -2 0.5])
     pause(0.03)
     hold off
      M(ct)=getframe(gcf)
ct =ct+1;
 end

% for creating the movie
 movie(M)
 videofile = VideoWriter('pendulum_animation.avi','Uncompressed AVI')
     open(videofile)
     writeVideo(videofile,M)
     close(videofile)
Program 2
function [dthetha_dt] = odefunct(t, thetha, b,g,l,m)
thetha1 = thetha(1);
thetha2 = thetha(2);
dthetha1_dt = thetha2;
dthetha2_dt = [-(b/m)*thetha2-(g/l)*sin(thetha1)]
dthetha_dt = [dthetha1_dt;dthetha2_dt];
end
Explanation of the code
clear all remove the stored variables
close all remove the plots ,graph
clc clear all the values in command window
linspace command is since the pendulum moves through time 0 to 20sec
It generates 500 values btw 0 and 20
Inorder to solve the differential equation there is an inbulit solver called ode45. It is an standard solver for ordinary differential equations of fifth-order (ode45). The ode45 function applies Runge-Kutta formulae with the time step variable for easy computation.
Call function 'odefunct' is used to calculate [ t, results]
Plot command is used to plot the graph
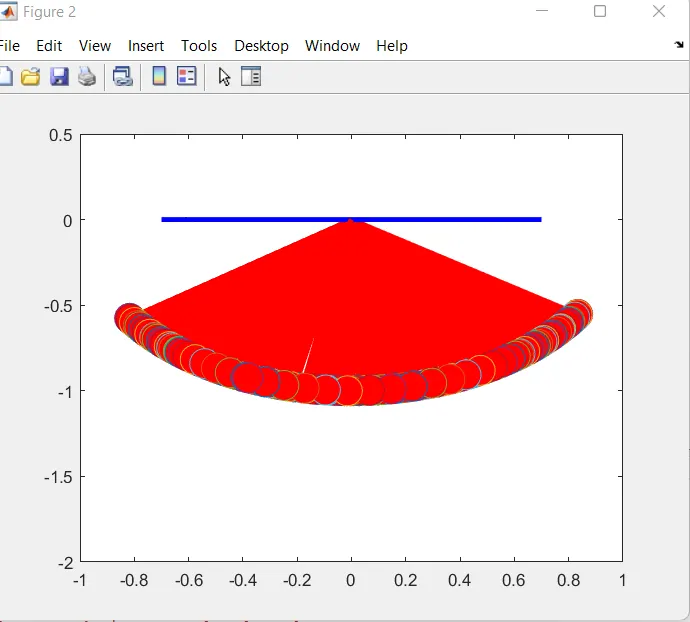
For loop is used since time has an array of 500 values
since we have to fix one end of pendulum to a base