Week 3 - Solving second order ODEs
AIM :
- To simulate a program in Matlab and to slove the motion of a Simple Pendulum with damping effect ,using a second oder differential equation(ODE) .
OBJECTIVE :
- To write a program to simulate the transient behaviour of Simple Pendulum .
- To create an animation of motion of simple Pendulum using Matlab .
THEORY : ORDINARY DIFFERENTIAL EQUATION (ODE)
- In mathematics ,an ODE is a differential equation containing one or more independent variables and the derivatives of those function .The differential equation classified into many equation they are Linear ,Homogenous , non - Homogenous , non - Linear equation .
- In engineering ,ODE is used to describe the transient behaviour of system .An example given for this is Simple Pendulum .
SIMPLE PENDULUM :
- A simple pendulum is a mechanical system of mass attached to a long massless inextensible string that performs Oscillatory motion .
- Pendulum were used to keep a track of time in ancient periods .
- The pendulum is also used for identifying the beats.
DIAGRAM :
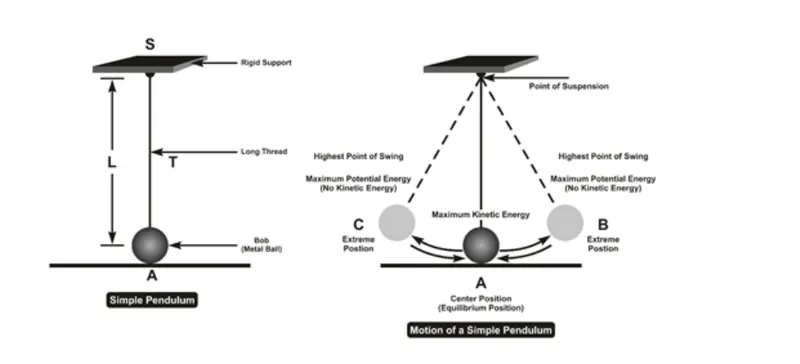
MOTION OF SIMPLE PENDULUM :
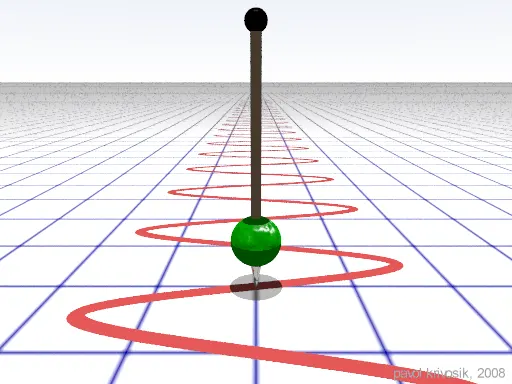
- The differentail equation for a motion of a simple pendulum with damping is given below
`d^2theta/dt^2 +b/m(d theta/dt) +g/l sintheta = 0`
where
b = Damping coefficient ,
m = mass of the pendulum in kg ,
l = length of the pendulum in m,
g = gravity in `m/s^2`.
- This is Second Oder Ordinary Differential Equation ,because this equation is in form of oder '2'.
DERIVATION : Let us consider ,
`theta = theta_1` and so ,
`d theta /dt = d theta_1/dt = theta_2` equation 1
`d^2 theta/dt^2 = d^2theta_1/dt^2 = d/dt(d theta_1/dt) = d theta_2/dt` equation 2
- substituting equation 1 and 2 in these given equation .
`d^2theta/dt^2 +b/m(d theta/dt) +g/l sintheta = 0`
`d^2 theta/dt^2 +b/m(d theta_1/dt) + g/lsintheta_1 = 0`
`d^2 theta_2/dt +b/mtheta_2+g/lsintheta_1 = 0`
Therefore,
`d theta_1/dt = theta_2`
`d theta_2/dt = -b/mtheta_2 -g/lsintheta_1`
Now, let us convert this equation into a matrix form
`d/dt[theta_1;theta_2] = [theta_2;-b/mtheta_2-g/lsintheta]`
where
`theta_1`= Angular Displacement of pendulum ,
`theta_2`= Angular Velcity of pendulum .
PROGRAM :
clear all
close all
clc
%  Inputs
% damping coefficient
 b = 0.05;
% length of the pendulum in (m)
 l = 1;
% mass of the pendulum in (kg ) converted into (m)
 m = 0.1;
% gravity in (m/s^2)
 g = 9.81;
% Initial condition
 theta_0 = [0;3];
% time point
 t_span = linspace(0,20,450);
% solving ODE
 [t,result] = ode45(@(t,theta)ode_func(t,theta,b,g,l,m),t_span,theta_0);

% plotting the angular displacement and angular velocity
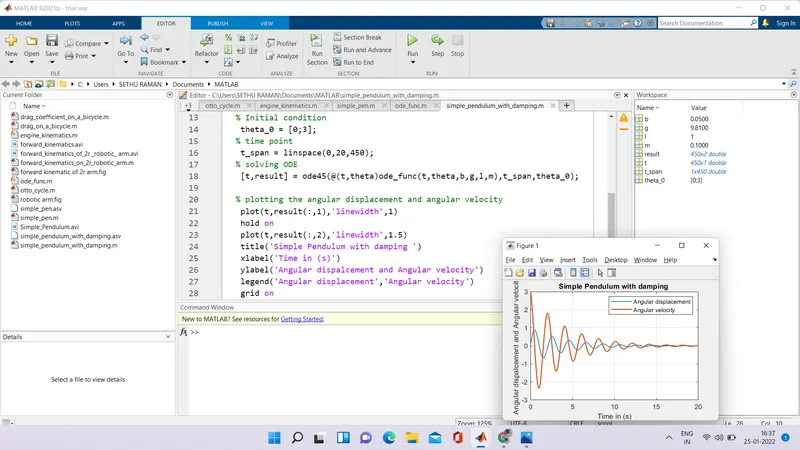
 plot(t,result(:,1),'linewidth',1)
 hold on
 plot(t,result(:,2),'linewidth',1.5)
 title('Simple Pendulum with damping ')
 xlabel('Time in (s)')
 ylabel('Angular dispalcement and Angular velocity')
 legend('Angular displacement','Angular velocity')
 grid on

 % Animation
  ct = 1 ;
  for i = 1:length(t_span);
      x0 = 0;
      y0 = 0;

      x1 =  l*sin(result(i,1));
      y1 = -l*cos(result(i,1));

      plot([-1 1],[0 0],'linewidth',5,'color','g')
      axis([-2 2 -2 2]);
      line([x0 x1],[y0 y1],'linewidth',4,'color','b')
      hold on
      plot(x1,y1,'o','markersize',30,'markerfacecolor','r','markeredgecolor','r')
      hold off
      grid on
      pause(0.1)
      M(ct) = getframe(gcf);
      ct = ct+1;
  end

  % Animation of motion of Simple Pendulum
   movie(M)
   videofile = VideoWriter('Simple_pendulum.avi','Uncompressed AVI')
   open(videofile)
   writeVideo(videofile,M)
   close(videofile)
CODE EXPLANATION :
- The program starts with clear all ,close all , clc command.
- 'clear all ' command is used to clear the data stored in the workspace .
- 'close all ' command is used to close the plot and figures .
- 'clc' command is used to clear the command window .
- Then the given input values of b,g,l,m entered and inital conditions for angular displacement is `theta_1`is 0 and angular velocity `theta_2`is 3 rad/sec.
- And time span is taken to be 0 to 20 with 450 intervals.
- A function code is used in the case to solve the second oder differential equation .
-
function [dtheta_dt] = ode_func(t,theta,b,g,l,m) theta1 = theta(1); theta2 = theta(2); dtheta1_dt = theta2; dtheta2_dt = -(b/m)*theta2-(g/l)*sin(theta1); dtheta_dt = [dtheta1_dt;dtheta2_dt]; end - ode45 - is inbuilt function in matlab.
- counter vaule command is used to ,so that the variable increments by specific step value in every iteration of a loop.
- 'for' loop is used for continous motion to the pendulum.
- The 'pause ' command is used for animation speed and slow.
- The 'getframe ' command is used to capture the motion.
- To save the video 'videofile' commad is used.and finally 'close' command is used to close the videofile.
ERRORS :
- These are the errors made while programming
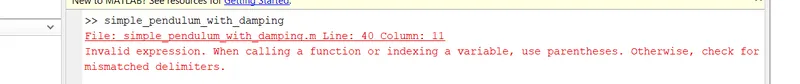
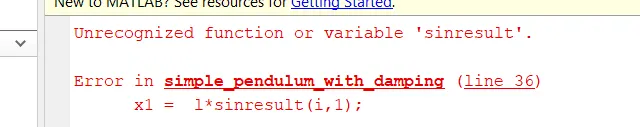 rectified = missed parentheses.
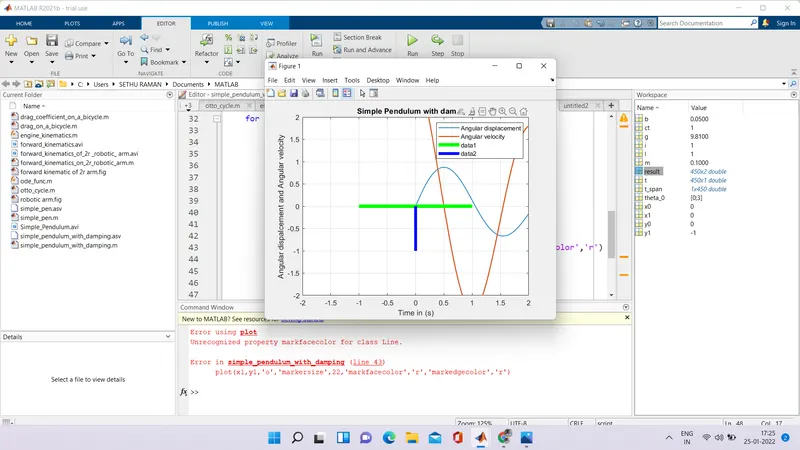 rectified = instead markerfacecolor, markeredgecolor made mistake of markface,markedge.
OUTPUT :
ANIMATION :