Week 3 - Solving second order ODEs
AIM:
Write a program in Matlab\Octave that will simulate the pendulum motion.
PROCEDURE:
clear all
close all
clc

%parameters
b=0.03
g=9.81
l=1
m=0.1

%initila conditions
theta_0=[0;3];
time 0 to 20 seconds with 200 time steps
t_span=linspace(0,20,200);

%calling in built function ode45 to find the derivative of our function
%our function is ode_func with input arguments b,g,l,m
[t,results]=ode45(@(t,theta)ode_func(t,theta,b,g,l,m),t_span,theta_0);

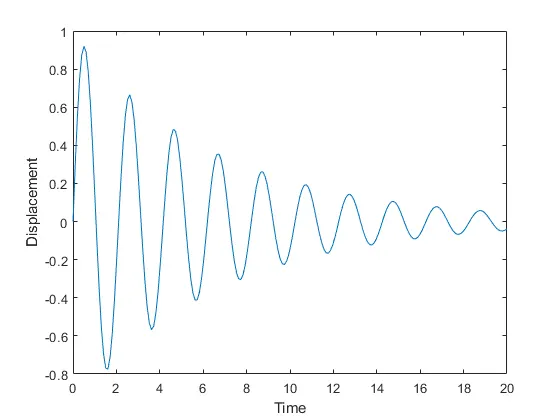
figure(1)
plot(t,results(:,1))
xlabel('Time')
ylabel('Displacement')

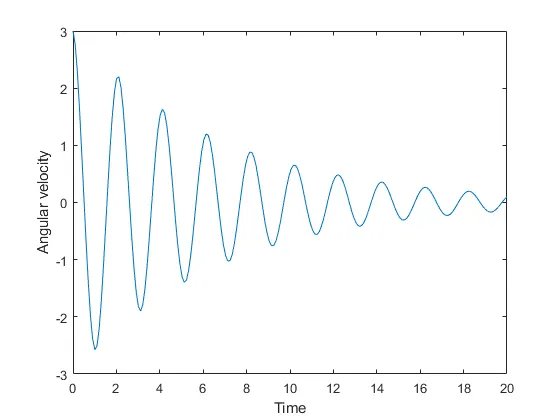
figure(2)
plot(t,results(:,2))
xlabel('Time')
ylabel('Angular velocity')

figure(3)
Theta=results(:,1)
count=1
for i=1:length(Theta)
    theta=Theta(i)

    x0=0;
    y0=0;

    x1=l*sin(theta);
    y1=-l*cos(theta);


    plot([-0.5 0.5],[0 0],'r')
    hold on
    plot([-0.5 0.5],[0.0625 0.0625])
    hold on
    plot ([0 0],[0 -1])

    plot(x1,y1,'o','markersize',25,'color','r','markerfacecolor','r');
    plot([x0 x1],[y0 y1],'linewidth',5);
    hold off
    axis([-1 1 -1.5 1])


    pause(0.03)
    M(count)=getframe(gcf);
    count=count+1;
end

%Animation
movie(M);
videofile=VideoWriter('Pendulum.avi')%saving our animation to a video file with name pendulum
open(videofile)%opening the video file
writeVideo(videofile,M)%writing the video file with arrays in M
close(videofile)
RESULTS: