Week - 3 Drop test Challenge
AIM: To setup the mobile phone model for drop test using LS-Dyna.
Objective:
1. To create material as per requirement for the different parts.
2. To create section for solid and shell.
3. To define for Part such as material and section ID.
4. To create Boundary conditions such as construction.
5. To create Contact definition for phone and plate
6. To create Velocity which will assign to the phone.
7. To define the Control keyword so that we will control simulation like time of simulation, printing results every defined time etc.
Introduction on Finite Element Analysis:
The finite element method is a numerical technique for obtaining approximate solutions to a wide variety of engineering problems. FEA (Finite Element Analysis) is done in three phases.
1. Pre-processing
2. Solution
3. post-Processing
Drop test:
The most common failure of cellular phones is probably the impact due to accidental drop, so the manufacturers aim to develop products that are impact resistant and can survive the drop test from specific height. Both physical test and finite element (FE) simulation are employed in the industry at different stages. At the design stage, FE method plays a more important role since actual drop test can only be conducted at the end of design cycle and provides little feedback to improve the design. The FE simulation will help designers understand how components interact in the assembly and how the failure mode and mechanism is developed under the impact loading.
Procedure:
Import .k file, to import file>open>LS-DYNA keyword file. Figure1 shows the imported model after deleting the solid floor. Figure2 shows the keywords used in the importd file.
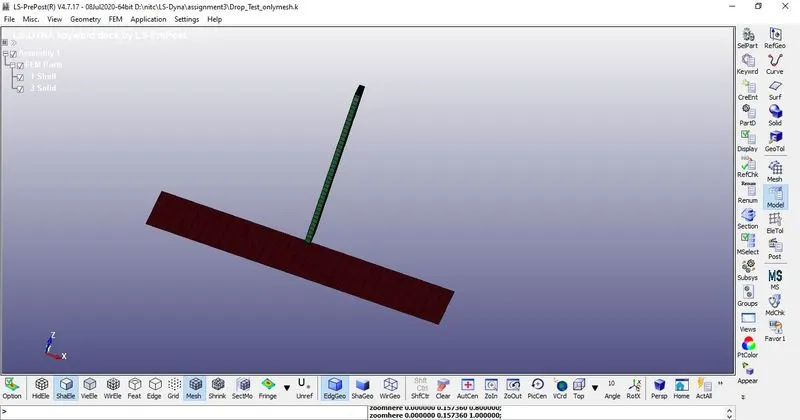 Figure1
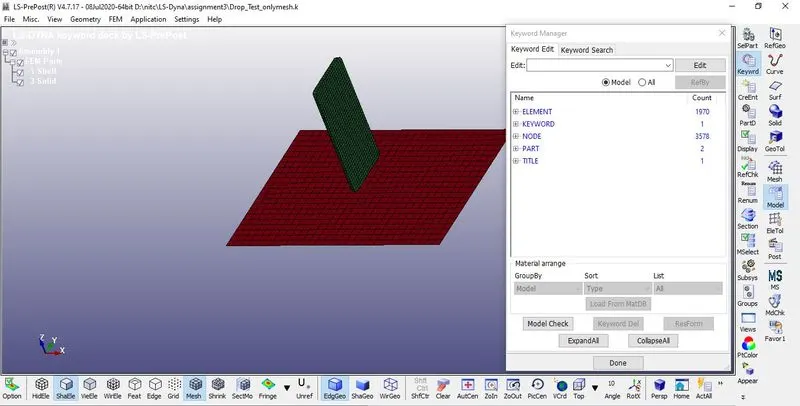 Figure2
1. To create material as per requirement for the different parts.
Material Creation: For every part the material is necessary in order to run simulation. also the unit system with we have to input data.
a. Here the unit system is kg-mm-ms, all the data which is input must be in same unit system.
b. Create material for floor is rigid, and for phone here considered as aluminium. ((Model and Part>MAT(all)>020_rigid (plate) and 024_picewise linear_plasticity)
Figure3&4 shows the material creation of the model.
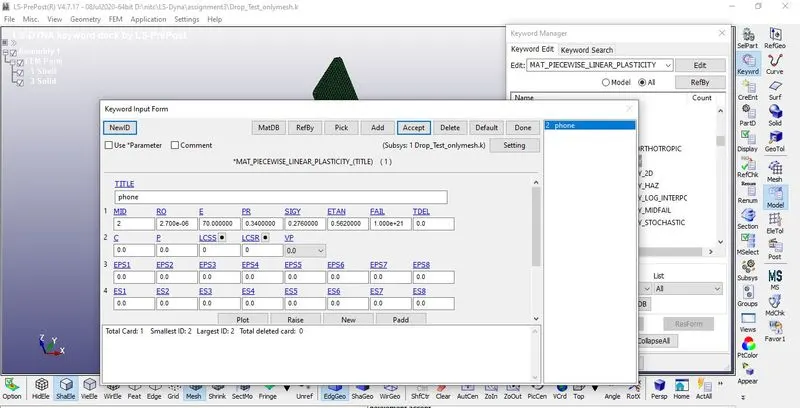 Figure3
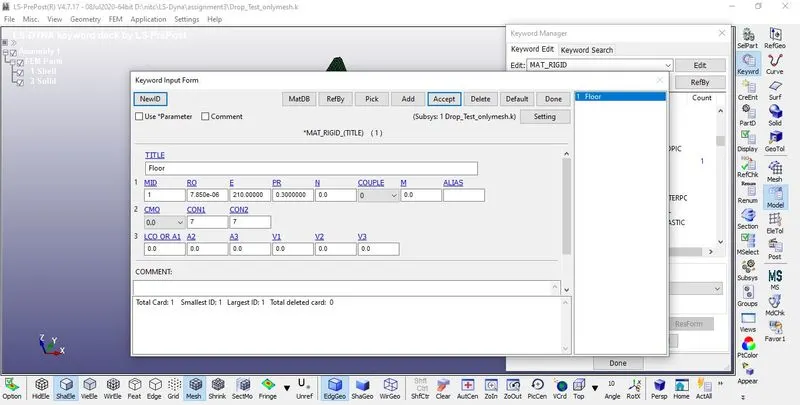
Figure4
2. To create section for solid and shell.
Section Keyword: In order to distinguish b/w the type of element we have to define the section keyword. for shell and solid
a. Section is created for (Model and Part>section (all)>shell) floor and have to define thickness and type of element formulation here it's not important because all nodes are fixed in all direction so there is no element undergo displacement and solid is created for phone.
Figure5&6 shows the section creation for phone and floor.
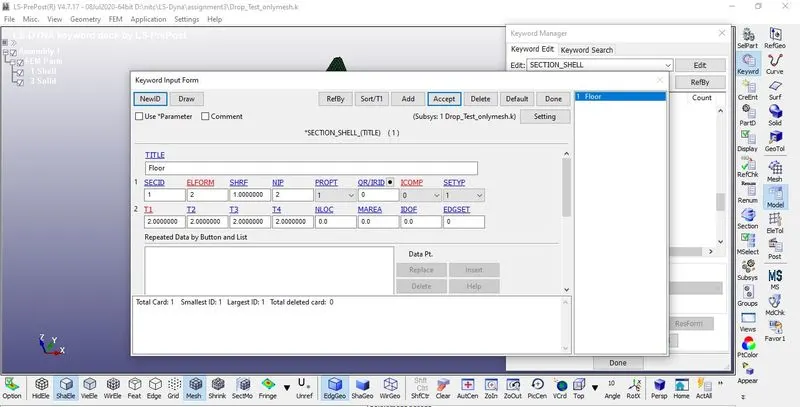 Figure5
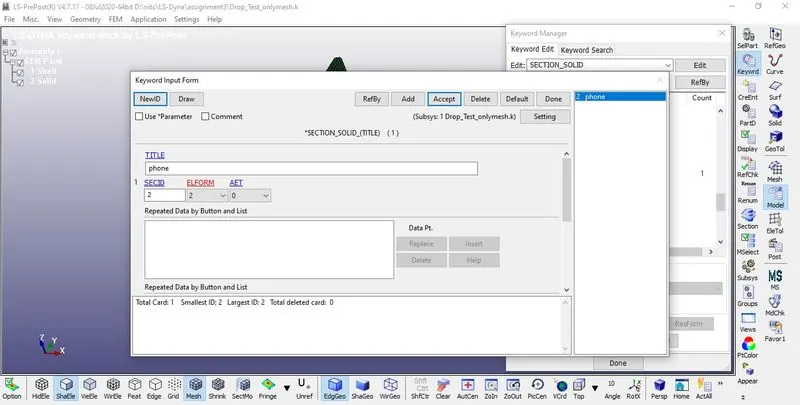 Figure6
3. To define for Part such as material and section ID.
Assigning Material and section: one done with Material and section we can assign those data to the parts by directly clicking on part in (Model and Part>part) so we can see part list and each part has the option to select for Section ID and MATID.
Figure7&8 shows the assigning of material and section to the parts.
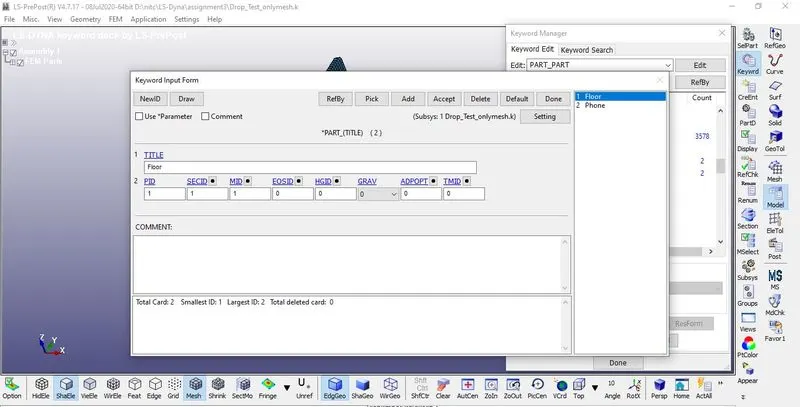 Figure7
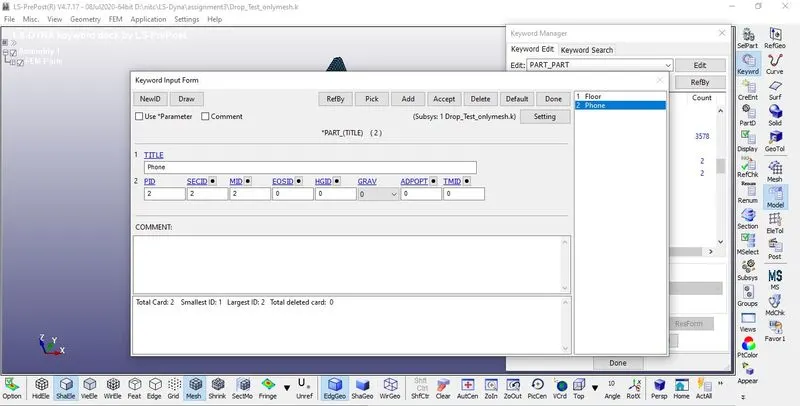
Figure8
4. To create Boundary conditions such as construction.
Creating Boundary: In order to run model we need boundary condition such as constraints and initial parameters such as velocity etc, so to create fixed floor where the phone is going to impact steps, before that we need to create node set to both phone and floor.
Figure9 shows the constrained boundary for the floor.
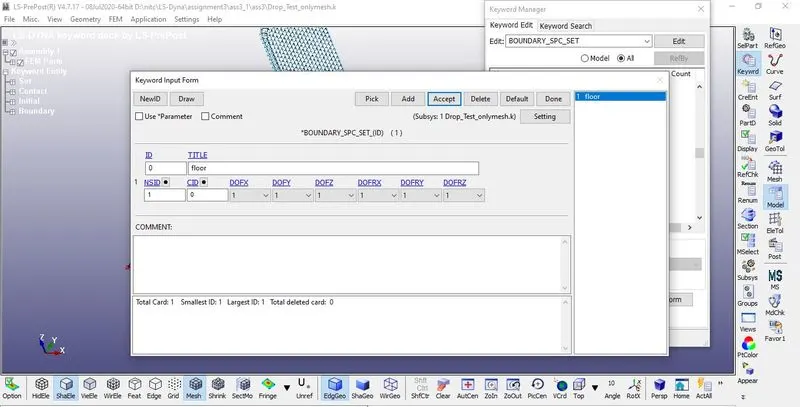 Figure9
5. To create Contact definition for phone and plate
Define Contact: In order to impact take place b/w phone and floor there should be contact definition or else phone will simply pass through plate,here all phone nodes are slave and all floor nodes are master nodes. we have so many options to select the by nodes or parts or sets etc.
Figure10 shows the contact between phone and floor.
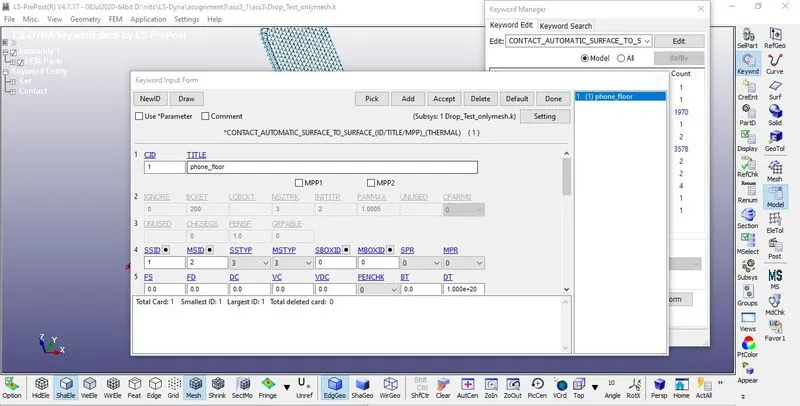 Figure10
6. To create Velocity which will assign to the phone.
Initial velocity: In order to move the phone twords plate we are assuming the velocity of 5 mm/ms in negative direction. here select the node set and input velocity in which direction it should move.
Figure11 shows velocity defining to the phone
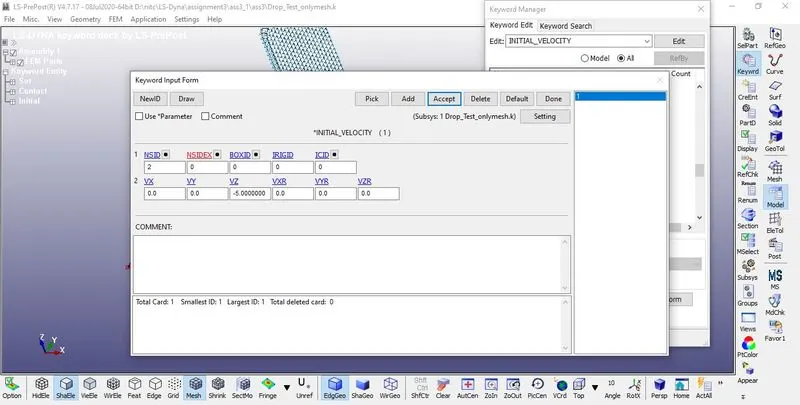 Figure11
7. To define the Control keyword so that we will control simulation like time of simulation, printing results every defined time etc.
Figure12&13 shows the defining of control cards and requesting outputs.
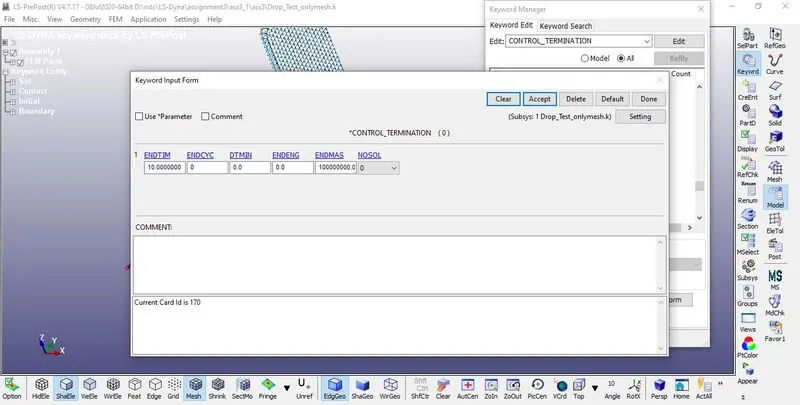 Figure12
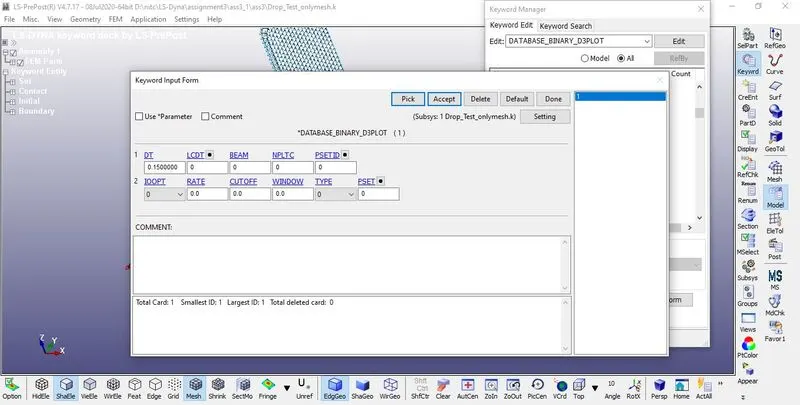 Figure13
Model Checks:
check the model whether any errors were there and correct them.
Figure14 shows the model after correcting the errors.
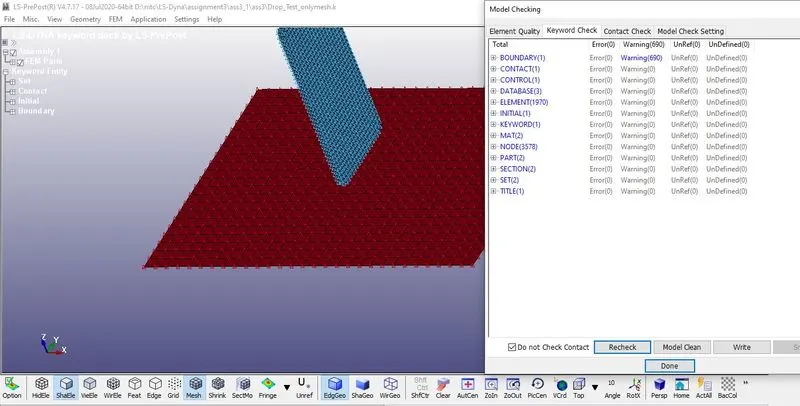 Figure15
RESULTS:
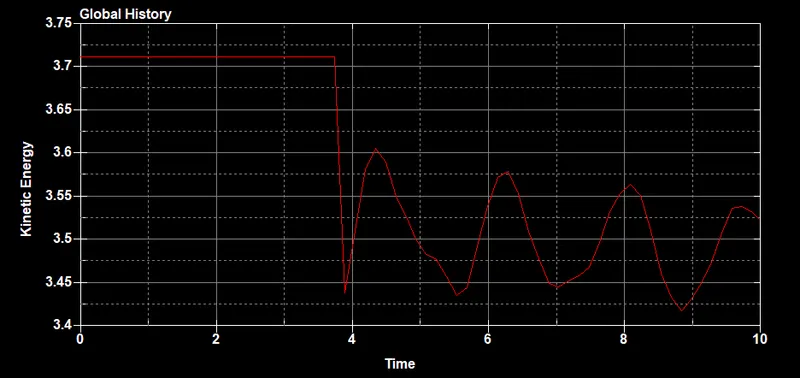
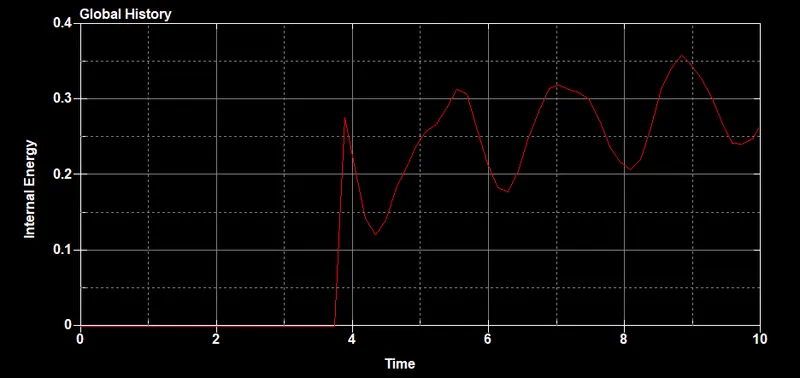
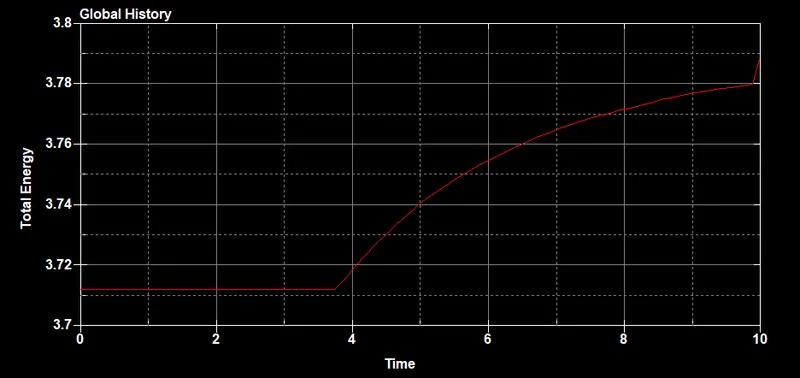
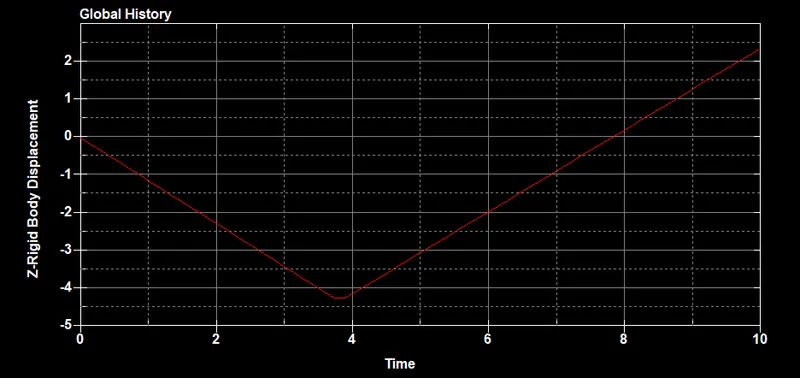
Animation file is uploaded as the the video named video1.mkv
Plots are shown below figures.