Week-3 Challenge: ADVISOR Tool
AIM
To download the ADVISOR TOOL and Link the files to MATLAB then perform the given challenges as well as explain the results and models.
Answer #1
The basic EV model EV_defaults_in Module open and the Cargo mass changed as 500KG.
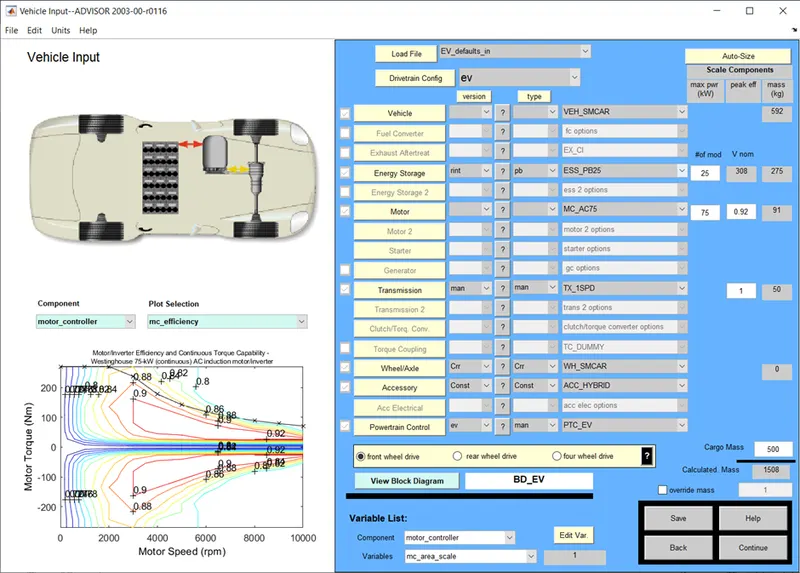
Fig 1.1
Block Diagram Architecture of Basic EV vehicle has shown in Fig 1.2
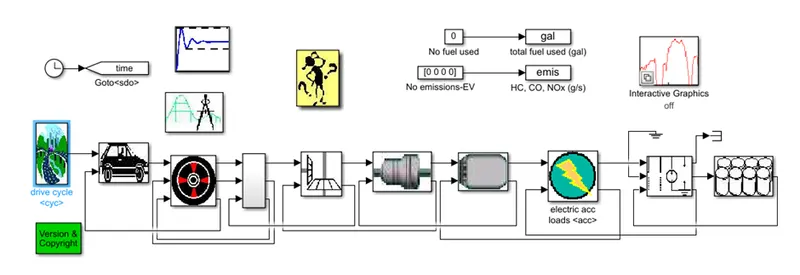
Fig 1.2
The driving cycle has changed to FTP model and output plotted as shown Fig 1.3
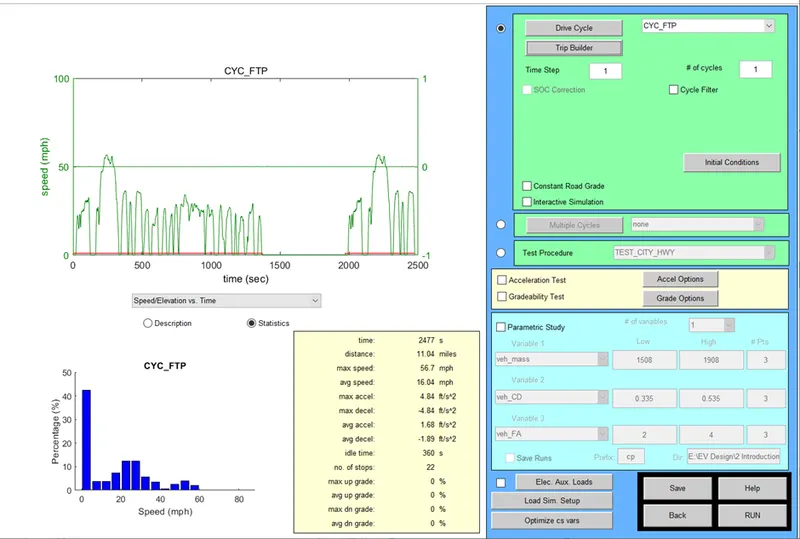
Fig 1.3
As shown in the Fig 1.4 Output of FTP Driving cycle, the below are observed,
The vehicle reached 17.8KM per cycle with gasoline equivalent 2.4.
While this cycle time the speed is reached almost 90KM/Hr.
The SOC has reduced up to 50% for one cycle.
Emissions is zero.
Over all system efficiency is 0.368
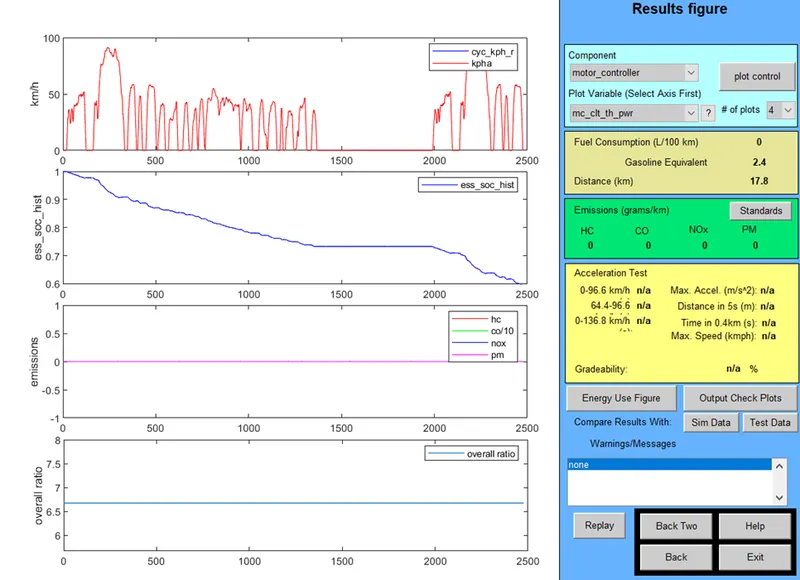
Fig 1.4
The Fig 1.5 shows the Energy Usage of the EV system, input, output and loss of various components of our Ev system.
The Over all system efficiency is 0.368..
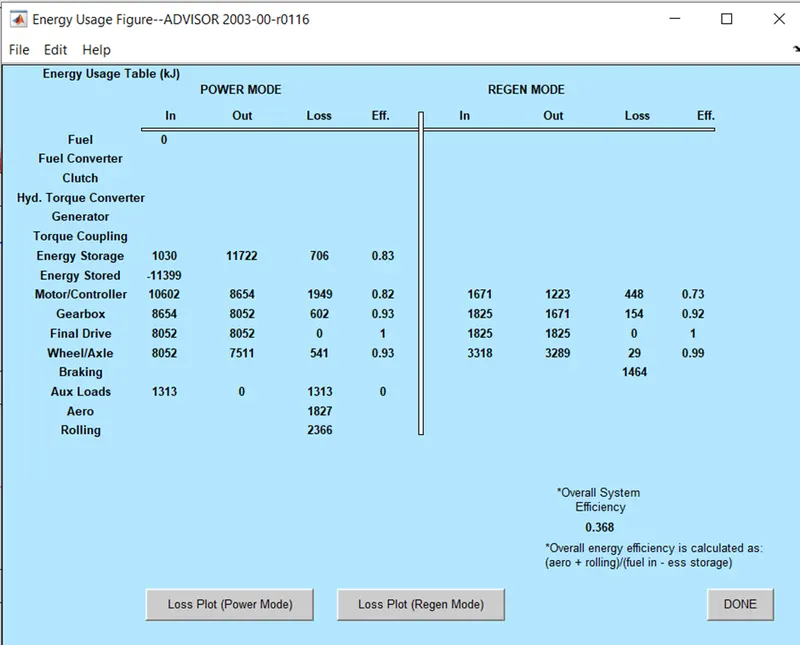
Fig 1.5
Fig 1.6 shows the Driving cycle result We increases the cycle in to three time more but the total Distance covered by the vehicle is 41.6KM,
Not able to reach 45KM because the SOC is Zero, in this FTP driving cycle,in the given default values with edited cargo weight of 500kg, so we need to change the battery capacity for the same driving cycle.
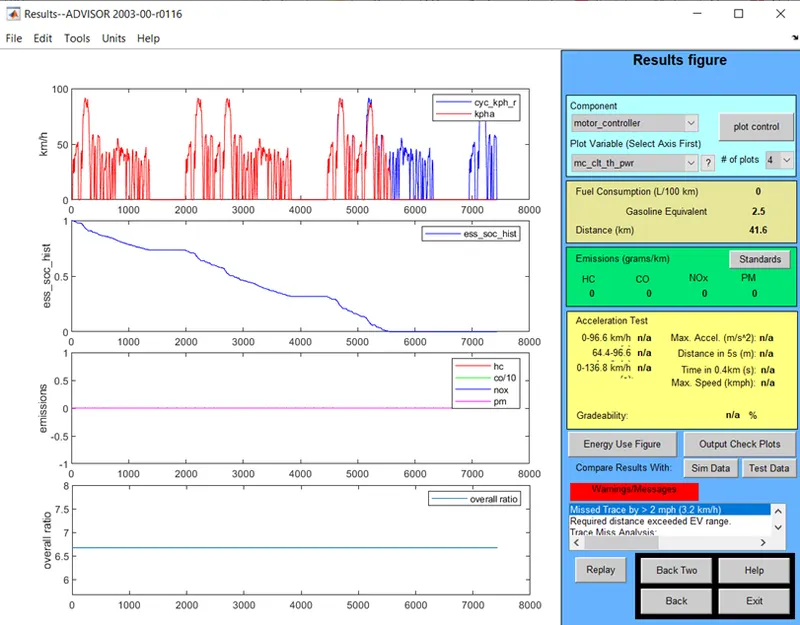
Fig 1.6
Answer #2
Fig 2.1 shows the Same EV model with changed Battery capacity or model.
In default we used (PSS_PB25 - Hawker Genesis 12V 25Ah 10EP sealed valve-regulated lead-acid (VRLA) battery)
Now we replaced (ESS_PB104 - providing 1.23 kW per module, the Horizon 12N85 lead-acid battery)
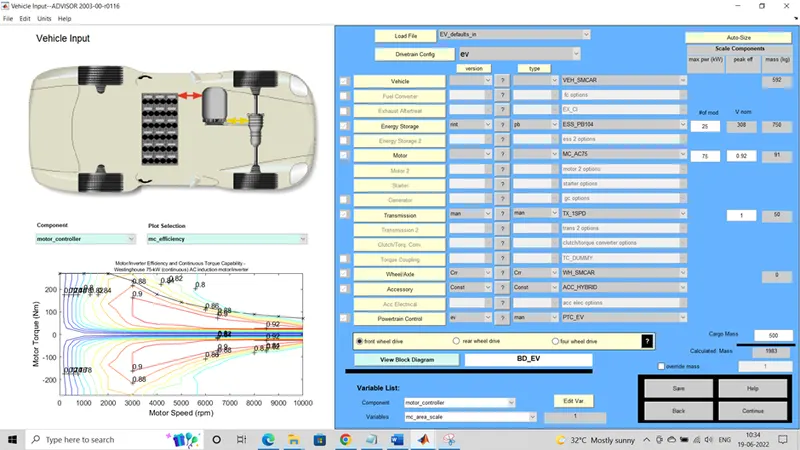
Fig 2.1
The Fig 2.2 Shows the changed Number of driving cycle as 5, then only we reach 45Km in the specified load in the FTP cycle.
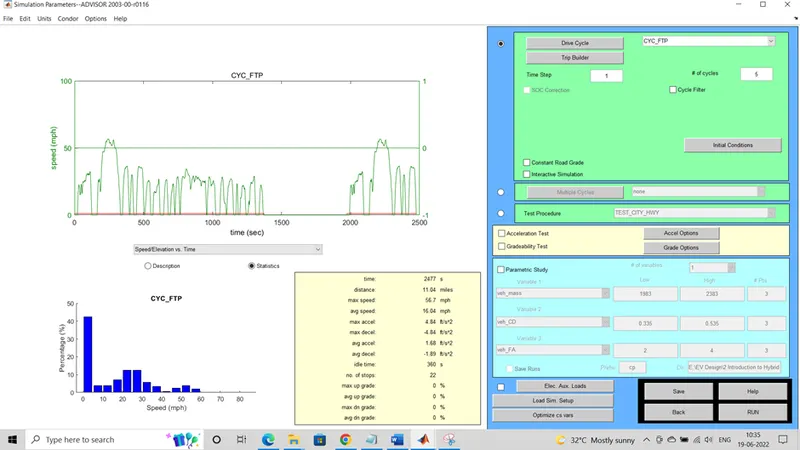
Fig 2.2
Fig 2.3 Shows the output characteristics of our configuration in the EV module.
Vehicle crossed 45KM in 5th round in the ETU cycle.
Covered Distance at 5th cycle is 55.2KM.
The Over all system efficiency is 0.363
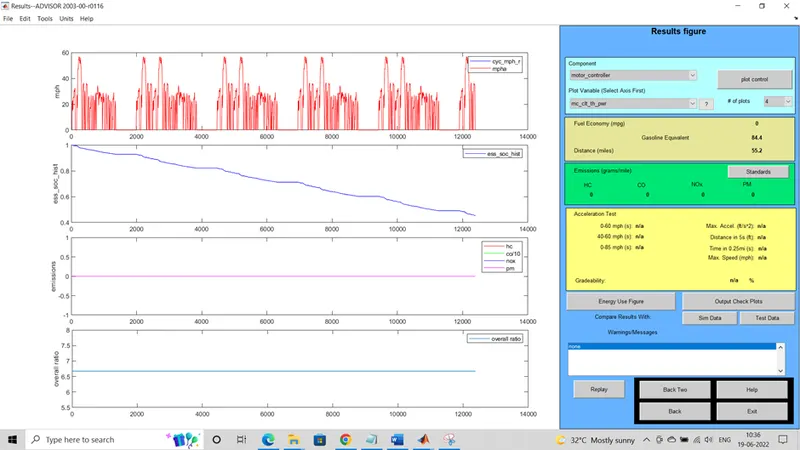
Fig 2.3
Answer #3
Gradeability test with PRIUS_Jpn_defaults_in file.
Fig 3.1 shows the Basic model structure of PRIUS Hybrid Model car.
The all-default parameter values are remains same.
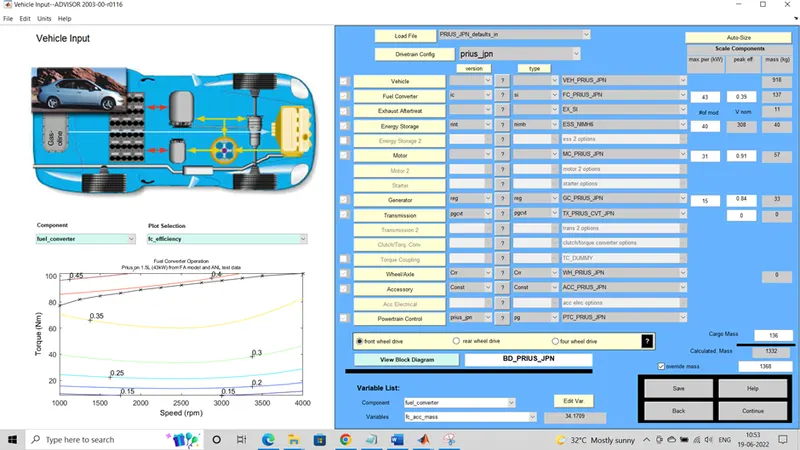
Fig 3.1
Fig 3.2 show the (UDDS - Urban Dynamometer Driving Schedule) default driving cycle for PRIUS Hybrid vehicle.
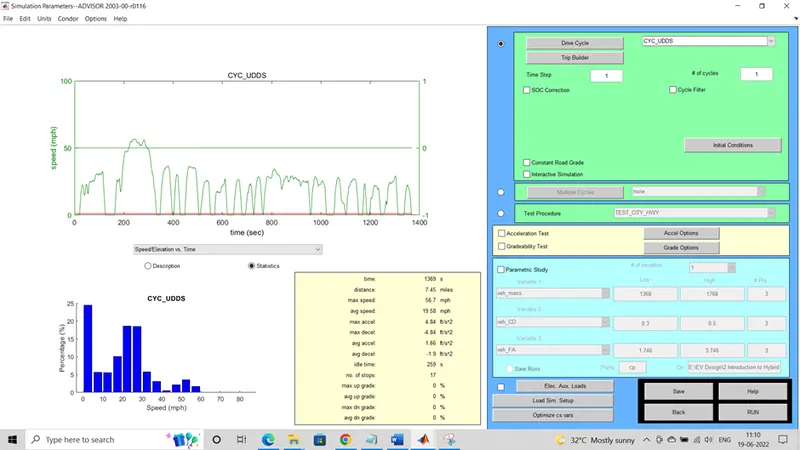
Fig 3.2
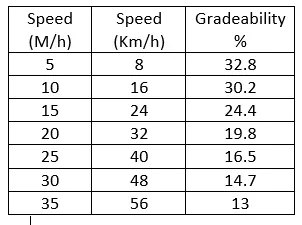
The comparison Shows in the Fig 3.4 and Fig 3.5, While performing the gradeability test basically the values of Speed and Gradeability are anti parallel, if the speed is increase the gradeability will be minimum as well as the gradeability is maximum the speed will be minimum.
Fig 3.3 is the input of Grade points parameters.
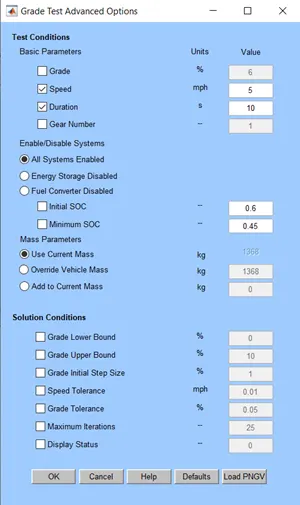
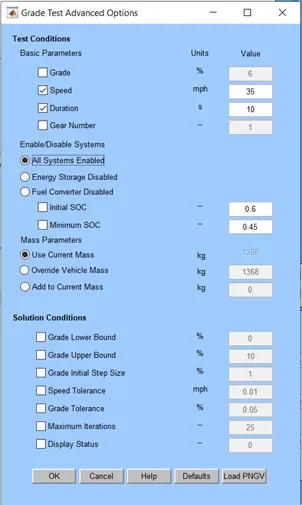
Fig 3.3
Fig 3.4 show the Gradeability against the speed range of 35mails – 56.3 km/hr is 13%
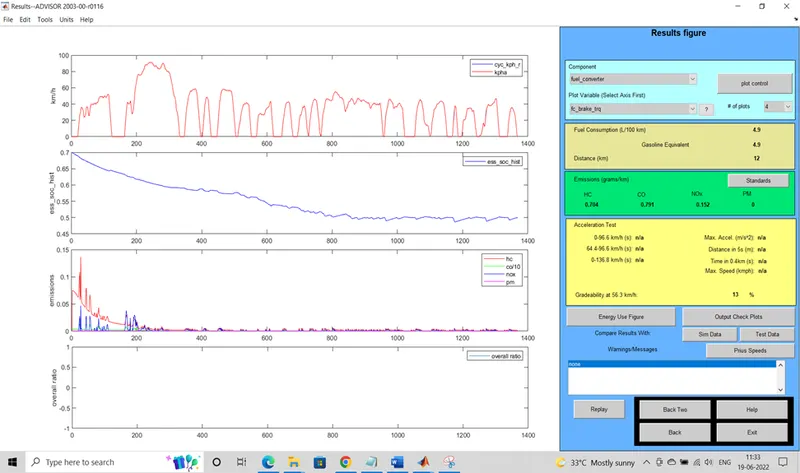
Fig 3.4
Fig 3.5 Show the Gradeability against the speed range of 5mails – 8 km/hr is 32.8%
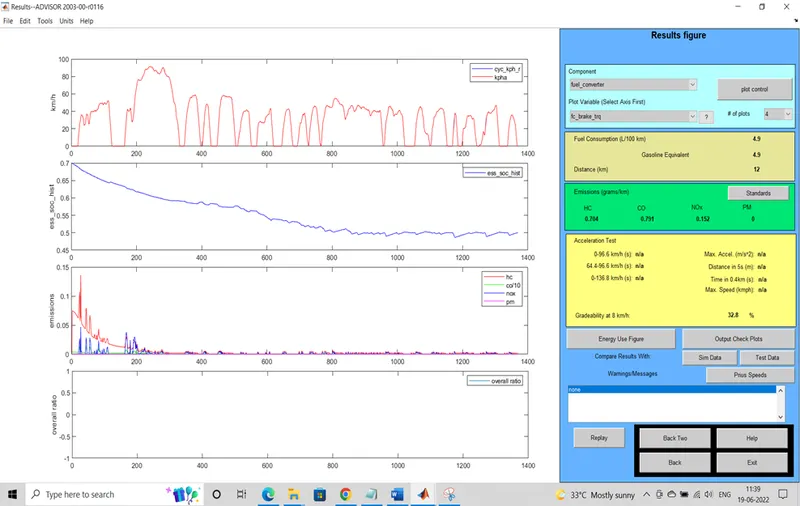
Fig 3.5
The table shows the comparison of results Speed Vs Gradeability.
Conclusion:
The advisor tool downloaded and the file linked to MATLAB then
- For basic EV_defaults_in file select and the ANSWER #1 performed, this case we found with the FTP driving cycle and default Battery (PSS_PB25) system is not sufficient for complete 45KM..
- In the same EV default file we change the PSS system for complete the 45KM, for that the Battery system change to (ESS_PB104), and simulate the module with 5 times of FTP driving cycle in the same setup, during 5th cycle the vehicle crossed 45KM..
- The gradeability test of the PRIUS_JPN_default_in performed, The result is when the speed of the vehicle is low the gradeability of the vehicle is high, When the vehicle speed is high the gradeability is low.