Week-3 Challenge: ADVISOR Tool
1. Here we initialized the EV_defaults_in file, from the advisor tool where we have so many parameters to vary which in result makes us observe the changes that happened in a drive cycle, power consumption, forces acting on, acceleration, etc.,
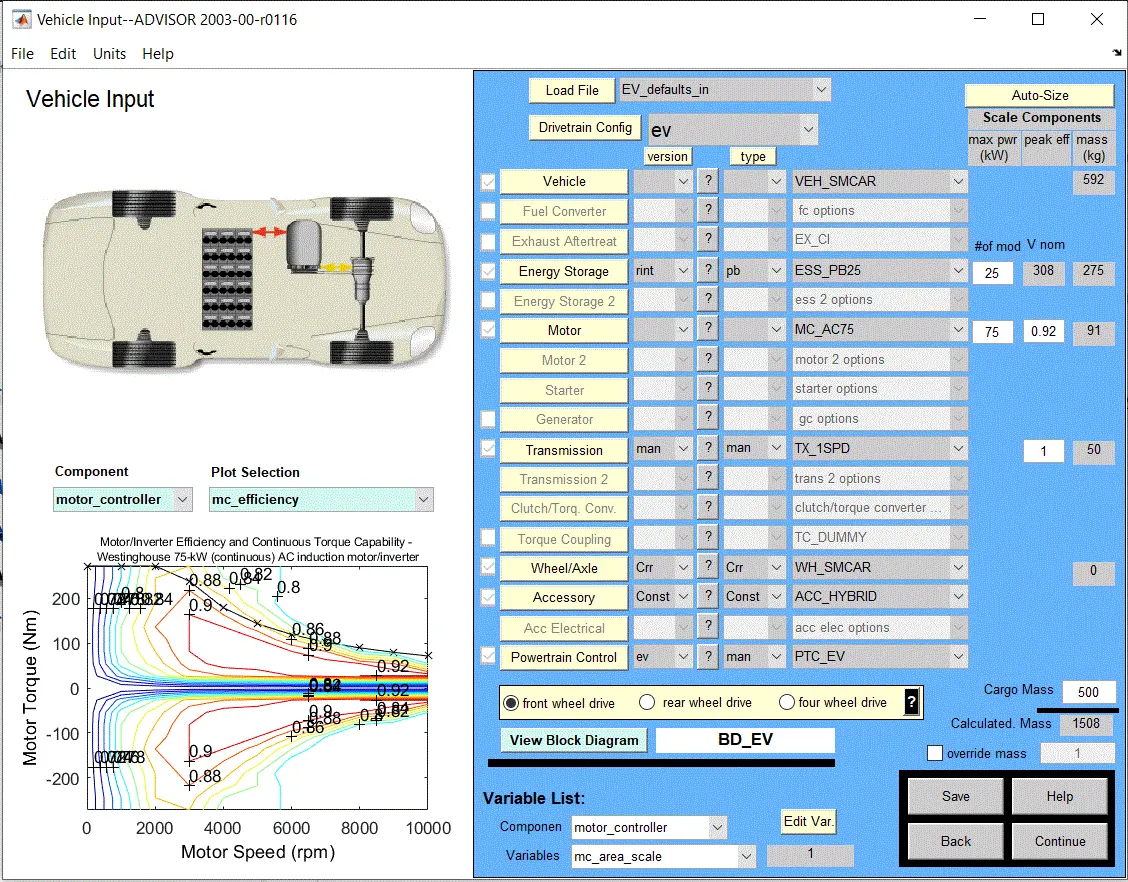
The above figure represents the EV car with many parameter variations and we also have many plots which will be very useful to understand the behavior of the vehicle at applied conditions and varied parameters.
Now according to the question, we changed the cargo mass to 500kg and observed various cycles to determine whether it can reach 45km of distance with the FTP drive cycle.
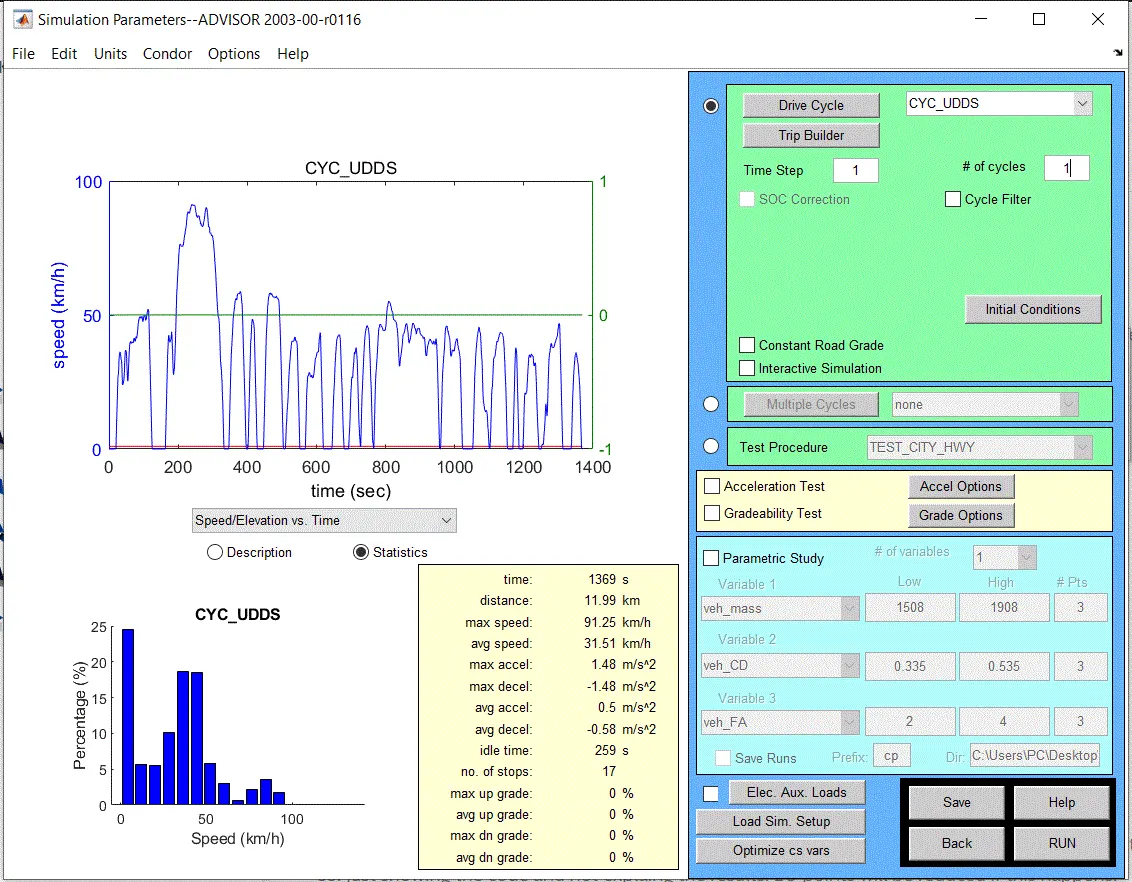
In the above figure, we noticed that for cycle(1) distance covered is 12km with 2.4 equivalent gasoline.
For cycle(2) we noticed the distance covered is 24km with 2.4 equivalent gasoline.
For cycle(3) we noticed the distance covered is 36km with 2.4 equivalent gasoline.
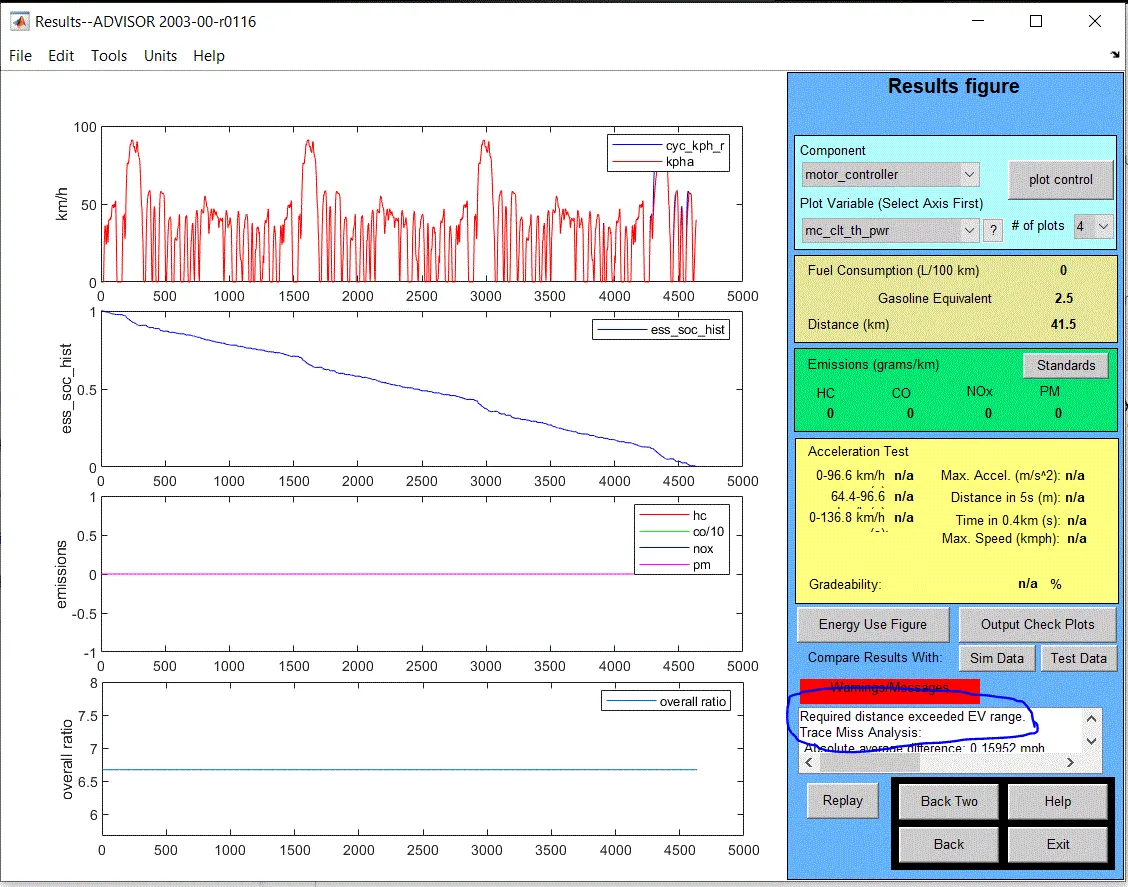
In the above figure, we noticed that for cycle(4) distance covered is 12km with 2.4 equivalent gasoline. And we can observe the message/warning where it reaches the maximum range(blue circled).
For cycle(5) we noticed the distance covered is 41.5km with 2.4 equivalent gasoline.
By this, we conclude that the above EV can reach up to 41.5km with 500kg cargo as weight increases the power consumed increases.
2. In this question we changed the battery parameters to observe the distance covered by the vehicle for cycles required.
For cycle(1) we noticed the distance covered is 12km with 2.4 equivalent gasoline.
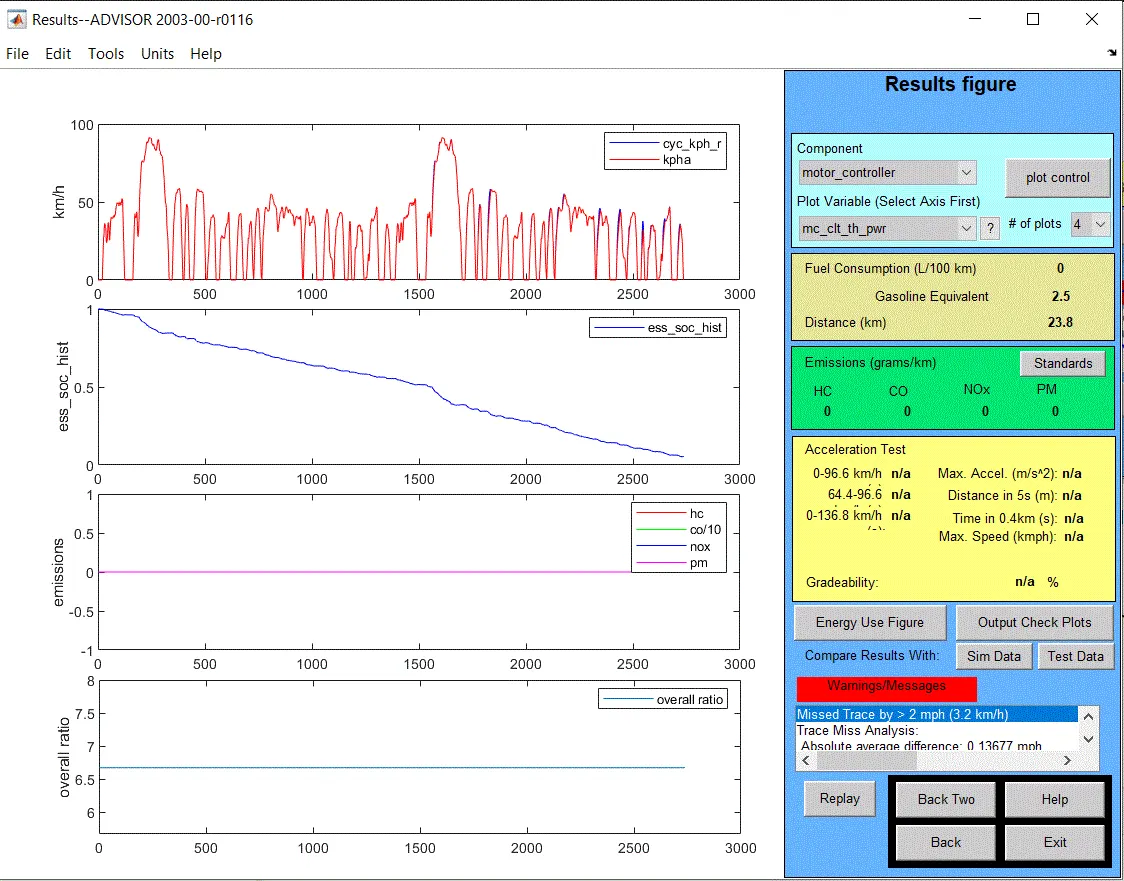
In this figure, we conducted cycle(2) and observed that it can reach up to 23.8km of distance with a 15mod change in battery.
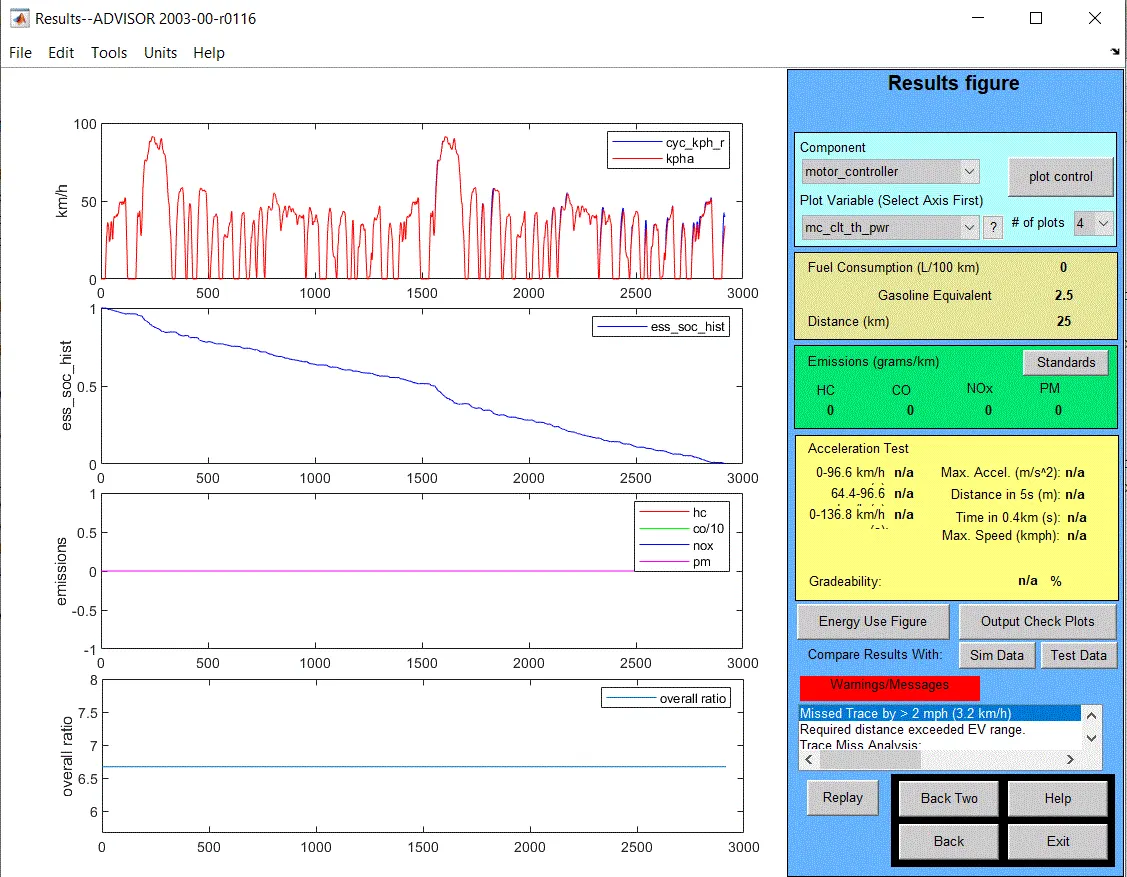
In this figure, we conducted cycle(3) and observed that it can reach up to 25km of distance with a 15mod change in battery.
And here we can observe that it exceeds the EV range at this cycle because we reduce the battery to 15mod from 25mod which will make the vehicle produce power for fewer cycles.
3. As given in the question I simulated the PRIUS_Jpn_defaults_in, where I varied the gradeability parameter of the vehicle and observed that when speed increases gradeability decreases i.e., inversely proportional to each other. Gradeability represents "rise/run" for an inclined surface.
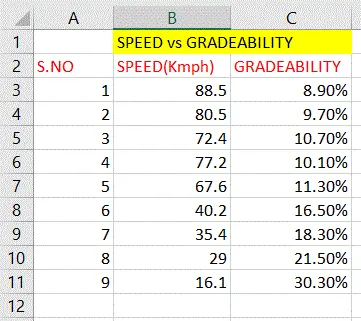
The above statement can be inferred from the results we obtained.