Week 3.2 - 2R Robotic Arm Challenge
Error :
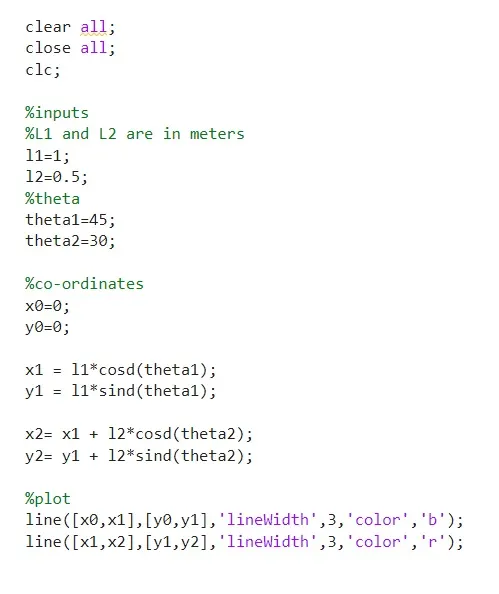
here have used cosd instead of cos because cos gives values in radians and cosd is in degree
steps:
1)we have given link L 1 and L 2 here whose length is particularly is 1 meter and 1.5 meter
2)then set an angle of theta 1 and theta 2 which is particularly 45 deg and 30 deg
3)then have set co-ordinates which are followes
a first link fixed to the base which has start (x0,y0) and end (x1,y1),which are (0,0) and (L1*cosd(theta1),L2*sind(theta1))
For second link which is connected to the first link is start co-ordinates are (x1,y1) and end co-ordinates are (x2,y2),which are (L1*cosd(theta1),L2*sind(theta1)) and (x1+L2*cosd(theta2),y1+L2*sind(theta2))
4)Now we are ploting it by line command
line ([x0,x1],[y0,y1],'linewidth',3,'color','b');
line([x1,x2],[y1,y2],'linewidth',3,'color','r');
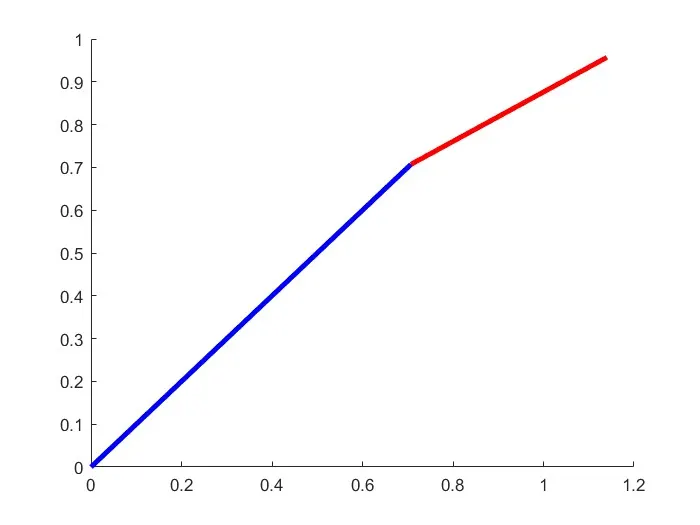
plot :
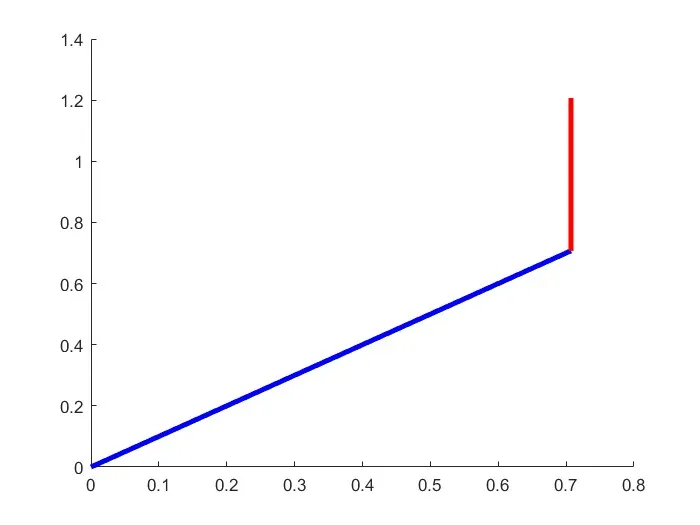
If I am keeping angle theta-2 90deg then
with theta-2 0 deg it will show stright line
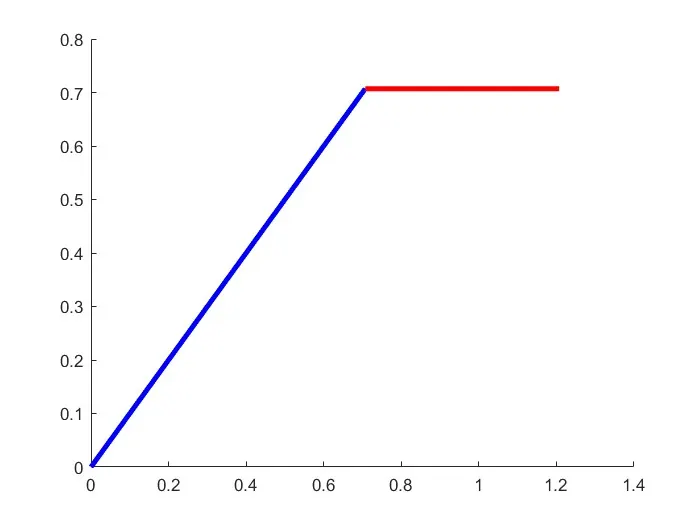
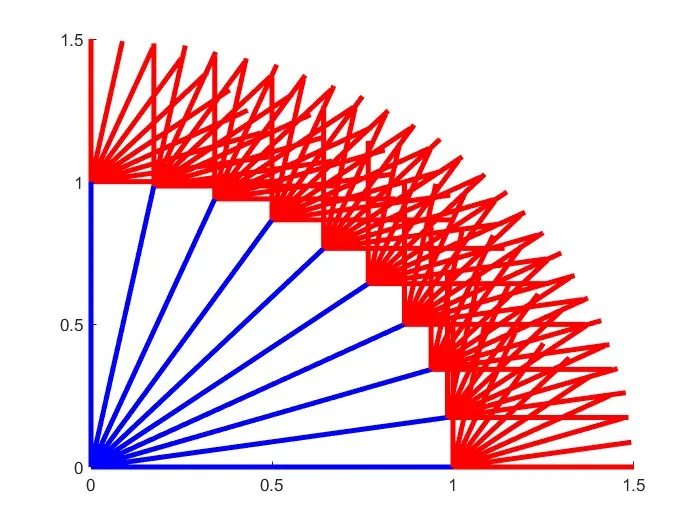
With variation in an angle its rotating along first arm while first arm is fixed to the base with constant angle .
so we can create animation for this robotic arm by changing its angle so for that will create new file or program .
clear all;
close all;
clc;
here for each theta 1 its ranging from 0 to 90 at 10 equal intervales and theta2 its from 0 to 90 at 10 equal intervales.
for loop indicates that for each value of theta 1 theta 2 is changing from 0 to 90
result : -
theta1=linspace(0,90,10)
theta1 =
0 10 20 30 40 50 60 70 80 90
change in theta2(i) is
theta2(i)
ans =
90
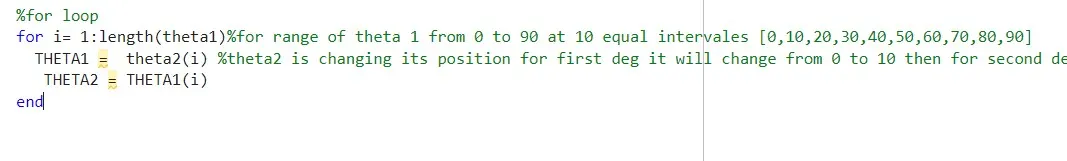
here in the for loop i = 1:length(theta1) which is changing from 0 to 90 at 10 equal intervales
theta2(i) is from 0 to 90 and THETA1 is variable which contain only one val
| Angle | ||||||||
|---|---|---|---|---|---|---|---|---|
| theta 1 | 0 | 10 | 20 | 30 | 40 | 50 | 60 | 70 |
| theta 2 | 0 - 90 | 0 - 90 | 0 - 90 | 0 - 90 | 0 - 90 | 0 - 90 | 0 - 90 | 0 - 90 |
here for each value of theta 1 theta 2 is changing from 0 to 90
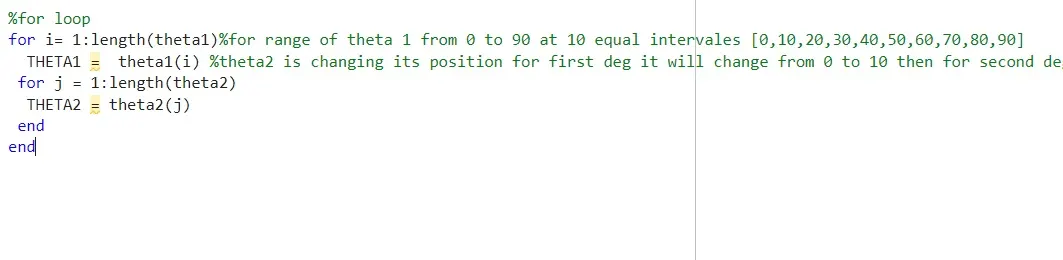
Here we are writing total program for robotic arm in which we have introduced THETA1 and THETA 2 which are variables and contain only one value
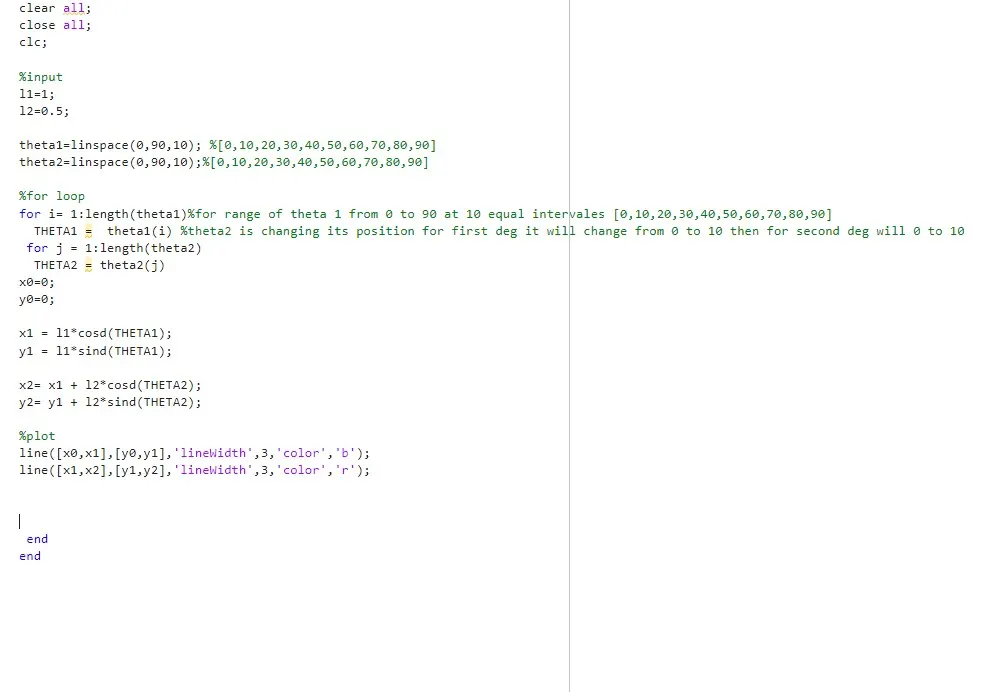
to the nest we have intruduced ct and ct + 1 for counter in an increment
then have merged two plots as well fixed our axes and created a movie for it
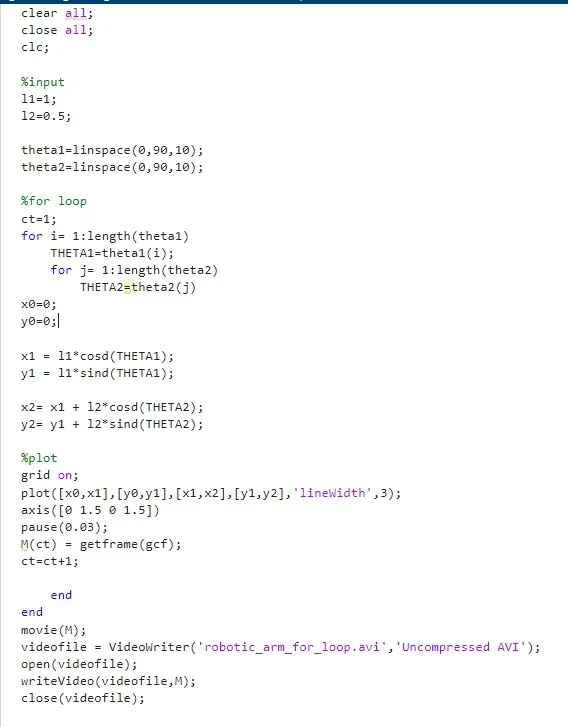
Error occure during movie creations are
was used samall v insted of V at writeVideo(videofile,M)
link for animation :
https://drive.google.com/file/d/1YSlNFUIpKSIDOfWXMlt74Xe425cstr03/view?usp=drive_link