Week 3.2 - 2R Robotic Arm Challenge
AIM-2R Robotic Arm Challenge .
Theory:-
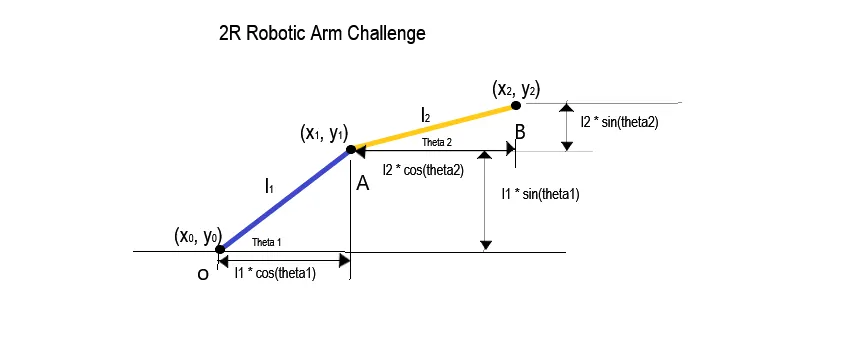
Here x0,y0 is the incial value .
theta is the angle of first arm .
x1,y1 is the joint of two arm .
x2,y2 is the end point 2nd arm .
here `x1=l1*cos(theta1)`
`y1=l1*sin(theta1)`
`x2=x1+l2*cos(theta2)`
`y2=y1+l2*sin(theta2)`
CODE IN MATLAB:
clear all
close all
clc
%inputs
l1=1;
l2=0.5;
theta1=linspace(0,90,10);
theta2=linspace(0,90,10);
ct=1;
for i=1:length(theta1)
    THETA1=theta1(i);
    for j=1:length(theta2)
        THETA2=theta2(j);
        %coordinats
x0=0;
y0=0;
x1=l1*cosd(THETA1);
y1=l1*sind(THETA1);
x2=x1+l2*cosd(THETA2);
y2=y1+l2*sind(THETA2);
%ploting
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
axis([-1 2 0 2])
pause(0.03)
M(ct)=getframe(gcf);
ct=ct+1;
    end
end
movie(M)
videofile=VideoWriter('Forword_kainametic.avi','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)
INNCORRECT CODE:
%kinametics of rubotic arms
clear all
close all
clc
%inputs
l1=1;
l2=0.5;
theta1=linspace(0,90,10);
theta2=linspace(0,90,10);
for i=1:length(theta1)
    THETA1=theta1(i);
    for j=1:length(theta2)
        THETA2=theta2(j);
%coordinats
x0=0;
y0=0;
x1=l1*cosd(THETA1);
y1=l1*sind(THETA1);
x2=x1+l2*cosd(THETA2);
y2=y1+l2*sind(THETA2);
%ploting
line([x0 x1],[y0 y1],'linewidth',3,'color','b')
line([x1 x2],[y1 y2],'linewidth',3,'color','r')
axis([-1 2 0 2])
pause(0.03)
    end
OUTPUT OF INCORRECT CODE:
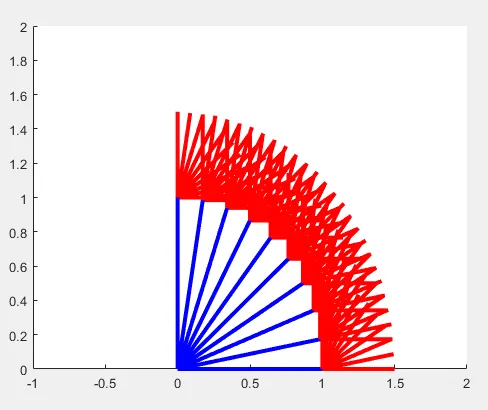
Here all the lines are ploted in one plot by every for loop ,so i replace the plot function by the line function ,then also i am not able to gate the proper plot ,so draw arm1 and arm2 in a one plot function .
Affter correction:
for corrected plot video
https://www.youtube.com/watch?v=YqXIyuuFOrA
Code explanation :
lear all:It remove all the variables stored in the current workspace.
close all:It close all the fig window opened if any from previous execution .
clc: This clear all the text from the commond windows.