Week -2
AIM:
- To make a Simulink Model of Door Bell using Solenoid Block.
- To make a Simulink Model Using a Thermistor to sense the temperature of Heater & turn ON or OFF the Fan.
STUDY- I : Make a Simulink Model of DoorBell using Solenoid Block.
SOLENOID:
A Solenoid is a type of electromagnet, the purpose of which is to generate a controlled magnetic field through a coil wound into a tightly packed helix. The coil can be arranged to produce a uniform magnetic field in a volume of space when a current is pass through it. The term solenoid was coined in1823 by Andre-Marie Ampere to designate a helical coil. In Engineering the term may also refer to variety of transducer device that convert energy into linear motion. The term is also often use to refer to a solenoid valve, an integrated device containing an electromechanical solenoid which actuate either a pneumatic value or hydraulic valve, or a solenoid switch, which is specific type of Relay that internally uses an electromagnetic solenoid to operate an electric switch for example an automobile starter solenoid or linear solenoid, solenoid bolts, a type of electromechanical locking mechanism, also exist. In electromagnetic technology, a solenoid is an actuator assembly with a sliding ferromagnetic plunger inside the coil. Without power, the plunger extends for part of its length outside the coil; applying power pulls the plunger into the coil. Electromagnet with the fix core is not considered solenoids.
Basic Component used to generate a simple Doorbell circuit is:
GIVEN CONDITION: IN the arrangement ,when the switch is closed the electromagnet receives electrical power from the Battery and pulls the metal arm to hit the bell producing sound by creating a situation where the switch is closed for 2 secs and then released.
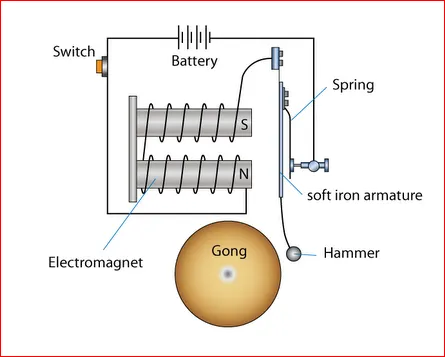
We have used the following Blocks in the model-
- Pulse Generator:
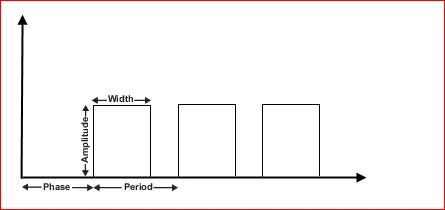
The Pulse Generator block generates square wave pulses at regular intervals. The block waveform parameters, Amplitude, Pulse Width, Period, and Phase delay, determine the shape of the output waveform. The following diagram shows how each parameter affects the waveform.
- Battery:
In Battery positive terminal is connected with switch and negative terminal is connected to “Electric Reference”.
- Switch:
The switch Block model a switch is controlled by an external physical signal.
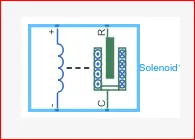
- Solenoid Block:
Solenoid Block is connected with Switch and Battery and electrical circuit will be formed.
The Solenoid Block represents the Electrical characteristics and generated force for the solenoid in the following figure:
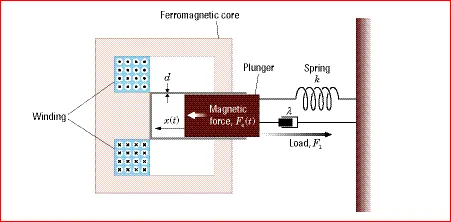
The return spring is optional. To remove the effects of this spring from the model, set the spring constant parameter as from 0 to 10.
To show the direction in which the solenoid acts the block icon changes dynamically based on value of the Motion direction under excitation parameter.
The Port ‘C’ is connected with Mechanical Translation reference.
- Ideal Translation Motion Sensor Block:
Ideal Translation Motion Sensor Block is connected with Solenoid Block ‘R’ to observe the Physical movement of the Plunger.
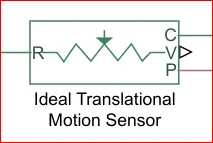
Connections R and C are mechanical translational conserving ports that connect the block to the nodes whose motion is being monitored. Connections V and P are physical signal output ports for velocity and position, respectively.
The block positive direction is from port R to port C. This means that the velocity is measured as v = vR – vC, where vR, vC are the absolute velocities at ports R and C, respectively.
Port C is connected with Mechanical translational reference.
- Scope:
Scope is connected with Ideal Translation Motion Sensor to get the output. The real-time Scope block acquires data in chunks of size Number of samples from the real-time application that is executing on the target computer.
- PS-Simulink Converter:
The PS-Simulink Converter block converts a physical signal into a Simulink output signal. Use this block to connect outputs of a Physical Network diagram to Simulink scopes or other Simulink blocks.
- Simulink-Ps Converter:
This Block convert simulink signals into physical signal for operational use in Model.

- Electrical Reference Block:
The Electrical Reference block represents an electrical ground. Electrical conserving ports of all the blocks that are directly connected to ground must be connected to an Electrical Reference block. A model with electrical elements must contain at least one Electrical Reference block.
- Mechanical Translation Reference Block:
The Mechanical Rotational Reference block represents a reference point, or frame, for all mechanical rotational ports. All rotational ports that are rigidly clamped to the frame (ground) must be connected to a Mechanical Rotational Reference block.
- Solver Configuration:
Each physical network represented by a connected Simscape block diagram requires solver settings information for simulation. The Solver Configuration block specifies the solver parameters that your model needs before you can begin simulation.
OBJECTIVES:
For DoorBell- Create a situation where the switch is closed for 2 sec and then released. Observe the physical movement of the plunger.
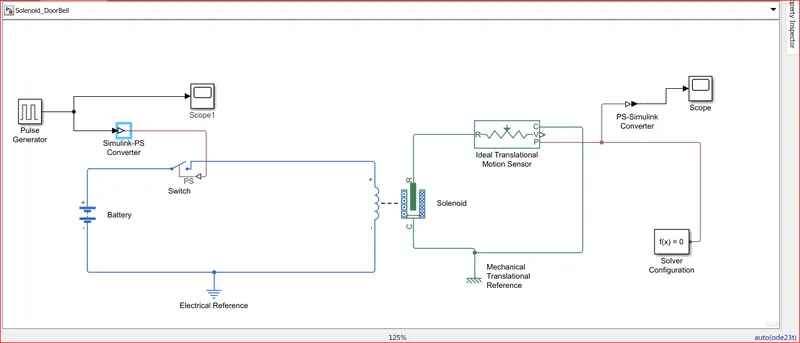
SIMULINK MODEL:
EXPLANATION:
- From the above governing circuit of a DoorBell, we know that we need a switch, solenoid, battery and a plunger.
- So, in order to get these entire component in simulink model we have to select the block that perform same action what the above device perform.
- Now first a “Solenoid block” is taken to represent a solenoid in the model, then to represent battery we have taken “Battery Block” from the library Browser.
- Then this “Solenoid Block” & “Battery Block” are connected to each other via positive and negative terminals.
- A “Switch Block” is placed between “Solenoid Blocks” and “Battery Block “and is connected with both Blocks.
- Now for switch to operate we need to provide Physical signal through “PS” port in the “Switch Block”. The provided physical signal should be greater than the threshold of the switch, for switch being close, or else it will be open.
- Now this whole Battery Switch and Solenoid path is connected to an “Electric Reference Block” which represents earthing of the circuit. This “Electric Reference Block” should be connected to the negative terminal of “Battery Block”.
- Then in the solenoid block “R” and”C” are two variable which represent Plunger and Fixed Point respectively.
- Now the solenoid “R” is connected to “R” of “Ideal Translation Motion Sensor Block” which senses the position of plunger in the Solenoid Block and gives the Output.
- Now in the “Ideal Translation Motion Sensor Block” the output are given as “V” & ”P” which represent the velocity and position of the plunger. Since we are only interested in knowing the change in position of the plunger, so we need only results of “P” output.
- Now “C” in the “Ideal Translation Motion Sensor Block” is a mechanical translation conserving port, which means that the mechanical process starts from “R” and end at “C” and again it start at “R” and the cycle goes on.
- So “C” in the “Ideal translation Motion sensor block” is connected to “Mechanical Translation Reference” which represents a fix point where it is rigidly clamped in real time.
- Similarly “C” of the solenoid block is also connected to the same “Mechanical Translation Reference” as fixed point for solenoid.
- Since we position of the plunger as output from “Ideal Translation Sensor Block” we have connected port”p” to a ‘PS-Simulink Converter’ where the Physical value from port ’P’ are converted into Simulink value, and then this ‘PS-Simulink Converter’ is connected to ‘Scope Block’ which will generate a graph for change in position of Plunger from port ‘P’ of ‘Ideal Translation Motion Sensor Block’.
- Now to provide a physical signal for operating the switch, we have used a “Pulse Generator Block”, which generates a continuous Square Pulse.
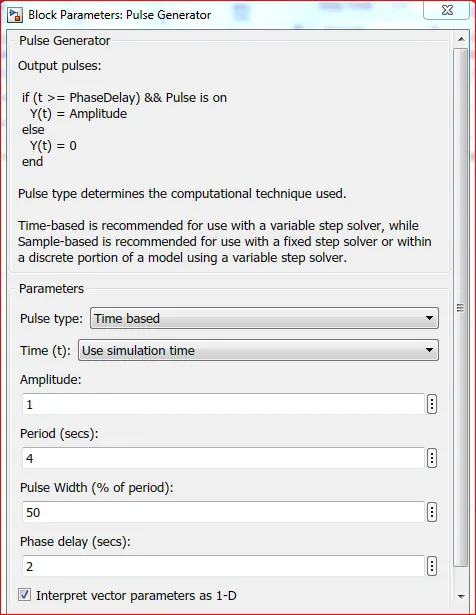
- From the above figure we can observe we have given period value as “ 4 ” pulse width as ‘50’, phase delay as ’2’ and Amplitude by default is ‘1’ we have not changed it. This means that initially the Pulse will be Zero, Since we have given Phase Delay of “2” so till 2 sec the Pulse will be Zero and at the end of 2 sec the Pulse will start rising from Zero to 1, Since we have given Amplitude as “1” and then now the Pulse width will be Half of Period, So for the next 2 seconds the Pulse will be at Amplitude “1” only, then it will again come down to zero at 4th Second and then it will be Zero. So, after these 4 seconds period again the pulse will be generated and thus cycle continues.
- From starting to ending of the Pulse it will take 4 sec of time period in which only for 2 secs the Amplitude will be “1” and for rest of time it will be Zero. So, after these 4 secs period again the Pulse will be generated and thus Cycle continues.
- To this “Pulse Generator” a “Scope Block” is connected to see how the Pulse is generated.
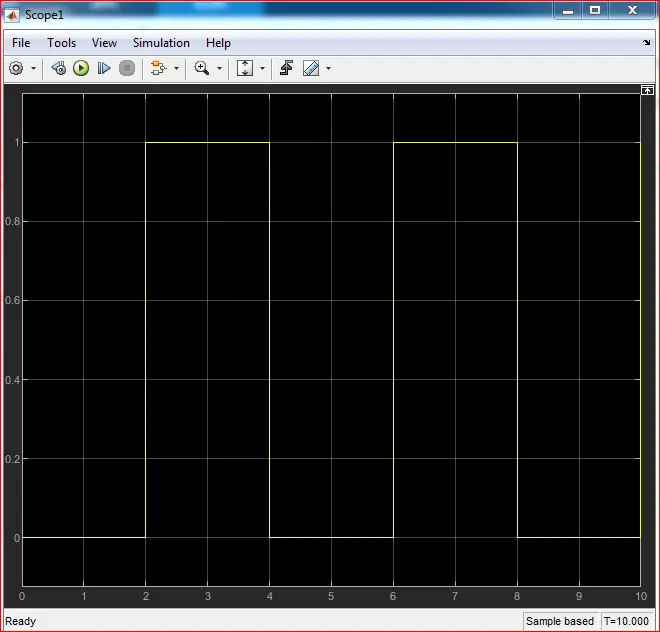
- The above figure is obtained by running the Simulink Model and double clicking the “Scope1 Block”. This figure shows how the Pulse is generated and in this figure the X-axis represents the “Time” and Y-axis represents the “Amplitude”. As mentioned in the point no.18, the Pulse has started from 2 sec and ending at 6 sec which is nothing but a time period of 2 secs.
- Thus, this represents that when amplitude is 1, the switch will be close and current will start flowing and when it is zero the switch will open and current stop flowing. Since our objective is only to see the change in position of Plunger when Switch is Close for 2 sec , so we have the Amplitude as 1 for 2 sec in the Pulse generator by making the Pulse width half of the period in the inputs fir “Pulse Generator Block”.
- Since the Pulse that is coming from “Pulse Generator Block” is a Simulink value, so to convert this value into Physical value we have used “Simulink-PS Converter Block”, since Switch only takes Physical value as Inputs.
- As mention above, the port “P” of “Ideal Translation Motion Sensor Block” is connected to another “Scope2 Block” and a “Solver Configuration Block” is also connected to this path which generates Equations and solves the whole Model internally to give the results of the Whole Simulink Model output.
- Now Run the Model and Double click on the “Scope2 Block” which is connected to “Ideal Translation Motion Sensor Block” to get the results.
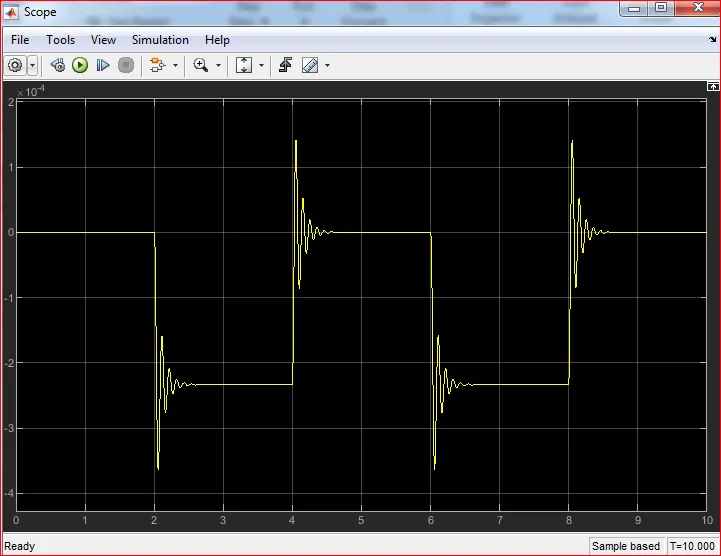
- We will get the above Graph as the result when we double click on “Scope2 Block”. Here X-axis Represent the “Time” and the Y-axis represent position of Plunger in mm.
- From the above figure we can observe that the initial position of the Plunger is at “5mm” as from Pulse generator Block, a Pulse generated at 2, so in the position of the Plunger is also changing at time 2 seconds and time till which the Pulse Amplitude is “1” till that time plunger is also at the same position after the change from initial position.
- Again, as the Amplitude of the Pulse become zero, the Plunger returns to the Original position back again and as the pulse cycle goes on, Plunger is also at same position after the change from initial position.
- We can also observe that when there is change in position of the Plunger, there is some Wave form at the start of change in position. This is due to recoil of spring, each time when the Plunger is moving. So to reduce this, in the “Solenoid Block” we can reduce the spring constant value and increase the Damping Coefficient. This will reduce the Waves that are being formed and we will get a smooth graph.
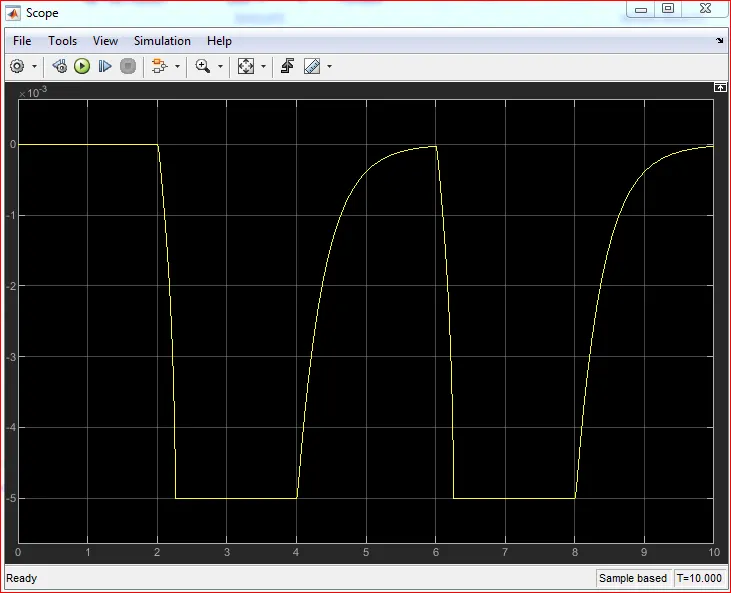
- The above figure is a smoother graph than previous one. This was done by changing the value of spring constant and Damping Coefficient in the “Solenoid Block”.
STUDY-II - Simulink Model for Fan operating system using Thermistor.
THERMISTOR:
A Thermistor is a type of Resistor whose Resistance dependent on temperature, more so than is standard resistors. The word is a combination of thermal and resistor. Thermistor are widely used as inrush current limiters, temperature Sensor (negative temperature coefficient or NTC type typically), self-resetting overcurrent protector, and self-regulating heating elements (positive temperature coefficient or PTC type typically).
Thermistors are of two opposite fundamental types:
- With NTC Thermistor, resistance decrease as temperature rises. An NTC are commonly use as Temperature Sensor, or in series with a circuit as an inrush current limiter.
- With PTC Thermistor, resistance increases as temperature rises. PTC Thermistor is commonly installed in series with a circuit, and use to protect against overcurrent conditions, as resettable Fuse.
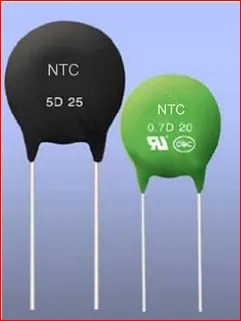
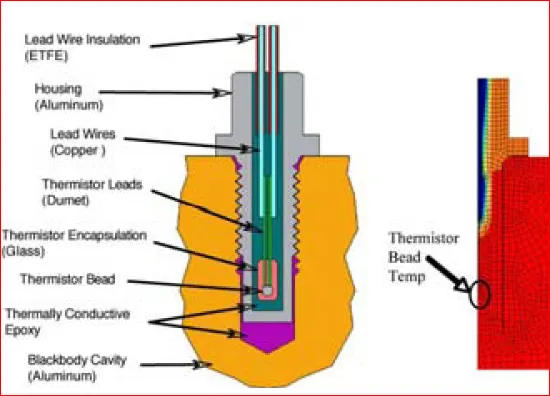
Thermistors are generally produced using powdered metal oxides. With vastly improved Formula and Technique over the last 20 years, NTC Thermistor can now achieve accuracies over wide temperature range such as (+-0.1)’C or (+-0.2)’C from 0 degree Celsius to 70 degree Celsius with the excellent long term Stability. The typical operating temperature range of a Thermistor is (-55) degree Celsius to (+150) degree Celsius, though some glass body Thermistor have a maximal operating temperature of (+300) degree Celsius.
Thermistor differ from resistance temperature detector (RTDs) in that the material used in Thermistor is generally a ceramic or polymer, while (RTDs) use pure metals. The temperature response is also different RTDs are useful over large temperature ranges, while Thermistor typically achieve a greater precision within a limited temperature range, typically -90 degree Celsius to 130 degree Celsius.
FOR FAN OPERATIONS USING THERMISTOR:-
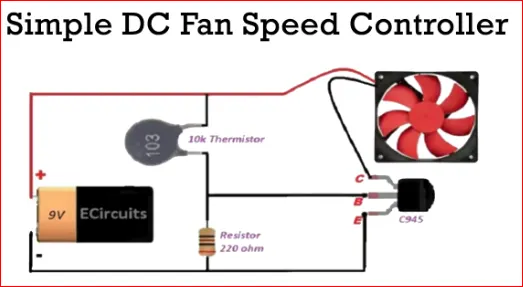
Basic Component used to generate a simple Thermistor operated Fan circuit is:
- Signal Builder Block:
The Signal Builder block allows you to create interchangeable groups of piecewise linear signal sources and use them in a model. You can quickly switch the signal groups into and out of a model to facilitate testing. In the Signal Builder window, create signals and define the output waveforms. To open the window, double-click the block.
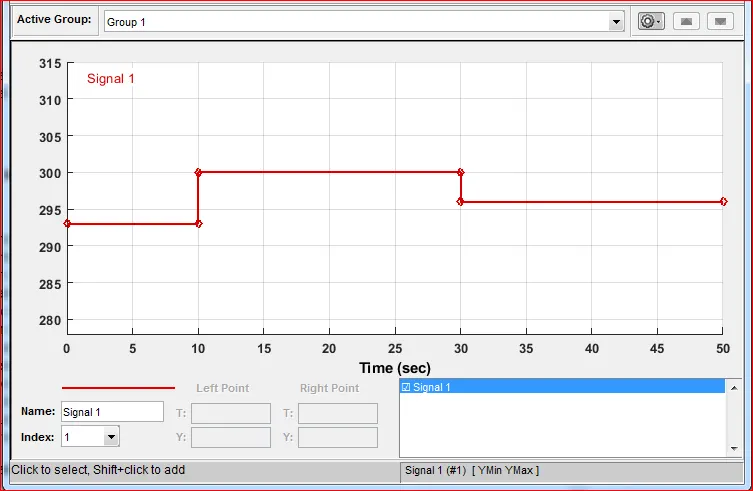
Given inputs :
At Point-1 - Time 0 sec - Temperature is 293K,
At Point-2 - Time 10 sec - Temperature is 293K,
At Point-3 - Time 10 sec - Temperature is 300K,
At Point-4 - Time 30 sec - Temperature is 300K,
At Point-5 - Time 30 sec - Temperature is 296K,
At Point-6 - Time 50 sec - Temperature is 296K,
- Controlled Temperature Source:
The Controlled Temperature Source block represents an ideal source of thermal energy that is powerful enough to maintain specified temperature difference across the source regardless of the heat flow consumed by the system.
Connections A and B are thermal conserving ports corresponding to the source inlet and outlet, respectively. Port S is a physical signal port, through which the control signal that drives the source is applied.
- Thermistor:
A Thermistor is a type of resistor whose resistance dependent on temperature, more so than in standard resistors. The word is combination of Thermal + Resistor.
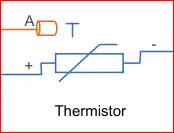
The Thermistor block represents an NTC Thermistor using the B-parameter equation.
NTC – Negative Terminal Coefficient
- Resistor:
The Resistor block model a linear resistor, describe with the following equation.
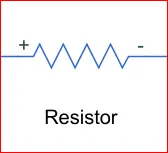
V = I.R
Where,
V = Voltage.
I = Current.
R = Resistance.
- Voltage Sensor:
The Voltage Sensor block represents an ideal voltage sensor, that is, a device that converts voltage measured between two points of an electrical circuit into a physical signal proportional to the voltage.
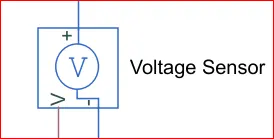
Connections + and – are electrical conserving ports through which the sensor is connected to the circuit. Connection V is a physical signal port that outputs the measurement result.
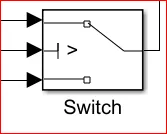
- Switch:
The Switch block passes through the first input or the third input signal based on the value of the second input. The first and third inputs are data input. The second input is a control input. Specify the condition under which the block passes the first input by using the Criteria for passing first input and Threshold parameters.
- Constant Block:
The Constant block generates a real or complex constant value signal. Use this block to provide a constant signal input. The block generates scalar, vector, or matrix output, depending on:
The dimensionality of the Constant value parameter
The setting of the Interpret vector parameters as 1-D parameter
The output of the block has the same dimensions and elements as the Constant value parameter.
- Simulink-Ps Converter:
This Block convert simulink signals into physical signal for operational use in Model.
- PS-Simulink Converter:
The PS-Simulink Converter block converts a physical signal into a Simulink output signal. Use this block to connect outputs of a Physical Network diagram to Simulink scopes or other Simulink blocks.
- Electrical Reference Block:
The Electrical Reference block represents an electrical ground. Electrical conserving ports of all the blocks that are directly connected to ground must be connected to an Electrical Reference block. A model with electrical elements must contain at least one Electrical Reference block.
- Battery:
In Battery positive terminal is connected with switch and negative terminal is connected to “Electric Reference”.
- Solver Configuration:
Each physical network represented by a connected Simscape block diagram requires solver settings information for simulation. The Solver Configuration block specifies the solver parameters that your model needs before you can begin simulation.
- Scope:
Scope is connected with Ideal Translation Motion Sensor to get the output. The real-time Scope block acquires data in chunks of size Number of samples from the real-time application that is executing on the target computer.
SIMULINK MODEL:
EXPLANATION:
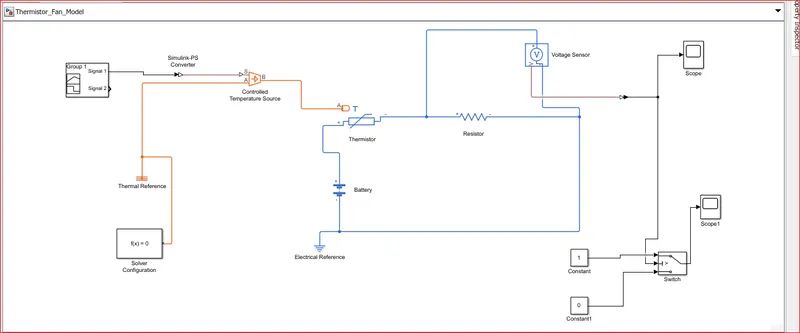
- To create a Simple Fan Cooling Model using Thermistor,Battery,Resistor,Voltmeter, a logical switch which are basic component of the circuit we need in Simulink model.
- First to represent a Thermistor, a “Thermistor Block” is taken and placed in model. Now to represent Battery, a”Battery Block” is taken and the positive terminal of this block is connected to positive port of the “Thermistor Block”.
- Now to represent a Resistor, a “Resistor Block” is taken from Library browser and its positive port is connected to negative port of “Thermistor Block”. The negative port of “Resistor Block” is connected to negative port of “Battery Block”. Now a “Electrical Reference Block” is connected near the negative terminal of the “Battery Block” which represent the Earthing of the real time circuit.
- Now to represent a Voltmeter a “Voltage Sensor Block” is connected parallel to the “Resistor Block”, because to measure the voltage across a component, voltmeter should always connected parallel to that component.
- Thus, we have completed our simple circuit Model, but we need some Physical Quantities to as Signal for Thermistor to work.
- In this case we need the Fan to get ON and OFF at different temperatures. So , to provide temperature , we have used “Controlled Temperature Source Block” which will gives a specified temperature as output even though heat flow is more.
- Now to give different temperature to this “Controlled Temperature Source Block” we need to send Temperature signals. To send these signals we have used a “Signal Builder Block” which allows us to send any type of signal as inputs.
- We have to double click on the “Signal Builder Block” to set the signal configuration according to our requirement.
- Above Figure shows how signals are set in the “Signal Builder Block”. As this Dialogue Box opens, first we have to click on “Signal” at the top and then select “New” then select “Custom” option. Now it will ask to give the value of Y-axis and X-axis. Since we know that at which time, we need which temperature as mentioned in the starting. We can give those values in an array in this box and then the above figure signals are generated.
- We can see in the figure that how different temperatures are given at different time. So, thus we have created our Signals and before connecting it to the “Controlled Temperature Source Block” we have to convert these Signals into Physical Value. So, to do this we have used a ”Simulink-PS Converter Block”.
- So now the port “B” of “Controlled Temperature Source Block” is connected to port ‘A’ of the “Thermistor Block” and port ‘A’ of “Controlled Temperature Source Block” is connected to the “Thermal Reference Block”. In “Controlled Temperature Source Block” a positive temperature difference causes the temperature at port ‘B’ to be greater than the temperature at port ‘A’.
- Now the output of the “Voltage Sensor Block” is connected to “Scope Block” first and before connecting to the “Scope Block” a “PS-Simulink Converter” is used to convert Physical value to Simulink values.
- Now when we run the simulation and Double click on the “Scope Block” we will get the following Graph.
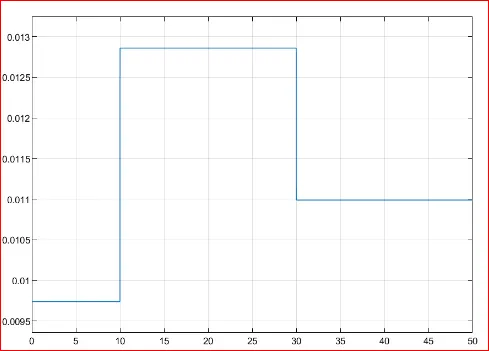
- From the above figure we can see that how voltage is changing with the change in temperature. Using this information, we can set condition for Fan to ON & OFF.
- If we observe the graph, we notice that from time 0 to 10 seconds when the temperature is 293K, Voltage is between 0.0095 and 0.01 and from time 10 to 30 seconds when the temperature is 300K, Voltage is between 0.0125 and 0.013 and from time 30 to 50 seconds when the temperature is 296K, Voltage is nearly 0.011.
- As mention in the objectives fan should be ON when the temperature is more than 25 degree Celsius i.e. 298.15K, from the above graph when voltage is more than 0.011 the Fan should get ON and when the Voltage is below 0.011, Fan should get OFF.
- This above Logic used to ON and OFF the Fan. To do this we have used a “Switch Block” that routes the Signal according to the conditions provided.
- The center port of “Switch Block” is connected to output of “PS-Simulink Converter” which gives the Voltage values. The top port of the “Switch Block” is connected to a “Constant Block” of value ‘1’ and the bottom port of the “Switch Block” is connected to another “Constant Block” of value ‘0’.
- The center port of “Switch Block” is the condition input which means that when the value from “Voltage Sensor Block” is more than the Threshold value in the “Switch Block” then it will pass the value ‘1’ which we have specified in the top port of the “Switch Block”. If the Voltage from the “Voltage Sensor Block” is less than the Threshold value in the “Switch Block” then it will pass the value ‘0’ which we have specified in the bottom port of “Switch Block”. Here it acts like a Transistor in Real time Circuit.
- To set the “Threshold value” of the “Switch Block”, we have to Double click on the “Switch Block” and then we can change the value of Threshold. Since we want to be ON only when the temperature is 300K so the Threshold value is given as {0.011}. so when the Voltage gets more than “0.011” the Switch will give value ‘1’ as output which means Fan will be ONN and when Voltage get less than 0.011 the Switch will give value ‘0’ as output which certainly means Fan will get OFF.
- Now the output of “Switch Block” is connected to another “Scope Block” to get results.
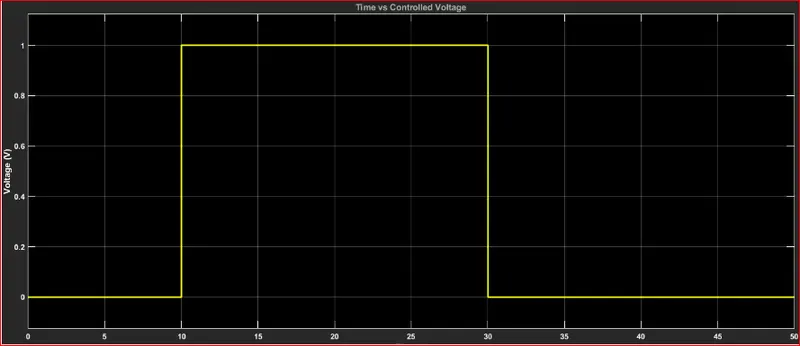
- By Double clicking the “Scope Block” we can observe the above Graph. Here we can clearly see that when temperature is 300K the Fan is ON and at remaining temperature the Fan is OFF.
CONCLUSION:
- Thus, both the objective was achieved successfully.
- Similar approach can be used for simulating other Physical Device using Simulink.
- Fan temperature was sensed by the thermistor in the Heater Model.
REFERENCE:
- https://www.youtube.com/watch?v=liIKeYxa00I
- https://www.youtube.com/watch?v=X76cKIVe-HY&t=691s
- https://www.youtube.com/watch?v=MDXwZhKlELI&t=332s
4.https://in.mathworks.com/help/physmod/sps/ref/solenoid.html
5.https://www.electrostudy.com/2011/10/ntc-and-ptc-thermistor.html