Week 2- 2R Robotic Arm Challenge
AIM:- To write a program in matlab to simulate the forwward kinematics of a 2R Robotic ARM
Objective:-
1. write a program to simulate forward kinematics of a 2r robotic arm
2.To creat a movie /animation from the plots obtained from the program
Theory:-
A robotic arm is a type of mechanical arm usually programmable with similar functions to a human arm the armmay be the sum total of the mechanism or may be part of a more complex robot the links of such a manipulated are connected by joints allowing either rotation motion such as in an ariculated robot or translational(linear)displacement the links of the manipulator can be considered form a kinematic chain the terminus of the kinematic chain of the manipulator is called the end effector and it is analogous to the human hamd .
in this project we consider 2R robotic arm A 2R robotic arm represents a robtic arm with two rotation ex:- it has two links which rotate or work over a two -dimensional plan with each of links having a single degree of freedom
also both the links are restricted to a 90 rotation with respect to the axes flg below shows the 2R roboticarm having many parts as described.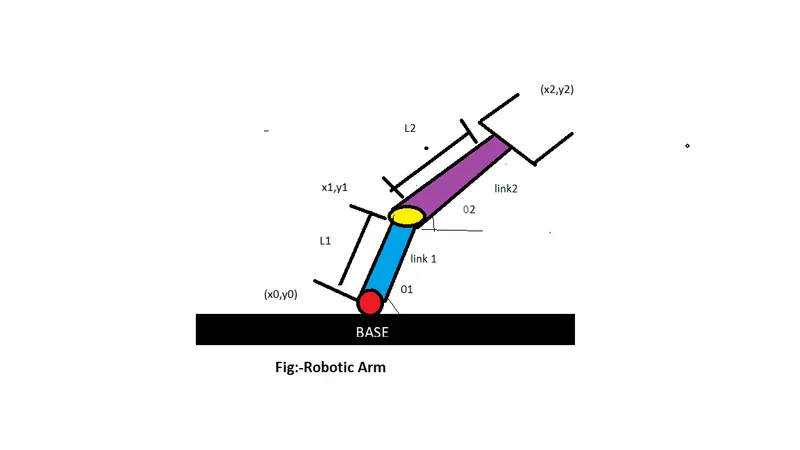
% inputs
l1 = 0.8;
l2 = 0.4;
theta1 = linspace(0,90,10);
theta2 = linspace(0,90,10);
ct=1;
for i = 1:length(theta1)
    THETA1 = theta1(i);
    for j= 1:length(theta2)
        THETA2 = theta2(j);
      x0 = 0;
      y0 = 0;

   x1 = l1*cosd(THETA1);
   y1 = l1*sind(THETA1);

  x2 = x1 + l2*cosd(THETA2);
  y2 = y1 + l2*sind(THETA2);


% Plotting
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3);
axis([-0.1 1.5 0 1.5])
pause(0.03);
M(ct) = getframe(gcf);
ct=ct+1;
    end
end

movie(M)
videofile = VideoWriter('forward_kinematics.avi','Uncompressed AVI');
open(videofile)
writeVideo(videofile,M)
close(videofile)