Week 2- 2R Robotic Arm Challenge
Aim - To write a program in matlab to simulate the forward kinematics of a 2R Robotic arm
Objective -
- To write a program to simulate forward kinematics of a 2R robotic arm.
- to create a animation /movie from the plots obtained from the programing.
CODE Explanation-
- starting the program using the comments.
- providing the input variable like, length /value of the robotic arm ,l1 & l2 .
- providing the value for theta 1& theta 2 using linspace command fir theta (0 to 90)for 10 values.
- providing the (ct) counter value.
- providing the coordinate x1,y1,x2,y2, of both robotic arms.providing the axis.
- using the pause command to make plot realistic.
- all figure assigned to a varible M
- using the movie command all the figure saved in the M file make an animation /movie.
- save the movie in the AVI format.
MATLAB PROGRAM CODE-
clear all
close all
clc
%inputs
%length of first arm(m)
l1 = 1;
%length of second arm(m)
l2 = 0.5;
% angle of the first arm
theta1 = linspace(0,90,10);
% angle of the second arm
theta2 = linspace(0,90,10);

%initiate the counter value
ct = 1;
for i =1:length(theta1)
    THETA1 = theta1(i);
    for j =1:length(theta2)
        THETA2 = theta2(j);
        x0=0;
        y0=0;

x1 = l1*cosd(THETA1);
y1 = l2*sind(THETA1);

x2 = x1+l2*cosd(THETA2);
y2 = y1+l2*sind(THETA2);

%plotting
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth',3)
axis([-0.1 1.5 0 1.5])
pause(0.06)
M(ct) = getframe(gcf);
ct=ct+1;
    end
end
%inserting frames in the animation to make movie

movie(M)
Videofile=VideoWriter('Robotic_arm.avi','Uncompressed AVI');
open(Videofile)
writeVideo(Videofile,M)
close(Videofile)
ERRORS -
unrecognized function of variable 'videowriter'
resolve this error again write the program coreect the 'VideoWriter'.
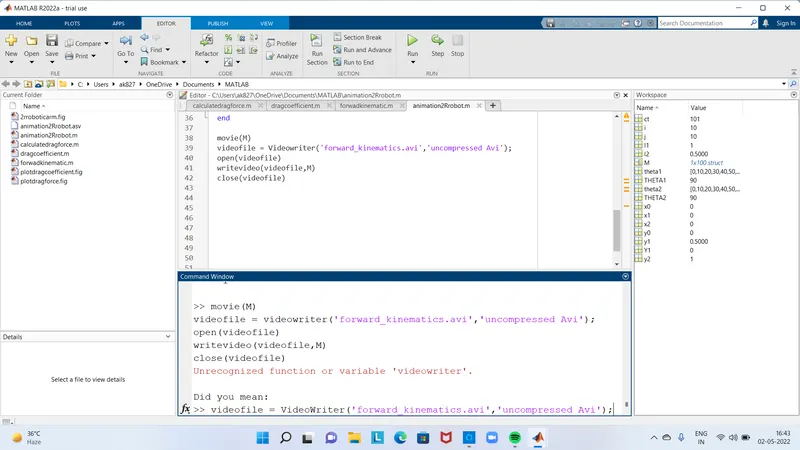
complete program screenshot-
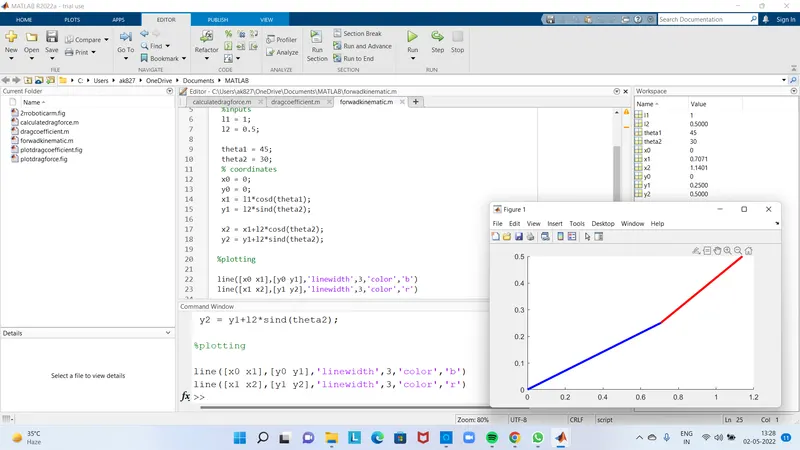
RESULT - 2R robotic arm by using the matlab programing created a movie / animation from the plots obtained from program.
https://1drv.ms/u/s!Ao7kj2qrB8wAfmzhPWVG61qoxqI?e=O98wkY
https://1drv.ms/u/s!Ao7kj2qrB8wAfmzhPWVG61qoxqI?e=Kd2wfz