Week 2- 2R Robotic Arm Challenge
Aim:
To write a program in Matlab to simulate the forward kinematics of a 2R Robotic Arm, as shown in the video.
Basic Introduction:
In our Program, we are going to use the basic arms of the robot to do that we are dealing with the linkage known as Forward kinematics of a 2R Robotic arm (where 2R means 2-rotating Link i.e 2 is a number of link and R is rotation). ... We need to Animate the Arm and find out its behavior in Different conditions.
Points To Remember:
1.Co-ordinates of link 1
2.Co-ordinates of link 2
3.angles
4.Ploting
program:
%To create a program in Matlab to simulate the forward kinematics of a 2R Robotic Arm

clear all
close all
clc
% Inputs
l1=2;
l2=1;
theta1 = linspace(0,80,10);
theta2 = linspace(0,80,10);
a1=theta1;
a2=theta2;

ct=1;
for i= 1:length(a1) %represents the no of value in angle1
    A1=a1(i);
    for j= 1 : length(a2)
        A2=a2(j);
x0=0;
y0=0;
x1 = l1* cosd(A1);
y1 = l1* sind(A1);
x2 = x1+l2* cosd(A2);
y2 = y1+l2* sind(A2);
%plotting
plot([x0 x1],[y0 y1],[x1 x2],[y1 y2],'linewidth', 3);
axis([-0.3 3.6 -0.3 3.6])
pause(0.1);
M(ct)=getframe(gcf);
ct=ct+1;
    end
end
movie(M)
videofile = VideoWriter('forward_kinematics.mp4');
open(videofile)
writeVideo(videofile, M)
close(videofile)
Output:
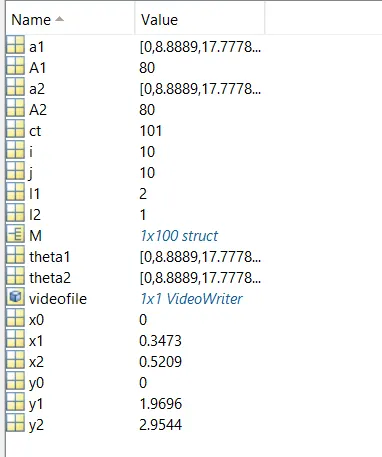
Explanation:
1.Based on governing equation we are taking x,y Co-ordinates & theta's.
2.Perform and ploting the forward kinematics of a 2R Robotic arm.
Errors:
Reducing Errors:
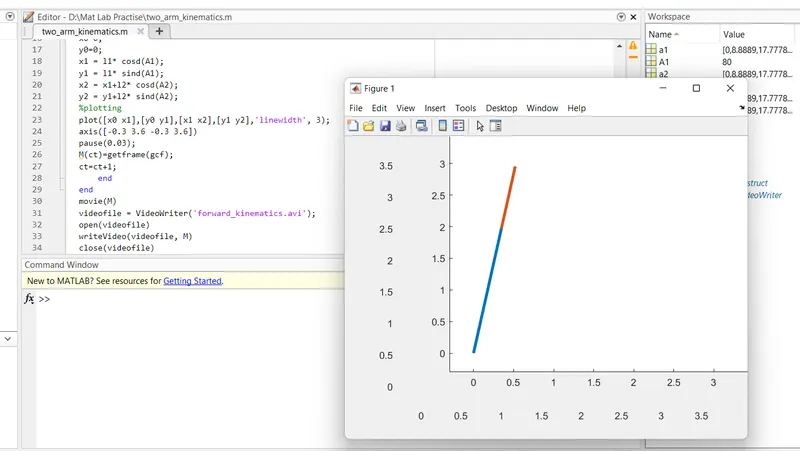
I am facing Little bit of errors in plotting but Again Reduced by Relearn the video which was in our website Matlab skill-lync.
So My animation of forward kinematics of a 2R Robtic Arm YOUTUBE link was given below:
Coclusion:
It would be applicable in kinematic equations of a robot to compute the position of the end-effector from specified values for the joint parameters. The kinematics equations of the robot are used in robotics, computer games, and animation.