week-11 Joint creation and Demonstration
Aim:
- To perform and demonstrate spherical, revolute, cylindrical, and translational joints between two rigid and deformable
Objective:
- Describe the types of joints like spherical, revolute, cylindrical & translational joints
- For all the joints simulate with rigid & deformable material respectively
Procedure:
- There are remarkable cards that are commonly used in all types of joints. Those are used in rigids & deformable
Material
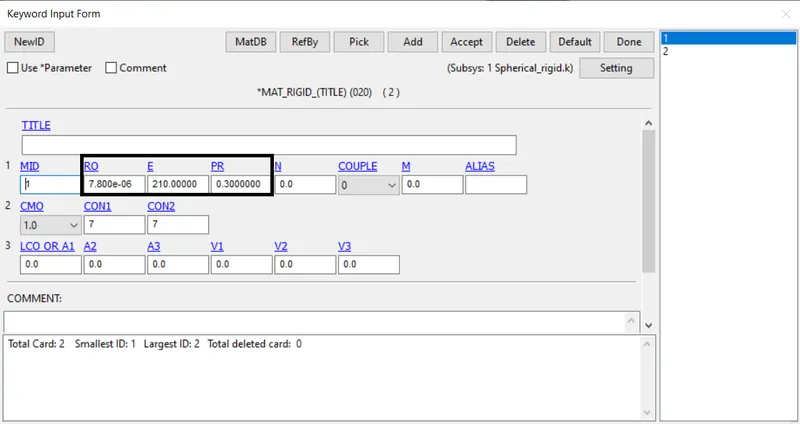
- *MAT_RIGID is used for all the rigid cases in all four joints. The steel characteristics are used here
- Here CMO=1.0, constraints applied in local directions (SPC constraint)
CON1=7, constrained upon x, y, and z displacements
CON2=7, constrained upon x, y, and z rotations
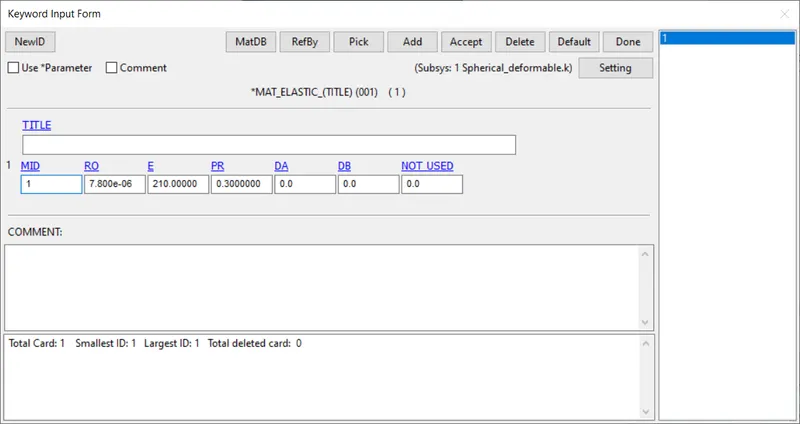
- *MAT_ELASTIC is used for all the deformable cases in all four joints. The aluminum properties are used here
Section
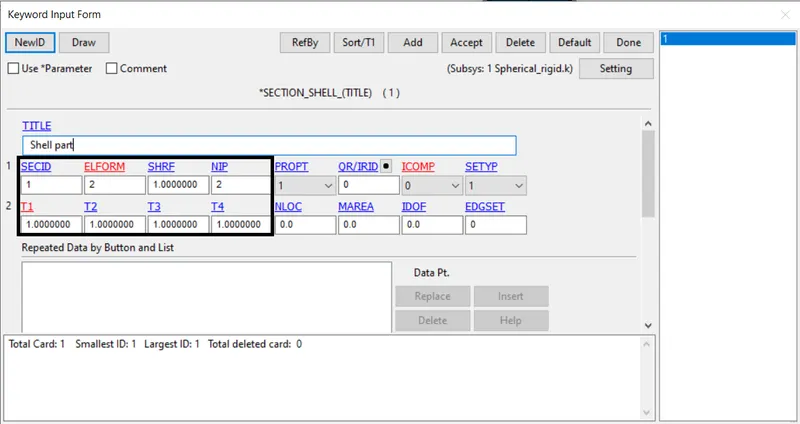
- The section card used here for the FE joints are Shell type with an Element formulation of 2 along with the thickness of 2mm
Control cards
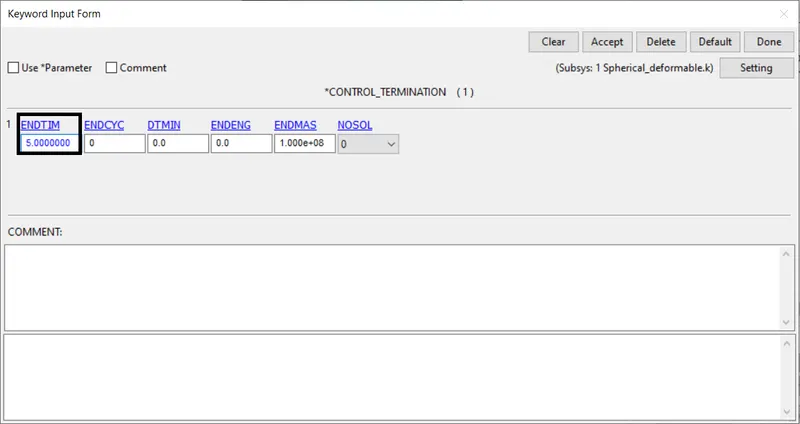
- Termination time is kept at 5 ms for all the joints regards rigids and deformable
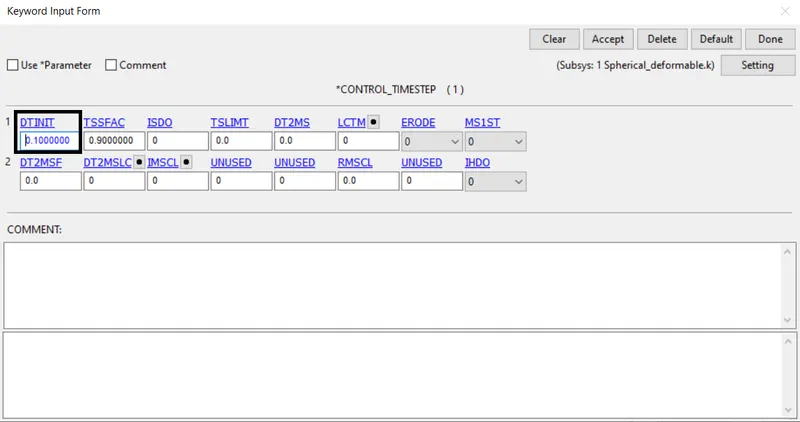
- The initial time step size is given as 0.10ms for all the joints respectively to rigids and deformable
Database
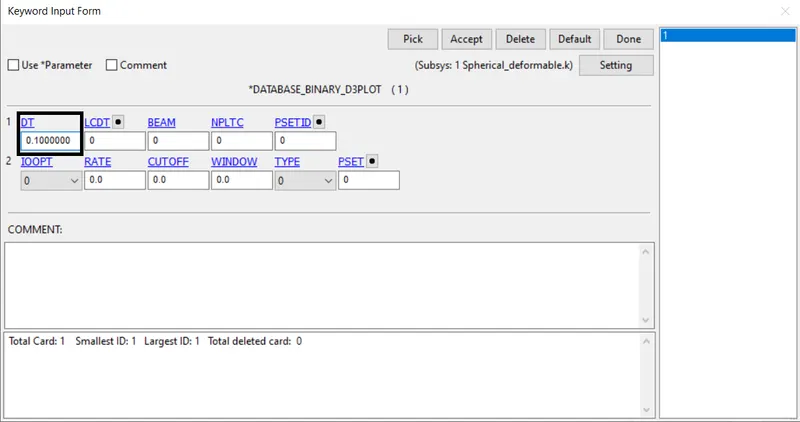
- The time interval between outputs is assigned as 0.10ms for the respected joints
Spherical Joint
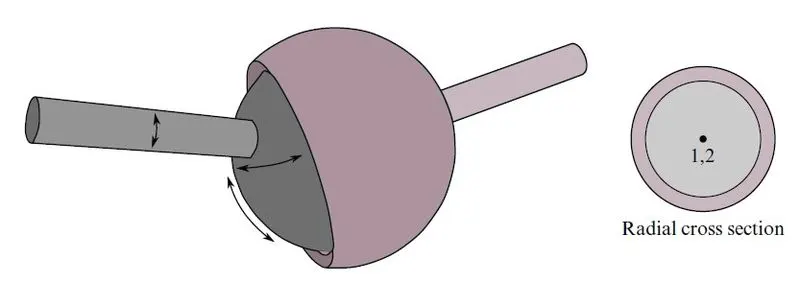
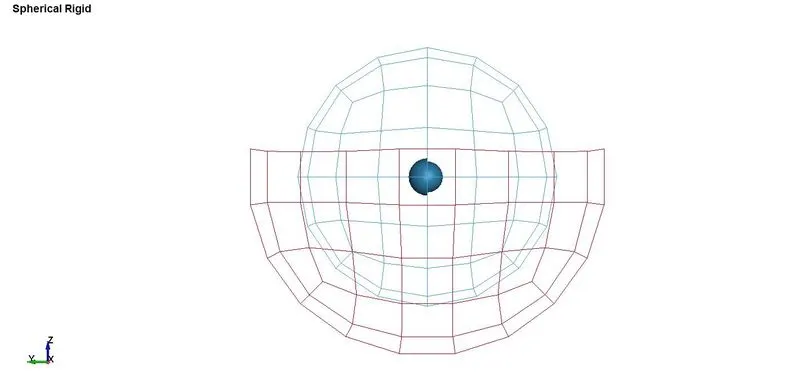
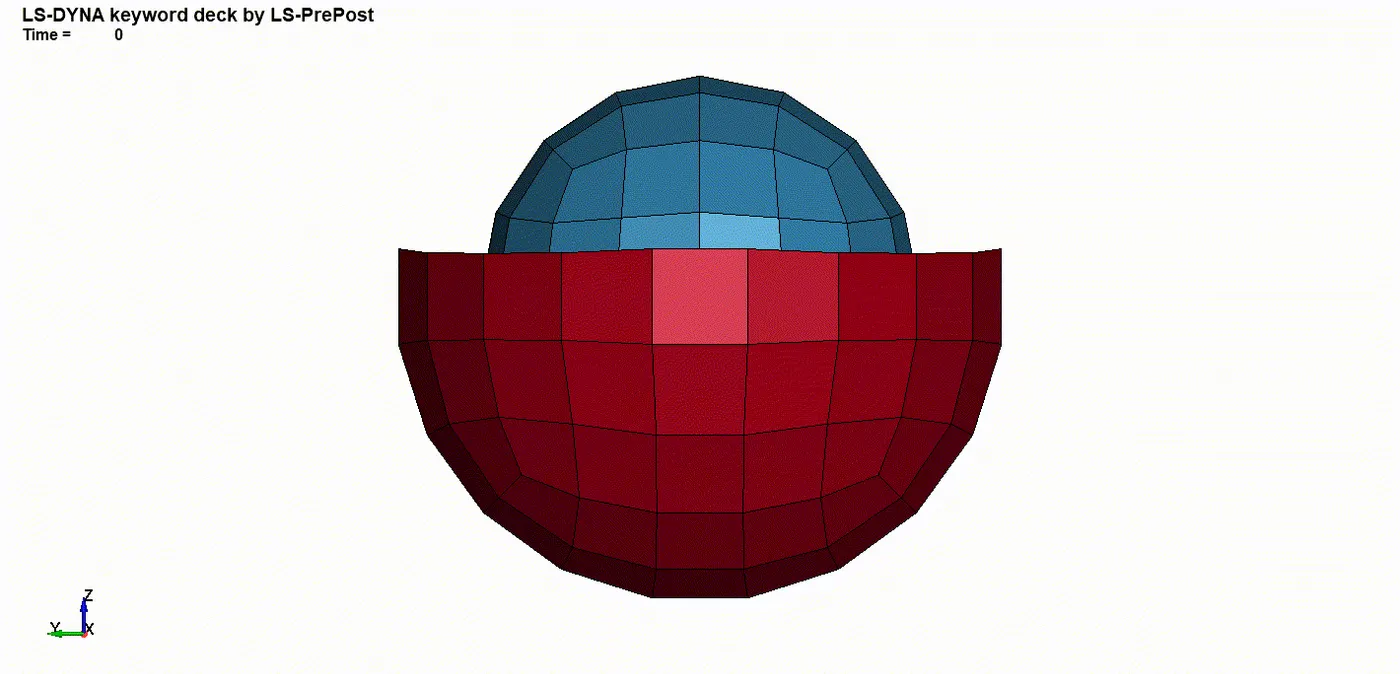
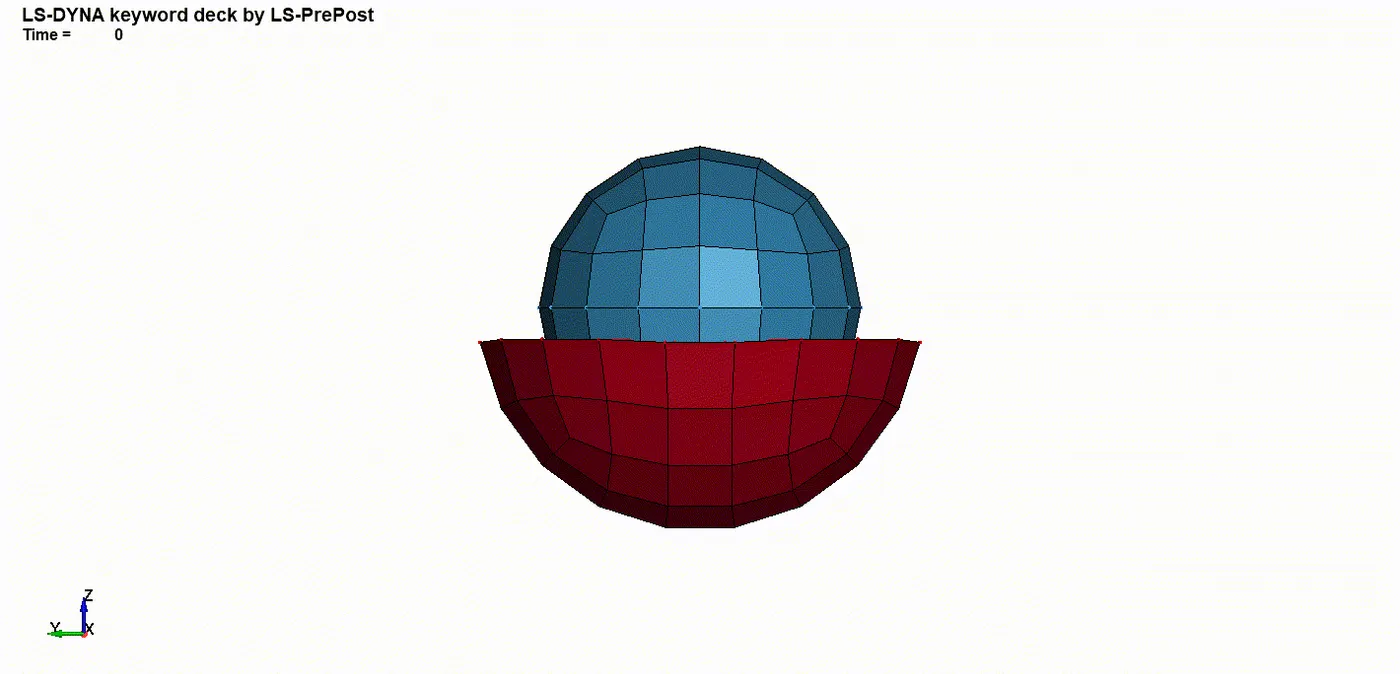
The spherical joint is used for allowing free rotation in two planes at the same time while preventing translation in any direction, including rotating in those planes. The relative motion of the rigid bodies is constrained so that nodes that are initially coincident remain coincident. In the below figure, the socket’s node is not interior to the socket. LS-DYNA does not require that a rigid body’s nodes be interior to the body
Spherical Rigid
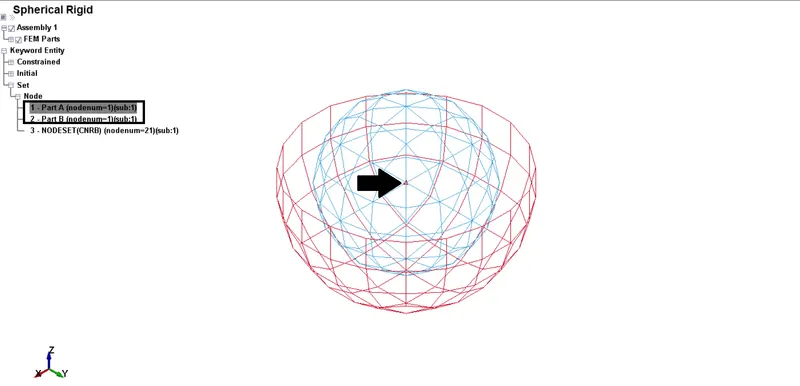
- Using Element and Mesh`rarr`Shape Mesher`rarr` Entity`rarr`Sphere Shell, create two parts as shown in the figure below
- The outer sphere shell elements are deleted using option Element editing
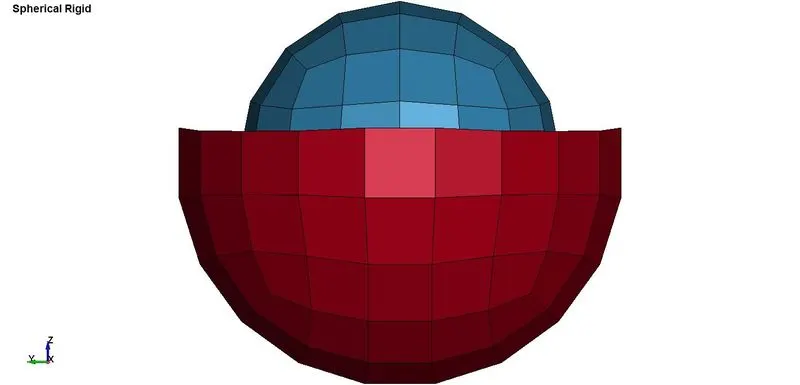
- Create a two node-set containing the nodes which are needed to be assigned to their respective parts
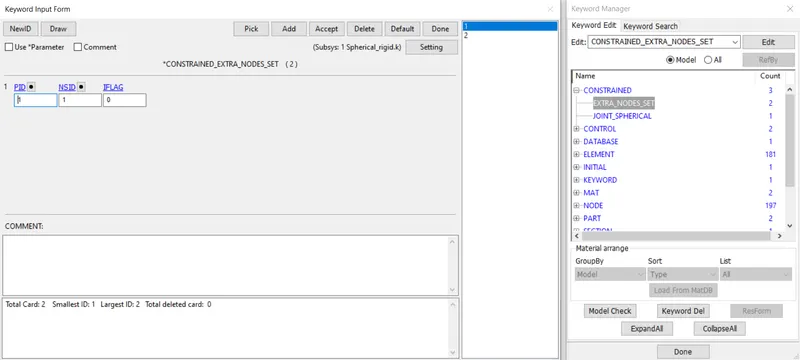
- As a node 250, 251 is constrained to parts 1 and 2 using *CONSTRAINED_EXTRA_NODES card as shown below
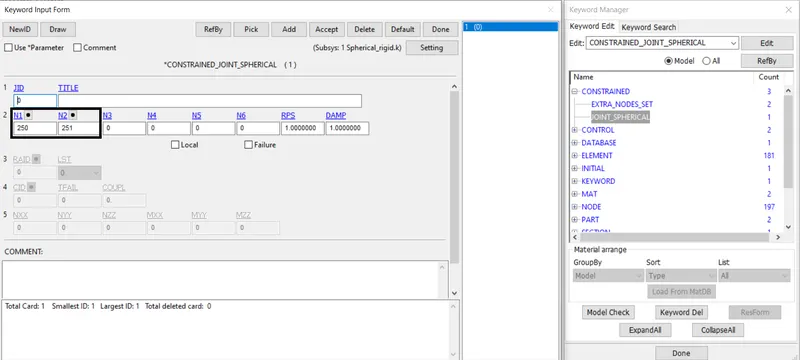
- The spherical joint is created using *CONSTRAINED_JOINT_SPHERICAL card with Node 1, in rigid body A is 250 and Node 2, in rigid body B is 251
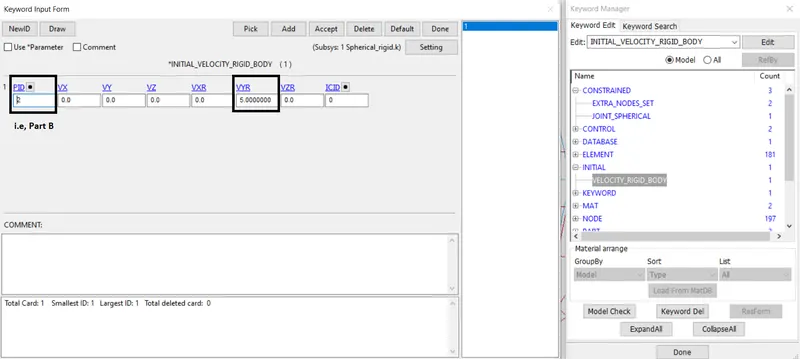
- Initial velocity by the rigid body is provided upon Y-Rotation, VYR=5 mm/ms
- The SPC is created before using constraints on MAT_Rigid
Results
Spherical Deformable
- From Create entity`rarr`Constrained`rarr`Nodal Rigid Body (CNRB). Using the nodes create a CNRB by linking between two parts respectively for creating a spherical joint
- The spherical joint is created using *CONSTRAINED_JOINT_SPHERICAL card with Node 1, in rigid body A is 250 and Node 2, in rigid body B is 251
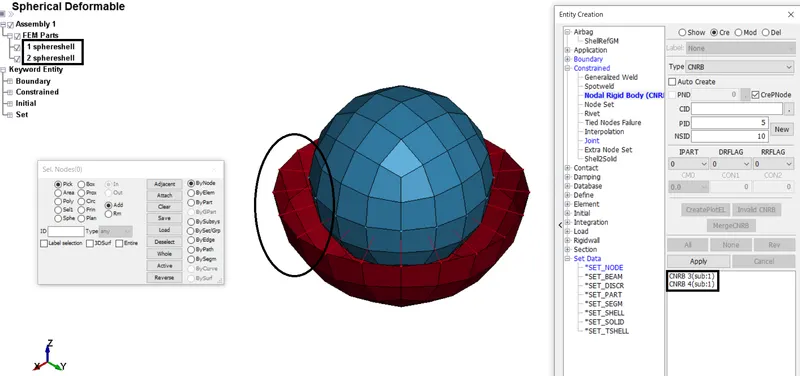
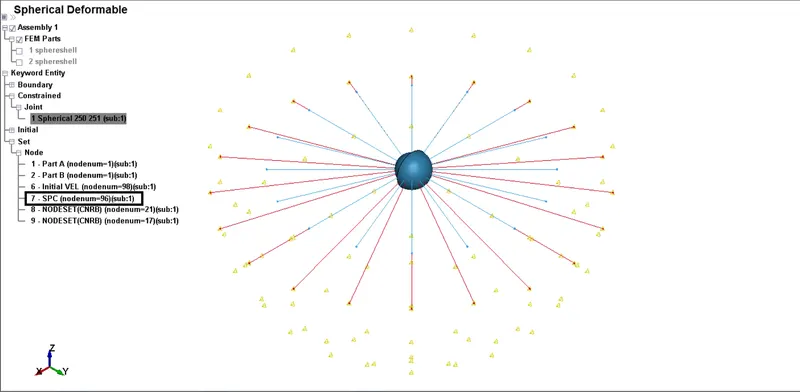
- SPC is created for part A need to be constrained in all translation and rotation
- Initial velocity is used here by the deformable body is provided upon Y-Rotation, VYR=5 mm/ms
Results
Revolute Joint
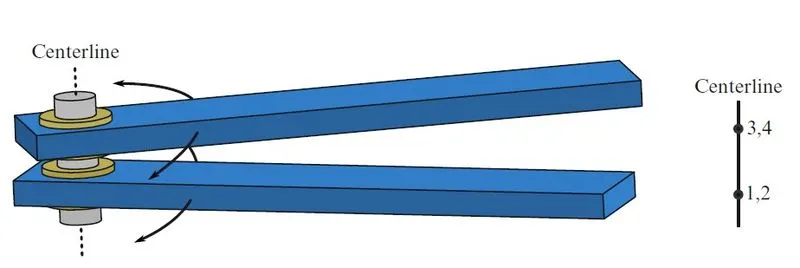
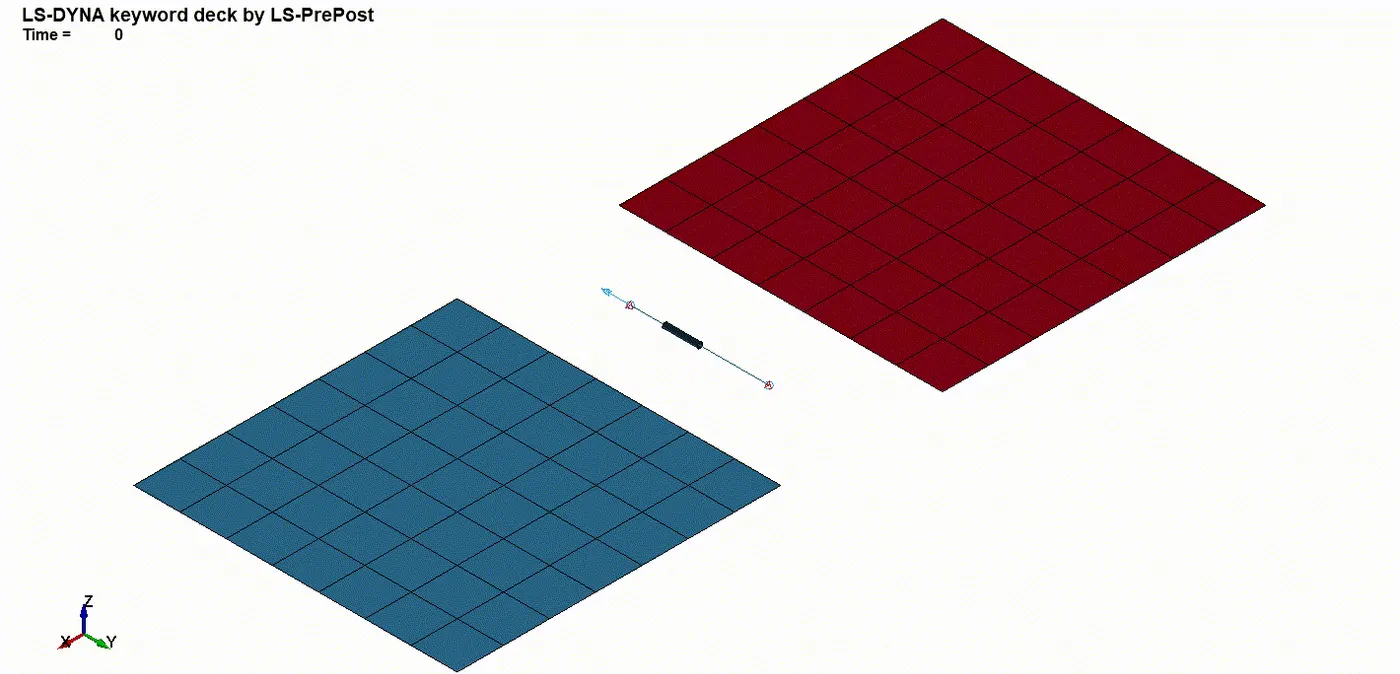
A revolute joint is one degree of freedom kinematic pair used frequently in mechanisms and machines. The joint constrains the motion of two bodies to the pure rotation along a common axis. As shown in the below figure, Nodes 1 and 2 are coincident; nodes 3 and 4 are coincident. Nodes 1 and 3 belong to rigid body A; nodes 2 and 4 belong to rigid body B. The relative motion of the two rigid bodies is restricted to rotations about the axis formed by the two pairs of coincident nodes. This axis is labeled the “centerline”
Revolute rigid
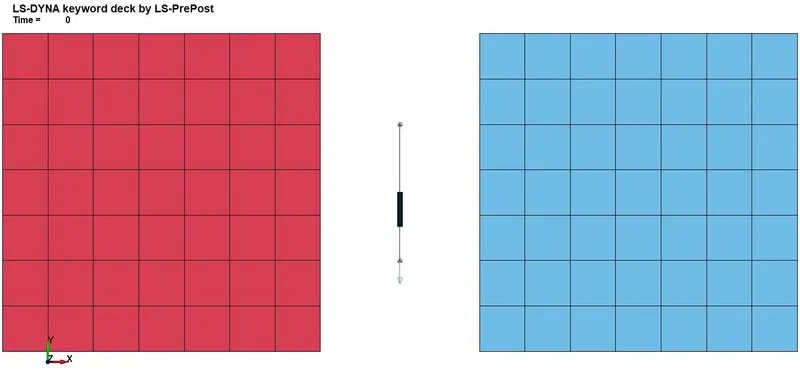
- Under Element and Mesh`rarr`Shape Mesher`rarr`Entity`rarr`4N Shell, create and translate two parts as shown below
- Two pairs of nodes are created under Element Tools`rarr`Node Editing`rarr`Create, i.e node 129-130 and 131-132
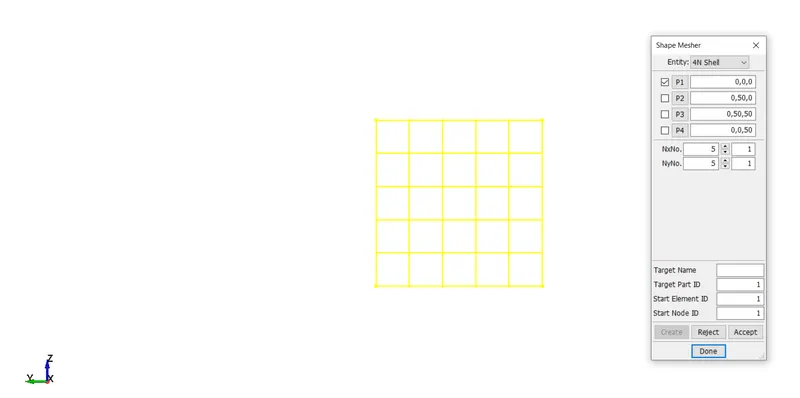
- Two pairs of nodes are created under Element Tools`rarr`Node Editing`rarr`Create, i.e node 129-130 and 131-132
- Create a two node-set containing the nodes which are needed to be assigned to their respective parts
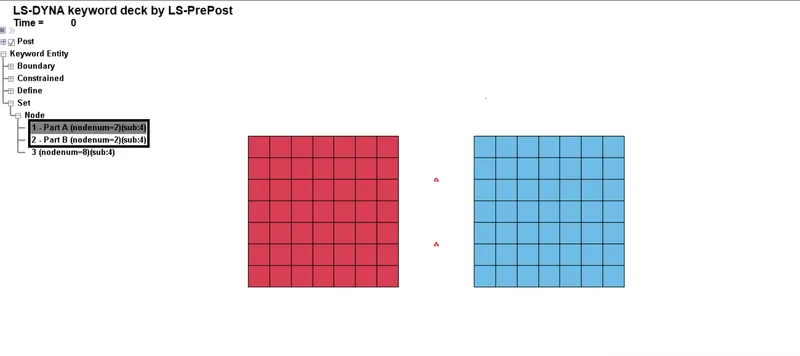
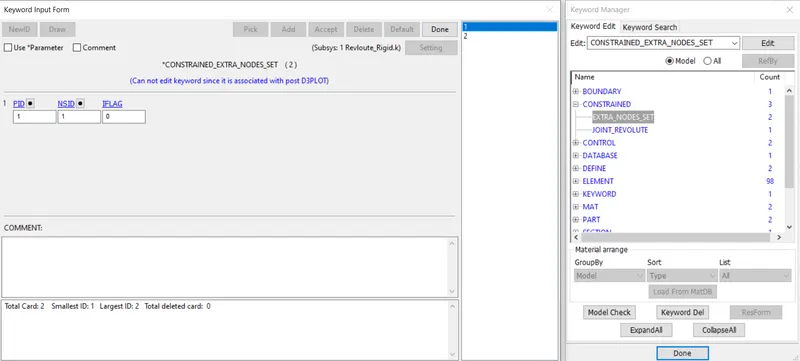
- The nodes 129 and 130 are constrained to part 1 and nodes 131 and 132 are constrained to part 2 using *CONSTRAINED_EXTRA_NODES as shown below
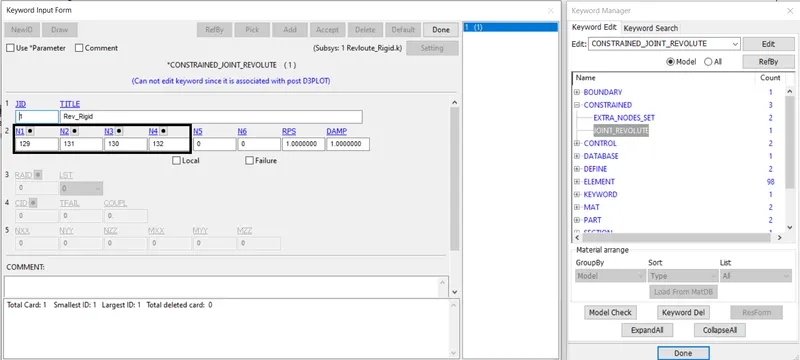
- The revolute joint is created using *CONSTRAINED_JOINT_REVOLUTE card with
Node 1, in rigid body A is 129
Node 2, in rigid body B is 131
Node 3, in rigid body A is 130
Node 4, in rigid body B is 132
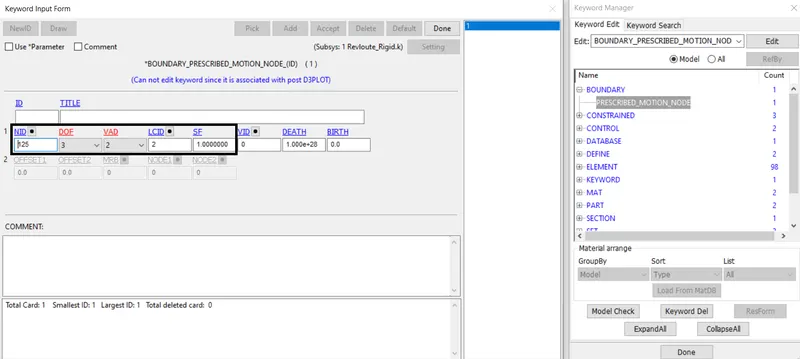
- Prescribed motion node is used at the rigid body B by defining LCID, upon Y-Direction as displacement
- The SPC is created at rigid body A by constraining at MAT_Rigid
Results
Revolute Deformable
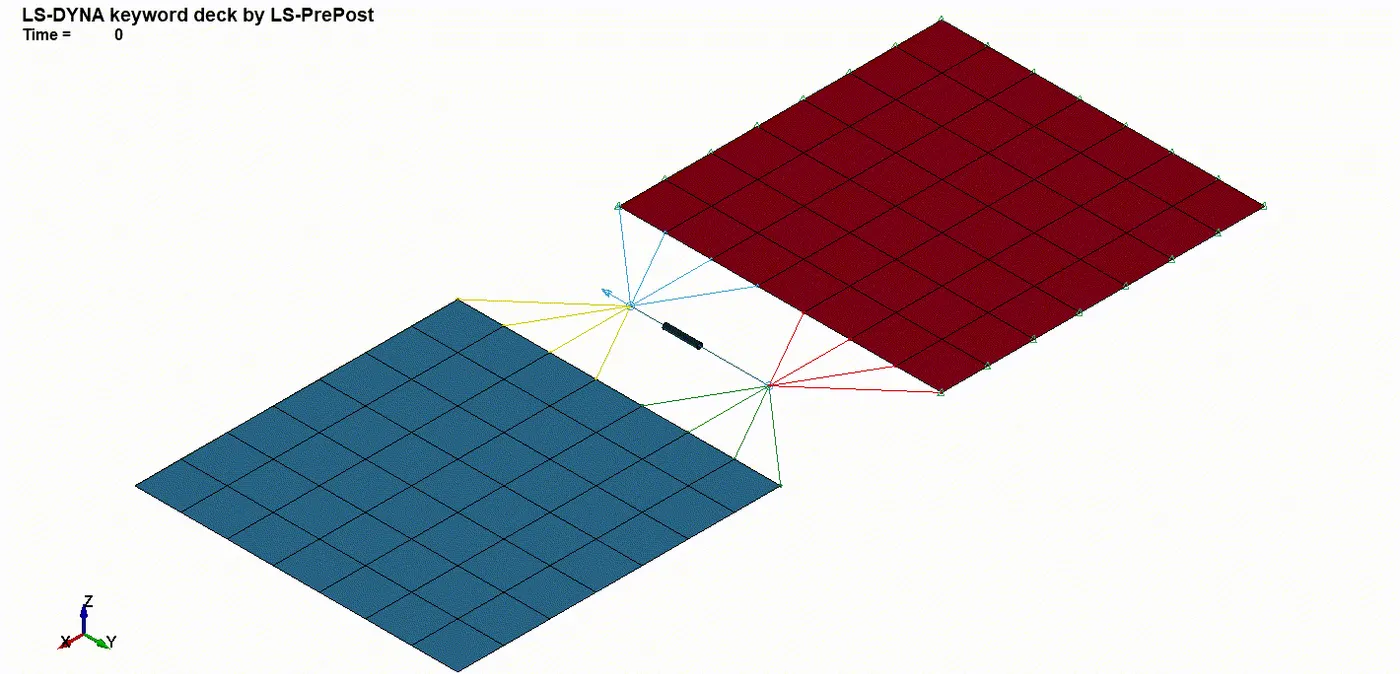
- From Create entity`rarr`Constrained`rarr`Nodal Rigid Body (CNRB). Using the nodes create a CNRB by linking between two parts respectively for creating a revolute joint
- The revolute joint is created using *CONSTRAINED_JOINT_REVOLUTE card with
Node 1, in rigid body A is 129
Node 2, in rigid body B is 131
Node 3, in rigid body A is 130
Node 4, in rigid body B is 132
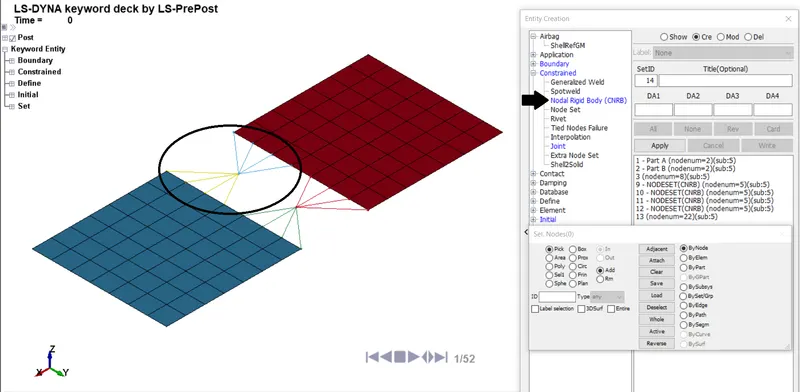
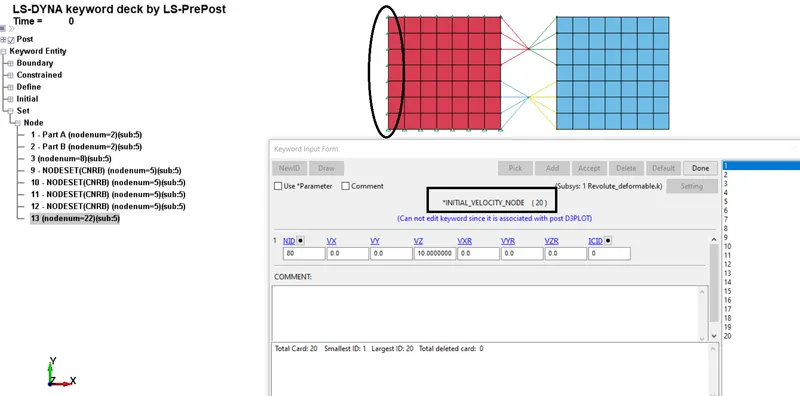
- SPC is created for part A need to be constrained in all translation and rotation
- Initial velocity is used here by the deformable body is provided upon Z-Translation, VZ=10 mm/ms
Results
Cylindrical Joint
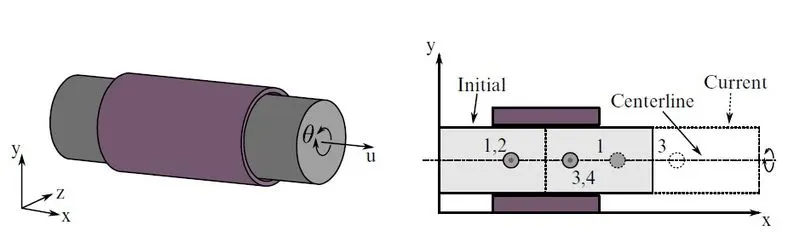
A cylindrical joint is two degrees of freedom kinematic pair used in mechanisms. It provides a single-axis sliding function as well as a single axis rotation, providing a way for two rigid bodies to translate and rotate freely. This joint is derived from the rotational joint by relaxing the constraints along the centerline. This joint admits relative rotation and translation along the centerline as shown in the below figure.
Cylindrical Rigid
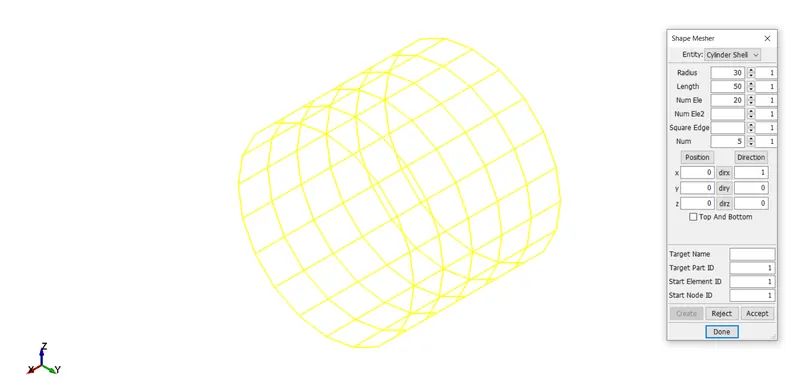
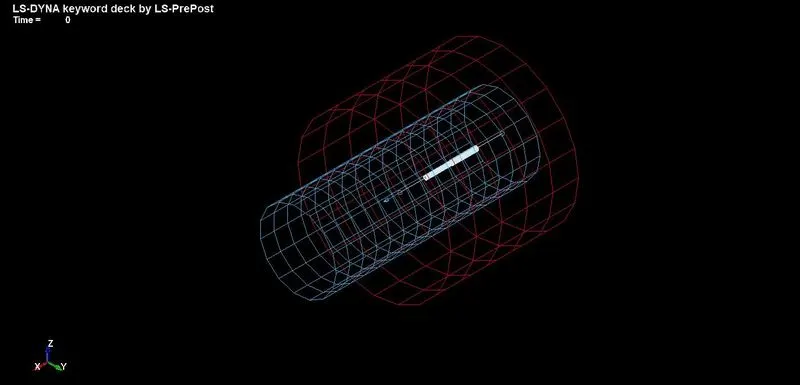
- Under Element and Mesh`rarr`Shape Mesher`rarr`Entity`rarr`Cylinder Shell, create two parts as shown below
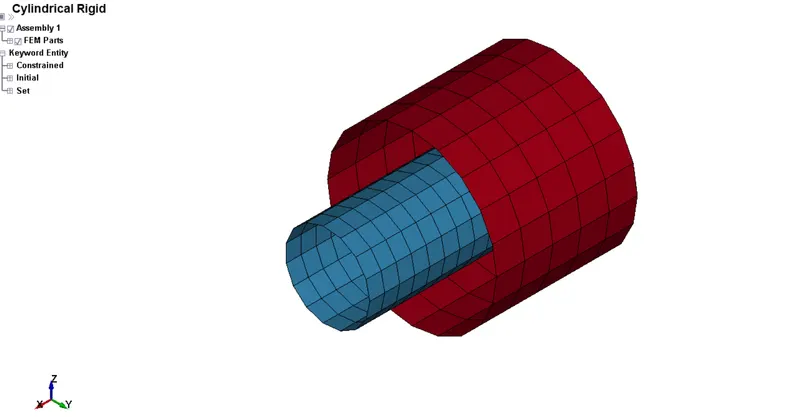
- Two pairs of nodes are created under Element Tools`rarr`Node Editing`rarr`Create, i.e node 361-362 and 363-364
- Create a two node-set containing the nodes which are needed to be assigned to their respective parts
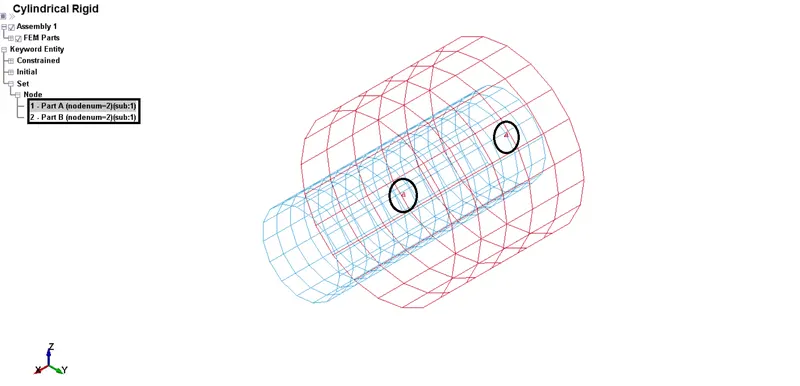
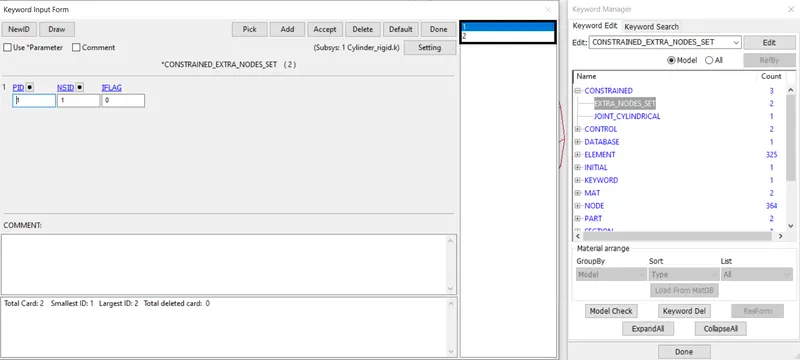
- The nodes 361 and 362 are constrained to part 1 and nodes 363 and 364 are constrained to part 2 using *CONSTRAINED_EXTRA_NODES as shown below
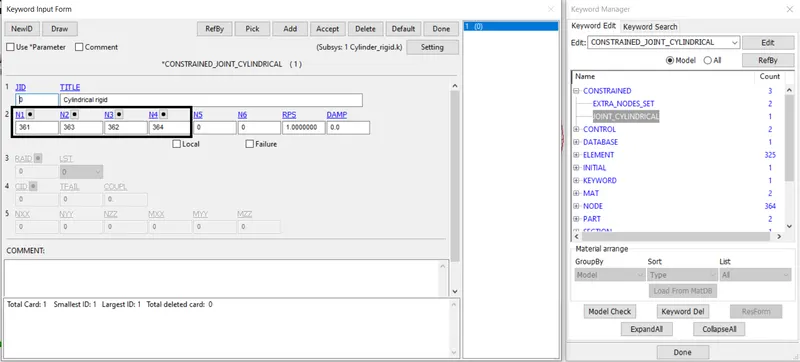
- The revolute joint is created using *CONSTRAINED_JOINT_CYLINDRICAL card with
Node 1, in rigid body A is 361
Node 2, in rigid body B is 363
Node 3, in rigid body A is 362
Node 4, in rigid body B is 364
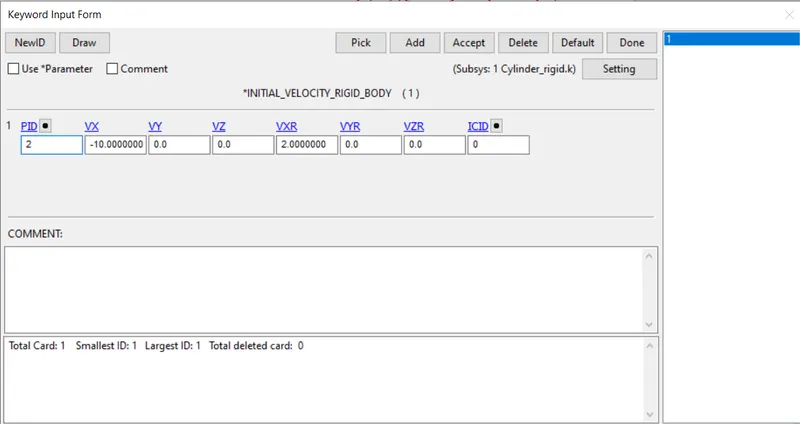
- Initial velocity by the rigid body is provided upon X-Translation, VX=-10 mm/ms
- The SPC is created at rigid body A by constraining at MAT_Rigid
Results
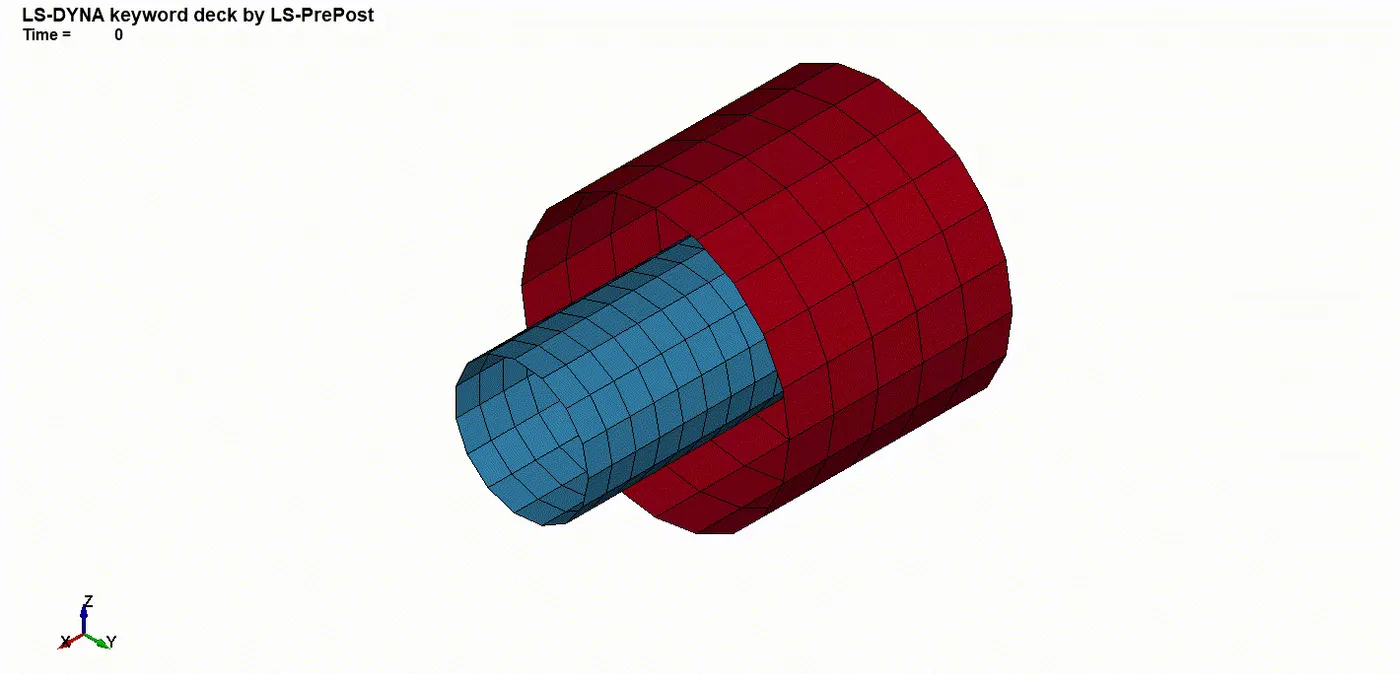
Cylindrical Deformable
- From Create entity`rarr`Constrained`rarr`Nodal Rigid Body (CNRB). Using the nodes create a CNRB by linking between two parts respectively for creating a cylindrical joint
- The revolute joint is created using *CONSTRAINED_JOINT_CYLINDRICAL card with
Node 1, in rigid body A is 361
Node 2, in rigid body B is 363
Node 3, in rigid body A is 362
Node 4, in rigid body B is 364
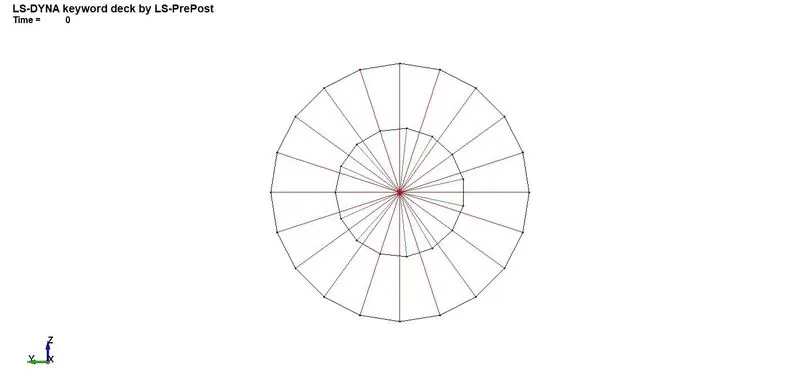
- SPC is created for part by constraining in all translation and rotation
- Initial velocity is used here by the deformable body is provided upon X-Translation, VX -15 mm/ms
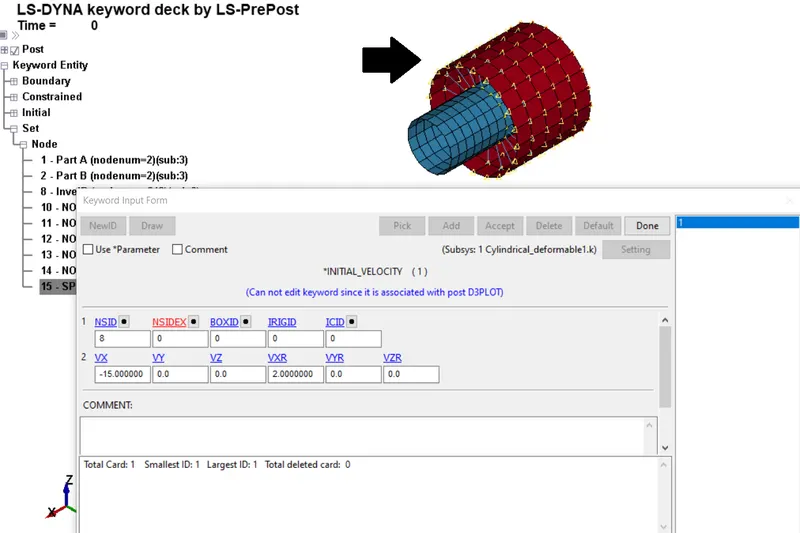
Results
Translational Joint
A Translational joint provides a linear sliding movement between two bodies. This is a cylindrical joint with the third pair of off-centerline nodes which restrict rotation. Aside from translation along the centerline, the two rigid bodies are stuck together. This joint has one translational degree of freedom and zero rotational degree of freedom 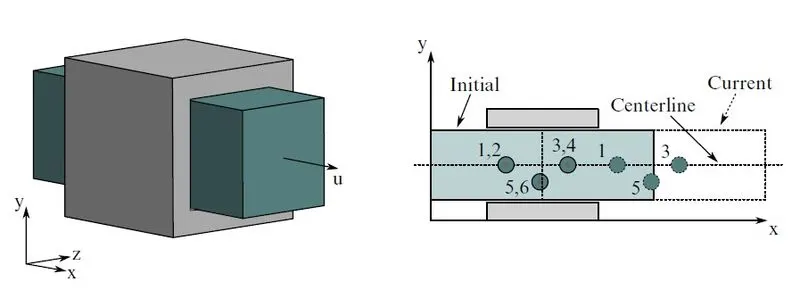
Translational Rigid
-
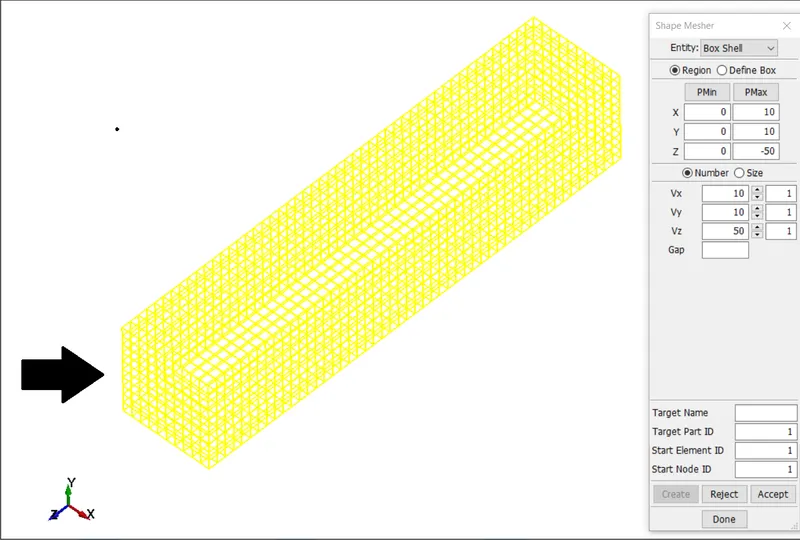
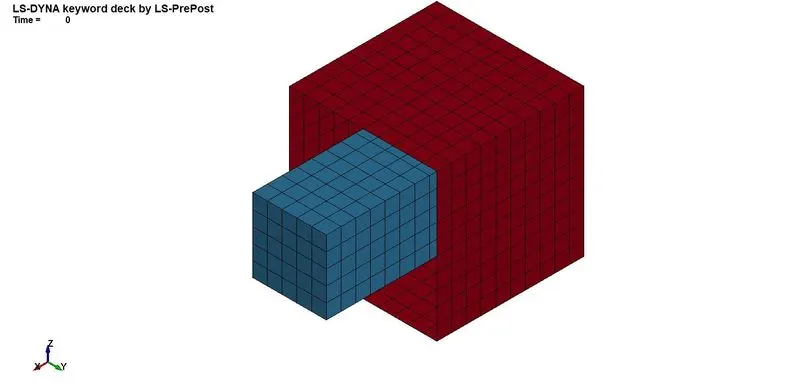
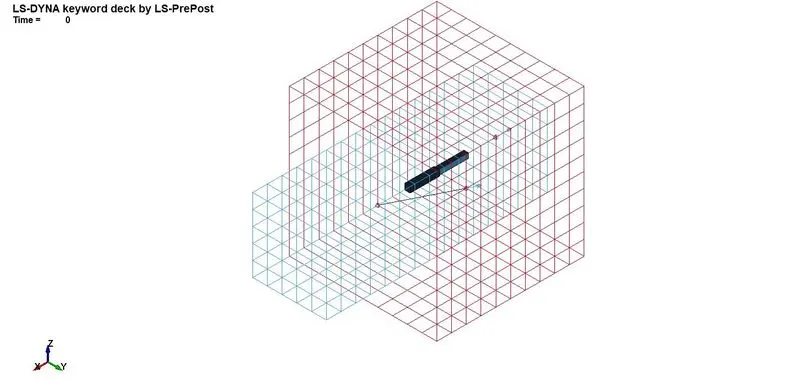
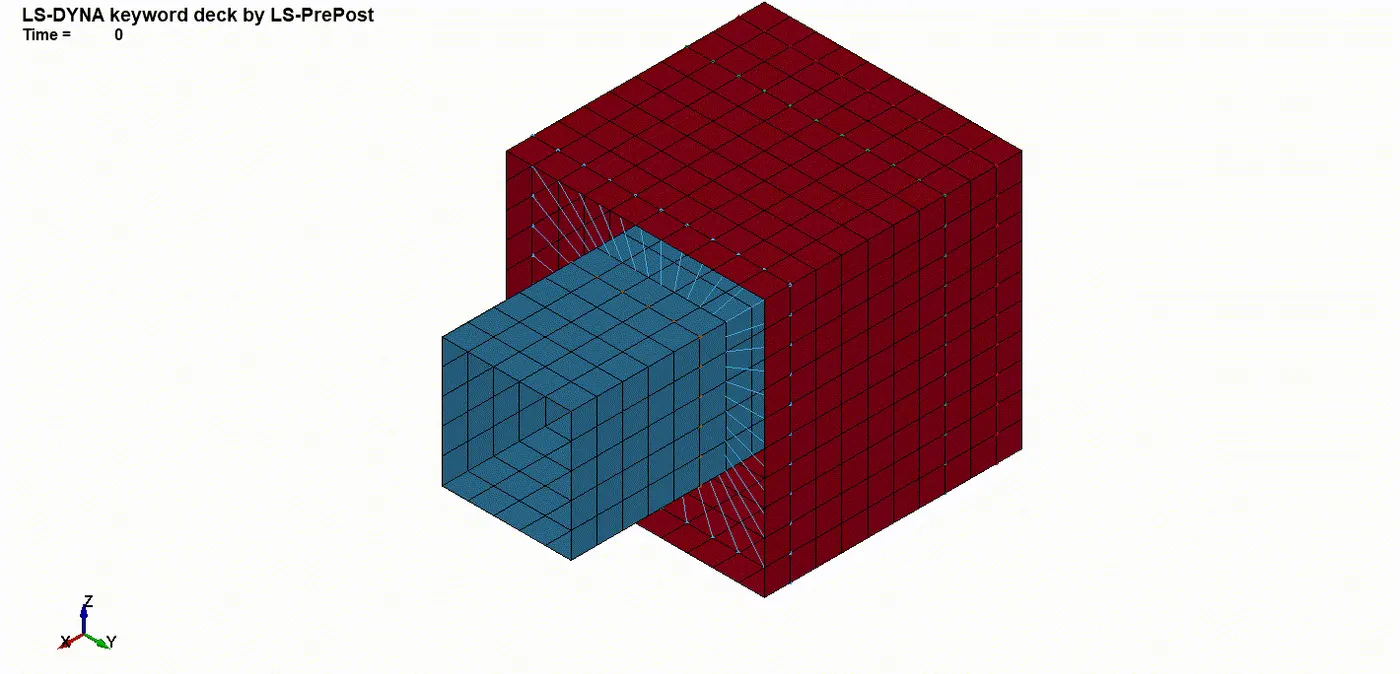
Under Element and Mesh`rarr`Shape Mesher`rarr`Entity`rarr`Box Shell, create two parts as shown in the image given below
- Three pair of nodes are created under Element Tools`rarr`Node Editing`rarr`Create, i.e node 1000-1001, 1003-1004, 1005-1006
- Create a three node-set containing the nodes which are needed to be assigned to their respective parts
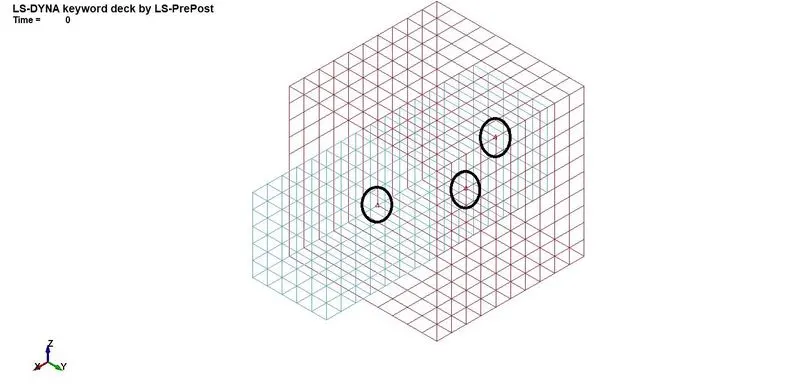
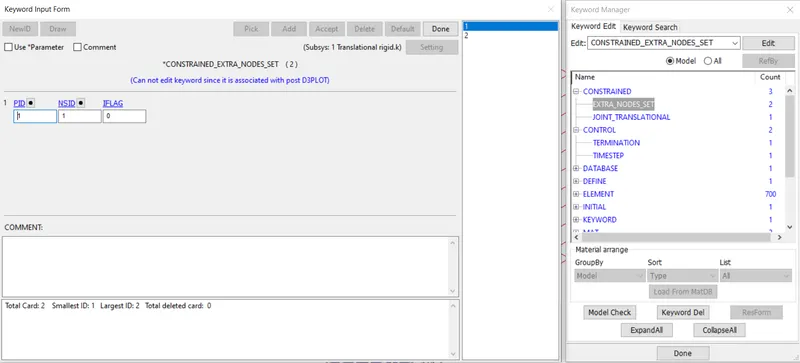
- The nodes 1000 and 1001 are constrained to part 1, nodes 1002 and 1003 are constrained to part 2, nodes 1004 and 1005 are constrained to part 3 using *CONSTRAINED_EXTRA_NODES as shown below
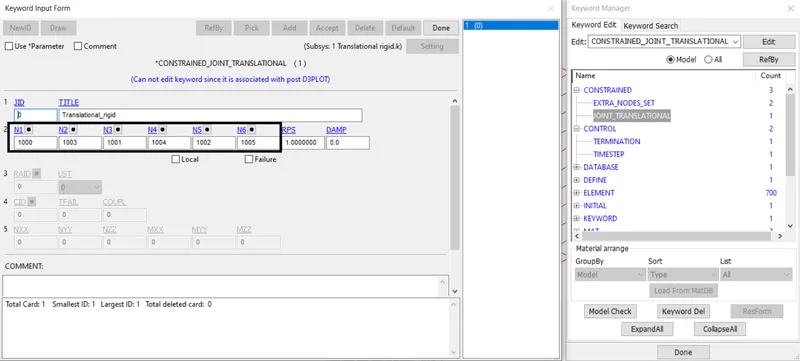
- The revolute joint is created using *CONSTRAINED_JOINT_TRANSLATIONAL card with
Node 1, in rigid body A is 1000
Node 2, in rigid body B is 1001
Node 3, in rigid body A is 1002
Node 4, in rigid body B is 1003
Node 5, in rigid body A is 1004
Node 6, in rigid body B is 1005
- Initial velocity by the rigid body is provided upon X-Translation, VX=-10 mm/ms
- The SPC is created at rigid body A by constraining at MAT_Rigid
Results
Translational Deformable
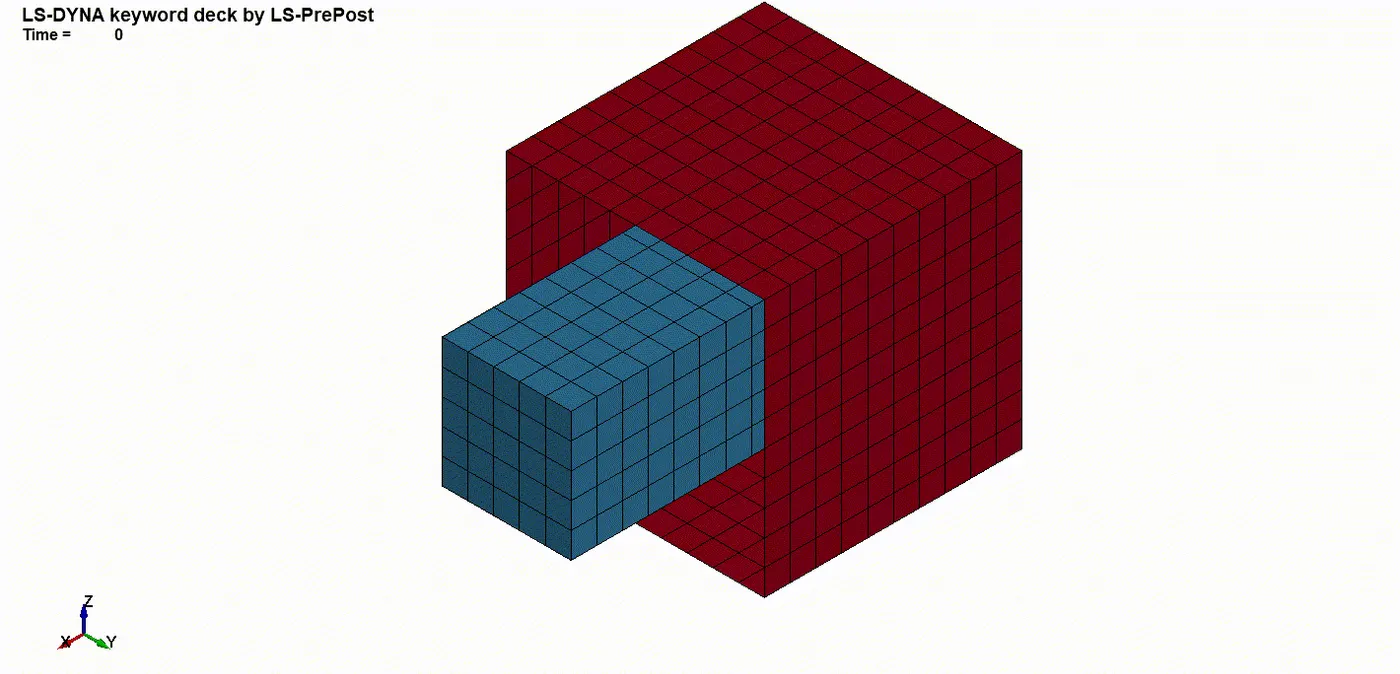
- From Create entity`rarr`Constrained`rarr`Nodal Rigid Body (CNRB). Using the nodes create a CNRB by linking between two parts respectively for creating a translational joint
- The revolute joint is created using *CONSTRAINED_JOINT_TRANSLATIONAL card with
Node 1, in rigid body A is 1000
Node 2, in rigid body B is 1001
Node 3, in rigid body A is 1002
Node 4, in rigid body B is 1003
Node 5, in rigid body A is 1004
Node 6, in rigid body B is 1005
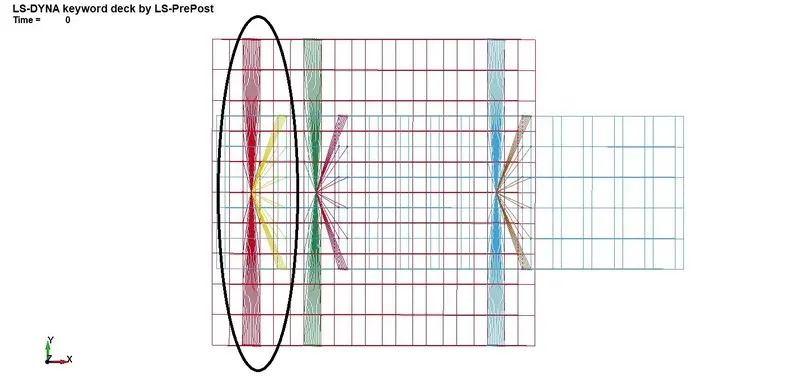
- SPC is created for a part by constraining in all translation and rotation
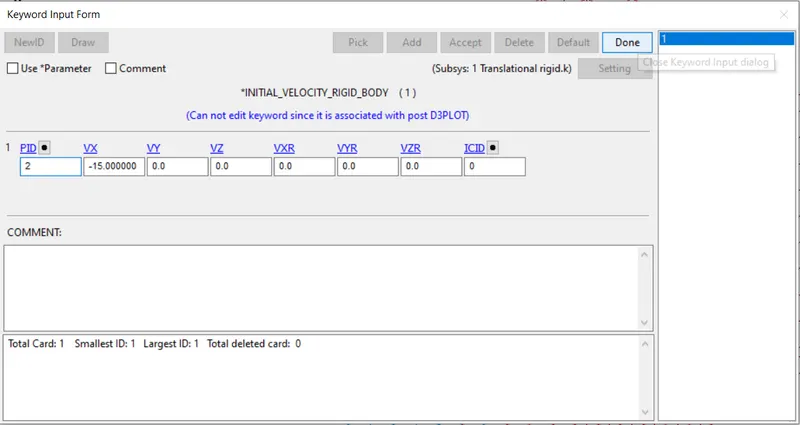
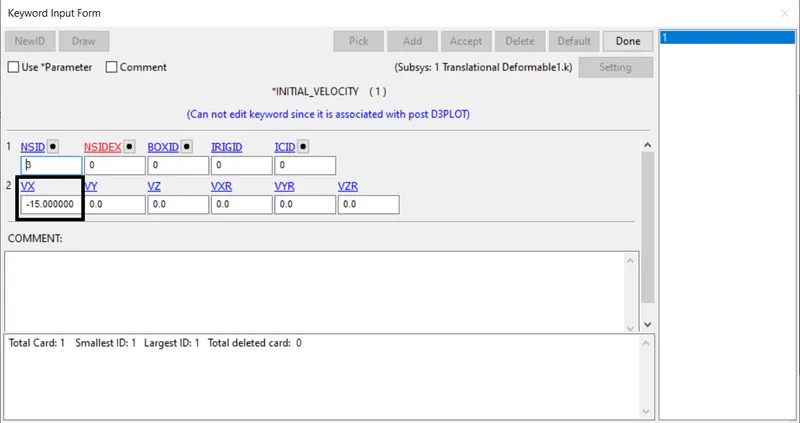
- Initial velocity is used here by the deformable body is provided upon X-Translation, VX -15 mm/ms
Results
Conclusion:
- The keyword files necessary to demonstrate spherical, revolute, cylindrical, and translational joints between two rigid bodies using the *CONSTRAINED_EXTRA_NODES card
- The keyword files necessary to demonstrate spherical, revolute, cylindrical, and translational joints between two deformable bodies using the *CONSTRAINED_NODAL_RIGID_BODY card
- Finally, we have simulated all joints for two rigid bodies and two deformable bodies using the LS-Dyna manual volume I r12