Week-11 Challenge: Braking
Aim:
* To calculate the energy required for braking, for a given driven cycle.
* To elaborate Why electric motor can’t develop braking torque at high speed similar to starting, and also How electric and mechanical brakes are coordinated
* Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots
i) Calculating the energy required for braking, for a given driven cycle:
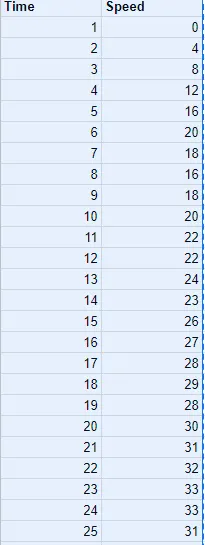
fig-1: The drive cycle
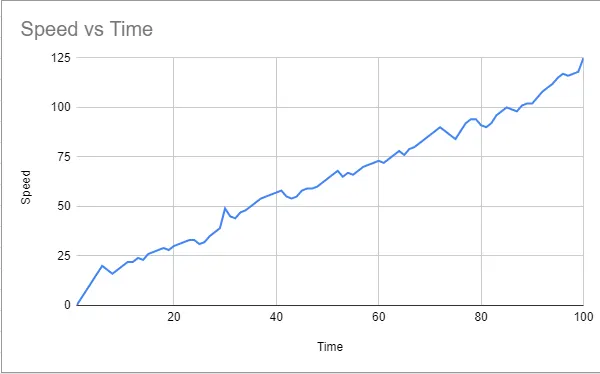
fig-2: Graph obtained by driving cycle
Formula:
Braking Energy = (1/2)*Mass*(Final Velocity - Initial velocity)^2
Calculations:
Parameters:
Mass = 500 kg
Vf = final velocity = minimum velocity
Vi = initial velocity = maximum velocity
Velocity is given in m/s
Braking Energy:
* (1/2)*500*(16-20)^2 = 4000J = 4KJ
* (1/2)*500*(23-24)^2 = 250J = 0.25KJ
* (1/2)*500*(28-30)^2 = 1000J = 1KJ
* (1/2)*500*(44-47)^2 = 2250J = 2.25KJ
* (1/2)*500*(55-58)^2 = 2250J = 2.25KJ
* (1/2)*500*(65-68)^2 = 2250J = 2.25KJ
* (1/2)*500*(66-67)^2 = 250J = 0.25KJ
* (1/2)*500*(78-76)^2 = 1000J = 1KJ
* (1/2)*500*(88-90)^2 = 1000J = 1KJ
* (1/2)*500*(98-100)^2 = 1000J = 1KJ
* ( 1/2)*500*(116-117)^2 = 250J = 0.25KJ
Total Braking energy for 0-100 seconds = 15.5 KJ
2) Elaborating Why electric motor can’t develop braking torque at high speed similar to starting, and also How electric and mechanical brakes are coordinated:
* Electric motor cannot develop braking torque at high speed.
Fig-3 (Torque vs speed characteristics)
* From the given image, it is clearly shown that the motor reaches its critical speed, it has constant torque and once it reaches the critical speed , the curve is h, arriving downwards which is constant power region.
* The graph denotes the accelerating operation of the motor, and for the decelerating or braking operation, the graph is mirrored down, having the high speed and low torque.
* Suppose, if an EV can achieve 0-100 kmph in 10 sec, Acceleration takes place with low speed and high torque, and further, it shifts to constant power region and thus it is easy to reach 0-100 kmph.
* In case of braking operation, we cannot say that the motor producing 7Nm torque for acceleration, as well as reducing 7 Nm torque for breaking. Because we are operating in the field weakening region, operating above the base speed. Thus, the peak acceleration torque is greater than the peak deceleration torque. Thus, the acceleration has high torque and deceleration has lower torque.
* There are two types of Brake control strategies, namely SERIES and PARALLEL.
* In series, brakes are applied one after other. Either one brake strategy at a time either regenerative braking or mechanical braking at a time.
* In parallel braking, Both the brakes are applied simultaneously ar a time.
Fig-4: From these images, Nissan has developed a brake called ELECTRIC DRIVEN INTELLIGENT BRAKE, in NISSAN LEAF EV.
Technology Functionality:
* After stepping on to the brake, the system produces the natural and adequate driving force which corresponds to the operation.
* The amount of energy regenerated also can be increased as much as possible.
* EDIB controls the regenerative brakeand friction brake to support the both of these requirements.
* It also controls the reactive force from the pedal in order to unify when stepping down on the pedal with the sense of deceleration.
3) Making a MATLAB program which plots contour of given motor speed, torque and efficiency values:
clear all
close all
clc

%program for plotting efficiency contours for electric motors
%setting up arrays

x = linspace(1,1000);
y = linspace(1,250);

%allocating motor loss constants
kc = 0.2;
ki = 0.008;
kw = 0.00001;
ConL = 20;

% Making mesh
[X,Y] = meshgrid(x,y);

%Torque x Speed = power
Outputpower = (X.*Y);

% Copper losses
B = (Y.^2)*kc;
% Iron losses
C = X*ki;
%Windage losses
D = (X.^3)*kw;

Inputpower = Outputpower + B + C + D + ConL;
Z = Outputpower./Inputpower;

% plotting and setting the efficiencies
V = [0.70,0.80,0.90,0.91,0.92,0.925,0.93];
box off
grid on
contour(X,Y,Z,V);
xlabel('speed/rad.s^-1');
ylabel('Torque/N.m');
hold on
% the array output power has been calculated
V = [8000,10000];
contour(X,Y,Outputpower,V);
* The first two inputs were given, which are speed and torque by usibg linspace command.
* The motor constant values are assigned namely copper loss,iron loss,windage losses and constant motor.
* The meshgrid is used to evaluate the functions of two variables and 3D mesh plots.
* Output is obtained by multiplying Speed and torque.
* Then all the losses as well as input powers are calculated.
* Then the contour graph is plotted between the Speed, Torque and Efficiency.
Output plot:
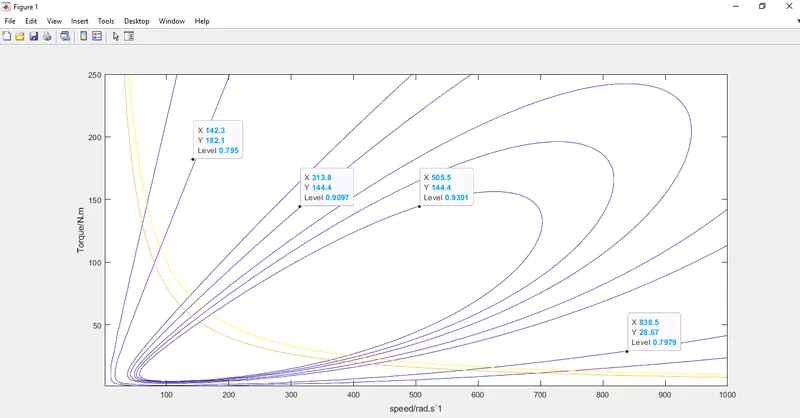
Result:
Calculating the energy required for braking for a given driven cycle, Elaborating Why electric motor can’t develop braking torque at high speed similar to starting, and also How electric and mechanical brakes are coordinated, Making a MATLAB program which plots contour of given motor speed, torque and efficiency values has been done and elaborated.