Week-11 Challenge: Braking
1. For a defined driving cycle, calculate the energy required for braking.
Ans: -
Braking:
- The function of the braking system is to retard the speed of the moving vehicle or bring it to rest in the shortest possible distance whenever required. The vehicle can be held on an inclined surface against the pull of gravity by the application of a brake.
- Brakes are mechanical devices for increasing the frictional resistance that retards the turning motion of the vehicle wheels. It absorbs either kinetic energy or potential energy or both while remaining in action and this absorbed energy appears in the form of heat.
- While moving down a steep gradient the vehicle is controlled by the application of brakes. In this case, brakes remain in action for a longer period making it imperative to dissipate the braking heat to the atmosphere as rapidly as possible.
- Automobiles are fitted with two brakes; the service or foot brake and the emergency or hand brake. The foot brake is used to control the speed of the vehicle and to stop it, when and where desired, by the application of force on the brake pedal.
- The hand brake, applied by a lever, is used to keep the vehicle from moving when parked. Hand brakes are called emergency brakes because they are applied when the service brake fails. Virtually all vehicles are now equipment with 4-wheel brakes.
- The front brakes must operate without interfering with the steering action. The brakes must be capable of decelerating a vehicle at a faster rate than the engine is able to accelerate it. Normally brakes have to absorb three times the amount of engine horsepower energy in its equivalent form.
Kinetic energy is the force that keeps the vehicle moving. This energy is provided by the engine in order to accelerate the vehicle from a standstill to desired speed. Kinetic energy is dissipated as heat by the brakes during application of breaks. The kinetic energy of a vehicle during braking is given by
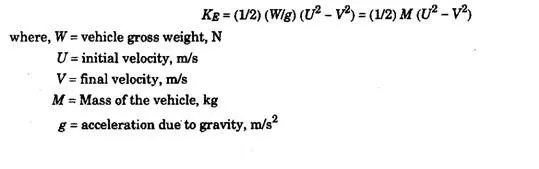
Thus, the kinetic energy doubles as the weight doubles, but it increases four times as speed doubles.
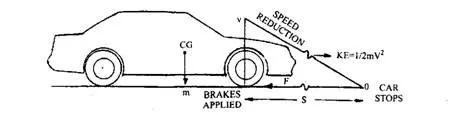
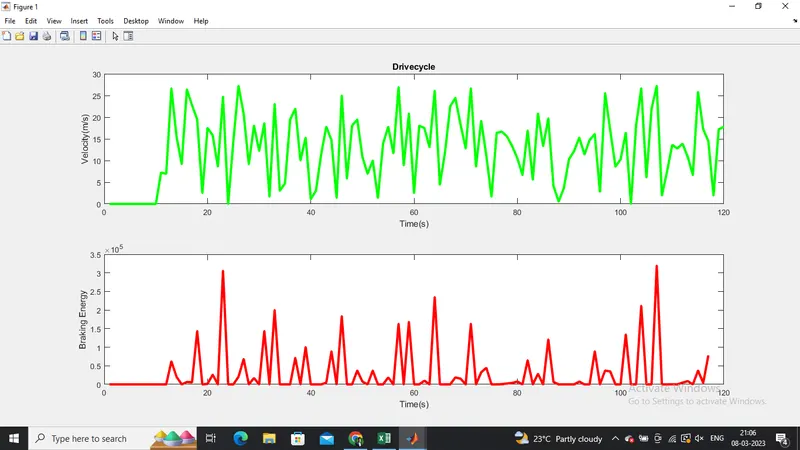
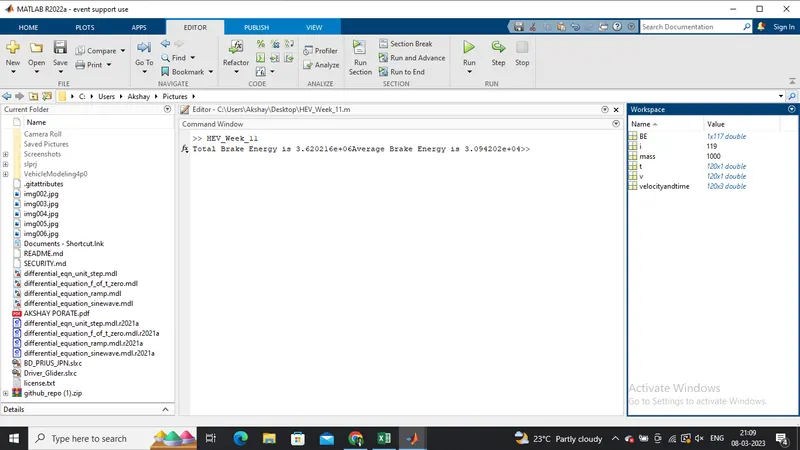
- Before calculating the Braking Energy of a particular vehicle ,we need to create an excel sheet for a drive cycle and excel file is attached below. Now we need to import this excel data to the MATLAB and then create a program to calculate and plot the results of the brake energy.
MATLAB program for the calculation of brake energy:
Electric Motor Braking :
Electric motor can’t develop braking torque at high speed similar to starting, because Braking torque is applied in the opposite direction of the rotation. We can use a mechanical brake to produce a braking torque. We can also do it electrically.
Regenerative Braking:
It is a form of braking in which the kinetic energy of the motor is returned to the power supply system.
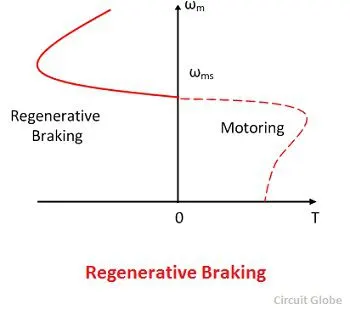
Fig - Speed torque charactristics of regenerative breaking
- Regenerative braking takes place whenever the speed of the motor exceeds the synchronous speed. This baking method is called regenerative baking because here the motor works as generator and supply itself is given power from the load, i.e. motors.
- The main criteria for regenerative braking is that the rotor has to rotate at a speed higher than synchronous speed, only then the motor will act as a generator and the direction of current flow through the circuit and direction of the torque reverses and braking takes place.
- Sometimes after accelerating you can't reach the maximum torque. The reason is that no matter how much the current loop wants to increase current (proportional to torque) by increasing the PWM duty cycle of the power stage, the Vmotor is too close to Vbemf and therefore current can't increase more.
- This situation does not occur at the beginning of an acceleration because most of the torque is used to increase the kinetical energy of the load (and motor). But when the speed is already high and no extra load is applied it is not possible to increase the torque.
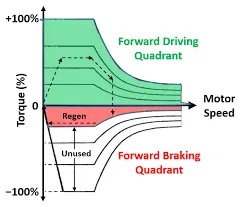
Fig - Accelaration torque vs Deccelaration Torque
- Peak Acceleration Torque and Peak Deceleration torque are not equal for Electric Vehicle Motor. So the Peak Torque during acceleration and the Peak torque during deceleration or braking are not equal. Acceleration is usually higher, at low speed we get higher Torque but high speed the value of the torque gets lower.
- So we cannot say that the motor which is producing 7Nm Torque for Acceleration can also produce -7Nm of Braking Torque. So beacuse we Operating the Motor in Field Weakening region or we are operating the Motor above base speed we must know that the torque is compromised or the torque value is lower.
- So Electric motor can’t develop braking torque at high speed similar to starting, because Braking Torque of an EV Motor is not as high as the Acceleration Torque. Therefore Regenerative braking is cannot happen so effectively that we can get all the power back to the battery.
- In a electric Motor the Total Brake distribution is in two aspects which are Electrical Brake which is called Regenerative Brake and Mechanical Brake or Classical Brake with hydraulic cylindrical system.
- Brake Force distribution must be uniform, If the Regenerative braking power requirement is more than the charging limit of the battery or more than regenerative capacity of the machine we must apply Mechanical brakes as well. In practical case the combination of these two is applied.
- So usually it is combined response of Mechanical brake and Regenerative brake. The reason for how these brake force are combined, that particular phenomena is called Brake Control Strategies. There are two Brake Control Strategies, which are
MATLAB Program to Plot Motor Speed-Torque Contour Efficiency :
clear all
close all
clc

% Plotting Efficiency Contour for Electric Motor
%Input of Speed & Torque
Speed=linspace(1,1000);
Torque=linspace(1,250);

%Losses
kc=0.2; % For Copper Loss
ki=0.008;% For Iron Loss
kw=0.00001;% For Windage Loss
C=20;% For Constant Motor Loss

%Meshing
[S,T]=meshgrid(Speed,Torque)

%Calculating Power = Speed * Torque
Outputpower=(S.*T);

%Calculating Losses
Cu=(T.^2)*kc;%Copper Losses
Fe=S*ki;%Iron Losses
W=(S.^3)*kw;%Windage Losses

Inputpower = Outputpower+Cu+Fe+W+C;
Efficiency = Outputpower./Inputpower;

%Now Set the Efficiency to plot Contour
V=[0.70,0.80,0.85,0.90,0.91,0.92,0.925,0.93];
box off
grid off
contour(S,T,Efficiency,V)
xlabel('Speed(rad/s)')
ylabel('Torque(Nm)')
title('Motor Speed-Torque Efficiency Contour Plot')
hold on

%Now Plot a contour of Power Output
%Additionally Plotting contour of 8kw and 10kw
V=[8000,10000];
contour(S,T,Outputpower,V)
Explanation for above Program :
Step-1 : Assign Input of Speed and Torque in an array using 'linspace' Command and allocate Constant Values for four losses(Copper Loss, Iron Loss, Windage Loss and Constant Motor Loss)
Step-2 : Mesh the Speed and Torque values using 'meshgrid' command.
Step-3 : Calculate the Output Power by multiplying Speed and Torque values.
Step-4 : Calculate Copper Loss, Iron Loss, Windage Loss using those formulas.
Step-5 : Calculating Inputpower by adding Output Power and Four Losses(Copper Loss, Iron Loss, Windage Loss and Constant Motor Loss).
Step-6 : The ratio of Output Power and Input Power we can get the Efficiency.
Step-7 : Now Set the Efficiencies for which a contour will be plotted. The range of contour efficiency is to plot from 70% to 93% efficiency. V is the Mapping of those efficiency points.
Step-8 : Plot the Contour Efficiency using 'contour' command and plot Speed,Torque,Efficiency and V.
Contour : contour(Z) creates a contour plot containing the isolines of matrix Z, where Z contains height values on the x-y plane. MATLAB automatically selects the contour lines to display. The column and row indices of Z are the x and y coordinates in the plane, respectively.
'contour(X,Y,Z)' specifies the x and y coordinates for the values in Z.
Step-9 : Now plot a contour of Power Output. Plotting contour of 8kw and 10kw of a Motor.
Step-10 : Run the Program and get the Motor Speed-Torque Efficiency Contour Plot.
Result: -
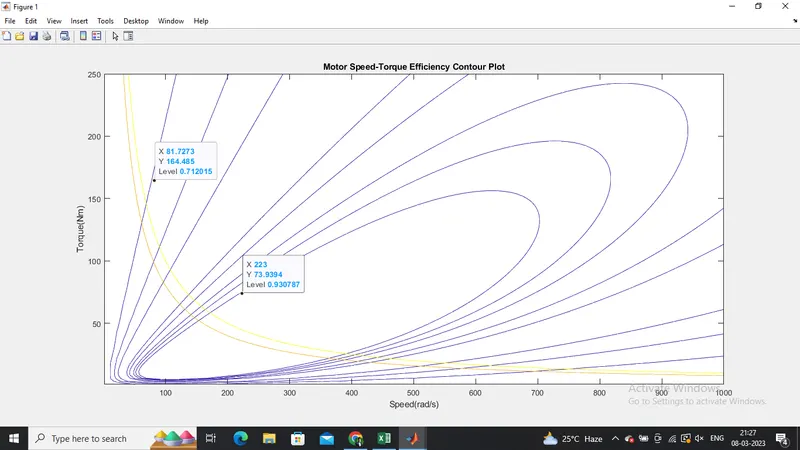
Conclusion
- The above Plot shows the Motor Speed-Torque Efficiency Contour Plot. A Point is denoted in innermost contour line is group of efficiencies which is highest value of the efficiency as 93%, because where the height is maximum and another point is denoted outermost contour line is contain group of efficiencies which is the lowest value of efficiency as 70%, because where the height reduces. Increasing efficiency order as going inward and Decreasing efficiency order as going outward. The yellow line shows the 8kw and 10kw Power.