Week-11 Challenge: Braking
1. For a defined driving cycle, calculate the energy required for braking.
To Find the Breaking power First we identify the Decelaration condition.
During Breking the same amount Power requird as accelaration.
We select the UDDS Driving cycle.
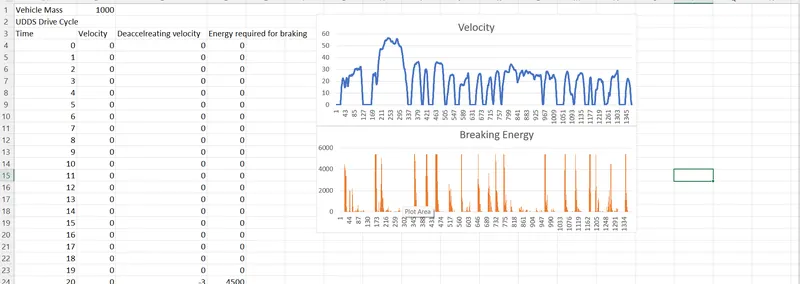
First We Download the Data of UDDS data Frm Google.
Step 1
Wee calculate the deacelarating velocity From Formula which is following.
V=(Runnig Velocity - upcoming velocity) Or (initial velocity-final Veocity).
Srep 2
Then We apply the formula for braeking in excel sheet which is 0.5*m*v^2
I explain The Few condition for understanding Purpose.
Condition 1
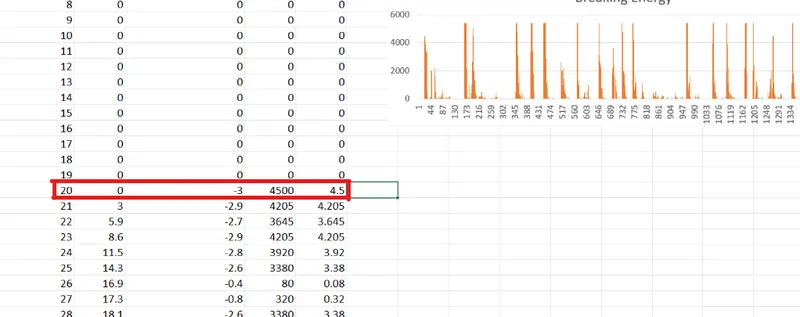
0.5*M*V^2
0.5*1000*(-3)^2=4500 W.
4500/1000=4.5 kW.
Condition 2
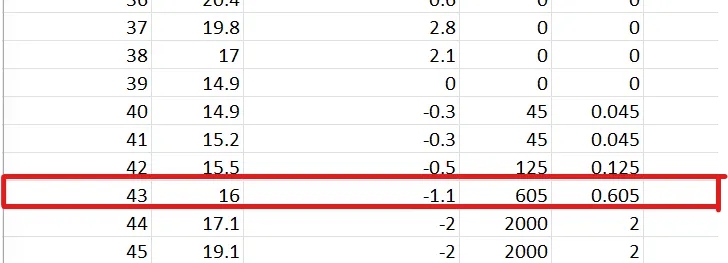
0.5*M*V^2
0.5*1000*(-1.1)^2=605 W.
605/1000=0.605 KW.
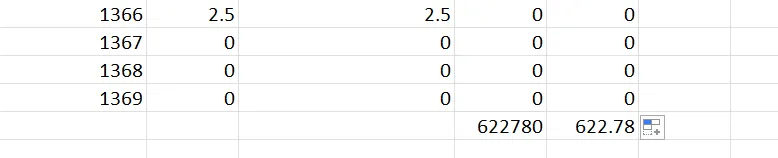
Then We calculate The Total braking Power which is following.
Total Braking Power(w)=622780w
Total Braking Power (Kw)=622780/1000=622.78 kW.
The Total Braking Power Requird For The UDDS driving Cycle is 622.78kW.
We Draw The Graph Of the Driving Cycle and Braking Power.
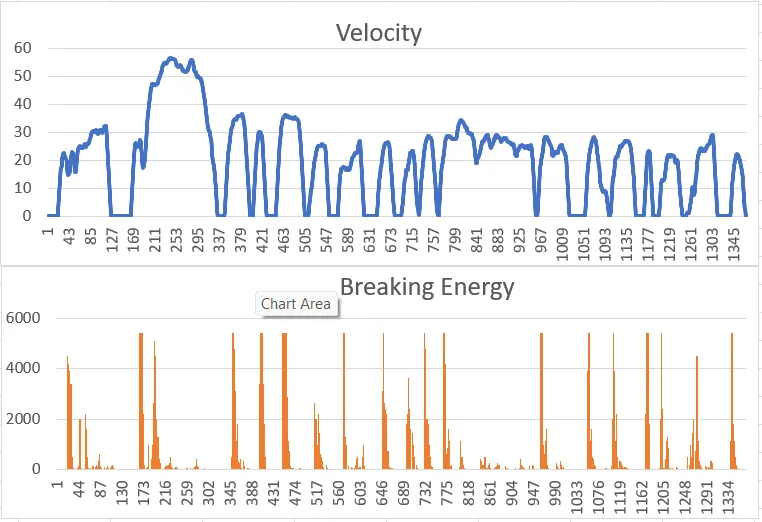
We observed The graph.
We impliment The IF Else Condition In excel sheet.
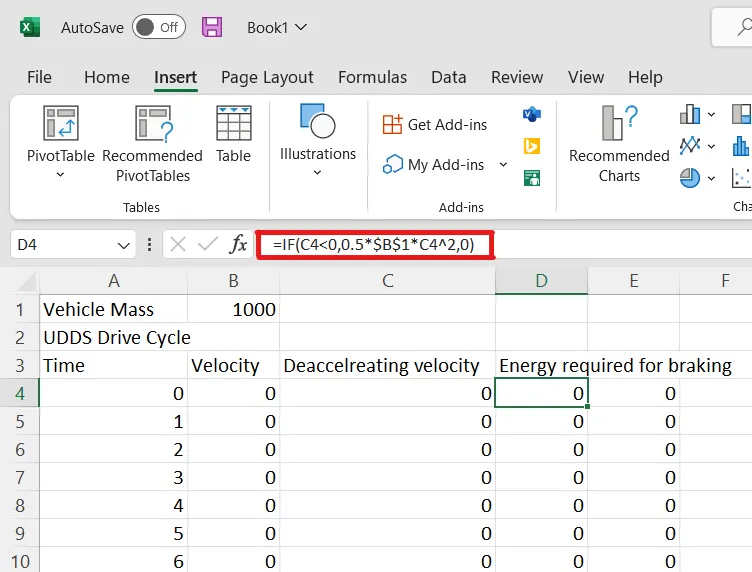
If Decelarating Velocity Is Smaller Then The zero Then Impliment the Energy Forumla otherwise Give the value zero For Graph Purpose.
2.Why electric motor can’t develop braking torque at high speed similar to starting? How electric and mechanical brakes are coordinated?
The Direction Of the Motor is opposite to the Motor Braking Torque Of the Eectrical Motor. when The motor Is starts Torque produced by the motor is very high or peak Value. when motor is Accelarating Torque is constant that is called constant Torque mode. and after some time motor is reached to the high speed or desired speed the torque is low and power is constant that is called constant power mode.means the Torque and speed is visevirsa Torque is high speed is low And torque is low speed is high.
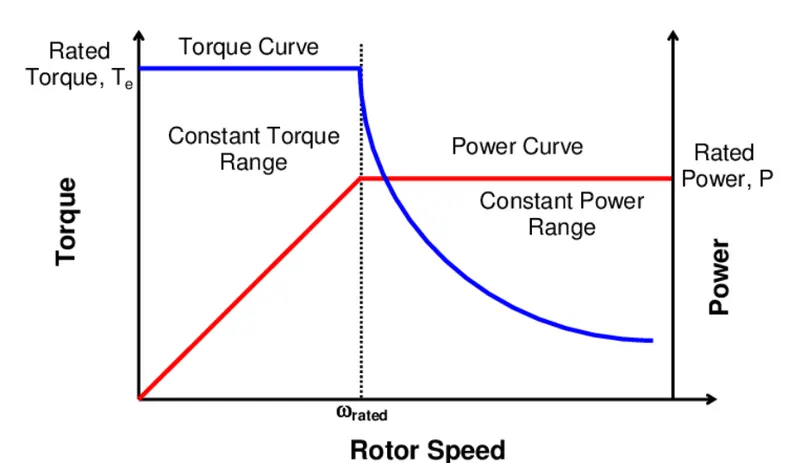
Peak accelarattion And Peak Decelaration Torque Are not equal of the Electric vehicle motor .
At the time of braking, speed value is high therefore torque value will be low. Therefore at the time of braking torque value available will be lower. which results in motor not acheiving higher torque at higher speeds.
How electric and mechanical brakes are coordinated?
Series :- In this Break Control strategy apply Mechanical Break Regenrative break One after Anather That is the Name give to the series Break strategy.
The Breack apply only one at a time either mechanical brake or eithe regenrative brake.
Parallal:- In this braking strategy Both Brakes Simultanously Or Tow brakes apply at a time.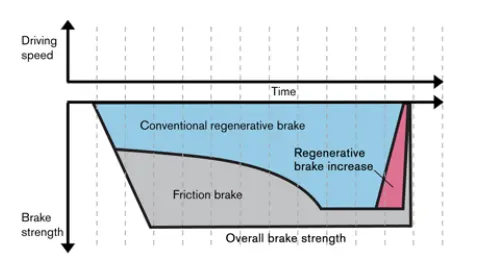
At lower speeds Regenerative braking’s are used and at higher speeds mechanical brakes are used.
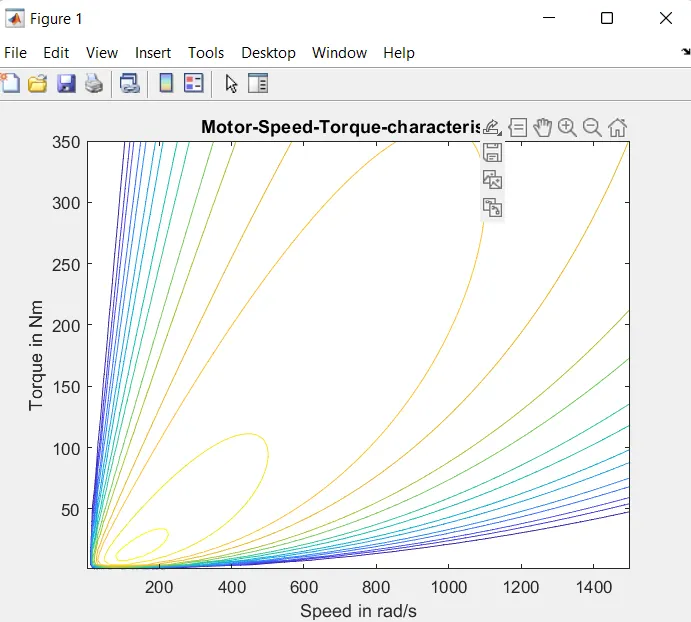
3. Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as a .m file attach a screenshot of all the plots.