Project - Speed Control of a Direct Current (DC) motor
In this project, a Simulink model for the DC motor will be first developed per the schematic shown in Figure 1.Use the Proportional, Integral, and Derivative (PID) control design knowledge gained in the training to design, develop and test a controller to maintain a desired speed for the motor.
- A dc machine can function as a motor in this case.
- A dc Machine has a rotor that is rotating part And stator that is stationary part.
- Here the Speed control of a DC motor is either done manually by the operator or by means of an automatic control device.
- so the speed can be varied by changing:
- The terminal voltage of the armature V
- The external resistance in armature circuit Ra
- The flux per pole.
We Difine the basic Parameters in Workspace.
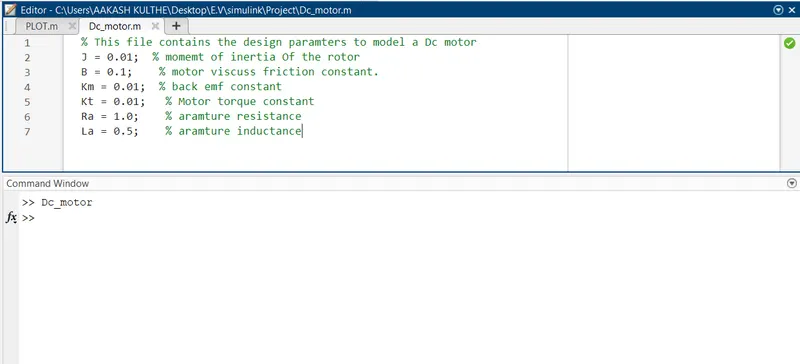
J = 0.01; % momemt of inertia.
B = 0.1; % motor friction
Km = 0.01; % back emf
Kt = 0.01; % Motor torque constant
Ra = 1.0; % aramture resistance
La = 0.5; % aramture inductance
We design the subsystem Of the Dc motor.
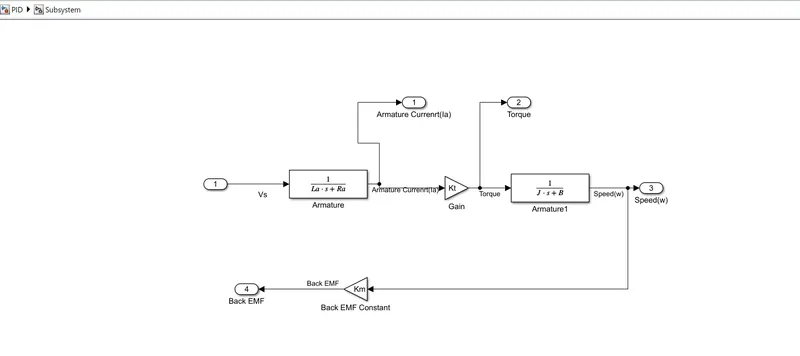
WFind out the Mathamatical equation as following
Usinng Kirchofs voltage low we can derived
Vs=RaIa+La dia/dt+Vb
Bck EMF , anguler velocity and torque are related by
Vb=Km d Theta/dt=Tau=KTaui
So Final equation can be derived as
w(s)/Vs(s)=Kt/JLas^2+(JRa+BLa)s+(BRa+Kt Km)
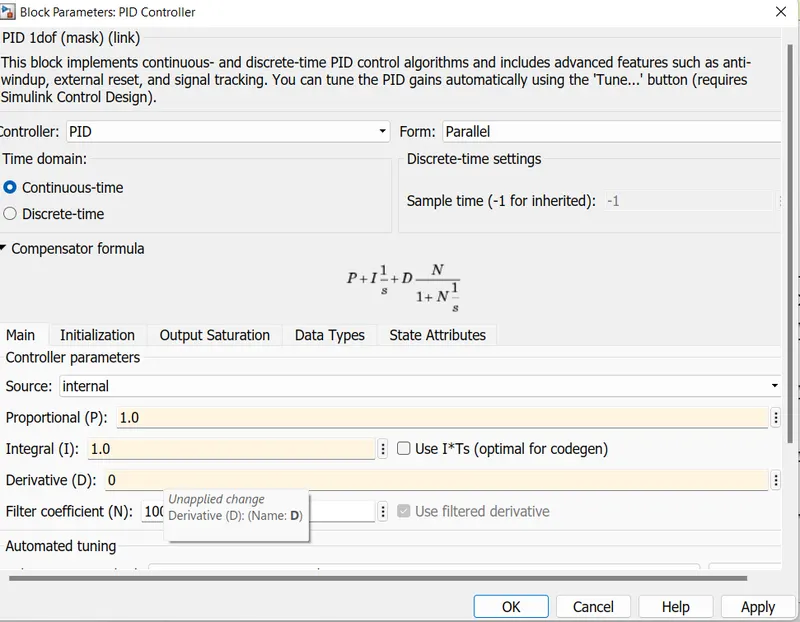
We create the PID controllar.
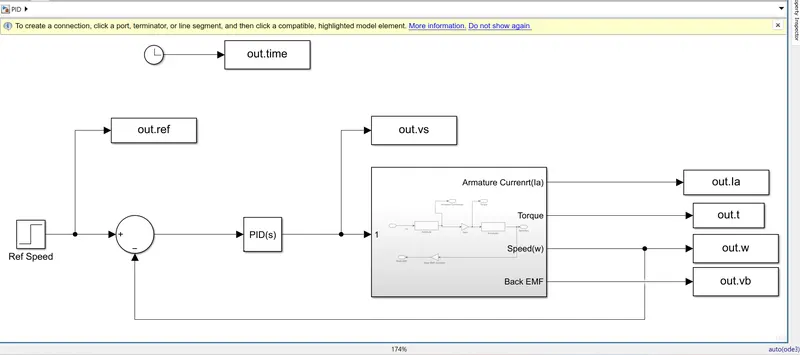
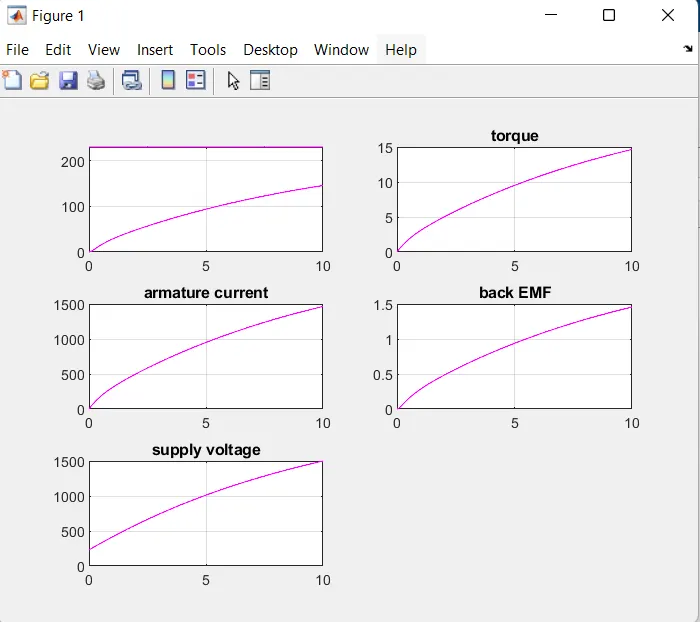
We gave the Kp=1.0,Ki=1.0,Kd=0
Output of For First condition.
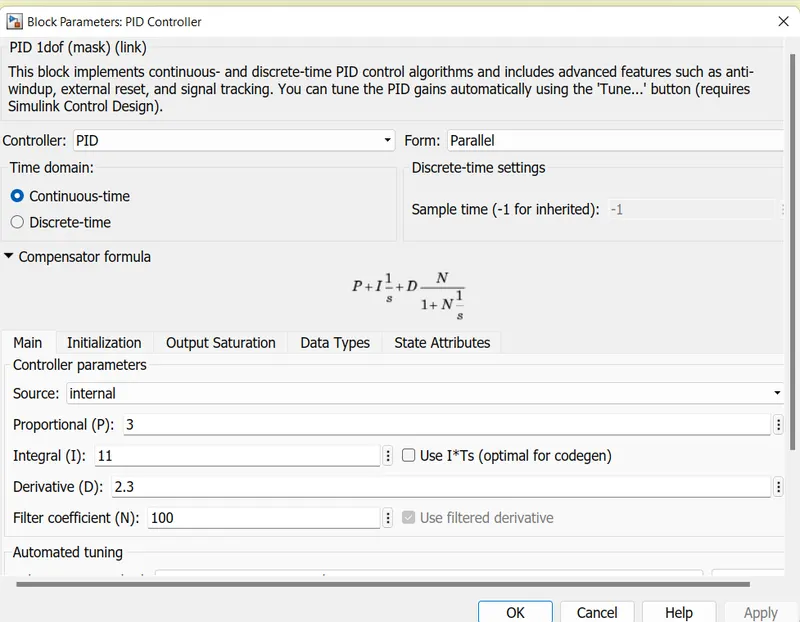
We change the KP Kd Ki Values using std Table
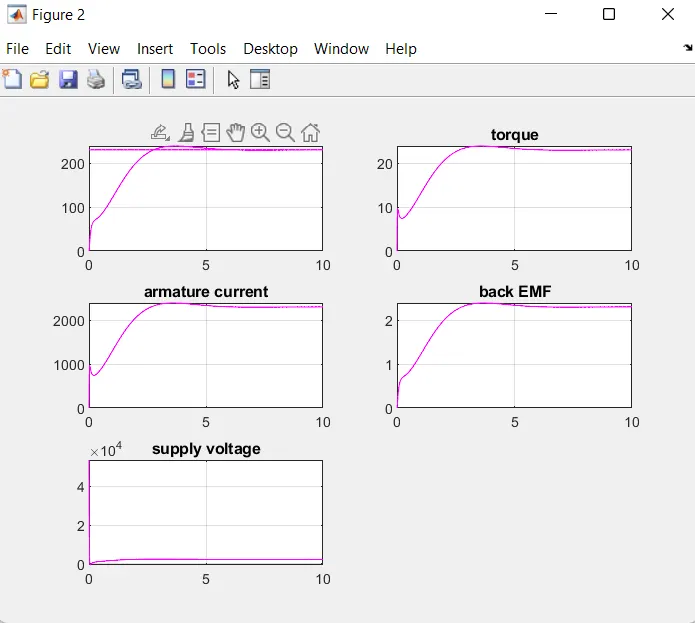
Kp=3 Ki=11 Kd=2.3.
Output For second Condition
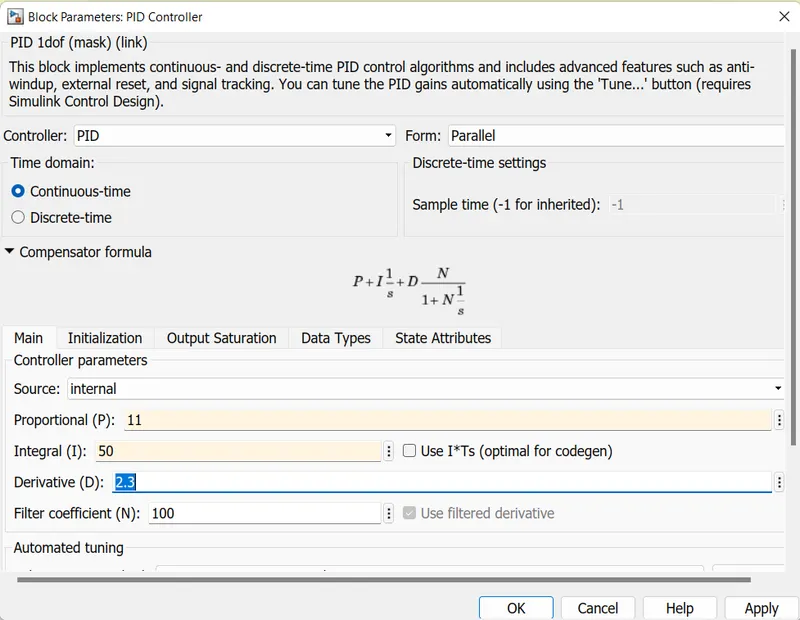
We change the KP Kd Ki Values using std Table
Kp=11 Ki=50 Kd=2.3.
Output For Third Condition.
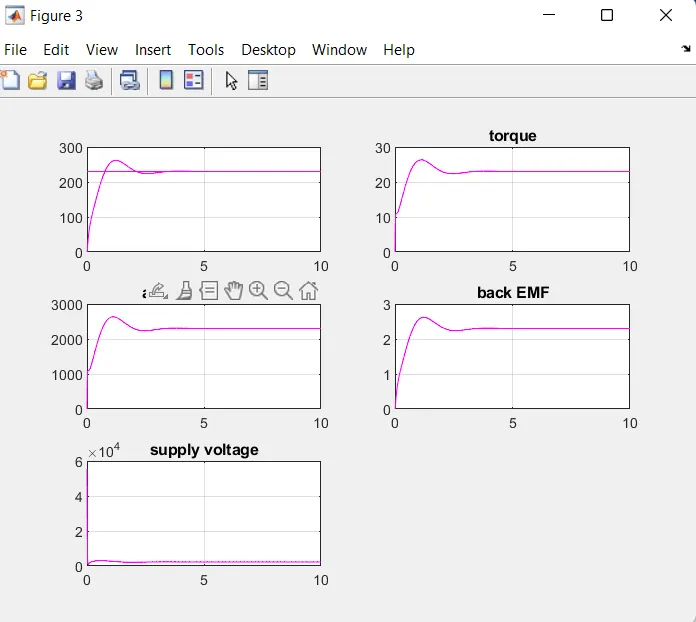
We change the KP Kd Ki Values using std Table
Kp=25 Ki=45 Kd=2.3.
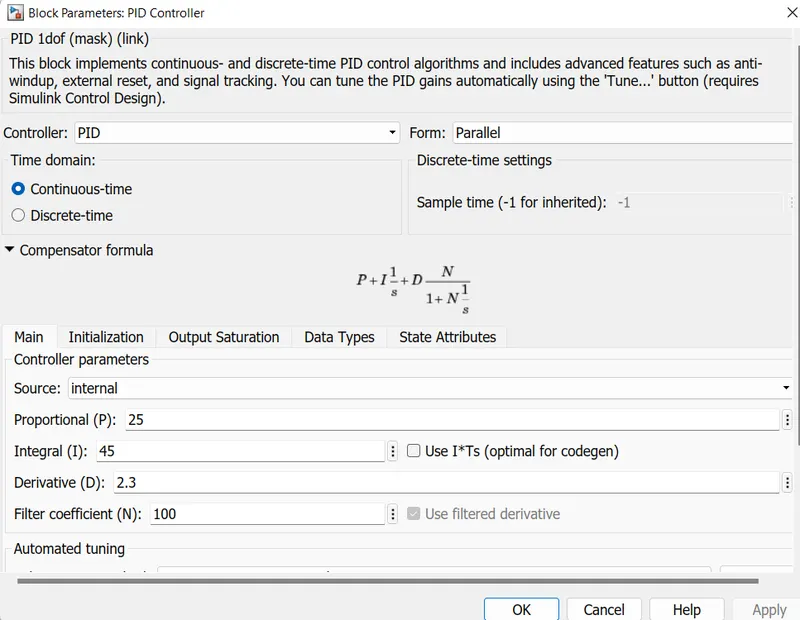
Output For Forth Condition.
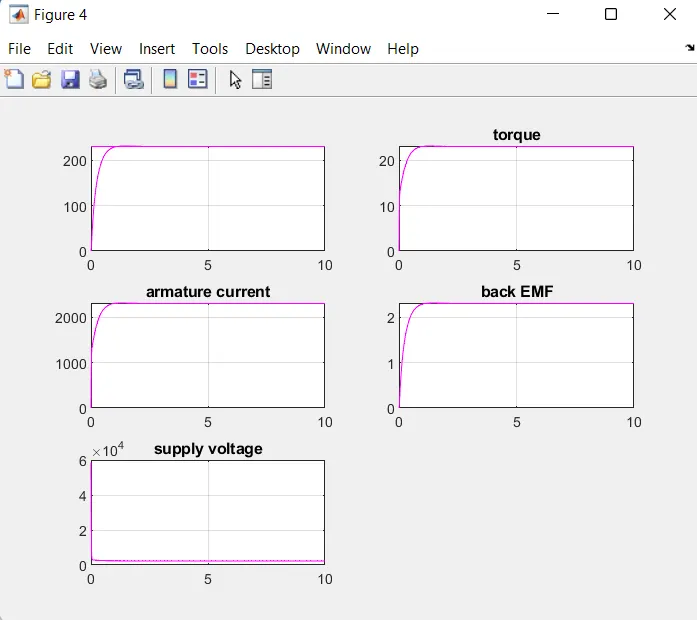
we saw the Mentainig the stability of the system.
Maintain the Desired speed of the motor.
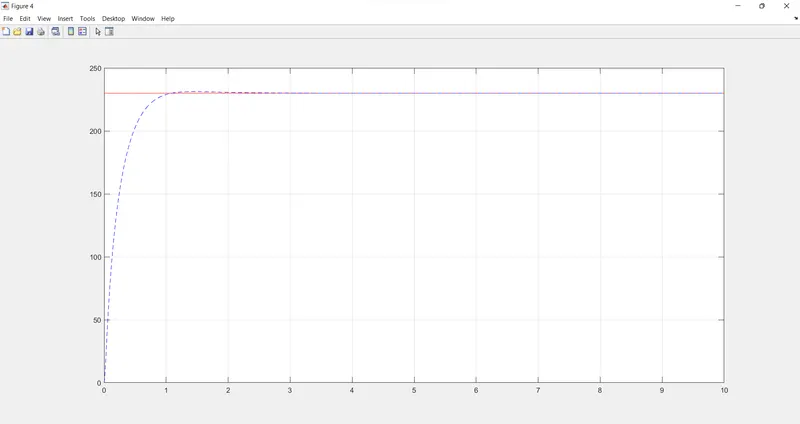
we verify the speed of changing the voltage at 150v
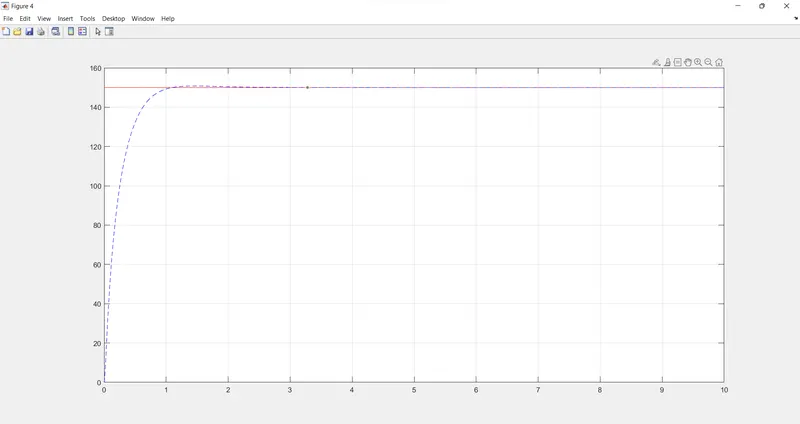
So Both cases Speed are Maintain or follow the Voltage.
In this project we design the Simulink model for the DC motor schematic shown in Figure 1.
Use the Proportional, Integral, and Derivative (PID) control design knowledge gained in the training to design, develop and test a controller to maintain a desired speed for the motor.