Braking
Model 1:
Under the condition of braking, some amount of energy is required to do the same as that of energy required for accelerating the vehicle. Hence to calculate energy, we use the acceleration energy equation,
`E_k = 1/2 *m *v^2`
Calculating the energy required for braking for a defined drive cycle:
Drive cycle: Follow the link for Drive cycle Time vs Velocity data
https://drive.google.com/file/d/1TneTl6RjDbgcH4Npnf-tfK-oa-040btm/view?usp=sharing
From the drive cycle, there are 4 different situations of deceleration of which the energy has to be calculated.
First Braking: 24 - 15km/hr in 4 seconds
Second Braking: 35 - 30km/hr in 1 second
Third Braking: 45 - 23 km/hr in 5 seconds
Fourth braking: 63 - 5 km/hr in 7 seconds
Using Excel Calculator:
The calculations with the formulae is also available in the same google drive link as drive cycle values.
| Energy For Braking | ||||
| Kerb Weight of Vehicle (Kg) | 1500 | |||
| Payload on the Vehicle (Kg) | 250 | |||
| Total Mass (kg) | 1750 | |||
| Braking 1 | Braking 3 | |||
| Initial Velocity(km./hr) | 24 | Initial Velocity(km./hr) | 45 | |
| Initial Velocity(m/s) | 6.666667 | Initial Velocity(m/s) | 12.5 | |
| Final Velocity(km/hr) | 15 | Final Velocity(km/hr) | 23 | |
| Final Velocity(m/s) | 4.166667 | Final Velocity(m/s) | 6.388889 | |
| Time (s) | 4 | Time (s) | 5 | |
| Energy (J) | 23697.9181 | Energy (J) | 101003.085 | |
| Power (kW) | 5.92447953 | Power (kW) | 20.200617 | |
| Braking power(KWh) | 0.00658276 | Braking power(KWh) | 0.02805641 | |
| Braking 2 | Braking 4 | |||
| Initial Velocity(km./hr) | 35 | Initial Velocity(km./hr) | 63 | |
| Initial Velocity(m/s) | 9.722222 | Initial Velocity(m/s) | 17.5 | |
| Final Velocity(km/hr) | 30 | Final Velocity(km/hr) | 5 | |
| Final Velocity(m/s) | 8.333333 | Final Velocity(m/s) | 1.388889 | |
| Time (s) | 1 | Time (s) | 7 | |
| Energy (J) | 21942.5165 | Energy (J) | 266280.864 | |
| Power (kW) | 21.9425165 | Power (kW) | 38.0401234 | |
| Braking power(KWh) | 0.00609514 | Braking power(KWh) | 0.07396691 | |
|
Total Energy Required For Braking (kWh) |
0.11470122 | |||
Solution:
Total Braking energy required = 0.114 kWh = 413KJ
Model 2:
Regenerative braking allows electric vehicles to use the motor as a generator when the brakes are applied, to pump vehicle energy from the brakes into an energy storage device. Regenerative braking is an effective approach to extend the driving range of an EV.
- The regenerative braking torque cannot be made large enough to provide all the required braking torque of the vehicle as it might lead to the deterioration in stability of the vehicle. Also as compared to the torque values of acceleration torque of motor is much higher than deceleration torque.
- At high speed, the motor might be in its constant power region which causes less values of torques produced and this limits the amount of braking torque that is used for regeneration. Hence the peak value of acceleration torque and braking torque are not equal.
Electric and Mechanical brakes Co-ordination:
The regenerative braking system may not be used under many conditions, such as with a high State of Charge (SOC) or a high temperature of the battery. In these cases, the mechanical braking system works to cover the required total braking torque.
Thus, cooperation between the mechanical braking system and the regenerative braking system is a main part of the design of the EV braking control strategy and is known as torque blending.
There are 2 different control strategies for Braking Combinations:
- Series Control Strategy
- Parallel Control Strategy
Series Control Strategy:
- a combination of friction-based mechanical braking system with a regenerative braking system that transfers energy to the battery with an integrated control, which distributes the required braking force between the regenerative braking system and the mechanical braking system.
- Series Strategy could give an increase of 15-30% in fuel efficiency and has more consistent braking due to good torque blending capability.
Parallel Control Strategy:
- Combination of mechanical and the regenerative braking system, operated simultaneously without an integrated control.
- The regenerative braking force is added to the mechanical braking force which cannot be controlled.
- The regenerative torque is determined by considering the motor capacity, battery SOC, and vehicle velocity. The regenerative braking force is calculated from the brake control unit by comparing the demanded brake torque and the motor torque available.
Model 3:
Code:
clear all
close all
clc

% Speed Array
omega = linspace(0, 300, 100);

% Torque Array
T = linspace(0, 2000, 100);

% Meshgrid
[X,Y] = meshgrid(T, omega);

% Loss Coefficients
cu = 0.17;                              % Copper coefficient
fe = 0.006;                             % Iron coefficient
win = 0.000015;                         % Windage coefficient

% Losses
cu_loss = cu*(Y.^2);                  % Copper Losses
fe_loss = fe*(X.^2);                  % Iron Losses
win_loss = win*(X.^3);                % Windage Losses
cond_loss = 18;                       % Conduction Losses% Output Power
P_out = (X.*Y);

% Input Power
P_in = P_out +  (cu_loss) + (fe_loss) + (win_loss) + (cond_loss);

% Efficiency
eta = ((P_out)./(P_in));

% Efficiency values for contour
W = linspace(0.75, 0.95, 10);

% Contour Plot

contour(X,Y,eta,W)
xlabel('Angular Speed, rad/s')
ylabel('Torque, Nm')
title('Speed, Torque and Efficiency characteristics of Motor')
Code Explanation:
A contour plot that shows the characteristics of the speed, torque and the efficiency of a motor is referred to as an efficiency map. Contour plots are very useful as they make it very easy to understand which operating states result in the highest efficiencies of the motor. In this way, a manufacturer can design a motor knowing which applications it will be useful for depending on the speed, the torque it achieves at that speed and the efficiency of the motor which operates at those values.
In order to plot this, we need the specifications of a motor. In this question, I am taking generic values for the specifications of the motor as well as for the losses that occur in the motor operation.
In the MATLAB script, I begin with the clear all, close all and clc commands. Then, I create arrays for the speed and the torque of the motor using the ‘linspace’ command. For the speed, I am taking a range of values from 0 to 2000 radians per second whereas for the torque, I am taking a range of values from 0 to 300Nm.
These arrays are then used to create 2D grid coordinates using the ‘mesh grid’ command. These coordinates will help in the creation of the contour plot. In order to find the efficiency of the motor, we need to consider the various losses that occur in the motor’s operation.
The main losses that occur are:
- Copper losses
- Iron losses
- Windage losses
- Conduction losses
These various losses are dependent on the speed and the torque of the motor. They each also have a characteristic constant of proportionality which are all assumed for the following calculations and represented as 'K'. In each calculation, the speed and the torque are represented respectively as: `omega`and `T`
- Copper losses = `K_(cu)*omega^2`
- Iron losses = `K_(fe)*T^2`
- Windage losses = `K_w*T^3`
- Conduction losses are assumed to be 18 Joules.
We also need to calculate the efficiency of the motor using the data we currently have. Since efficiency is defined as the ratio of the output power to the input power, we can calculate the efficiency of the motor by determining the input and output power of the motor. The output power of the motor can be calculated by multiplying the angular speed with the torque.
`P_(out) = T*omega`
Then, we can calculate the input power supplied to the motor by adding the output power to the energy losses.
`P_i = P_(out) + Cu_(loss) + Fe_(loss) + W_(loss) + Cond_(loss)`
Since efficiency is defined as the ratio of the output power to the input power, we can calculate the efficiency of the motor by:
`eta = P_(out) /(P_i + Cu_(loss) + Fe_(loss) + W_(loss) + Cond_(loss))`
As you can see, the calculations for the output power are performed with the values from the mesh grid and not the individual variables of speed and torque.
Plotting of the contour is done with the 'contour' command. In addition, an array for the efficiency values we want to plot for is created called 'W' and is assigned for values ranging from an efficiency level of 0.75 to 0.95. This array is used in the creation of the contour. Axis labels and a title is also made for better readability.
Output:
The image below shows the contour plot that is achieved when the code is executed:
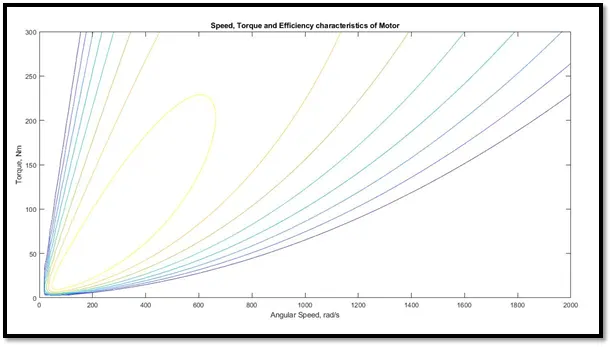
From this contour plot, we can see that the highest level of efficiency arises in the innermost contour plot and this efficiency decreases as the contours increase in size from the innermost contour. The innermost contour shows that any point on the contour will have an efficiency of 0.9054. The second, third and fourth innermost contour display efficiencies of 0.88, 0.86 and 0.84 respectively anywhere on their respective contour plots.