Week-11 Challenge: Braking
1.
For a defined driving cycle, Calculate the energy required for braking.
Braking of a vehicle is as important as acceleration. Acceleration is the increase in the speed and deceleration is reduction in the speed. We can calculate the energy required for braking in the same way we calculate the energy required for acceleration.
i.e Energy for braking = 1/2*m*v^2.
where m = mass of the vehicle.
v = velocity of the vehicle.
The excel sheet which calculate the energy required for braking for a specific drive cycle is attached below.
https://drive.google.com/file/d/17rAPru7GtTKkS8ErCXnoSe7R7-ler77Z/view?usp=sharing
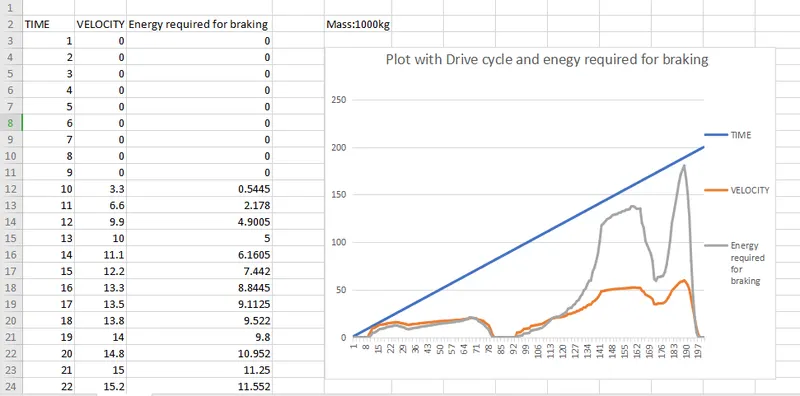
The above shown is the plot of time vs velocity and time vs braking energy.
The maximum braking energy for this driving cycle is 180KJ.
2.
Why electric motor can't develop braking torque at high speed similar to starting? How electric and mechanical brakes are co-ordinated?
Consider a speed-torque characteristics ofa motor used in EV application
An EV can achieve high speed during statring but can't achieve the same with same speed during braking. This is true in the EV motor case.
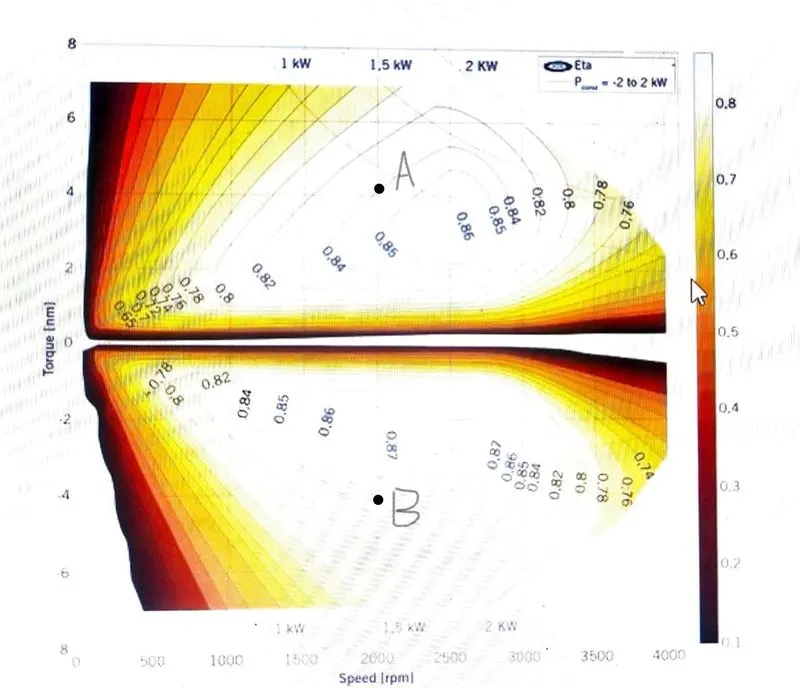
During low speed the torque produced by the motor is almost constant and motor operates in the constant torque region. Thus it has higher acceleration power. Now consider the point A in the above characteristics of a motor with a vehicle speed of 100 kmph at that point which is in constant power region.
Now when it comes to braking part where torque is negative, Lets consider the replicate of point A is point B and the braking torque is at point B is around -4 N-m compared to peak torque of -7 N-m.
The peak acceleration torque and peak decceleration torque is not same for a motor, i.e at low speed we get high torque and at high speed the value of torque is lower. So we cannot say that motor which is producing 7 N-m of torque for acceleration can also produce -7 N-m of braking torque. so because we are operating the braking torque at field weakening region or operating the motor abovr base speed we must also know that the torque value is compromised or lower.
The braking torque of EV motor is not high as acceleration torque. Therefore regenerative braking cannot happen so effectively such that all power produced is pulled back to the battery.
This is one of the motor limitation.
The electric and mechanical brakes are coordinated in two different ways.
1. Series brake control stratergy
2. Parallel brake control stratergy.
In series brake control stratergy, we apply the mechanical brake and regenerative electrical brake one after another, i.e we apply only one brake at a time (either mechanical braking or regenerative braking).
In parallel brake control, we apply both the brake simultaneously.
The series has two classification.
(a) Comfort of driver
(b) Energy efficiency.
Electric Driven Intelligent Brake (EDIB)
It is a braking stratergy developed in Nissan Leaf.
This EDIB is a combination of hydraulic brake along with a regerative brake
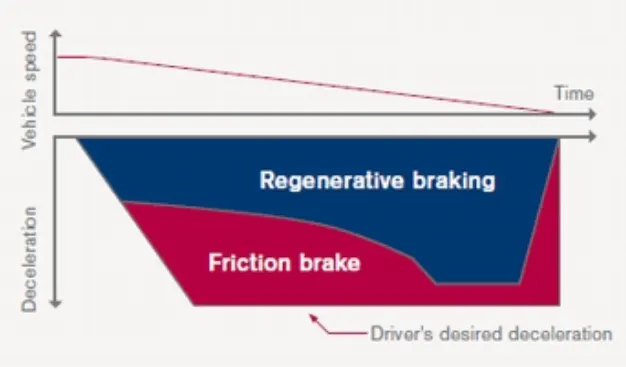
Here parallel braking technique is used initialy. At higher braking speed, we have both regenerative braking and frictional braking and whenever speed of the vehicle reduces at low speed we get higher torque by the motor and percentage sharing for regenerative braking increases in lower speed.
3.
Make a MATLAB program which plots contour of given motor speed, torque and efficiency values. Attach the code as .m file and attach a screenshot of all the plots.
Every motor has losses happening inside it.
1.copper loss : I^2*R losses.Since T is proportional to I, the copper losses can be considered as constant of copper losses. i.e Kc = T^2.
Kc takes care of resistance of brushes and also care of magnitic flux and its effect.
2. Iron loss : Ki*`omega`. Ki depends on magnetic field effect. The iron loss changes according to the speed beacuse at various speed we have different value of back emf, therefore that will effect the iron loss.
3. Windage loss: Kw*`omega`^3. This depends on the size and shape of the the motor and the amount of windage losses that the motor is going to experience.
4. Constant losses: denoted a C
Total losses = (Kc*T^2) + (Ki*`omega`) + (Kw*`omega`^3) + C.
Almost all types of motor can be modelled with this equation.
% A program for plotting efficiency contours for electric motors.
% The x axis corresponds to motor speed (w)and y axis to torque T.
% First setup arrays for range
x=linspace(1,1000);    %speed in rad/sec
y=linspace(1,250);     %Torque in N-m.
% Allocate motor loss constants.
Kc = 0.2;     % copper loss.
Ki = 0.008;   % Iron loss.
Kw = 0.0001;  % Windage loss.
conL = 20;    % Constant motor loss
% make mesh
[X,Y]=meshgrid(x,y);
outputpower=(X.*Y);  %Torque*speed=power.
B=(Y.^2)*Kc;         %copper loss.
C=X.*Ki;             %Iron loss.
D=(X.^3)*Kw;         %windage loss.
inputpower=outputpower+B+C+D+conL;
z=outputpower./inputpower;
%we now set the efficiencies for which a contour will be plotted
V = [0.70,0.80,0.85,0.90,0.91,0.92,0.925,0.93];
%V is the mapping of the efficiency points.
box off
grid off
contour(X,Y,z,V);
xlabel('speed/rad.s^-^1'),ylabel('Torque/Nm');
OUTPUT:
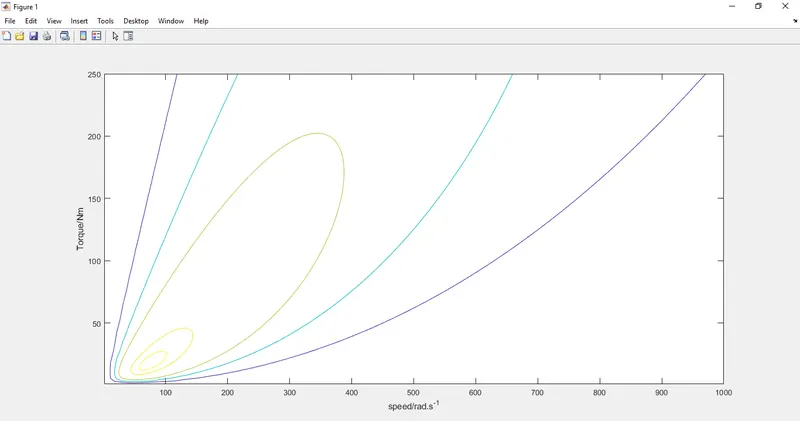
If we are provided with Ki, Kc, Kw then we can plot its contour using matlab of any type of motor.