Suspension Geometry: Instant Center and Roll Center
The instant centre is a point in space (real or extrapolated) about which the suspension links pivot. The line drawn from the wheel centre to the instant centre is the equivalent swing arm and its length and angle are critical to suspension design. Geometrically it is obtained at a point where the upper control arm and lower control arm intersect each other virtually.
The roll centre is located at the intersection of a line drawn from the centre of the tire contact patch to the IC and the centerline of the vehicle in the YZ plane. The roll centre establishes the force coupling point between the sprung mass and unsprung mass.
Here we are going to calculate the location of the instant centre of both the tires and also calculate the roll centre height.
Aim:
1. To calculate the Instant centres of both wheels in coordinates of the YZ plane.
2. To calculate the roll centre height.
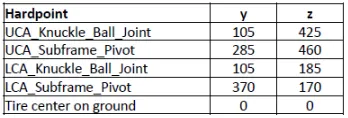
SUSPENSION HARDPOINTS:
FRONT VIEW GEOMETRY DIAGRAM PLOTTED USING MATLAB:
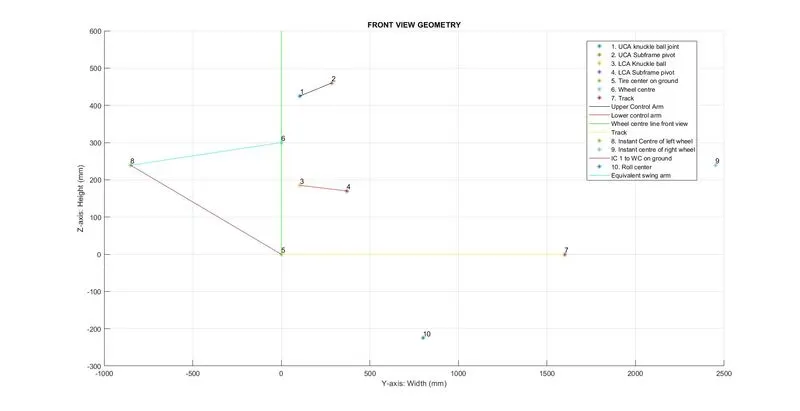
A clear picture of this diagram can be downloaded from this link: Instant Center & Roll Center diagram
RESULTS/OUTPUT:
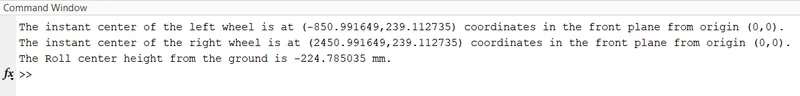
The instant centre of the left wheel lies at (-850.99 mm, 239.11 mm) in the YZ plane.
The instant centre of the right wheel lies at (2450.99 mm, 239.11 mm) in the YZ plane.
The roll centre height is -224.785 mm.
MATLAB CODE:
close all
clear all
clc

track = 1600;
half_track = track/2;
wheel_radius = 300;

y = [105 285 105 370 0 0 track]; % All y-coordinates
z = [425 460 185 170 0 wheel_radius 0]; % All z-coordinates

labels = {'1','2','3','4','5','6','7'};

hold on
for i = 1:length(y)
    plot(y(i),z(i),'*')
    text(y(i),z(i),labels{i},'VerticalAlignment','bottom','HorizontalAlignment','left')
end

plot([y(1),y(2)],[z(1),z(2)],'color','k') % Upper control arm
plot([y(3),y(4)],[z(3),z(4)],'color','r') % Lower contol arm
plot([y(5),y(5)],[z(5),z(6)*2],'color','g') % Wheel centre line front view
plot([y(5),y(7)],[z(5),z(7)],'color','y') % Track

% Calculating Intersection of left wheel UCA and LCA
m1 = (z(2)-z(1))/(y(2)-y(1));
c1 = z(2) - (y(2)*m1);
m2 = (z(4)-z(3))/(y(4)-y(3));
c2 = z(4) - (y(4)*m2);

IC_y1 = (c2-c1)/(m1-m2); % y co-ordinate of IC 1
IC_z = (m1*IC_y1)+c1; % IC height
plot(IC_y1,IC_z,'*') % IC of left wheel
IC_y2 = y(7) - IC_y1; % y co-ordinate of IC 2
plot(IC_y2,IC_z,'*') % Ic of right wheel

plot([IC_y1,y(5)],[IC_z,z(5)]);

% Calculating inyersection
m3 = (IC_z-z(7))/(IC_y1-y(5));
c3 = IC_z - (IC_y1*m3);
m4 = (IC_z-z(7))/(IC_y2-y(7));
c4 = IC_z - (IC_y2*m4);

RC = (c4-c3)/(m3-m4); % y co-ordinate of Roll center
RC_height = (m3*RC)+c3; % Roll center height
plot(RC,RC_height,'*')

text(IC_y1,IC_z,'8','VerticalAlignment','bottom','HorizontalAlignment','left')
text(IC_y2,IC_z,'9','VerticalAlignment','bottom','HorizontalAlignment','left')
text(RC,RC_height,'10','VerticalAlignment','bottom','HorizontalAlignment','left')

title('FRONT VIEW')
xlabel('Y-axis')
ylabel('Z-axis')
legend('1. UCA knuckle ball joint','2. UCA Subframe pivot','3. LCA Knuckle ball','4. LCA Subframe pivot','5. Tire center on ground','6. Wheel centre','7. Track','Upper Control Arm','Lower control arm','Wheel centre line front view','Track','8. Instant Centre of left wheel','9. Instant centre of right wheel','IC 1 to WC on ground','10. Roll center')

%% Required outputs
fprintf('The instant center of the left wheel is at (%f,%f) coordinates in the front plane from origin (0,0).n',IC_y1,IC_z);
fprintf('The instant center of the right wheel is at (%f,%f) coordinates in the front plane from origin (0,0).n',IC_y2,IC_z);
fprintf('The Roll center height from the ground is %f mm.n',RC_height);