Simulation of HEV Reference application with WOT drive cycle using MATLAB
Objective
> Definition of mapped and dynamic model
> Explanation of model calculating miles per gallon.
> Run the HEV ReferenceApplication with WOT drive cycle. Change the grade and wind velocity in the environment block.
> Keeping all other parameters same, compare the simulated results of hybrid and pure electric powertrains.
Difference between mapped and dynamic model of engine, motor and generator.
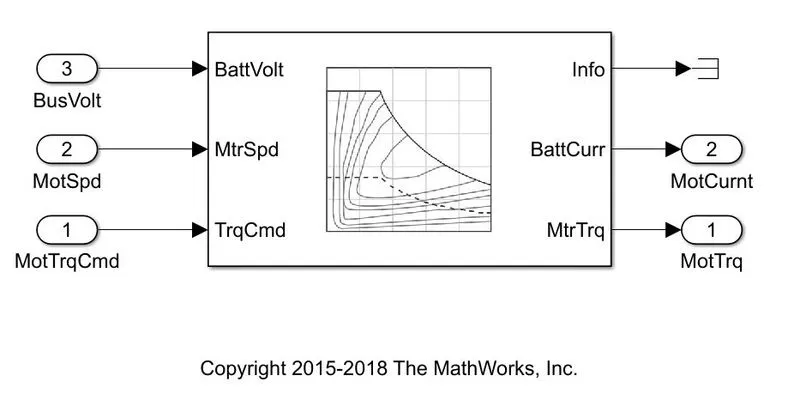
Mapped model
To run the simulation with predefined commands and set of look up tables, mapped model is selected.
Mapped model simulation takes less time to simulate.
Mapped model simulation can also be known as static model simulation since, it does not involve the real-time outputs from the subsystems.
Dynamic model
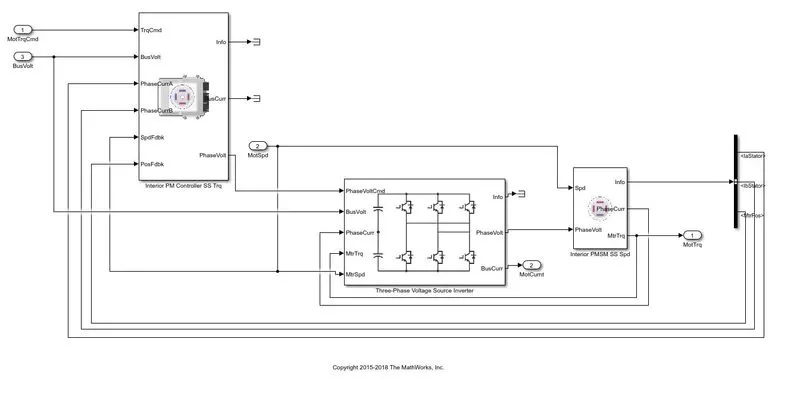
To run the simulation with the actual model, dynamic model is selected.
Dynamic model involves the real-time outputs from all the subsystems to simulate
Since considering all the subsystems, the accuracy of this model is better than the mapped model simulation
Dynamic model simulation takes more time to simulate than the mapped model simulation.
To change the model type
At first the type of vehicle is selected then, run the reference application using the command window in Matlab.
In the simulink window, open the electric plant block which will be inside the passenger car block.
If the selected type is pure electric vehicle then, right click the MotGenEvMapped block.
Choose, Variant-->Label mode active choice --> MotGenEvMapped/MotGenEvDynamic
If the selected type is hybrid electric vehicle then, the model of motor and generator can be changed seperately
To change the model type of the generator, right click on the generator block then
choose, Variant --> Label mode active choice --> GenDynamic / GenMapped
To change the model type of the motor, right click on the motor block then
choose, Variant --> Label mode active choice --> MotDynamic / MotMapped
Simulation of HEV with WOT condition without any change
The simulink window of the HEV reference application and the modified drive cycle source window is show below.
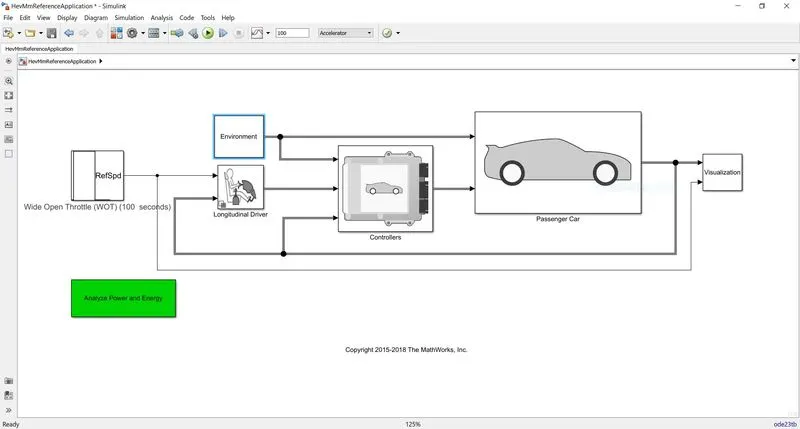
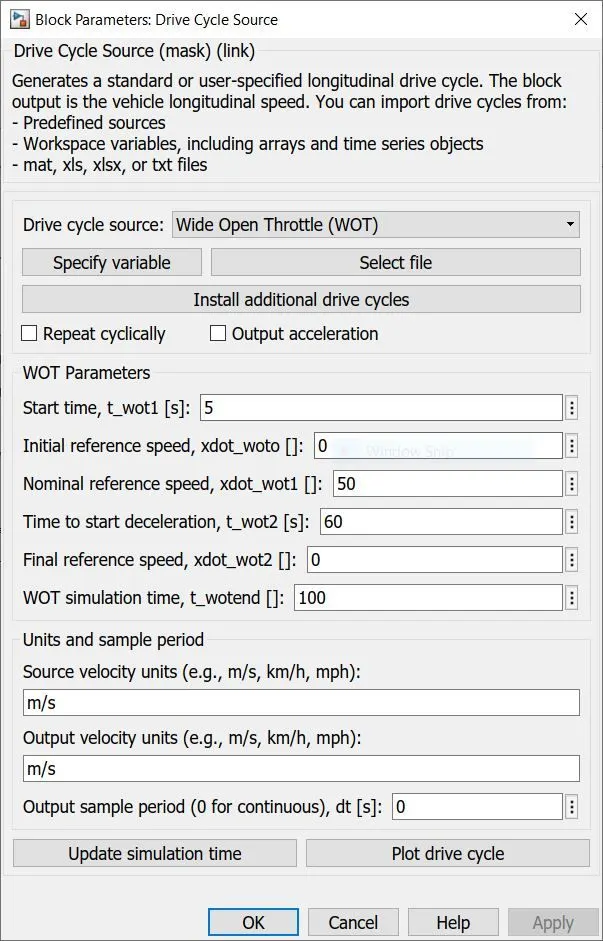
The drive cycle source is modified in such a manner to simulate the vehicle in wide open throttle condition.
The result of the simulation
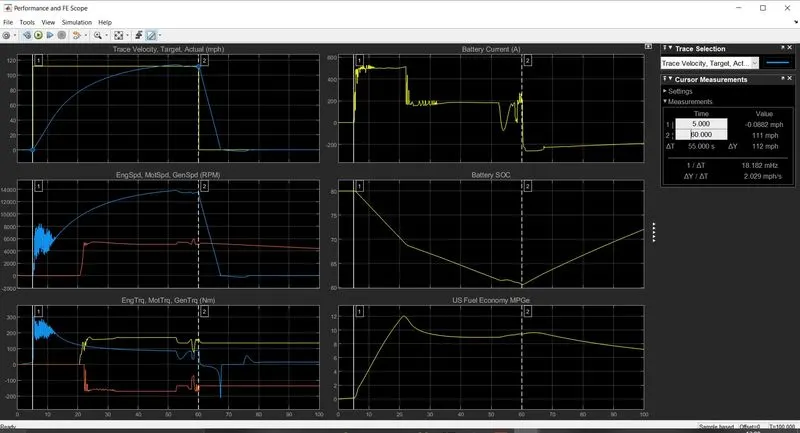
The result consists of six plots in which ,
Plot 1 - Target speed vs Actual speed in mph
The top speed of 112 mph was achieved in 42.3 seconds
The deceleration from 112 mph - 0 mph was achieved in 7.5 seconds
Plot 2 - Speed curve of engine , motor speed and generator speed
This shows the speed of the engine, motor and generator at various points
Plot 3 - Torque curve of engine, motor and generator in N-m
The torque of generator is in negative @ 21 sec of the simulation, which shows that the battery is getting recharged.
The torque of engine is reduced gradually as the power increases, due to the speed requirement of the vehicle.
Plot 4 - Battery current
Initially the current required to run the motor is high and reduces when the speed of the vehicle increases. The motor is used mainly for the starting torque of the vehicle since, the current requirement of the motor is also high.
Plot 5 - Battery state of charge
Initially the state of charge is at 80%. At the end of acceleration the SOC becomes 60.06%. This change in SOC shows the use of motor while acceleration. At 21 sec of the simulation the generator starts recharging the battery. Therefore two different discharging slopes occur during the acceleration of the vehicle.
When the vehicle starts decelerating, the state of charge gradually increases as there is no usage of motor and the generator continues to recharge the battery.
Plot 6 - Fuel economy
The fuel economy in US MPG which is calculated in the performance calculation block of the model is shown in this plot.
The fuel economy was high until the motor was used to accelerate the vehicle. When the power requirement of the vehicle increases the fuel economy decreases respectively
The maximum fuel economy was 12.04 MPG
The minimum fuel economy obtained was 7.18 MPG
Simulation of HEV with WOT condition with changes in environment block
The parameters of the drive cycle source block is kept the same.
The parameters such as grade and wind velocity in the environment block is changed as shown below
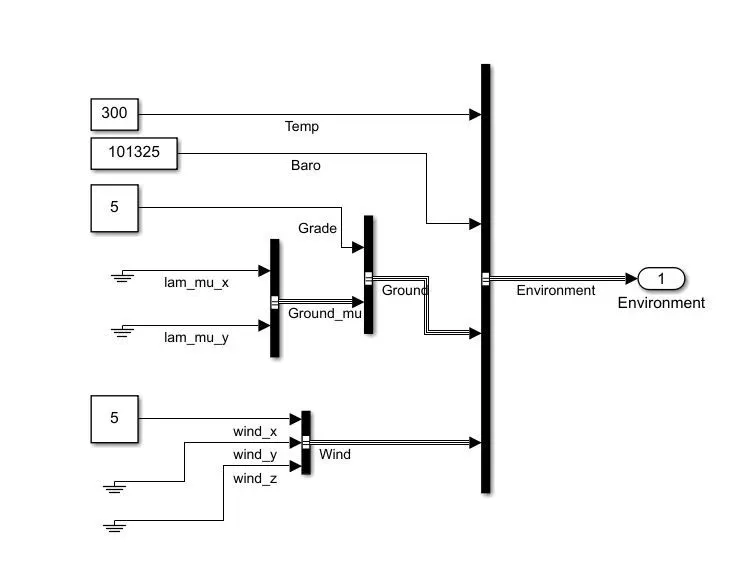
>The Grade value is set to 5 degrees
>The wind velocity is set to 5 m/s in x axis direction
>Other parameters remains unchanged
The result of simulation
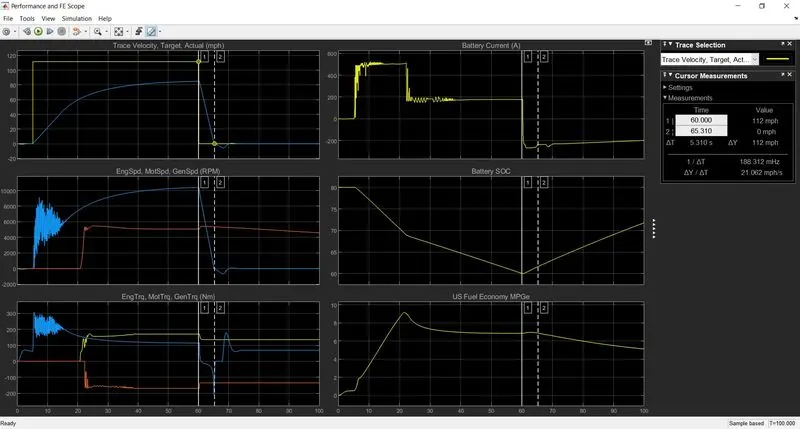
The result consists of six plots in which ,
Plot 1 - Target speed vs Actual speed in mph
The top speed of 85.1 mph was achieved in 55 seconds
The deceleration from 85.1 mph - 0 mph was achieved in 5.31 seconds
Plot 2 - Speed curve of engine , motor speed and generator speed
This shows the speed of the engine, motor and generator at various points
Plot 3 - Torque curve of engine, motor and generator in N-m
The torque of generator is in negative @ 21 sec, which shows that the battery is getting recharged.
The torque of engine is reduced gradually as the power increases, due to the speed requirement of the vehicle.
Plot 4 - Battery current
Initially the current required to run the motor is high and reduces when the speed of the vehicle increases. The motor is used mainly for the starting torque of the vehicle since, the current requirement of the motor is also high.
Plot 5 - Battery state of charge
Initially the state of charge is at 80%. At the end of acceleration the SOC becomes 60.03%. This change in SOC shows the use of motor while acceleration. At 21 sec of the simulation the generator starts recharging the battery. Therefore two different discharging slopes occur during the acceleration of the vehicle.
When the vehicle starts decelerating, the state of charge gradually increases as there is no usage of motor and the generator continues to recharge the battery.
Plot 6 - Fuel economy
The fuel economy in US MPG which is calculated in the performance calculation block of the model is shown in this plot.
The fuel economy was high until the motor was used to accelerate the vehicle. When the power requirement of the vehicle increases the fuel economy decreases respectively
The maximum fuel economy was 9.17 MPG
The minimum fuel economy obtained was 5.11 MPG
Conclusion
The results are compared using a spreadsheet
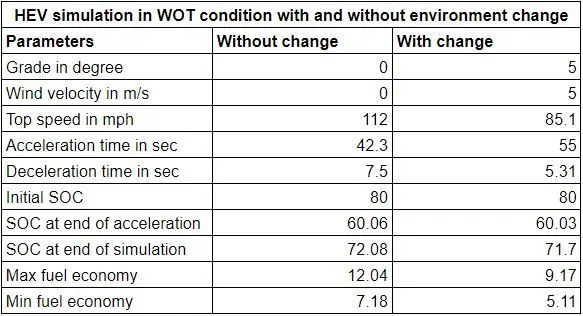
link for spreadsheet - (https://docs.google.com/spreadsheets/d/1V_-3MtrR4nwokeInsPsnClywiVjL8Gc-AqWZDFAtpaw/edit?usp=sharing)
Hence we can conclude that the vehicle with lower degree grade and lower wind velocity,
>Can reach high speed in short amount of time.
>Have high fuel efficiency.
>Have high deceleration time.
>Have better SOC.
Simulation of pure electric vehicle with WOT drive cycle
Simulation of Pure EV with WOT condition without any change
The drive cycle source window parameters are kept similar to the HEV simulation.
The simulation is made to run with no change in the environment block.
The result of the simulation
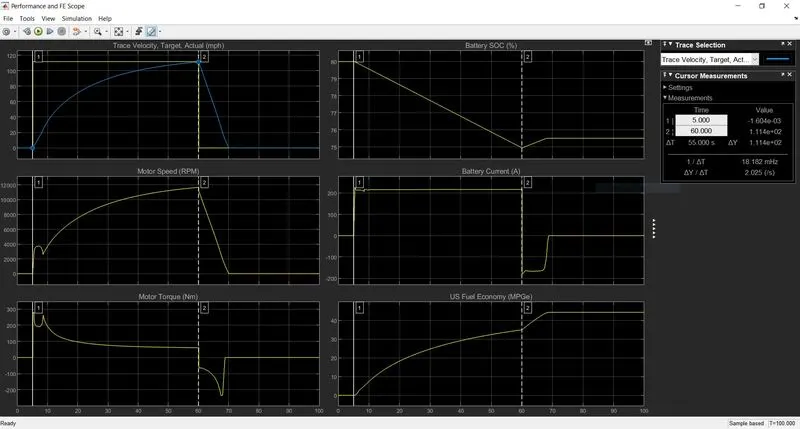
The result consists of six plots in which ,
Plot 1 - Target speed vs Actual speed in mph
The top speed of 111.4 mph was achieved in 55 seconds
The deceleration from 111.4 mph - 0 mph was achieved in 10 seconds
Plot 2 - Speed curve of motor
This shows the speed of the motor at various points in rpm
Maximum motor speed - 11670 rpm
Plot 3 - Torque curve of motor in N-m
The torque of motor is in negative from 60 sec - 70 sec, which shows that the vehicle is decelerating and the battery is getting recharged
Plot 4 - Battery current
The battery current requirement in the WOT condition for the vehicle was constant until the acceleration of the vehicle stops.
During deceleration, the current value goes negative which shows that the battery is recharged during that period of time.
Plot 5 - Battery state of charge
Initially the state of charge is at 80%. At the end of acceleration the SOC becomes 74.94%. This change in SOC shows the use of motor while acceleration. During the 10 sec deceleration period, from 60 sec - 70 sec of the simulation the battery got charged by 0.56%. therefore the SOC at the end of simulation was 75.50%
Plot 6 - Fuel economy
The fuel economy in US MPG which is calculated in the performance calculation block of the model is shown in the plot.
The maximum fuel economy was 44.30 MPG
The minimum fuel economy obtained was 34.95 MPG
Simulation of Pure EV with WOT condition with changes in environment block
>The drive cycle source window parameters are kept similar to the HEV simulation.
>The Grade value is set to 5 degrees
>The wind velocity is set to 5 m/s in x axis direction
>Other parameters remains unchanged
The simulation is made to run with the above changes
The result of the simulation
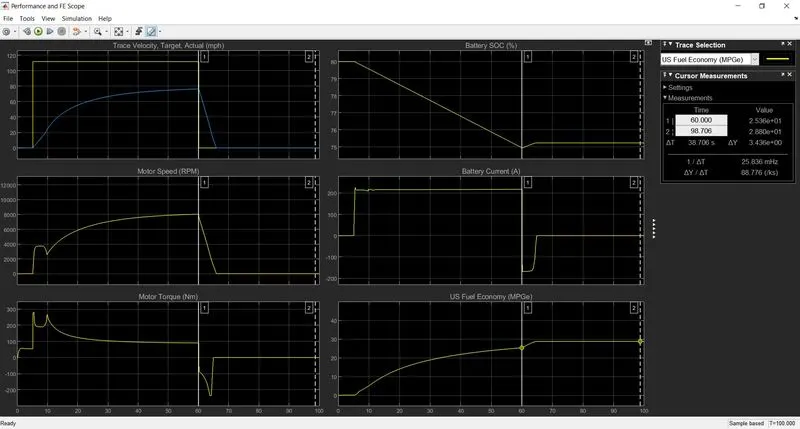
The result consists of six plots in which ,
Plot 1 - Target speed vs Actual speed in mph
The top speed of 76.36 mph was achieved in 55 seconds
The deceleration from 76.36 mph - 0 mph was achieved in 6 seconds
Plot 2 - Speed curve of motor
This shows the speed of the motor at various points in rpm
Maximum motor speed - 8046 rpm
Plot 3 - Torque curve of motor in N-m
The torque of motor is in negative from 60 sec - 66 sec, which shows that the vehicle is decelerating and the battery is getting recharged
Plot 4 - Battery current
The battery current requirement in the WOT condition for the vehicle was constant until the acceleration of the vehicle stops.
During deceleration, the current value goes negative which shows that the battery is recharged during that period of time.
Plot 5 - Battery state of charge
Initially the state of charge is at 80%. At the end of acceleration the SOC becomes 74.94%. This change in SOC shows the use of motor while acceleration. During the 6 sec deceleration period, from 60 sec - 66 sec of the simulation the battery got charged by 0.23%. therefore the SOC at the end of simulation was 75.23%
Plot 6 - Fuel economy
The fuel economy in US MPG which is calculated in the performance calculation block of the model is shown in the plot.
The maximum fuel economy was 28.8 MPG
The minimum fuel economy obtained was 25.36 MPG
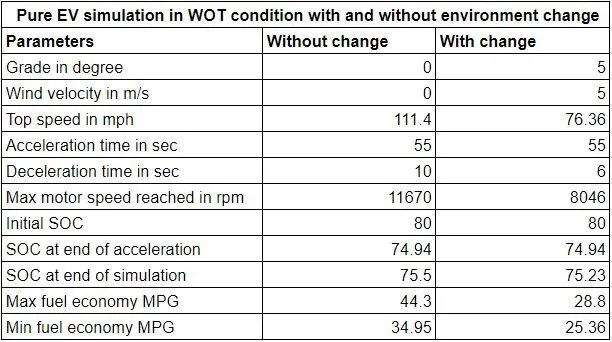
>Can reach high speed in short amount of time.
>Have high fuel efficiency.
>Have high deceleration time.
>Due to high deceleration time, the recharging time of battery is also high
>Therefore better SOC
Comparing the conclusions of simulations of HEV and Pure EV
A spreadsheet is used to compare the results of all the four simulation as shown below
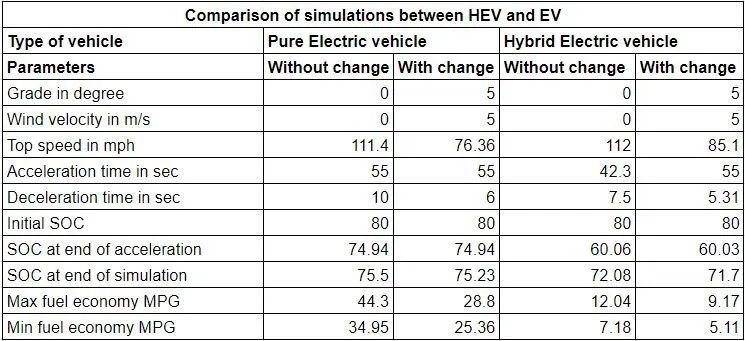
Link for spreadsheet - (https://docs.google.com/spreadsheets/d/1WetNFlSNZRh_xObJtj35k5yAoH9j2TkM5ck6-UOYXfc/edit?usp=sharing)
Ii is clearly seen that,
>HEV and EV without changed parameters have approximately equal top speeds. Since there is no opposing environmental forces
>HEV has good acceleration time. Since it has both motor and a engine.
>HEV with changed environment parameters has the lowest deceleration time.
>Pure EV with unchanged environment parameters has the longest deceleration time.
>Initial SOC of all the vehicles are same.
>At the end of acceleration EV has better SOC compared to the HEV simulation.
>SOC at the end of all the simulations is approximately equal.
>Pure EV without changed parameters has high fuel economy when compared to other simulations.
>HEV with changed parameters has the lowest fuel economy.
How does the model calculate miles per galon
For pure electric vehicle
The performance calculation of a pure electric vehicle is done using the model shown below
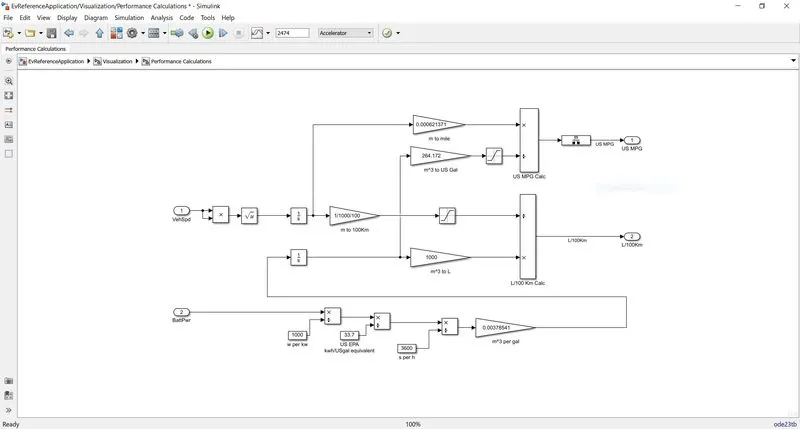
The factors which are considered to calculate the mile per gallon value of a pure electric vehicle are vehicle speed and battery power.
The vehicle speed is integrated to get the value of distance covered in meters. This value is then converted to mile and kilometre.
The battery power in watt is converted into m^3 per gal, which is then integrated and converted into US Gallon and Litre.
The US Gal value is used to divide the distance covered in mile to get the US MPG (miles per gallon) value of the vehicle.
The Litre value is used to divide the distance covered in km to get the L/100 km value of the vehicle
For hybrid electric vehicle
The performance calculation of the hybrid electric vehicle is done using the below shown model
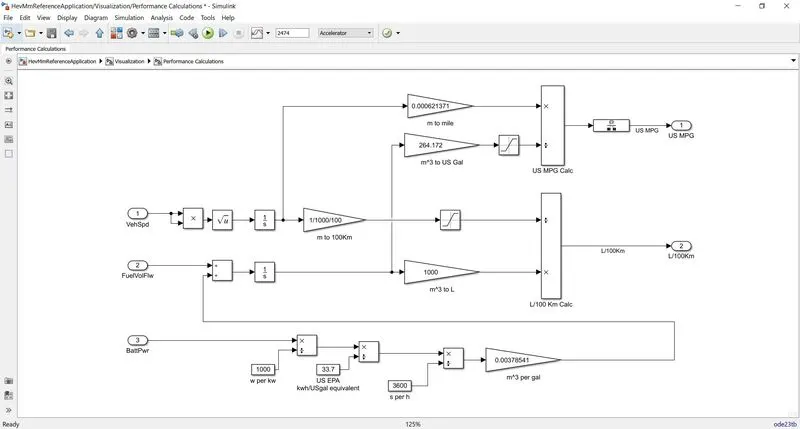
The vehicle speed, fuel flow and battery power are the factors which are involved in calculating the miles per gallon value of the vehicle.
The vehicle speed is integrated to get the value of distance covered in meters. This value is then converted to mile and kilometre.
The battery power in watt is converted into m^3 per gal, which is then summed with fuel flow and then integrated. This integrated value is converted into US Gallon and Litre.
The US Gal value is used to divide the distance covered in mile to get the US MPG (miles per gallon) value of the vehicle.
The Litre value is used to divide the distance covered in km to get the L/100 km value of the vehicle