Project - Speed Control of a Direct Current (DC) motor
Aim:
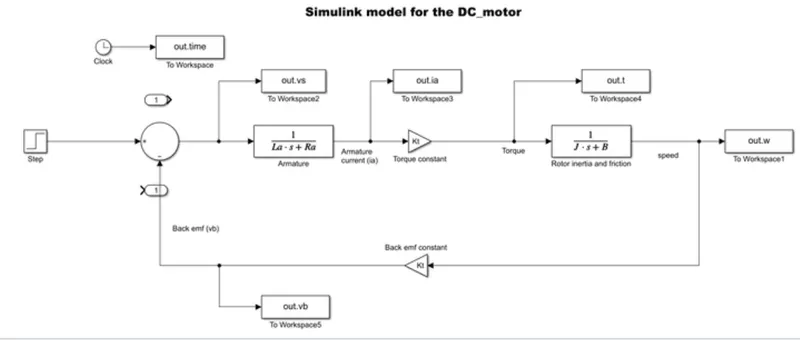
To design a Simulink model for the DC motor shown in Figure 1. amd aslo by Using the Proportional, Integral, and Derivative (PID) control design knowledge gained in the training to design, develop and test a controller to maintain a desired speed for the motor.
Answer:
- Here the Speed control of a DC motor is either done manually by the operator or by means of an automatic control device.
- This is different to speed regulation where the speed is trying to be maintained or regulated against the natural change in speed due to a change in the load on the shaft
-
so the speed can be varied by changing:
- The terminal voltage of the armature V
- The external resistance in armature circuit Ra
- The flux per pole
-
So Terminal voltage and external resistance involve a change that affects the armature circuit while flux involves a change in the maginetic field
-
so Therefore speed control of DC motor can be classified into:
- Armature Control Methods
- Field Control Methods
Simulink model :
- Here first we need to creat simulink model of the DC motor and make it as subsytem called the DC motor
- So next the subsytem of DC motor is connected to the discrete PID controller which helps in maintaining the desired speed
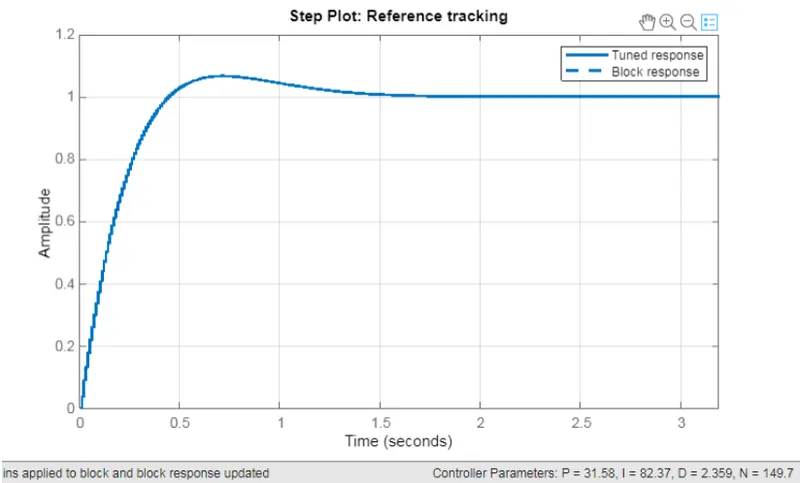
- So after the PID controller we need to start with the kp ki kd such as 1.0 1.0 0 after tunin accordingly so by this we can adjust the kp ki kd values as 31.5 82.3 2.3
- Which is used to obtaine the control design objectives
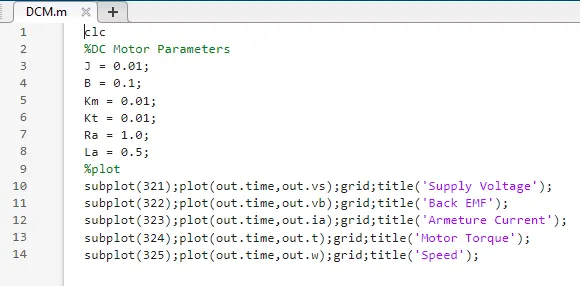
Matlab script:
Here we consider the following paramters:
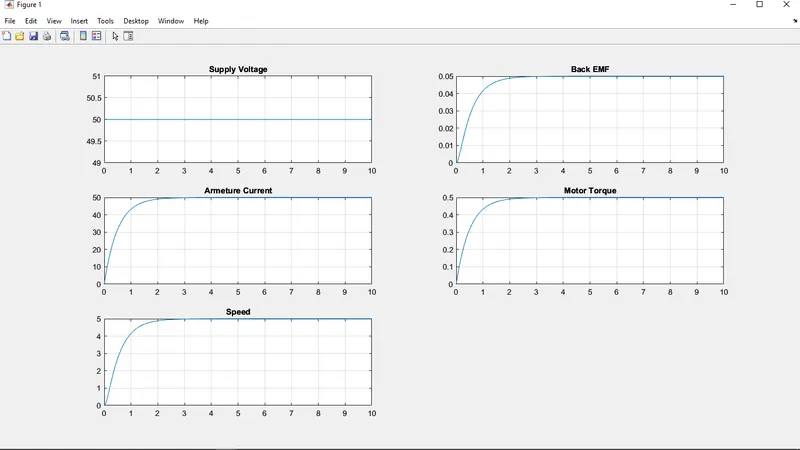
Plotting of Initial DC Motor Behaviour in Various Scenario Without any Controller -
Simulink Model DC Motor with Discrete PID Contoller :
- open the matlab and go to simulink and create the blank model
- Here first we need to creat simulink model of the DC motor and make it as subsytem called the DC motor
- So next the subsytem of DC motor is connected to the discrete PID controller which helps in maintaining the desired speed
- So after the PID controller we need to start with the kp, ki, kd such as 1.0 and 1.0 0 after tuning accordingly so by this we can adjust the kp ki kd values as 31.5, 82.3 and 2.3
- Which is used to obtaine the control design objectives
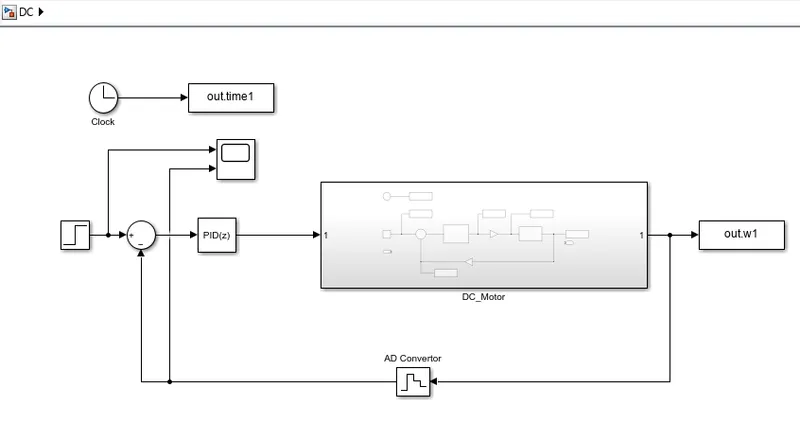
Kp =1, ki =1, kd =0
But after tuning we set kp ki kd to 31.5 82.3 2.3 which is used to obtaine the control objectives of the settling time overshoot time and steady state error.
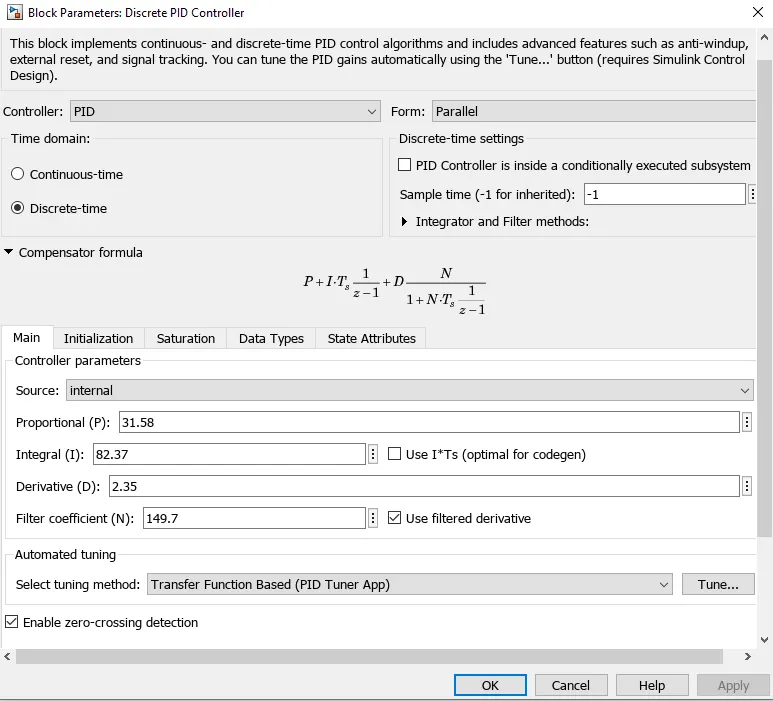
Plot Tuning as settling time as 1.5 sec:
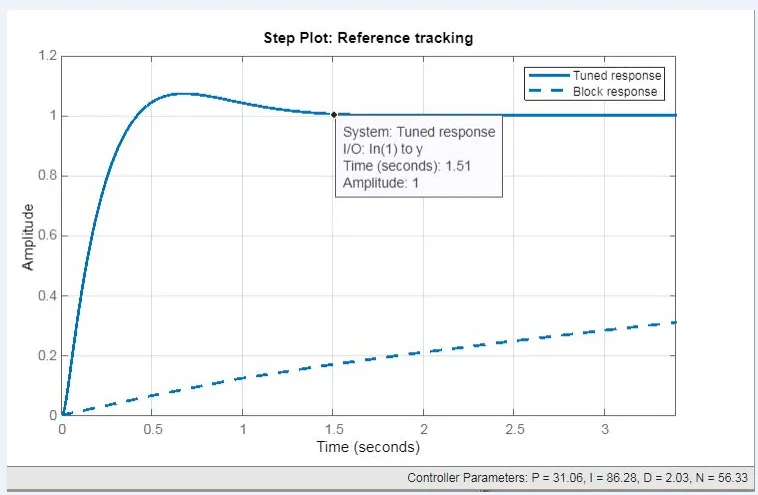
Plotting while Tuning as overshoot is less than 5% :
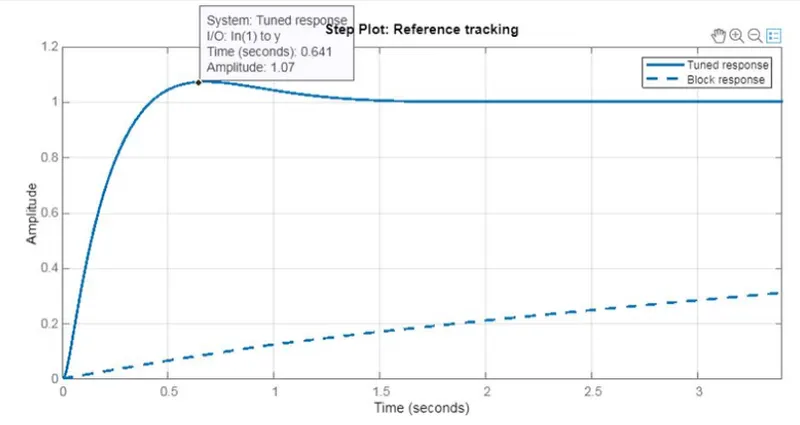
Plotting while Tuning as Steady State Error is less than 1% :
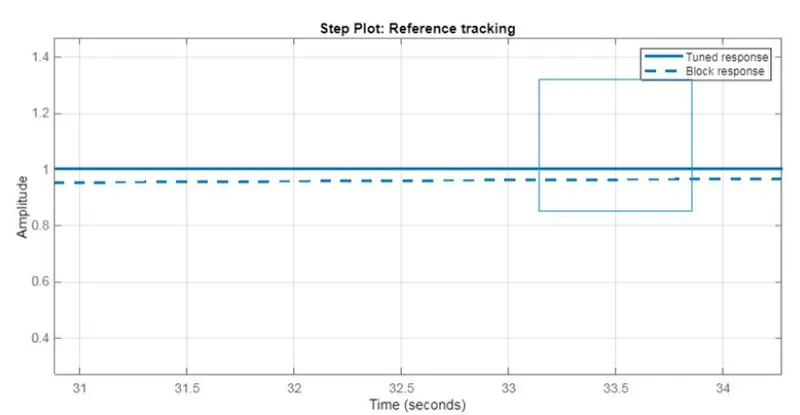
Final Plot After Updating into Block :
Scopes:
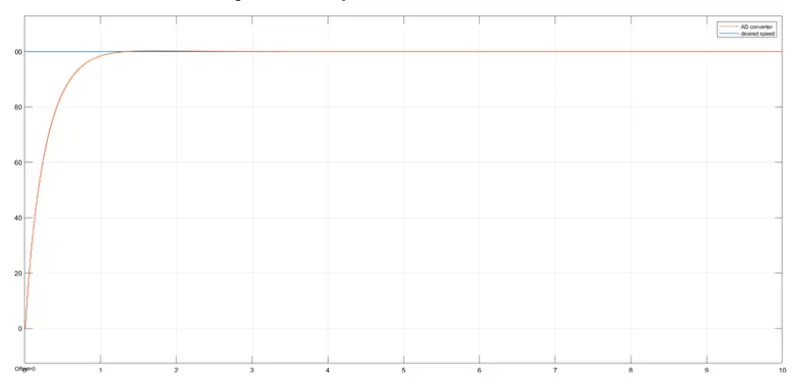
Desired Speed = 50 -
Desired Speed = 230 -
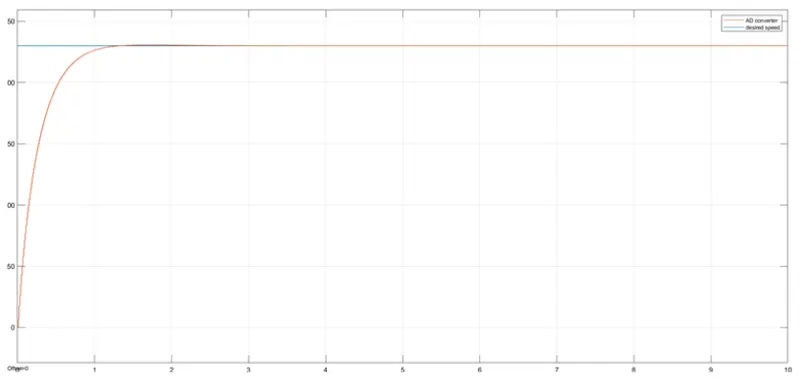
In above two cases,we change desired speed as 30 in case 1 and 230 in case 2 , since the both a case, Plotting Remains same. Hence, we maintain desired Speed For a Dc Motor.
Conclusion :
We desined a Simulink model for the DC motor and also we Use PID control design knowledge gained in the training to design develop and test a controller to maintain a desired speed for the motor.