Project - Speed Control of a Direct Current (DC) motor
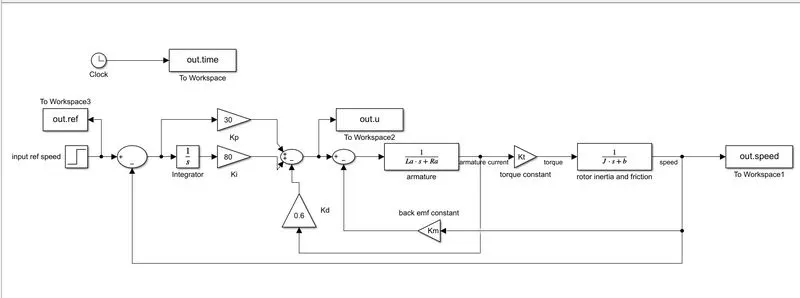
The blocks required for this simulink model are-
one clock block,seven workspace blocks,five gain blocks,three sum blocks,two transfer function blocks,one integrator block and one step block.
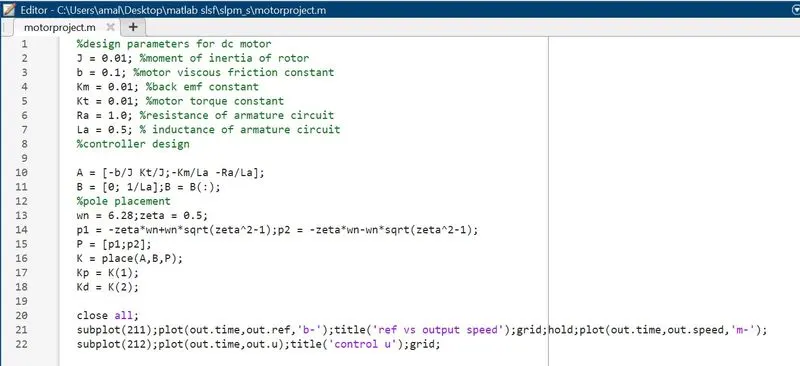
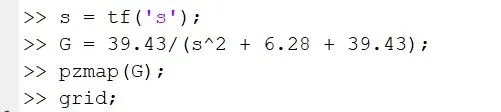
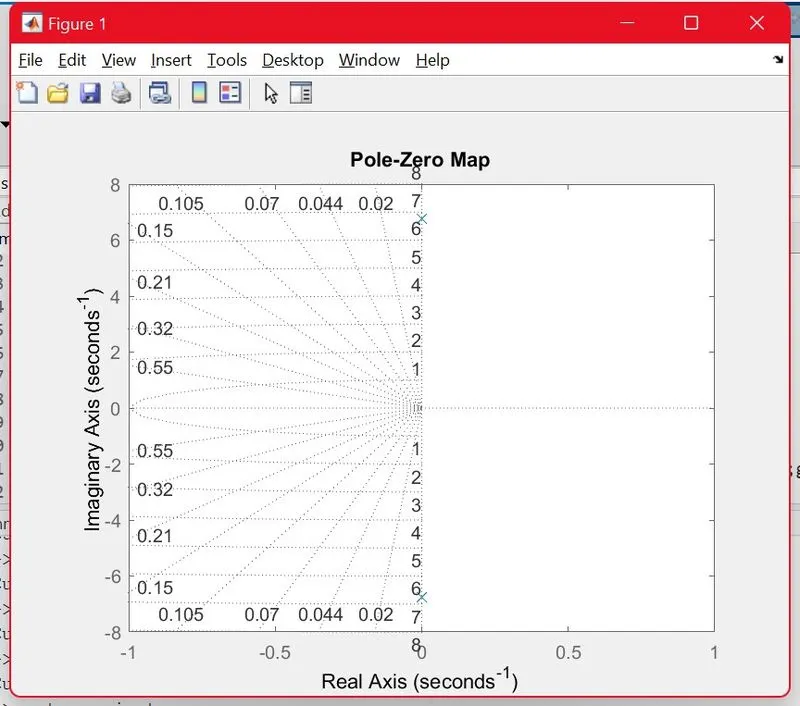
The state space equation of the motor is derived from the schematic diagram and they are arranged into the form of matrices and substituted with suitable values.The poles are found
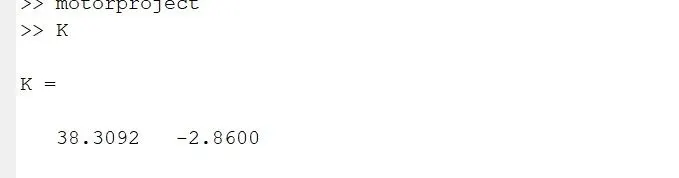
using the equation.The poles are on the jw axis ,and will produce incessant motion,when the damping is zero,therefore the system is stable.Using the values of poles and matrices,the value of gain block K can be found out using the place command.
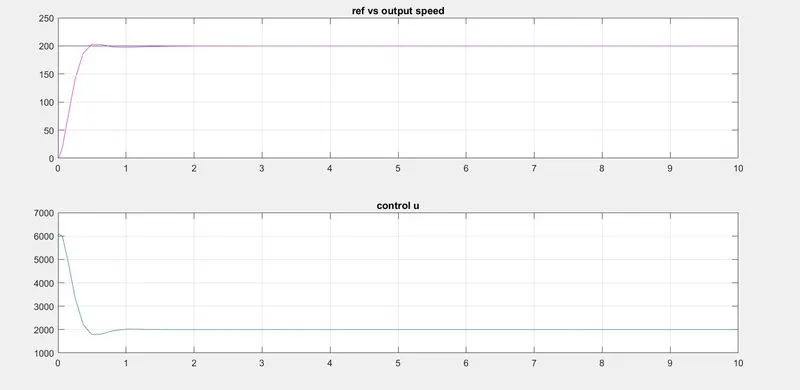
Step block is used to give the reference input speed.Actual speed is subtracted to get the error signal.Error signal goes through the gain blocks and gets added using sum block to become the control signal.The three control gain blocks are named Ki,Kp and Kd ,are given values to get the correct regulation of the speed considering the objectives for settling time,rise time and steady state error are met.The values in matrices are entered in the transfer functions.The values of Kd and Kp are got from place command.Then the values of ki ,Kd and Kp are manipulated manually to get suitable response.The step block is given value 200.The waveforms of input reference speed,output speed and control are plotted using the plot command in the editor window.Therefore ,the model is verified.