Project - Speed Control of a Direct Current (DC) motor
PROJECT -: Speed Control Of Direct Current Motor.
DC Motor -: A DC motor is an electrical machine that converts electrical energy into mechanical energy. In a DC motor, the input electrical energy is the direct current which is transformed into the mechanical rotation.DC motors can vary in size and power from small motors in toys and appliances to large mechanisms that power vehicles, pull elevators and hoists, and drive steel rolling mills.
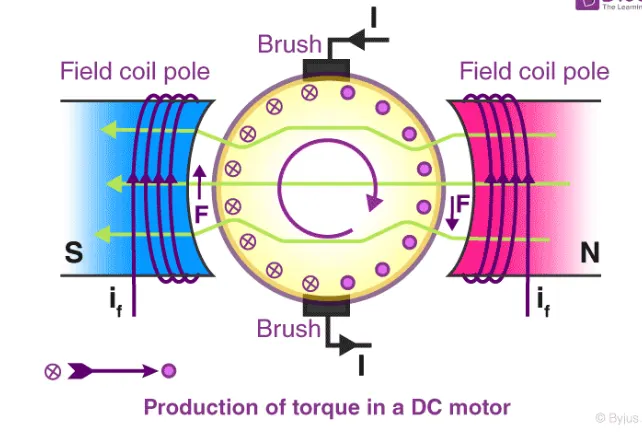
A DC motor or machine consists of two windings namely field winding and armature winding. The field winding is stationary and the armature winding can rotate.
The field winding produces a magnetic flux in the air gap between the armature and field windings and the armature is placed in this magnetic field.
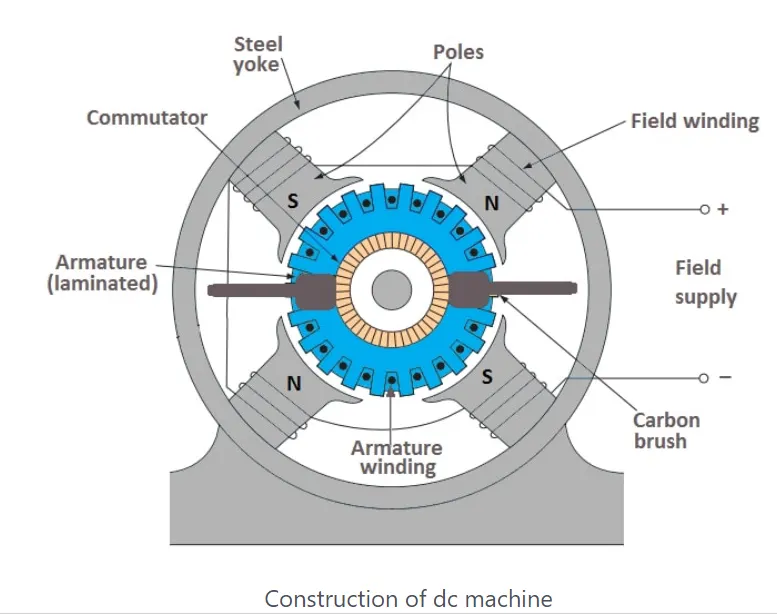
There are three main ways to achieve speed regulation in series DC motors–flux control, voltage control, and armature resistance control.
In the flux control method, a rheostat (a type of variable resistor) is connected in series with the field windings.
The controlling of armature resistance controls the voltage drop across the armature. With this method, the speed of the DC motor can control.
DC Motor Speed control using PID
DC motors are used in numerous industrial applications like servo systems and speed control applications. For such systems, the Proportional, Integral, Derivative (PID) controller is usually the controller of choice due to its ease of implementation, ruggedness, and easy tuning.
A PID controller is an instrument used in industrial control applications to regulate temperature, flow, pressure, speed and other process variables. PID (proportional integral derivative) controllers use a control loop feedback mechanism to control process variables and are the most accurate and stable controller.
AIM -: Design a PID controller to regulate the speed of the DC Motor
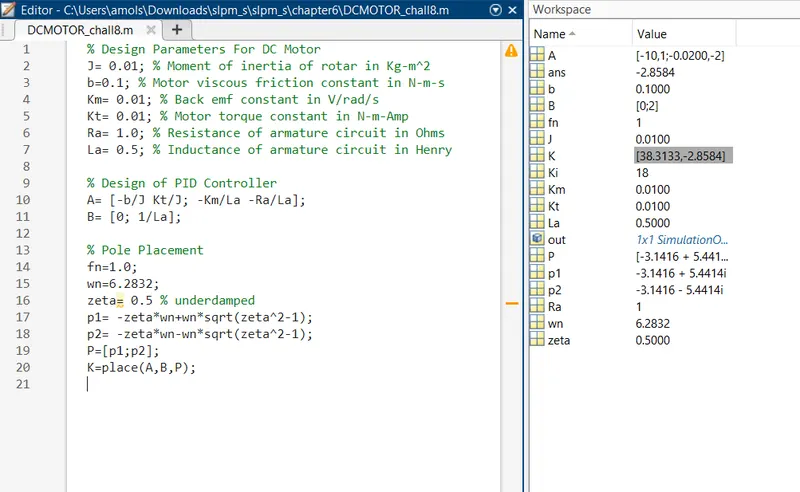
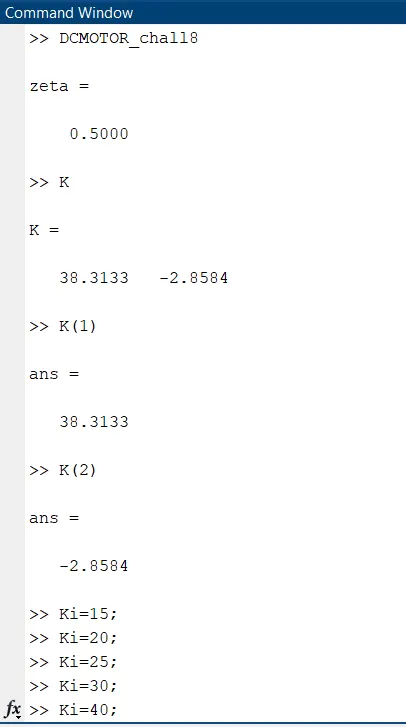
PID controller is been build by finding the values of Kp, Kd by using Matlab command 'place'.
The value of Ki is set manually to find out the behaviour of the system at different values of Ki.
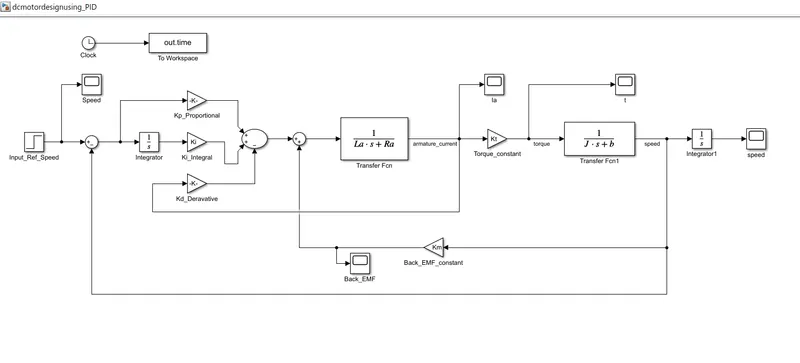
Step input block is been used as reference speed input.
The Editor script file is been build consisting of design parameters.
Model is been build to regulate the speed of the DC Motor by using PID Controller.
command window for selecting different values of Ki.
The reference speed is kept to 20.
Different values of Ki are been taken and accordingly waveforms are been generated as shown below.
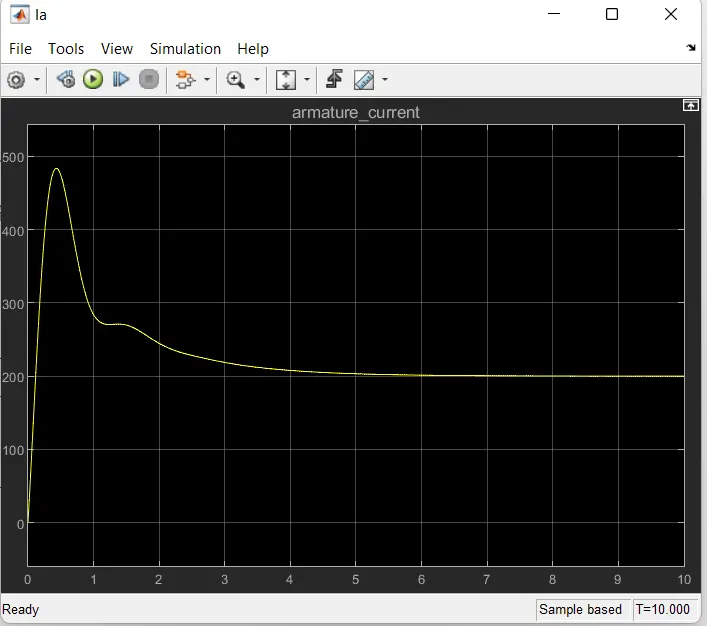
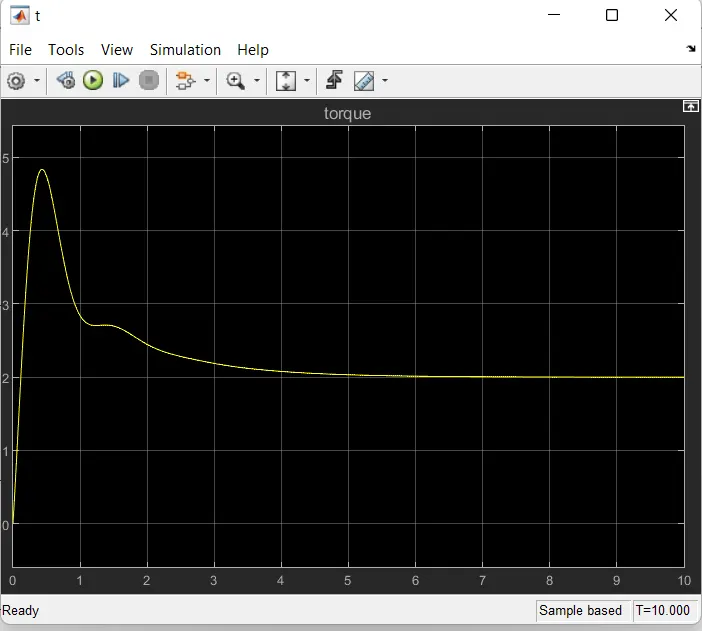
for Ki=15,
For this value of Ki the system settles at 5.5 sec with less oscillations. Though it has less oscillations but its settling time is more. The settling time should be near about 4secs.
the waveforms for Current Ia, Torque t are shown below.
For Ki=20,
For this value of Ki the settling time is near about 4 secs. the waveform has a little oscillations i.e overshoot and undershoot before settling at stable state.
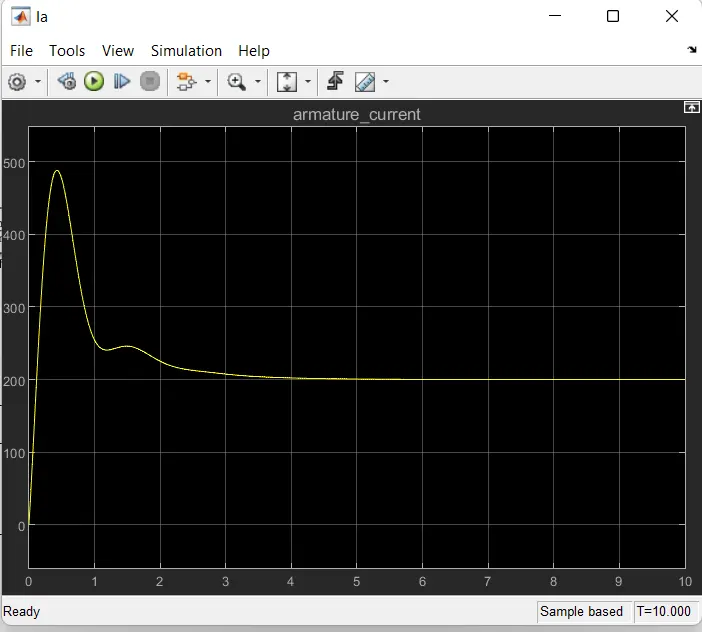
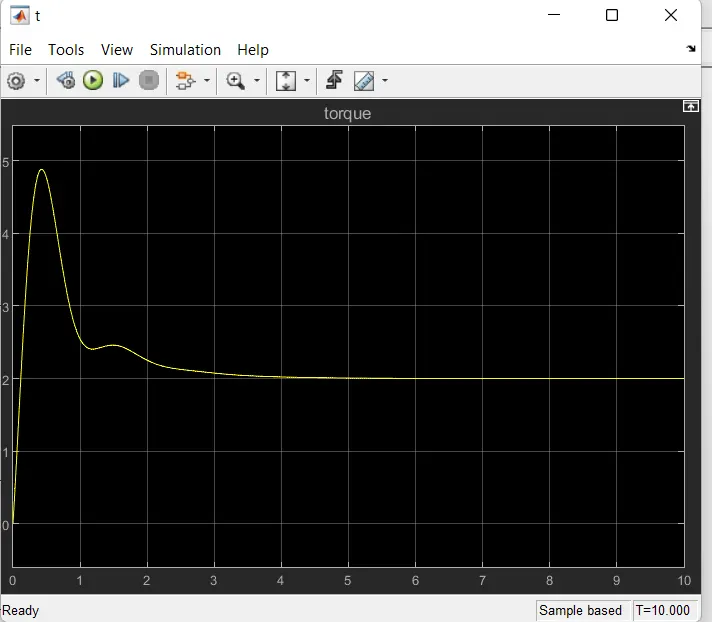
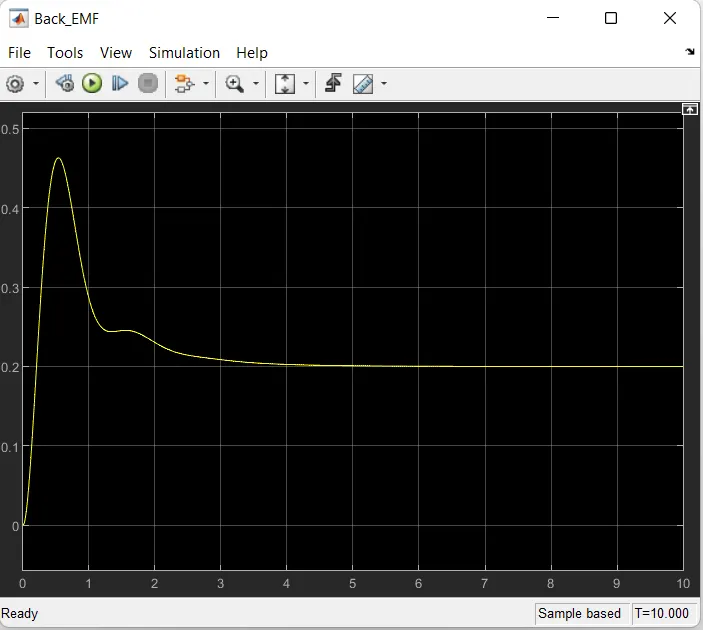
AT Ki= 25,
For this value of Ki settling time has quite been reduced it has been reduced to 3.5 secs, but system has more oscillations before comming to stability.
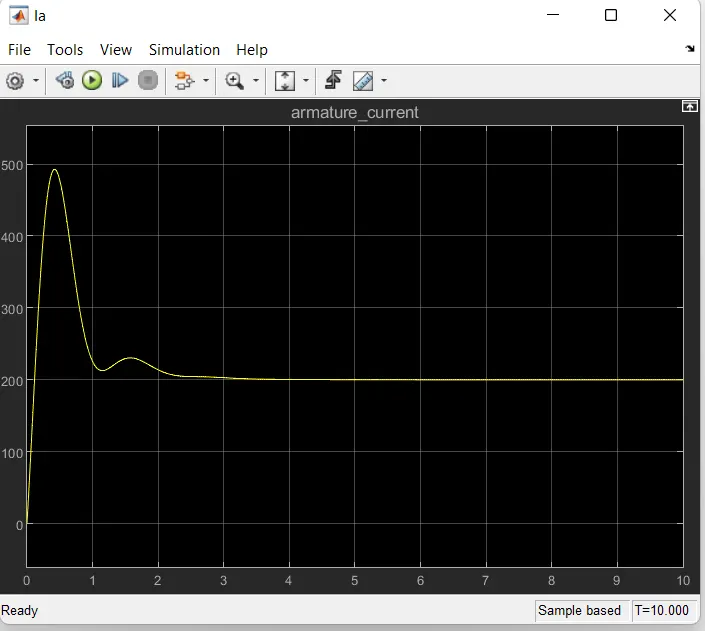
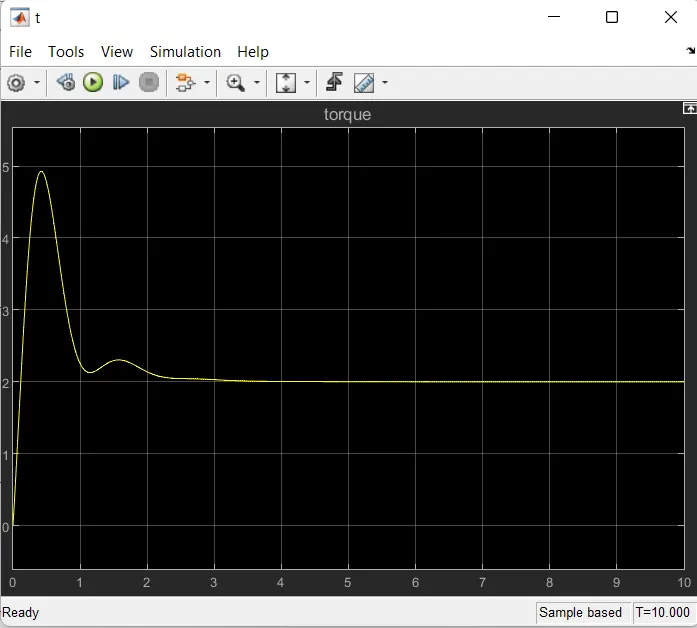
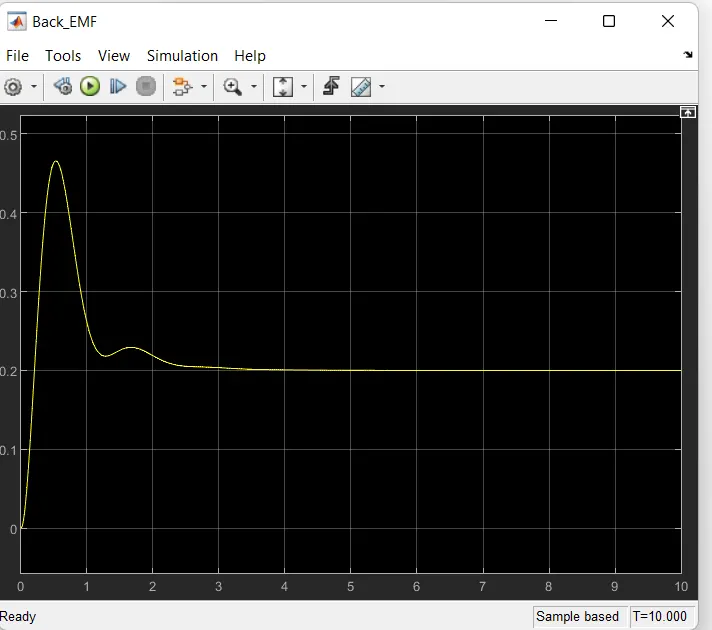
AT Ki=30,
the system settles at 3 sec but has overshoots and undershoots befor settling.
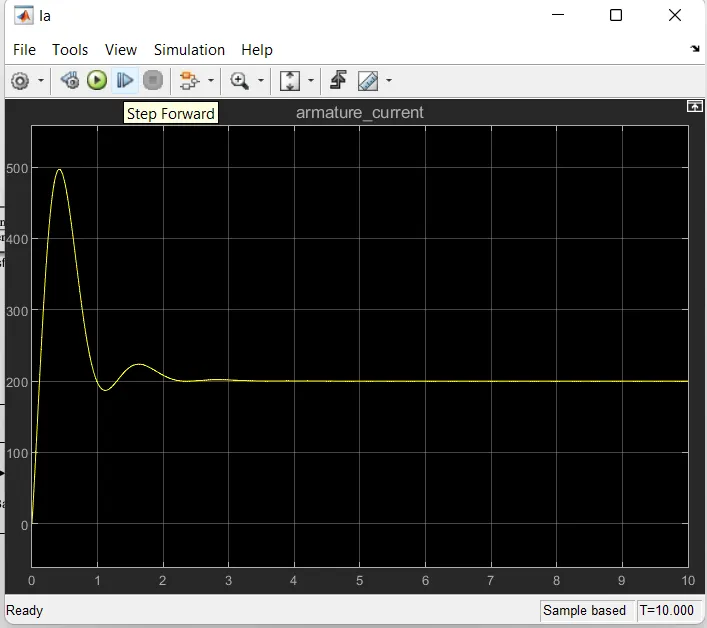
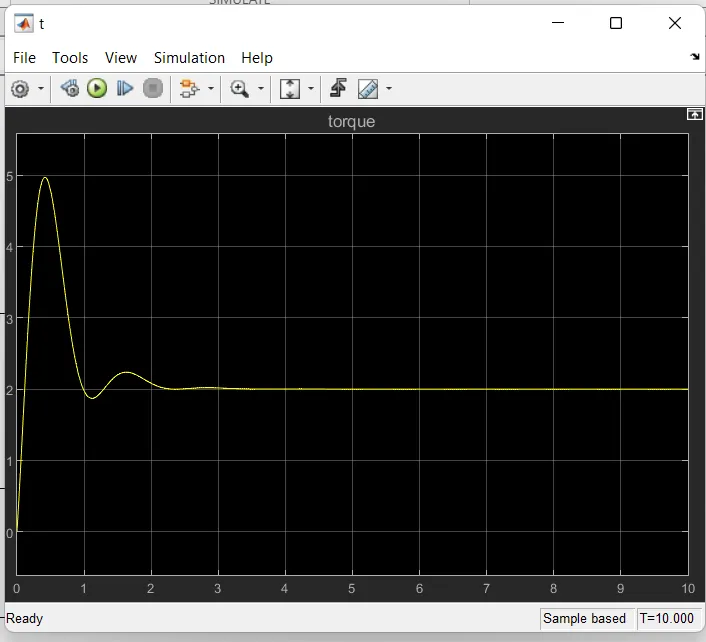
AT Ki=40,
As we go on increasing the value of Ki the system behaves faster, with oscillatons and low settling time.
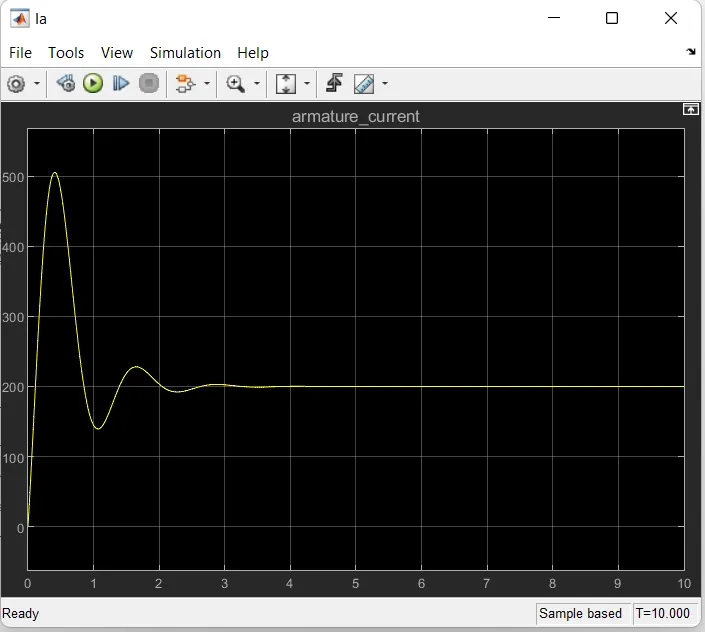
Conclusion-:The model is been simulated using different values of Ki. There were less oscillations when Ki was kept low but the settling time was more. For higher values of Ki the system response was faster with more oscillations and lesser settling time. It is required that the system must settle near about 4 secs with less oscillations. So it can be conclued that the values of PID Controller for better results must be,
Kp= +38.3133
Kd= -2.8584
Ki= +20
Key Highlights-:
Increasing Kp makes the controller more aggressive, it reduces the settling time, but also increases the oscillations, overshoot and settling time.
Increasing Ki helps in eliminating steady-state error, but increases oscillationsand overshoot.
Increasing Kd smoothens out oscillations and decreases overshoot, but a high Kd can make the system unstable.