Project - Speed Control of a Direct Current (DC) motor
DC motor converts electrical energy into mechanical energy by interaction of two magnetic field, one produced by magnet of poles, and other produce by aramture current on rotataing part.
This project is divided into two parts
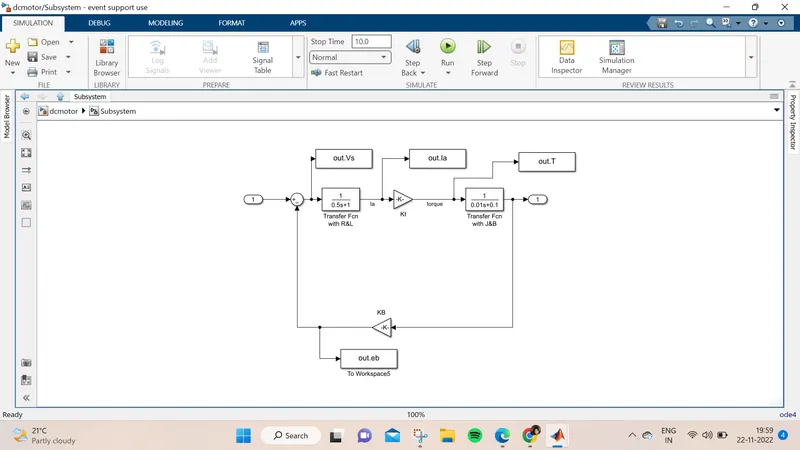
1. Design a simulink of dc model, and then make it a subsystem.
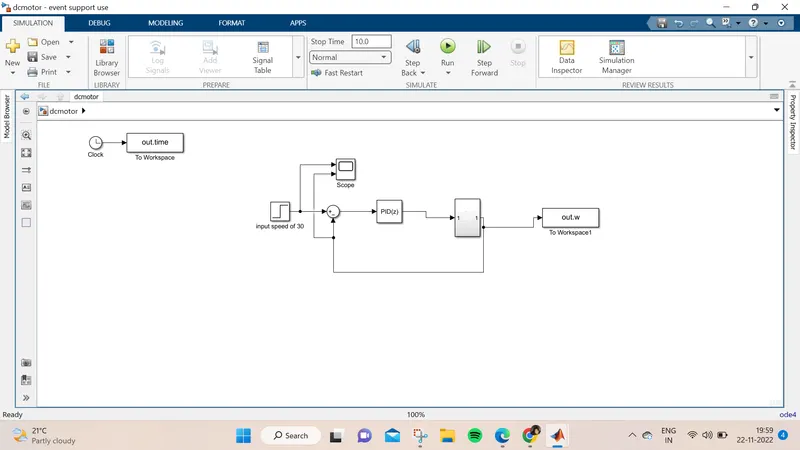
2. Using a discreate PID C ontroller for simulink blocks ,controlling speed of motor.
1. Design a simulink of dc model, and then make it a subsystem.
Here , following parametere are consider for design of dc motor.
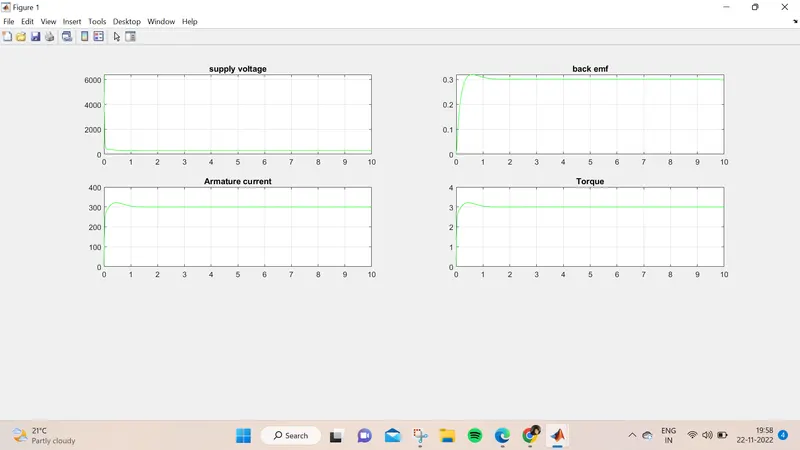
2. Using a discreate PID C ontroller for simulink blocks ,controlling speed of motor.
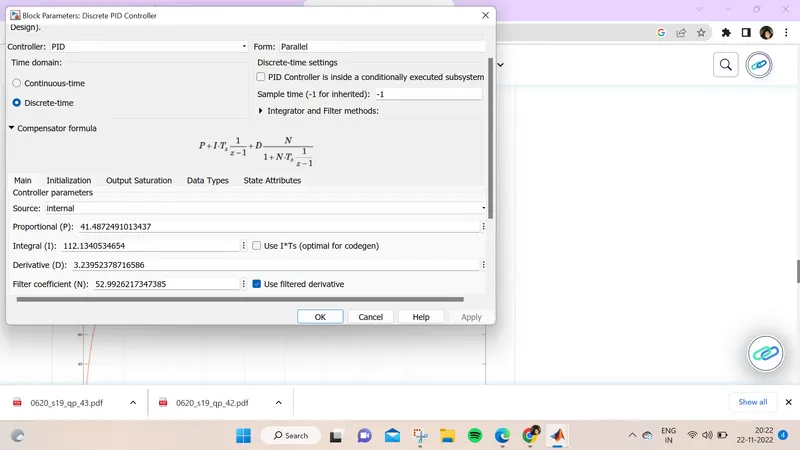
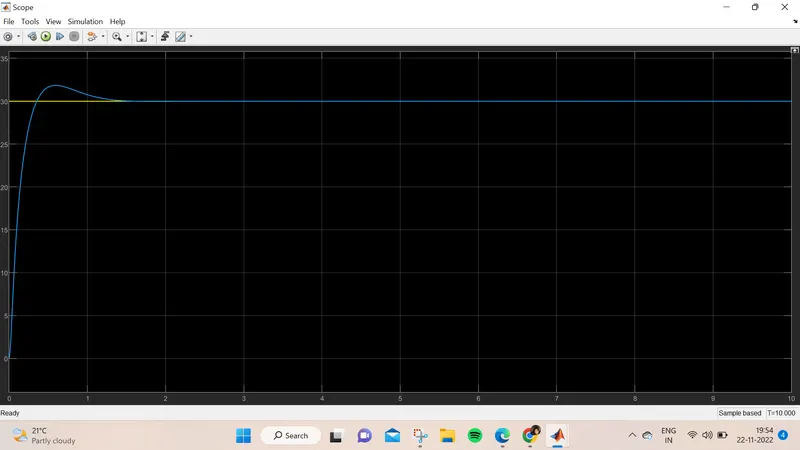
In this PID controller is taken from simulink blocks, value of Ki, Kp, Kd is chosen randomly and then using tune option the value of Ki, Kp, Kd is chosen to reduce overshoot, steady state error and settling time .